
解决基于对应的方法中的对称性模两可,用于实例级对象位估计

概括
本研究介绍了SymCode和SymNet,用于从图像中估计对象姿势,特别是对对称对象. 新方法使用一对多对应的方法来克服模两可,并实现快速,准确的结果.
科学领域:
- 计算机视觉 计算机视觉
- 机器人技术 机器人技术 机器人技术
- 机器学习 机器学习
背景情况:
- 从RGB图像中估计对象的姿势是具有挑战性的,特别是在对称的对象.
- 使用一对一像素到顶点对应的现有方法与对称性诱导的模糊性作斗争.
研究的目的:
- 为准确的6D对象构成对称对象的估计开发一种新的方法.
- 为了解决与一对一通信方法固有的模两可的问题.
主要方法:
- 提出了SymCode,一种使用一对多对应的对称感知表面编码.
- 介绍了SymNet,这是一个端到端的网络,用于直接进行6D姿势回归,绕过PNP解决器.
主要成果:
- 与现有方法相比,SymNet的运行时间更快.
- 在具有许多对称对象的T-LESS和IC-BIN基准上取得了可比的准确性.
结论:
- 拟议的SymCode和SymNet有效地处理对称对象的姿势估计.
- 该方法为6D姿势估计任务提供了高效和准确的替代方案.

相关概念视频
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
382
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
382
 01:03
Centroid of a Body: Problem Solving
1.1K
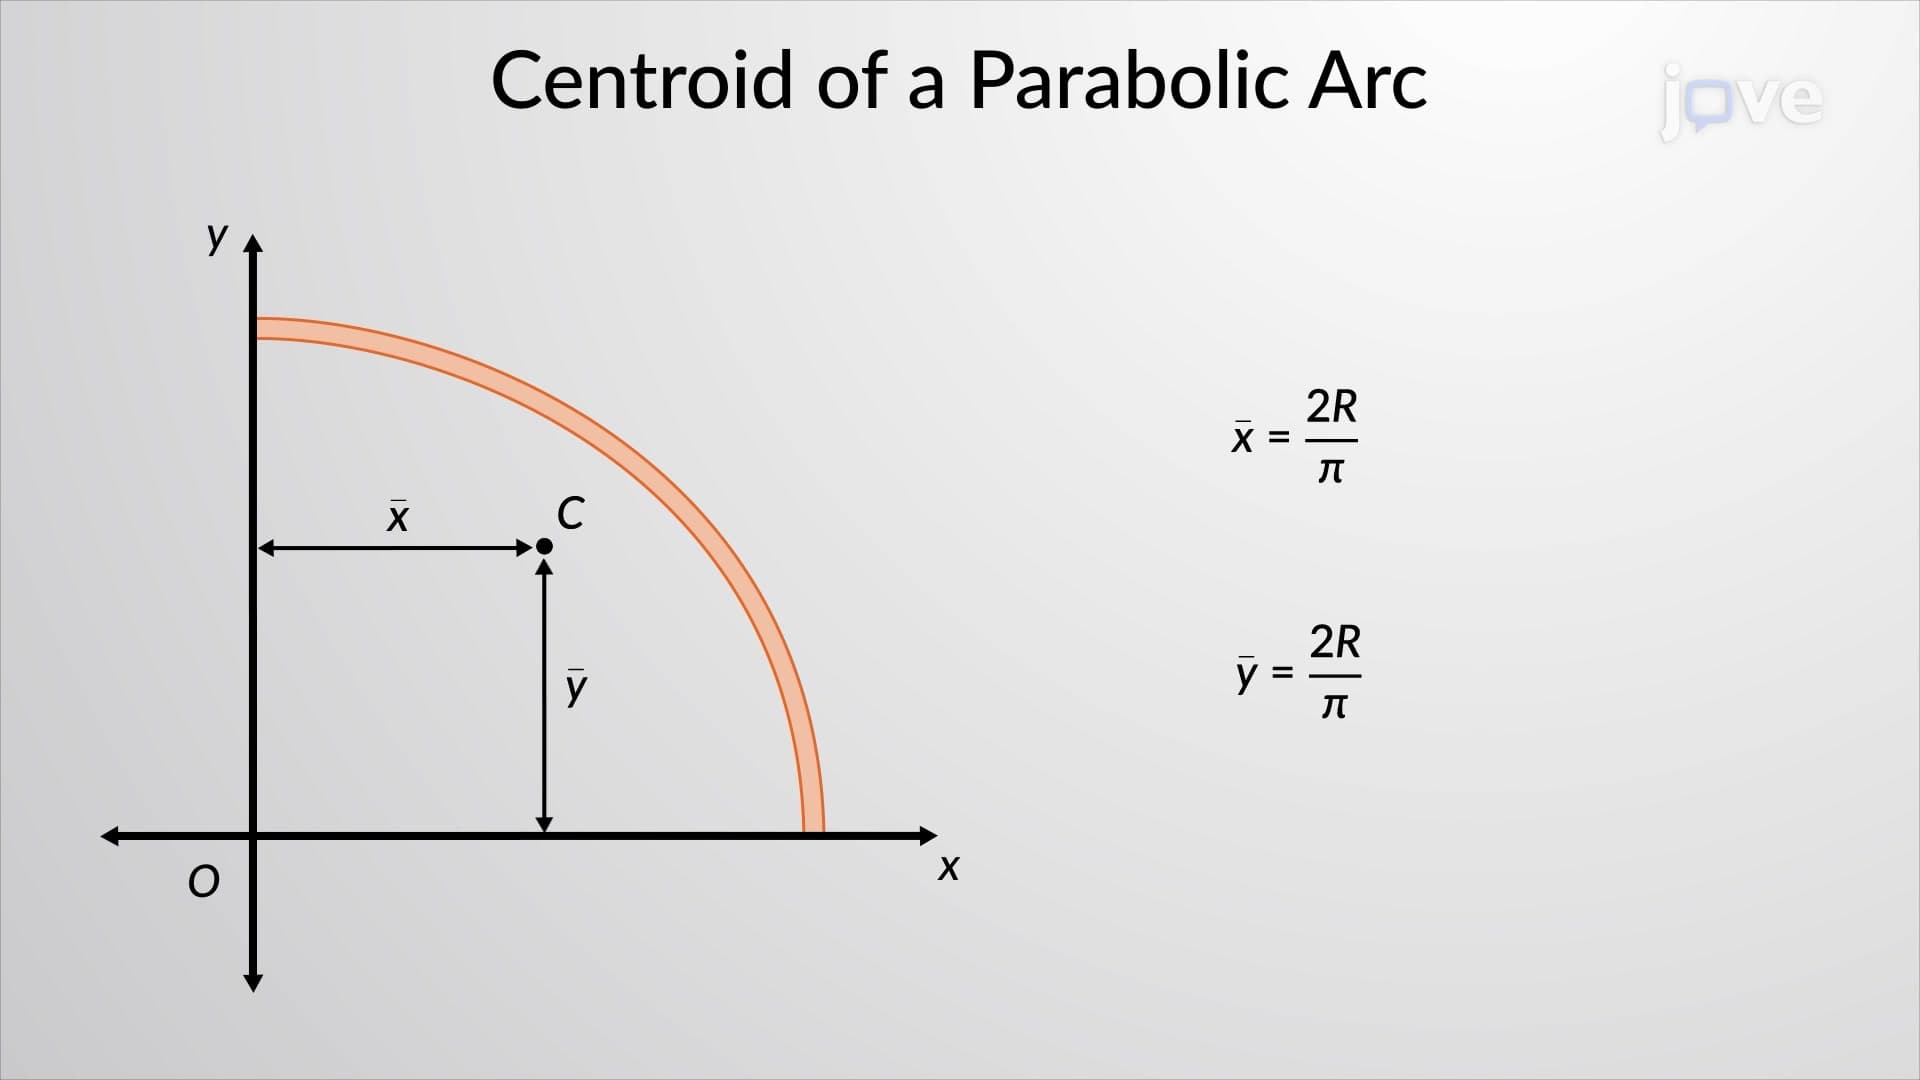
The centroid of a body is a crucial concept in engineering and physics. Finding the centroid of a body can help determine its stability, its balance point, and even its design. In this context, consider a thin wire bent in the form of a quarter circular arc. Polar coordinates are used to calculate the centroid. The wire is first divided into small differential elements of a length equal to the radius multiplied by the differential angle.
The x-coordinates and y-coordinates of each element's...
The x-coordinates and y-coordinates of each element's...
1.1K
 01:21
Rigid Body Equilibrium Problems - II
6.9K
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
6.9K
 00:49
Rigid Body Equilibrium Problems - I
4.3K
A rigid body is said to be in static equilibrium when the net force and the net torque acting on the system is equal to zero. To solve for rigid body equilibrium problems, do the following steps.
4.3K
 01:15
Kinematic Equations: Problem Solving
11.8K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
11.8K
 01:15
Unsymmetric Bending - Angle of Neutral Axis
265
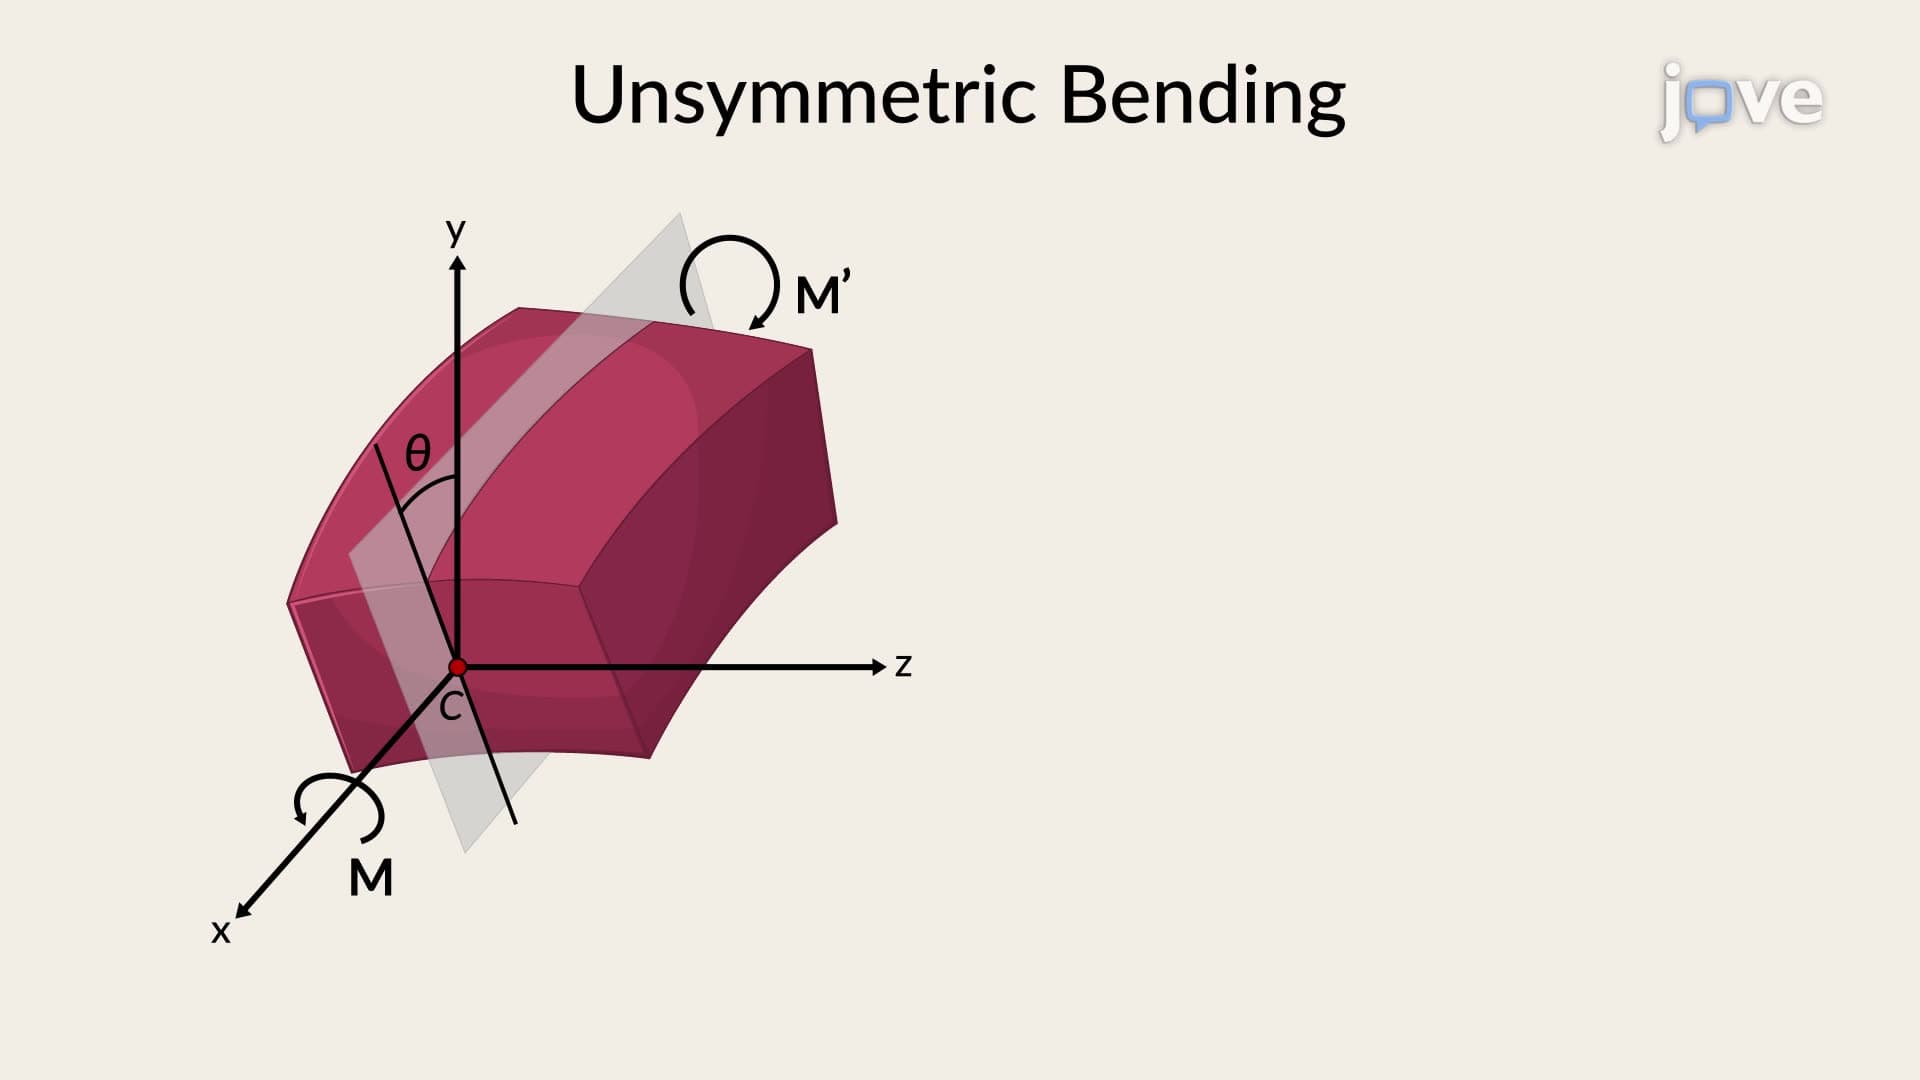
Unsymmetrical bending occurs when a structural member is subjected to bending moments in a plane that does not align with the member's principal axes. This scenario typically arises in beams and other structural components when loads are applied at non-ideal angles, introducing complexities in stress analysis.
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal...
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal...
265