每一个角度都值得一看:从多视图联合云挖掘动力学骨结构
IEEE transactions on visualization and computer graphics
|March 3, 2025

概括
这项研究引入了一种用于多人运动捕捉的新方法,通过使用联合云和变压器克服阻塞的挑战. 这种方法有效地从稀疏的摄像头视图中选择准确的3D人体姿势.
科学领域:
- 计算机视觉 计算机视觉
- 人类运动分析分析
- 机器学习 机器学习
背景情况:
- 从稀疏的观测中捕捉多人运动是很困难的,因为自我和相互封闭.
- 现有的2D-to-3D提升方法在准确的联合候选人选择和身份关联方面扎.
- 强大的人体姿势估计需要有效地利用所有可用的二维关节信息.
研究的目的:
- 从稀疏的,封闭的2D观测中开发一个用于准确的多人3D运动捕捉的新框架.
- 解决现有方法在处理联合模糊性和身份关联方面的局限性.
- 改进2D关节检测数据的利用,以进行可靠的3D姿势估计.
主要方法:
- 通过在视图中三角化所有相同类型的2D连接,无论目标ID如何,提出了一个联合云.
- 推出了联合云选择和聚合变压器 (JCSAT) 与三个级联编码器.
- 开发了一个最佳令牌注意路径 (OTAP) 模块,用于特征选择和聚合.
主要成果:
- 在JCSAT框架有效地处理冗余的3D联合候选人从联合云.
- OTAP模块成功地选择了信息特征,以准确预测人类运动.
- 在基准和一个新的具有挑战性的数据集 (BUMocap-X) 上实现了最先进的性能.
结论:
- 拟议的JCSAT框架显著提高了多人运动捕捉的准确性,特别是在严重的遮蔽下.
- 联合云和JCSAT有效地处理3D中的模糊性,从稀疏的视图进行估计.
- 与现有的最先进的技术相比,该方法显示出更高的性能.

相关概念视频
 01:20
Structural Classification of Joints
3.1K
Joints, also known as articulations, are classified based on their structural characteristics, i.e., based on whether the articulating surfaces of the adjacent bones are directly connected by fibrous connective tissue or cartilage, or whether the articulating surfaces contact each other within a fluid-filled joint cavity. These differences serve to divide the joints of the body into three structural classifications.
A fibrous joint is where the adjacent bones are united by fibrous connective...
A fibrous joint is where the adjacent bones are united by fibrous connective...
3.1K
 01:55
Bone Structure
47.9K
Within the skeletal system, the structure of a bone, or osseous tissue, can be exemplified in a long bone, like the femur, where there are two types of osseous tissue: cortical and cancellous.
47.9K
 01:30
Kinematic Equations for Rotation
301
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
301
 01:18
Kinematic Equations - III
7.4K
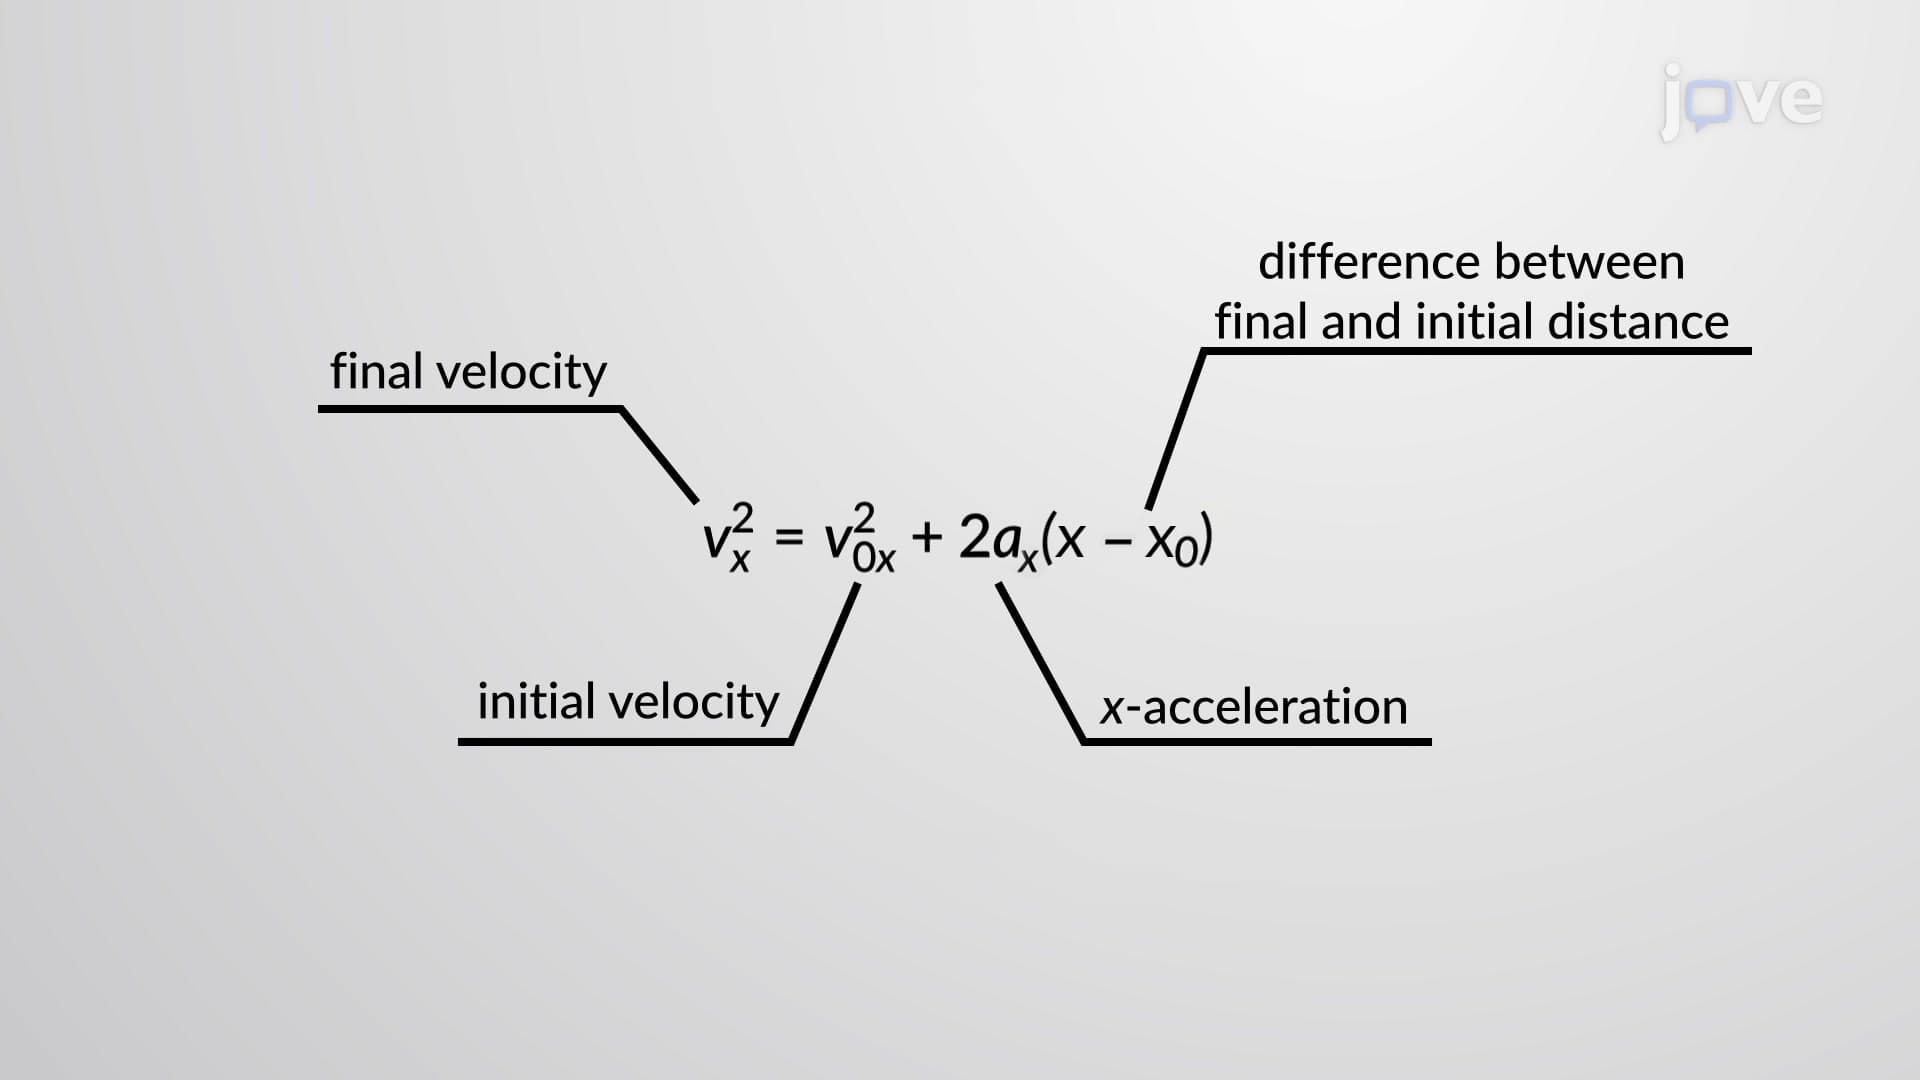
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.4K
 01:17
Kinematic Equations - II
9.2K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
9.2K
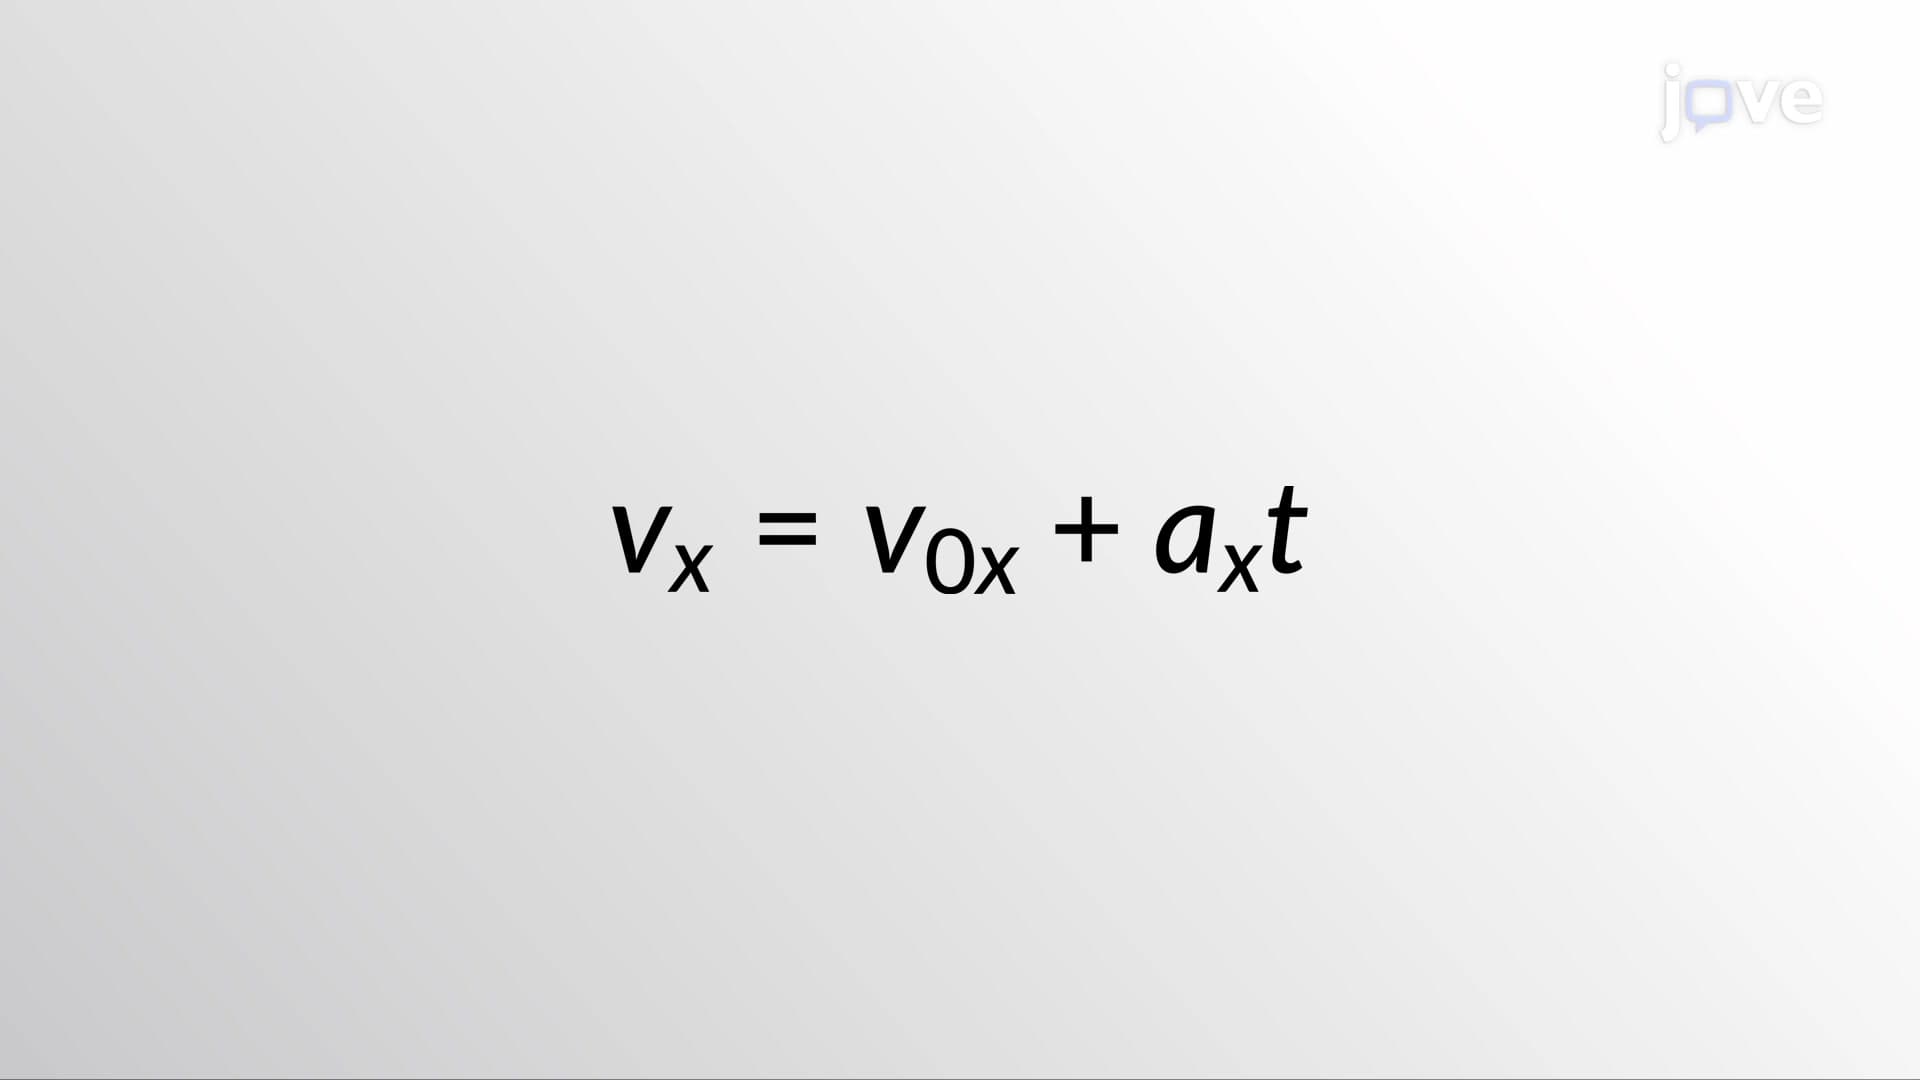 01:26
Kinematic Equations - I
10.2K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
10.2K