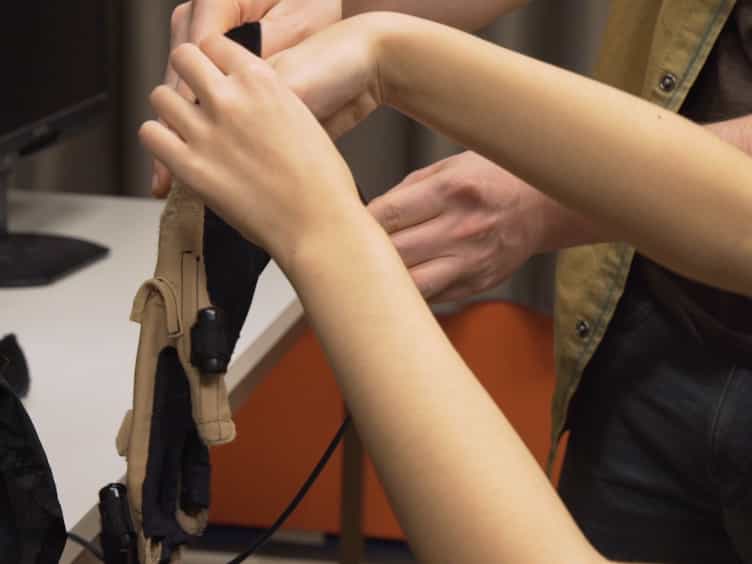

"一个身体,但四只手":探索虚拟手在虚拟共体化中的作用
IEEE transactions on visualization and computer graphics
|March 11, 2025

概括
虚拟现实 (VR) 的共同体现增强了技能转移. 与虚拟手匹配的虚拟手.
科学领域:
- 人与计算机的交互
- 虚拟现实 虚拟现实 虚拟现实
- 认知科学 认知科学
背景情况:
- 在虚拟现实中,虚拟共同体现使共享的化身能够进行技能转移,影响所有权感 (SoO) 和代理感 (SoA).
- 虚拟现实运动显示中的不匹配可以阻碍用户体验和学习效率.
- 在虚拟现实中,共体手的视觉因素对于它们对用户感知的影响还没有得到充分的研究.
研究的目的:
- 调查虚拟自助者的存在对SoO,SoA以及VR共体中的社交存在的影响.
- 检查虚拟手的透明度和一致性对SoO,SoA和社交存在的影响.
- 提供设计见解,以优化VR共体场景中的虚拟手的外观.
主要方法:
- 在虚拟现实环境中进行了两项用户研究.
- 评估了虚拟自助手的存在,透明度和一致性的影响.
- 通过拥有感 (SoO),代理感 (SoA) 和社交存在来衡量用户体验.
主要成果:
- 虚拟自助手的存在显著改善了SOO和SOA.
- 自我手和共同体的手之间相同的视觉外观显著增强了SoO.
- 虚拟手的透明度和一致性被确定为影响用户感知的关键因素.
结论:
- 虚拟自助手对于增强VR共体的用户体验至关重要.
- 手的视觉一致性显著提高了所有权感,这对于有效的技能转移至关重要.
- 结果提供了有价值的设计指南,用于创建更具身临其境和有效的VR联合体现体验.

相关概念视频
 01:06
Virtual Work for a System of Connected Rigid Bodies
360
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
360
 01:20
Virtual Work
775
The principle of virtual work states that if a body is in static and dynamic equilibrium, then the sum of all the virtual work done by all external forces and couple moments for any given virtual displacement must be zero.
In static equilibrium, a body can experience an imaginary or virtual movement, such as displacement or rotation. The virtual work done by a force is equal to the dot product of force and virtual displacement in the direction of the force. When it comes to virtually rotating a...
In static equilibrium, a body can experience an imaginary or virtual movement, such as displacement or rotation. The virtual work done by a force is equal to the dot product of force and virtual displacement in the direction of the force. When it comes to virtually rotating a...
775
 01:13
Principle of Virtual Work: Problem Solving
1.1K
The principle of virtual work is an essential concept in the field of mechanics and engineering. This is used to solve problems related to the equilibrium of a structure or system. It is based on the assumption that if a system is in equilibrium, the work done by all the forces during a virtual displacement is zero. This principle is applied by considering virtual displacements of the system and the corresponding work done by internal and external forces.
To apply the principle of virtual work,...
To apply the principle of virtual work,...
1.1K
 00:55
Composite Bodies
1.0K
A composite body is a body made up of multiple parts, connected to form a larger, unified object. Each part has its own weight and center of gravity, which must be considered to determine the center of gravity of the composite body. In cases where the density or specific weight is constant, the center of gravity coincides with the centroid.
Composite bodies have widespread applications in mechanical engineering, from automobiles to aircraft to rockets. For example, an automobile wheel comprises...
Composite bodies have widespread applications in mechanical engineering, from automobiles to aircraft to rockets. For example, an automobile wheel comprises...
1.0K
 01:33
Somatosensation
36.3K
The somatosensory system relays sensory information from the skin, mucous membranes, limbs, and joints. Somatosensation is more familiarly known as the sense of touch. A typical somatosensory pathway includes three types of long neurons: primary, secondary, and tertiary. Primary neurons have cell bodies located near the spinal cord in groups of neurons called dorsal root ganglia. The sensory neurons of ganglia innervate designated areas of skin called dermatomes.
36.3K