DPCS:基于路径跟踪的可差分投影机和摄像机系统
IEEE transactions on visualization and computer graphics
|March 17, 2025

概括
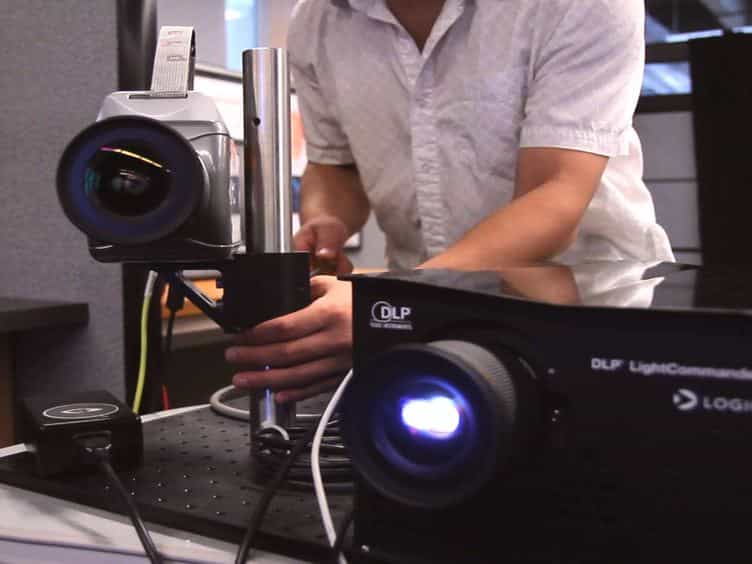
本研究介绍了可差分投影机和摄像机系统 (DPCS),这是一种用于实现现实的ProCams模拟的新型路径跟踪方法. DPCS提供了更好的解释性,并且比神经网络更好地处理复杂的效果.
科学领域:
- 计算机视觉 计算机视觉
- 计算机图形 计算机图形
- 染技术 染技术
背景情况:
- 投影机-摄像机系统 (ProCams) 模拟对于空间增强现实 (SAR) 应用,如重新照明和补偿至关重要.
- 现有的神经网络方法隐式地学习场景参数,限制了可解释性和新型场景模拟.
- 神经网络因隐含的间接照明学习而难以处理复杂的投影效应.
研究的目的:
- 开发一种可差异化的ProCams模拟方法,可以明确模拟物理项目和捕获过程.
- 通过学习的参数,实现可解释和高效的模拟新奇场景.
- 改进处理复杂的投影效果,如柔软的阴影和相互反射.
主要方法:
- 引入了可差分投影机摄像系统 (DPCS),一种基于路径跟踪的新型模拟方法.
- 利用可微分的基于物理的染 (PBR) 来建模项目和捕获过程.
- 显式解和学习场景参数,集成多弹跳路径跟踪.
主要成果:
- 与以前的神经网络方法相比,DPCS显示出更高的解释性.
- 该方法有效地处理复杂的相互反射和阴影.
- 对于有效的ProCams模拟,DPCS需要少得多的训练样本.
- 在下游的ProCams任务中取得了高质量的结果,例如重新点亮和补偿.
结论:
- DPCS为ProCams模拟提供了一种基于物理的,可差异化的方法.
- 场景参数的明确建模提高了可解释性,并使新的场景模拟成为可能.
- 在效率,准确性和处理复杂效果方面,DPCS比以前的方法提供了显著的优势.
相关概念视频
 01:24
One-Degree-of-Freedom System
444
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
444
 01:22
Planar Rigid-Body Motion
368
Understanding the movement of a rigid body in planar motion involves recognizing that every particle within this body is traversing a path that maintains a consistent distance from a specific plane. This concept is fundamental in the study of physics and mechanical engineering, and it allows us to comprehend better how objects move in space.
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
368
 01:26
PD Controller: Design
159
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
159
 01:24
Absolute Motion Analysis- General Plane Motion
199
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
199
 01:25
Design Example: Traverse Angle Computations
48
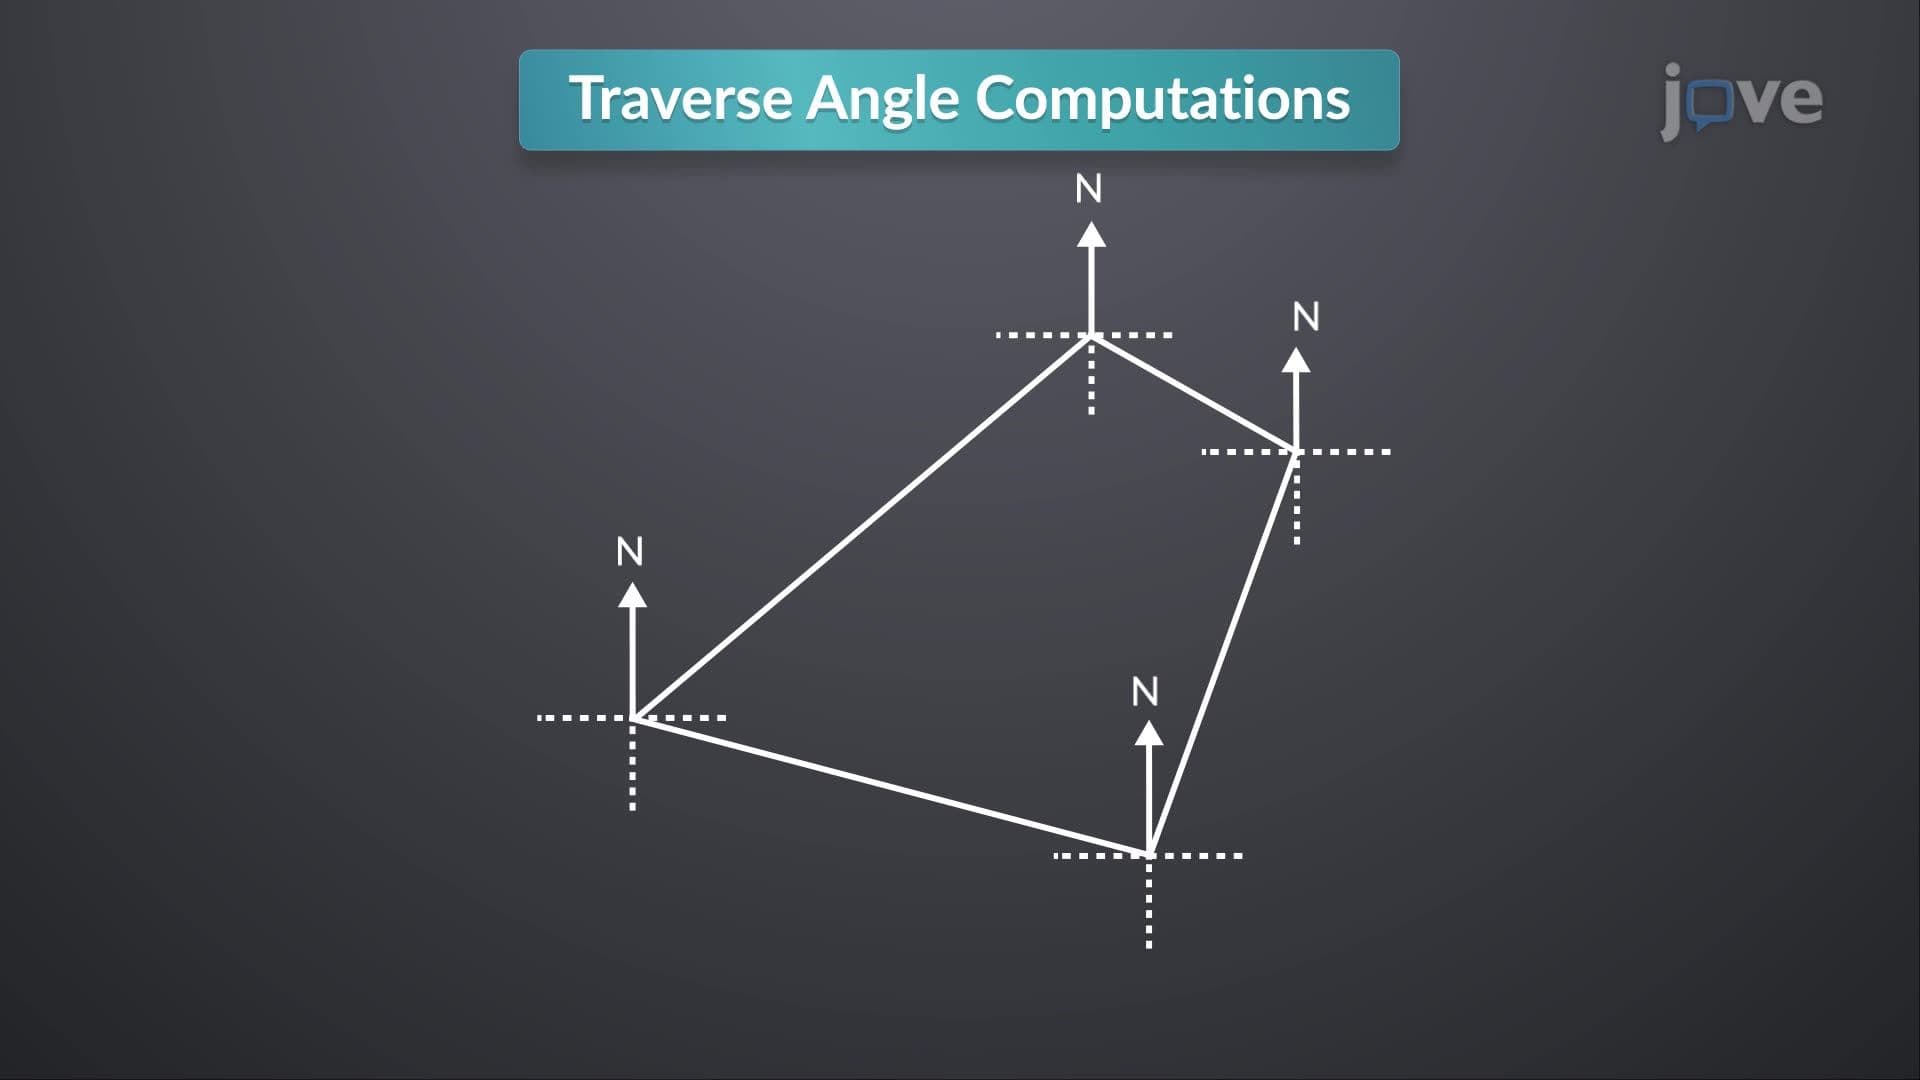
Traverse angle computations are a critical component of surveying, used to compute the internal angles within a closed traverse. A traverse consists of a series of connected lines forming a closed loop, often used for land boundary delineation or mapping. Calculating the internal angles ensures accuracy in the traverse geometry and is essential for checking survey data integrity.The process begins with known azimuths and bearings of the traverse sides. Internal angles at each vertex are...
48
 01:27
Curvilinear Motion: Polar Coordinates
337
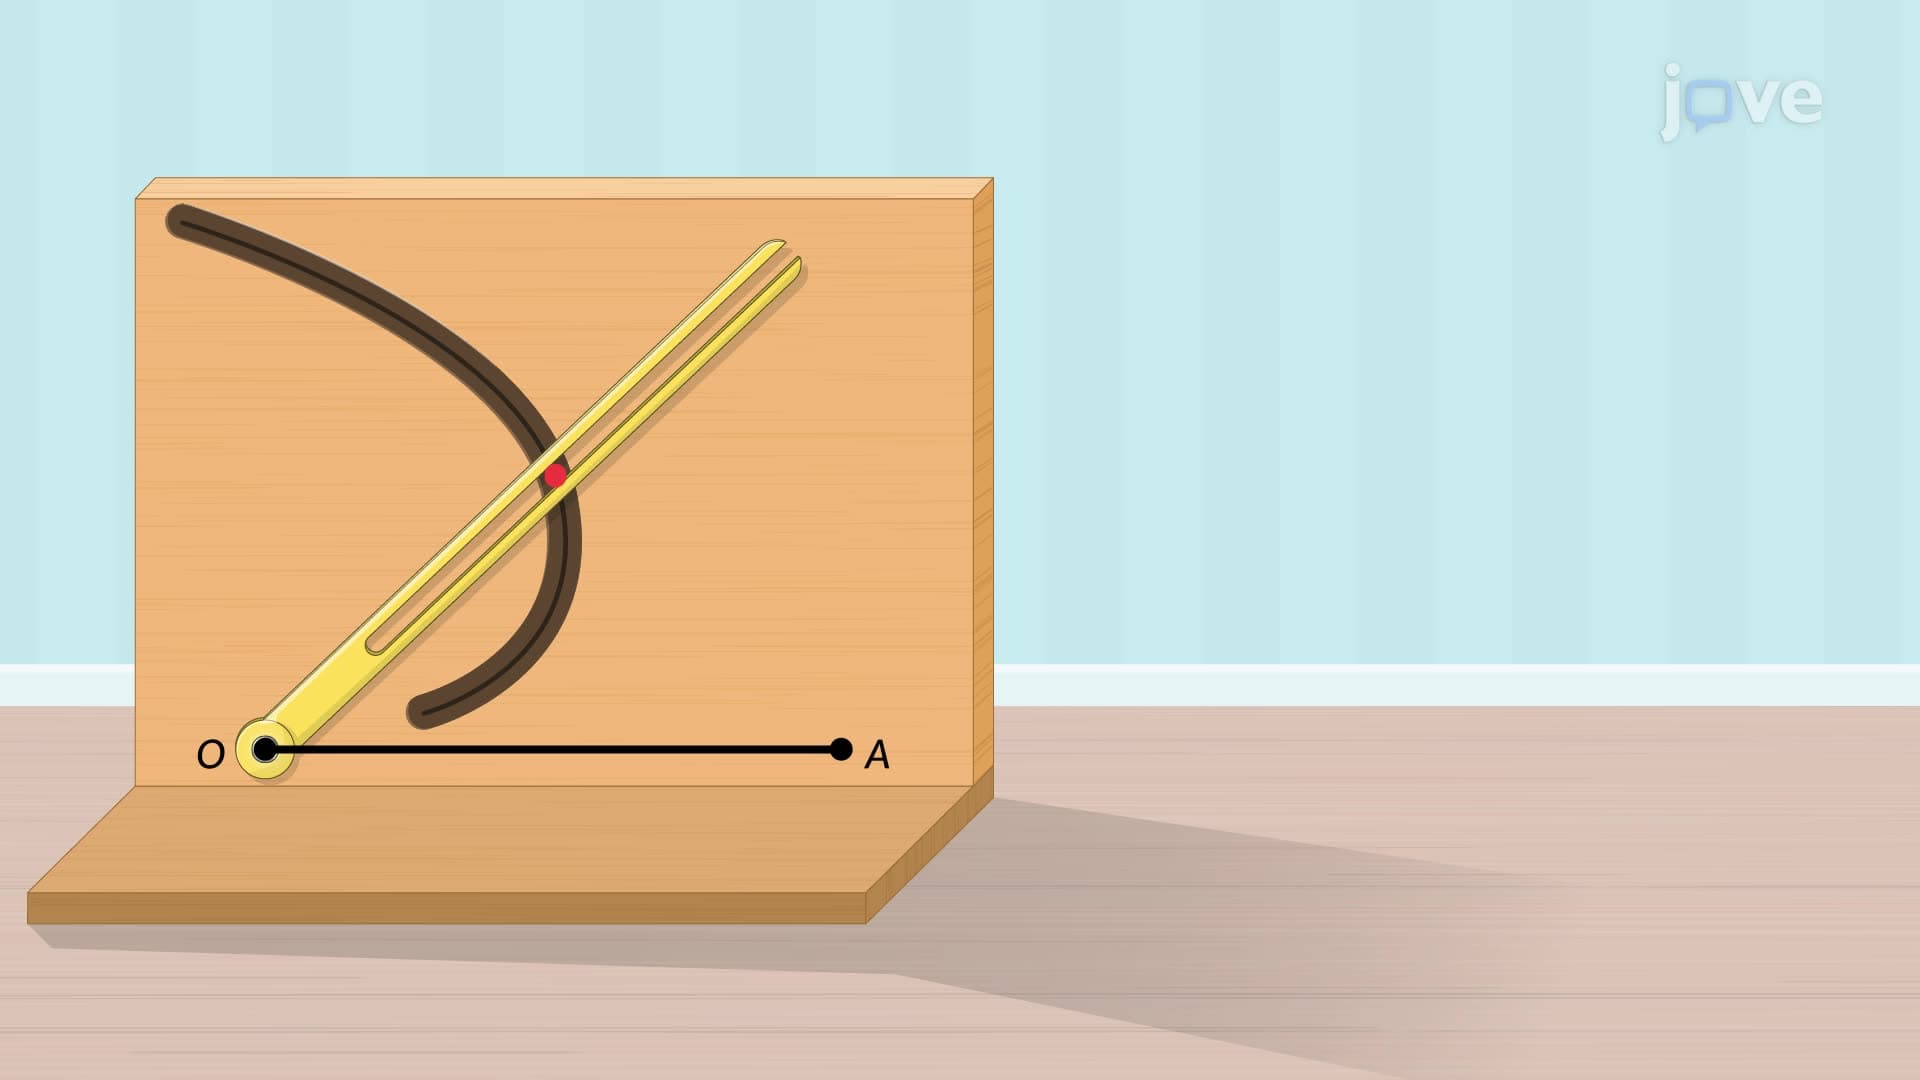
In polar coordinates, the motion of a particle follows a curvilinear path. The radial coordinate symbolized as 'r,' extends outward from a fixed origin to the particle, while the angular coordinate, 'θ,' measured in radians, represents the counterclockwise angle between a fixed reference line and the radial line connecting the origin to the particle.
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
337