

一个简单的模型来估计带状不稳定基的动力学从点附近的角度测量
1Institute of Sport Science, University of Bern, 3012 Bern, Switzerland.
Sensors (Basel, Switzerland)
|March 17, 2025

概括
本研究提出了一种具有成本效益的模型,用于估计不稳定的训练设备的角度测量中的动力学数据. 该方法适用于现实世界的应用,增强协调培训反系统.
科学领域:
- 生物力学 生物力学
- 发动机控制器的控制器
- 运动技术技术 运动技术
背景情况:
- 在不稳定的基础上进行感官运动训练可以改善平衡和协调.
- 实时运动反对于优化此类训练至关重要.
- 现有的动力学数据采集方法可能昂贵且复杂.
研究的目的:
- 为实时运动反开发一个具有成本效益的模型.
- 仅使用角度测量来估计磁带动力学数据.
- 为先进的电机控制反系统奠定基础.
主要方法:
- 建立了一个模型来估计来自角度测量的动力学数据.
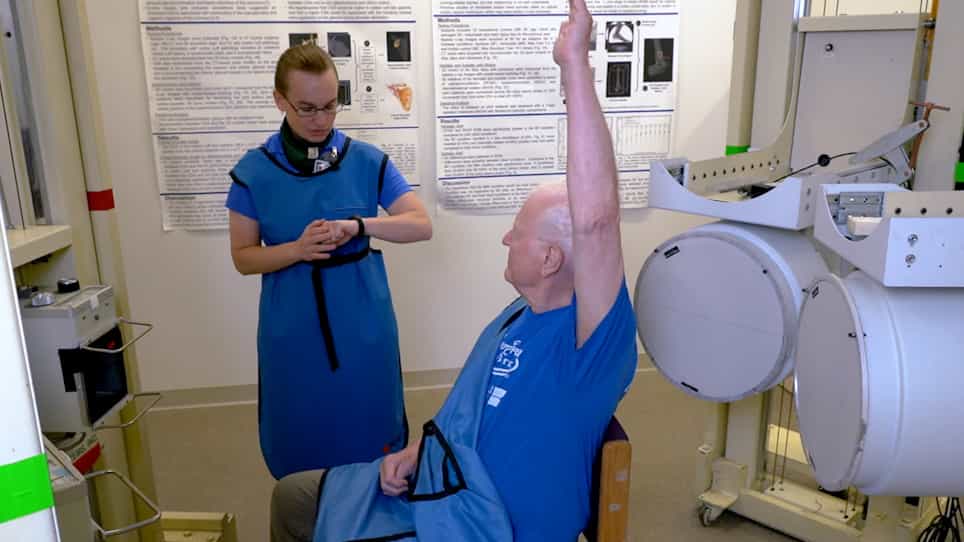
- 三名参与者在Sensopro Luna上进行了十项练习.
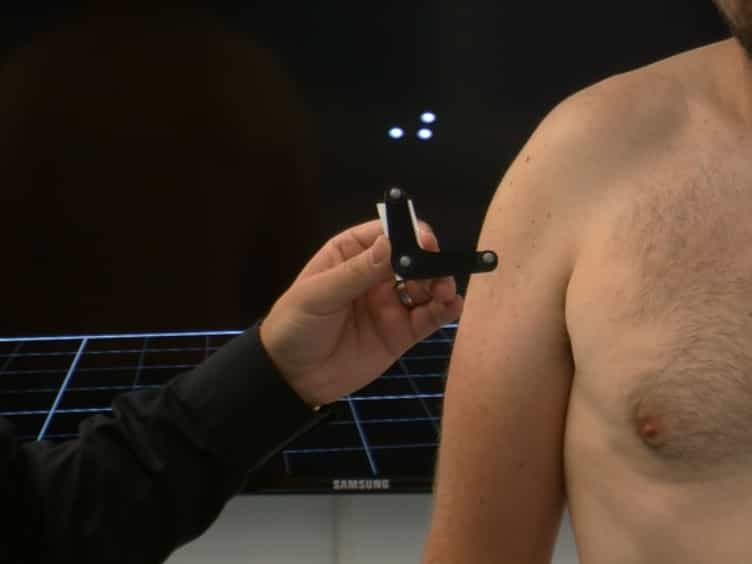
- 模型预测与动作捕捉数据进行了比较,以评估准确性.
主要成果:
- 拟议的模型证明了对现实世界运动数据记录的可行性.
- 对卷曲角度和带段的XYZ位置进行了准确性评估.
- 提出了将模型参数适应特定环境的方法.
结论:
- 开发的方法是一种可行的方法,可以在现实环境中获得动力学数据.
- 这种技术可以作为绩效指标或构成复杂培训反的基础.
- 这些发现支持开发更复杂的人类运动控制反系统.
相关概念视频
 01:25
Relative Motion Analysis using Rotating Axes
439
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
439
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
379
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
379
 01:30
Kinematic Equations for Rotation
300
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
300
 01:10
Relative Motion Analysis - Acceleration
319
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
319
 01:15
Kinematic Equations: Problem Solving
11.8K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
11.8K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
316
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
316