Diff9D:基于扩散的域-一般化的类别-级别9-DoF对象位置估计


概括
本研究引入了分类级九度自由度 (9-DoF) 对象姿势估计的扩散模型,只使用合成数据,可以将其推广到真实世界的场景. 该方法实现了最先进的性能,而不需要3D形状先验.
科学领域:
- 计算机视觉 计算机视觉
- 机器人技术 机器人技术 机器人技术
- 机器学习 机器学习
背景情况:
- 类别级的九度自由度 (9-DoF) 对象姿势和尺寸估计对于增强现实和机器人操纵至关重要.
- 现有的类别级别方法一般化到看不见的对象,但需要广泛的现实世界数据收集和标签.
- 域泛化仍然是一个重大挑战,限制了在特定数据集上训练的模型的适用性.
研究的目的:
- 开发一个基于扩散的范式,用于域泛化类别级别的9-DoF对象构成估计.
- 利用扩散模型的概括能力来克服领域转移问题.
- 为了在现实场景中使用仅在合成数据上训练的模型来实现准确的姿势估计.
主要方法:
- 为 9-DoF 对象姿势估计提出了一个新的扩散模型,将其作为一个生成任务.
- 仅在染合成数据上训练模型,消除了对现实世界标记数据的需求.
- 使用了Denoising Diffusion Implicit Model (DDIM) 进行高效的反向扩散,在短短3个步骤中实现了近乎实时的性能.
- 该模型不需要在训练或推断过程中使用3D形状先验.
主要成果:
- 在两个基准数据集上实现了最先进的域泛化性能.
- 在现实世界机器人抓取系统中成功应用.
- 通过三步反向扩散过程实现了近乎实时的性能.
结论:
- 拟议的基于扩散的方法有效地解决了类别级9-DoF对象立场估计中的域概括挑战.
- 仅仅在合成数据上的训练能够对现实世界的场景进行强有力的概括.
- 该方法为机器人操纵和增强现实等应用提供了实用解决方案.
更多相关视频
 06:32
Author Spotlight: Automated Deep Brain Stimulation for Parkinson's Disease - Exploring the Possibilities and Challenges of Home Monitoring
Published on: July 14, 2023
1.2K
 06:36
Author Spotlight: Insights into the Analysis of Human Interaction with 3D Virtual Objects
Published on: October 18, 2024
854
相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
199
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
199
 01:24
One-Degree-of-Freedom System
444
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
444
 01:09
Functional Classification of Joints
3.7K
Functional Classification of Joints
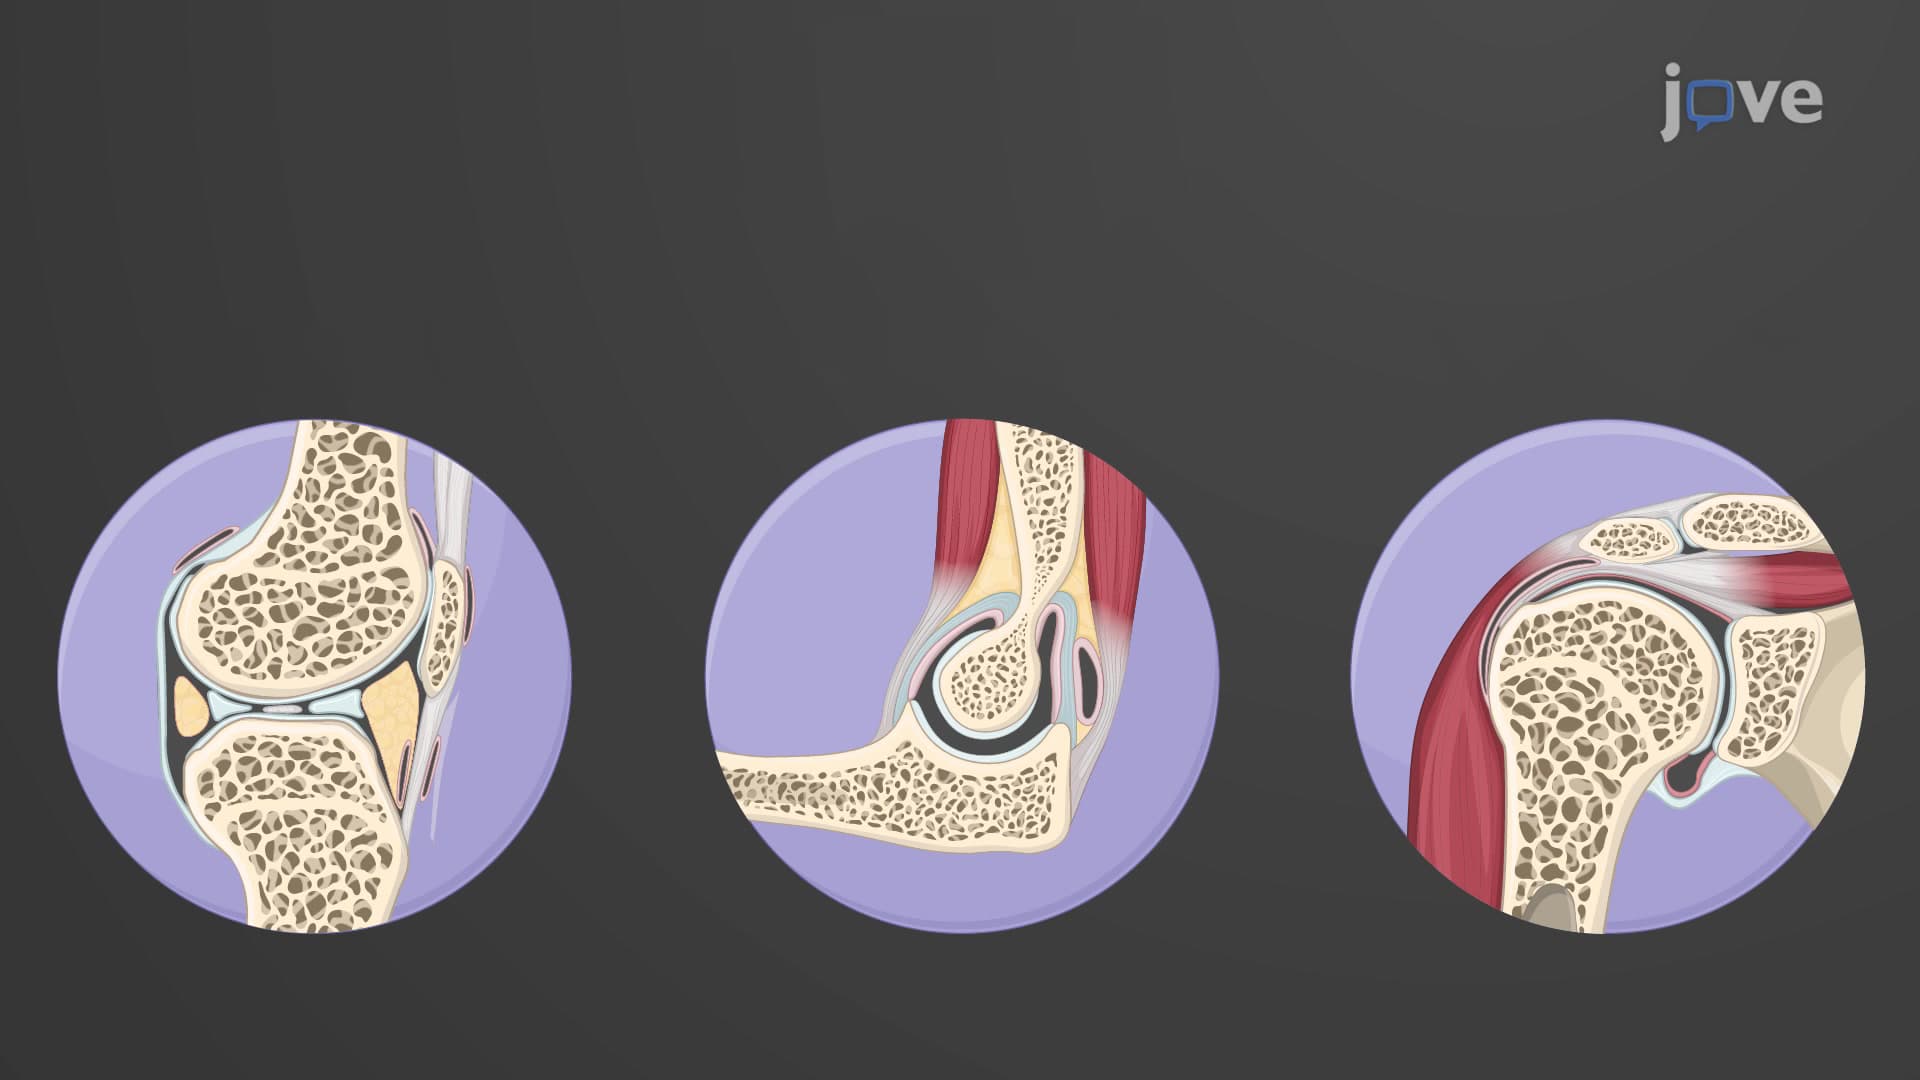
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An...
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An...
3.7K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
379
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
379
 01:22
Planar Rigid-Body Motion
368
Understanding the movement of a rigid body in planar motion involves recognizing that every particle within this body is traversing a path that maintains a consistent distance from a specific plane. This concept is fundamental in the study of physics and mechanical engineering, and it allows us to comprehend better how objects move in space.
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
368
 01:25
Relative Motion Analysis using Rotating Axes
439
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
439