
地测对齐的梯度投影用于持续的任务学习

概括
深度网络在连续学习过程中忘记了之前的任务. 一种新的地测对齐梯度投影 (GAGP) 方法通过考虑非欧几里德式变 manifold 上的任务变化来减轻这种灾难性的遗忘.
科学领域:
- 人工智能的人工智能
- 机器学习 机器学习
- 深度学习 (Deep Learning) 是一种深度学习.
背景情况:
- 深度神经网络在连续训练时表现出灾难性的遗忘.
- 现有的梯度投影方法假设静态的任务空间,限制了持续学习.
- 这导致了低于最佳的梯度投影,并影响了先前任务的性能.
研究的目的:
- 在顺序深度学习中解决灾难性遗忘.
- 开发一种方法,以考虑逐渐的任务变化.
- 通过利用任务空间的几何性质来提高持续学习能力.
主要方法:
- 将任务子空间嵌入非欧几里德式的多元体中,以捕捉任务演变.
- 通过分析推导沿着地测路径的子空间之间的累积投影.
- 提出了一种新的地理测量对齐梯度投影 (GAGP) 方法.
主要成果:
- 常规的 GAGP 方法有效地减轻了灾难性遗忘.
- 它利用任务多样性上的几何结构信息.
- 与图像分类中最先进的方法相比,实现了竞争力或更高的性能.
结论:
- 拟议的GAGP方法为灾难性遗忘提供了一个强有力的解决方案.
- 非欧几里德的多元体为建模不断变化的任务空间提供了一个合适的框架.
- 这种方法提高了在深度网络中持续学习的能力.
更多相关视频
相关概念视频
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
379
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
379
 01:16
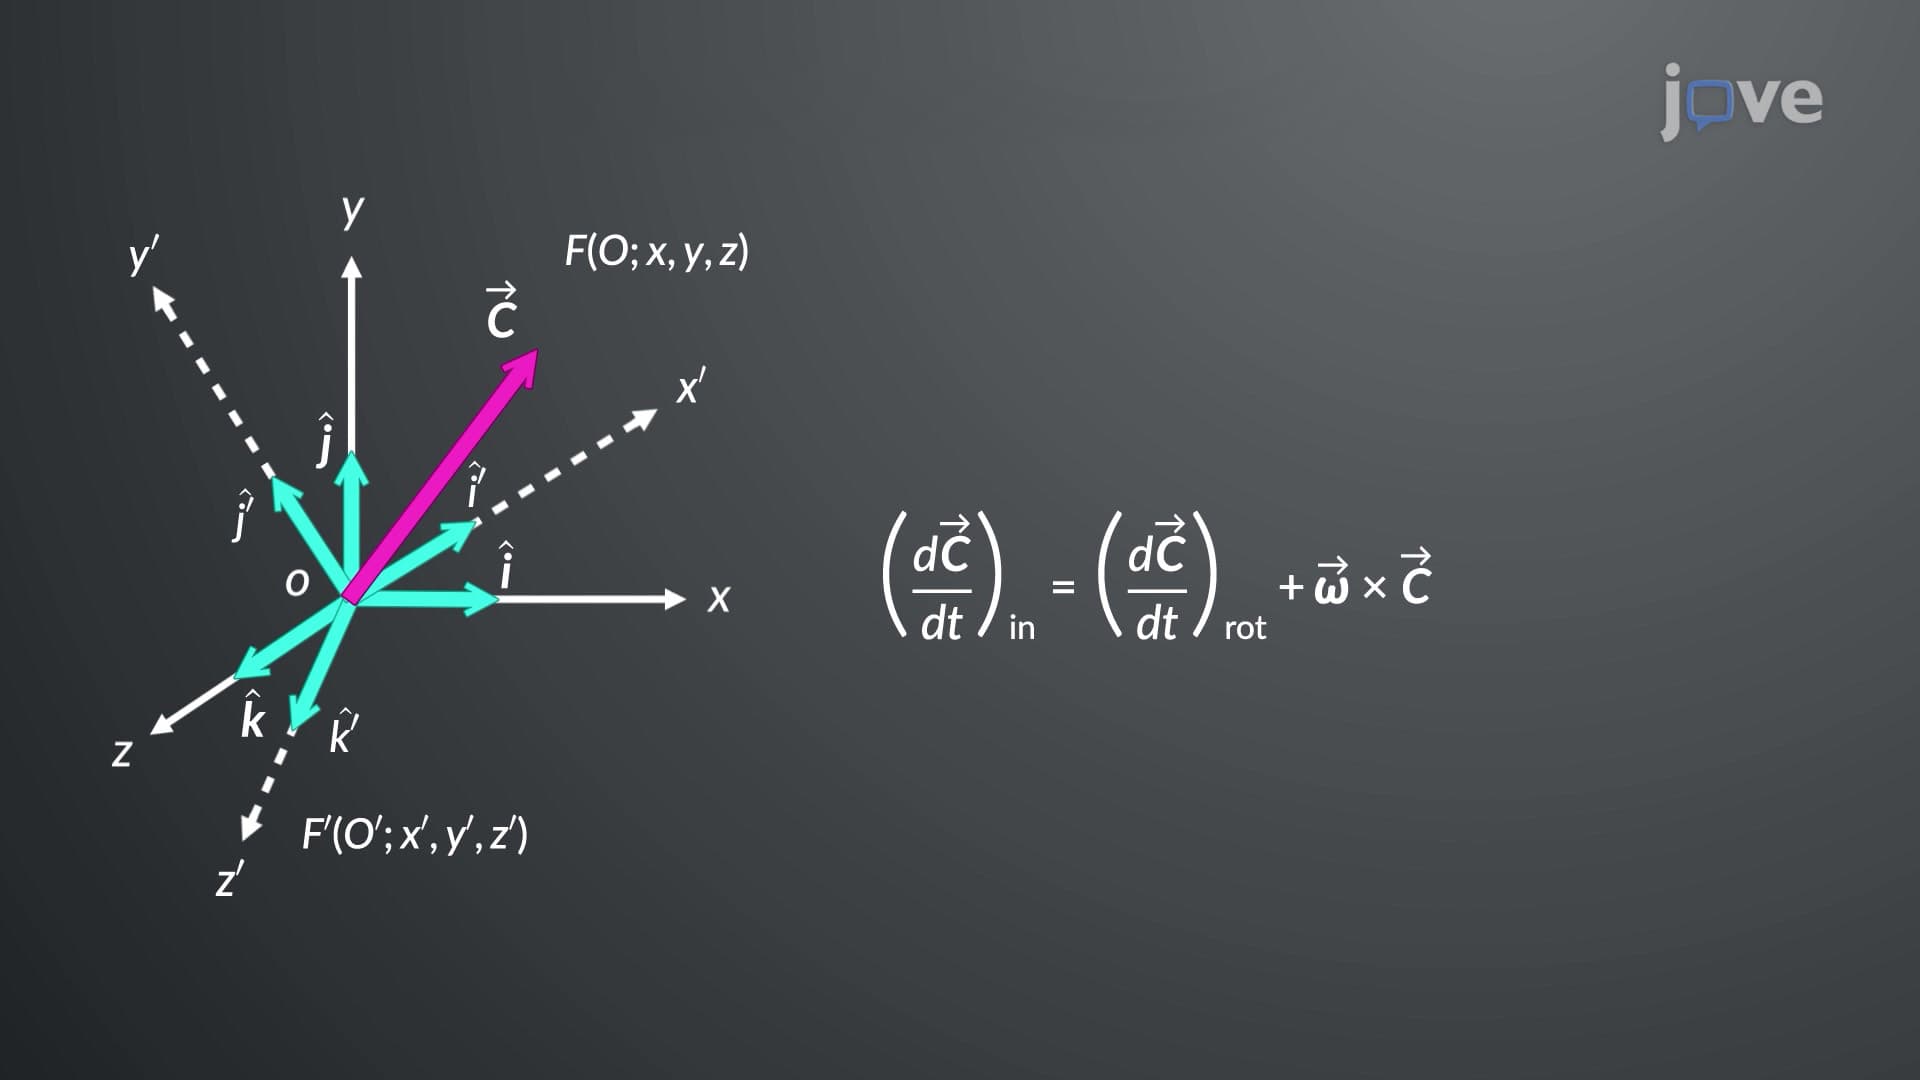
Vector Transformation in Rotating Coordinate Systems
1.4K
Consider a vector rotating about an axis with an angular velocity, such that its tip sweeps a circular path.
1.4K
 01:27
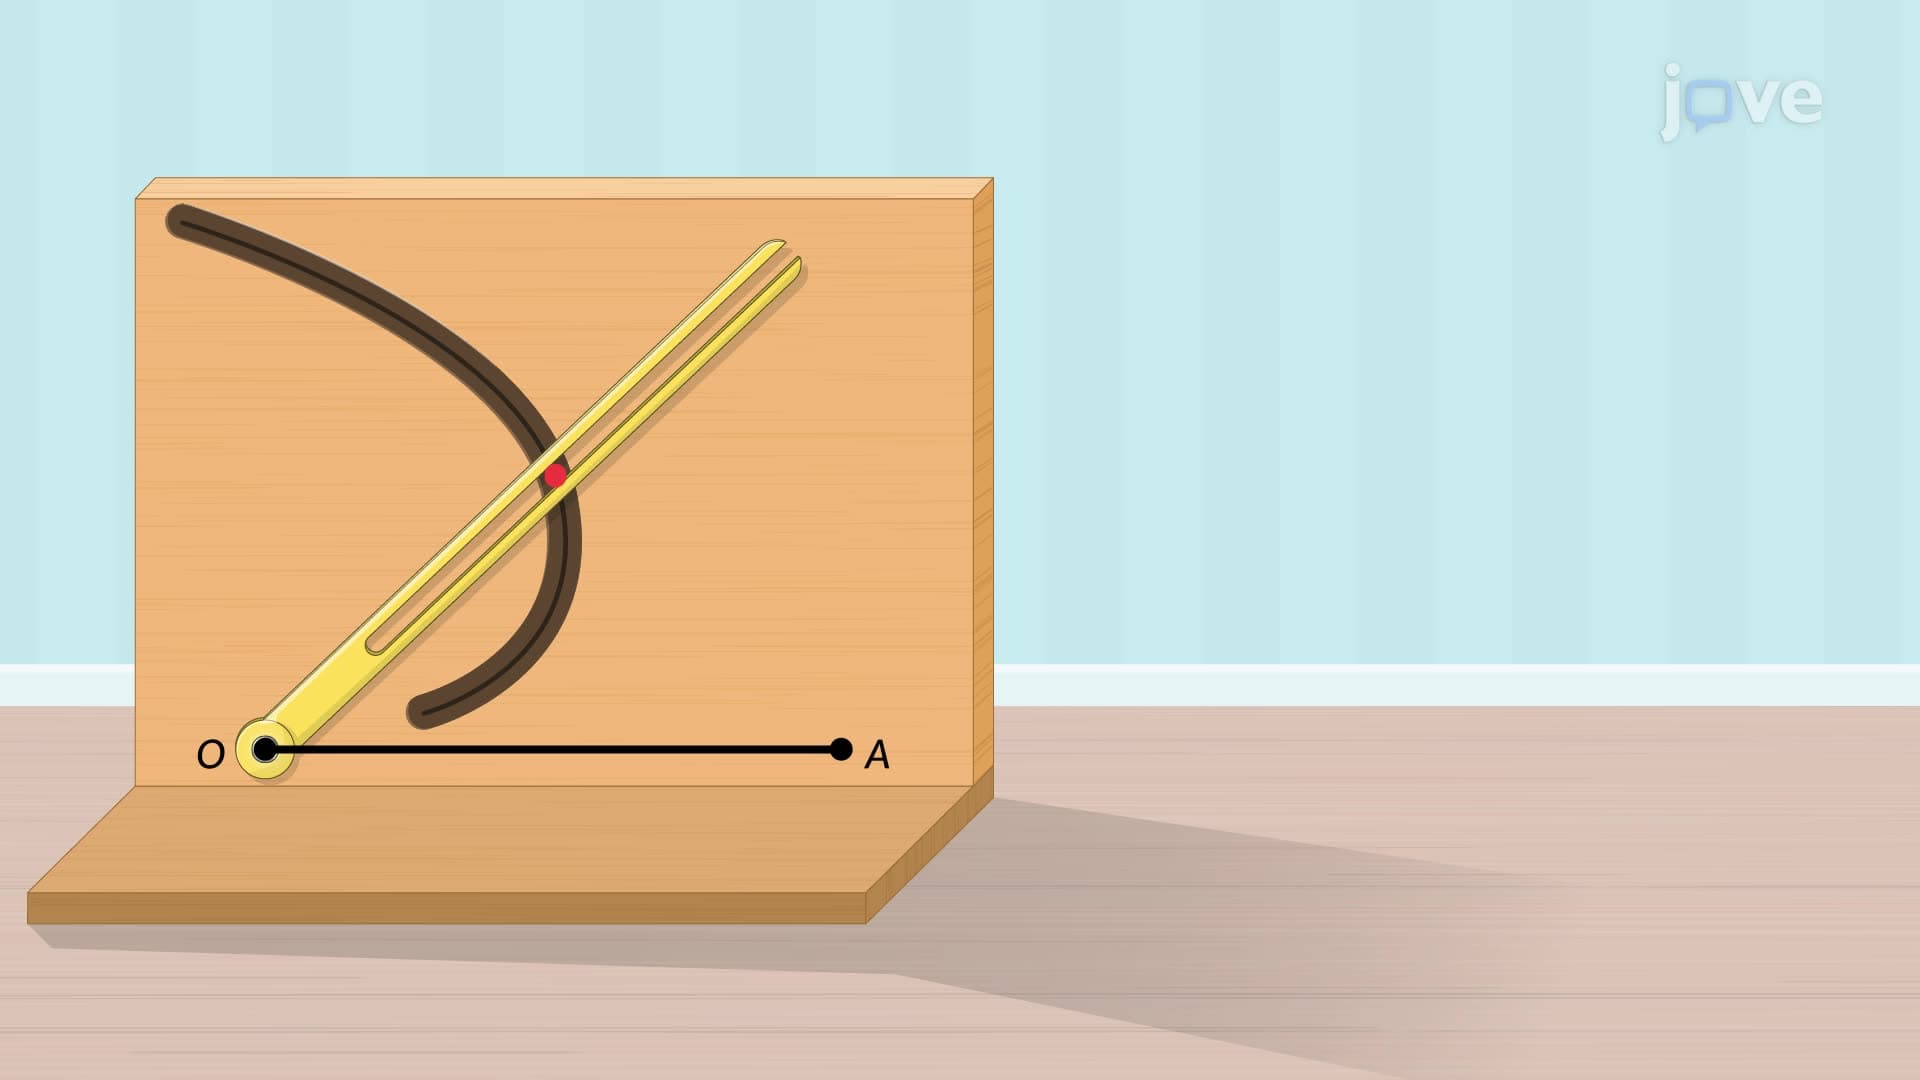
Curvilinear Motion: Polar Coordinates
337
In polar coordinates, the motion of a particle follows a curvilinear path. The radial coordinate symbolized as 'r,' extends outward from a fixed origin to the particle, while the angular coordinate, 'θ,' measured in radians, represents the counterclockwise angle between a fixed reference line and the radial line connecting the origin to the particle.
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
337
 01:28
Forced Transdifferentiation
1.9K
Transdifferentiation, also known as lineage reprogramming, was first discovered by Selman and Kafatos in 1974 in silkmoths. They observed that the moths’ cuticle-producing cells transformed into salt-producing cells. Many such cases of natural transdifferentiation occur in organisms. In humans, pancreatic alpha cells can become beta cells. In newts, the loss of the eye’s lens causes the pigmented epithelial cells to transdifferentiate into the lens cells.
Artificial...
Artificial...
1.9K
 01:23
Curvilinear Motion: Rectangular Components
386
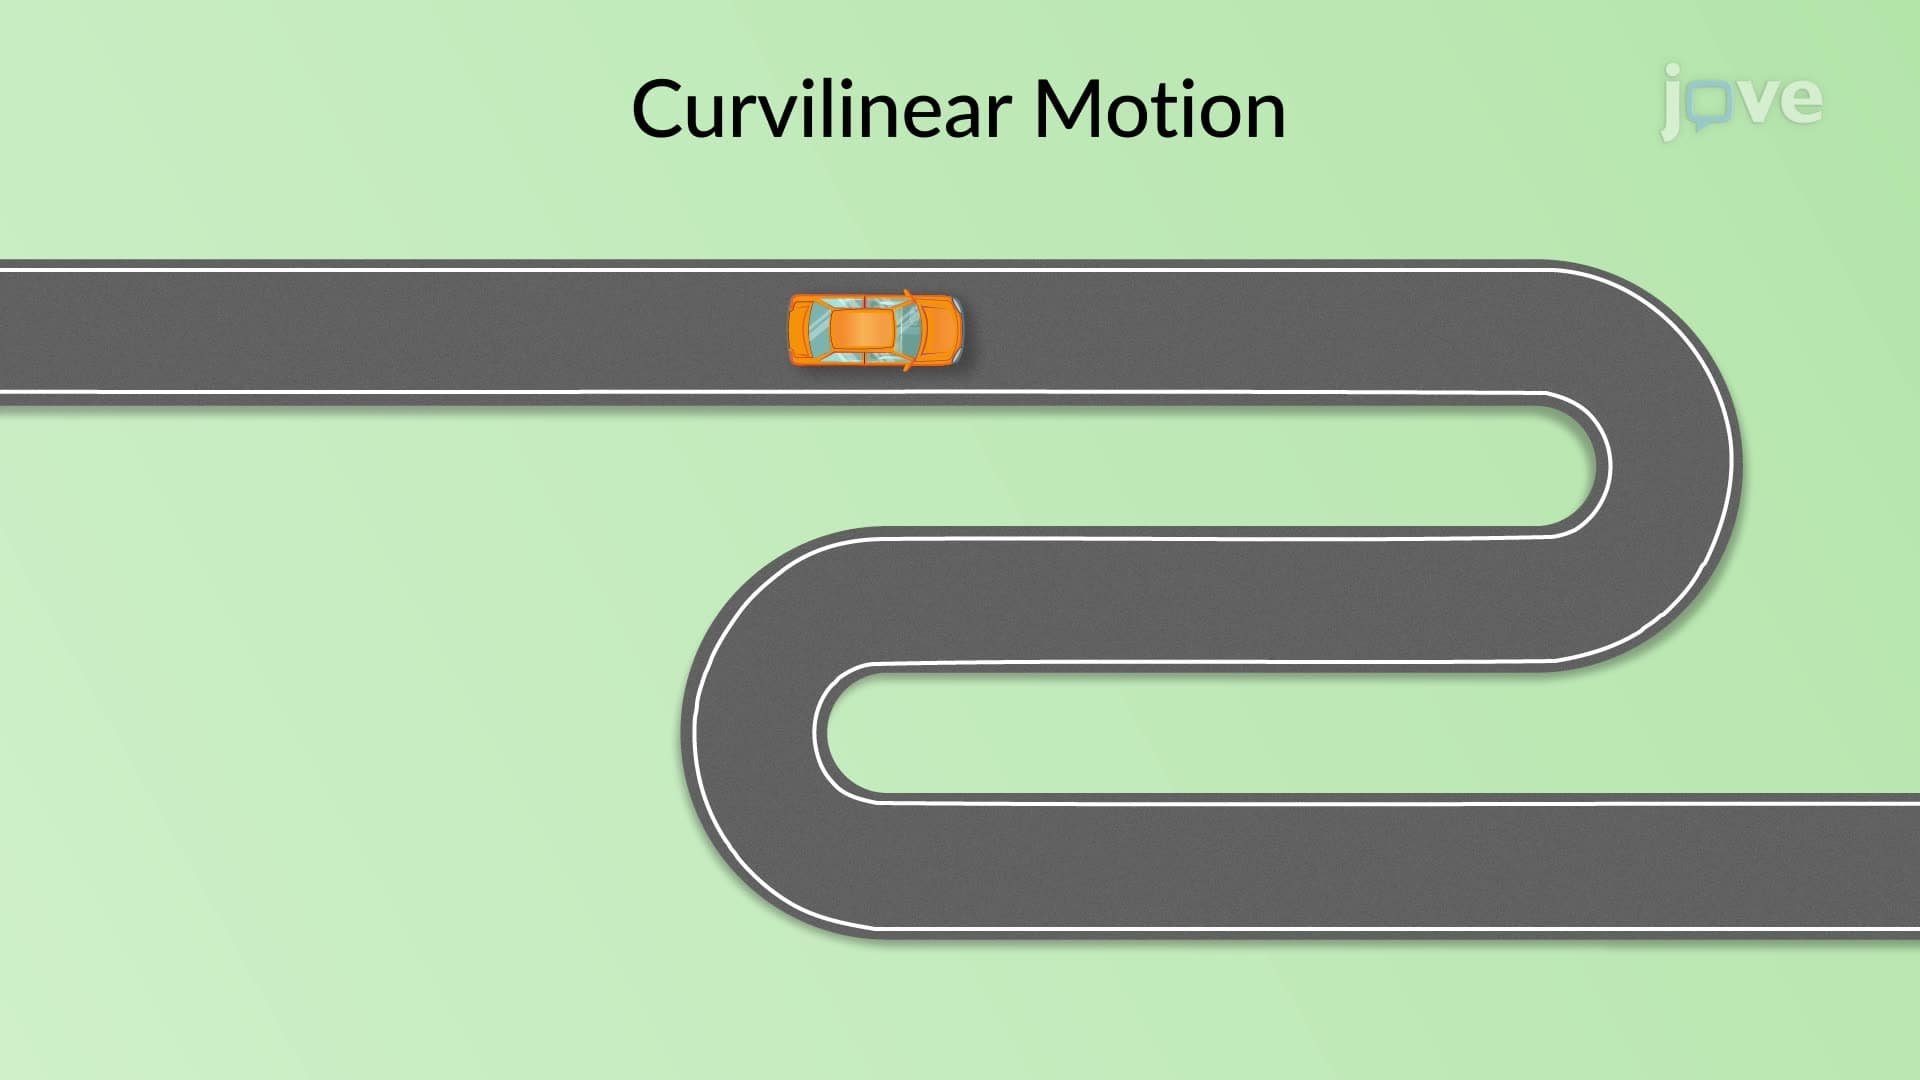
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
386
 01:03
Centroid of a Body: Problem Solving
1.1K
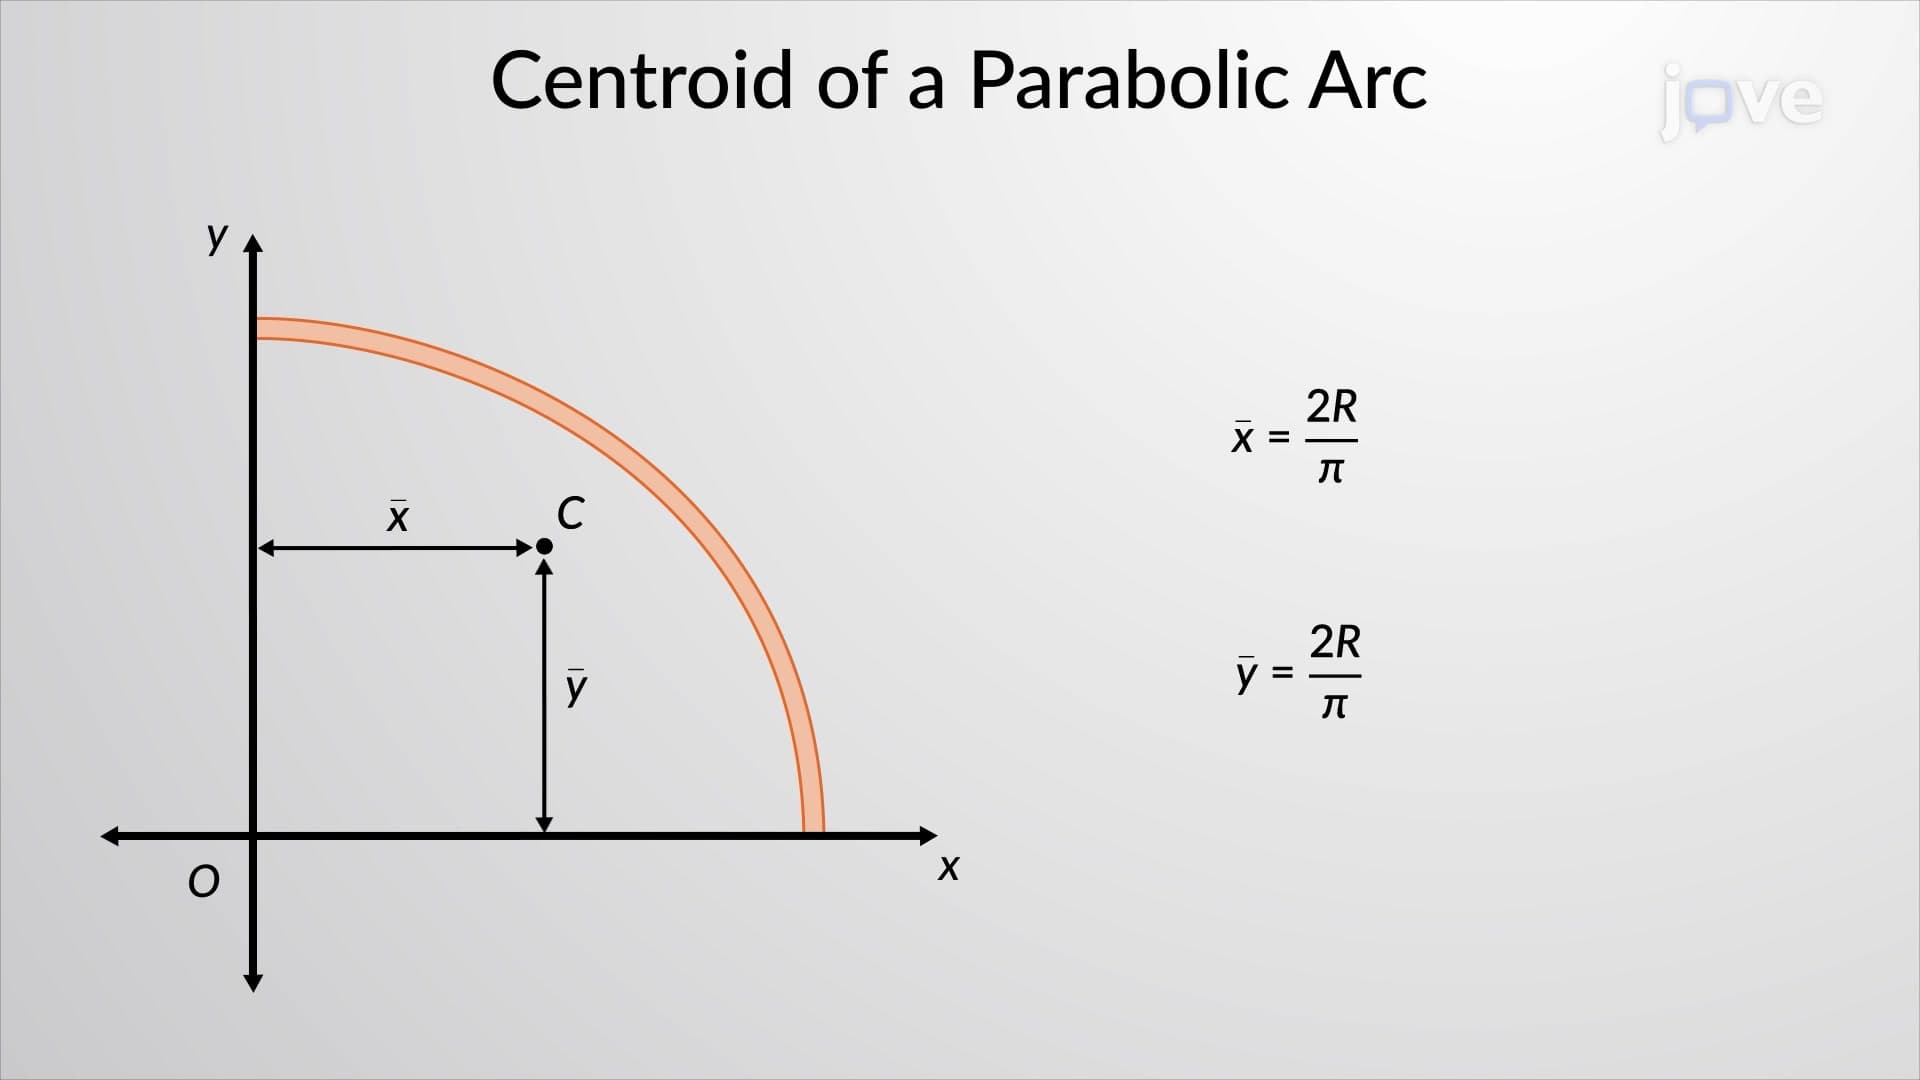
The centroid of a body is a crucial concept in engineering and physics. Finding the centroid of a body can help determine its stability, its balance point, and even its design. In this context, consider a thin wire bent in the form of a quarter circular arc. Polar coordinates are used to calculate the centroid. The wire is first divided into small differential elements of a length equal to the radius multiplied by the differential angle.
The x-coordinates and y-coordinates of each element's...
The x-coordinates and y-coordinates of each element's...
1.1K