

单脚机器人从一枝到另一枝跳跃和着陆,灵感来自松鼠平衡控制系统
Justin K Yim1, Eric K Wang2, Sebastian D Lee3
1Department of Mechanical Science and Engineering, University of Illinois Urbana-Champaign, Urbana, IL, USA.
Science robotics
|March 19, 2025

概括
腿长度控制可以改善机器人和松鼠在狭窄的树枝上降落的平衡. 这一策略增强了控制权,扩大了成功着陆的条件,并增加了对初始角动量的容忍度.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 生物力学 生物力学
- 动物的运动 动物的运动
背景情况:
- 树木运动包括在小支上动态着陆.
- 由于高势头和有限的控制权,平衡这些着陆很困难.
研究的目的:
- 为了调查腿长度控制是否可以在动态着陆过程中提高平衡.
- 扩大树木机动成功着陆条件的范围.
主要方法:
- 使用单脚机器人Salto-1P进行分支到分支的跳跃实验.
- 将机器人的着陆策略与松鼠的着陆策略进行比较,分析辐射力控制.
主要成果:
- 萨尔托-1P展示了纵向平衡着陆,尽管抓取扭矩有限.
- 更大的辐射力控制显著降低了所需的反应扭矩.
- 平衡控制策略使初始角动量的范围增加了230% (机器人) 和470% (松鼠).
结论:
- 腿长度控制是改善树木环境中的动态着陆稳定的可行策略.
- 辐射力控制对于在狭窄的支上平衡高角度动量至关重要.
- 这种方法对机器人运动和理解动物生物力学都有影响.

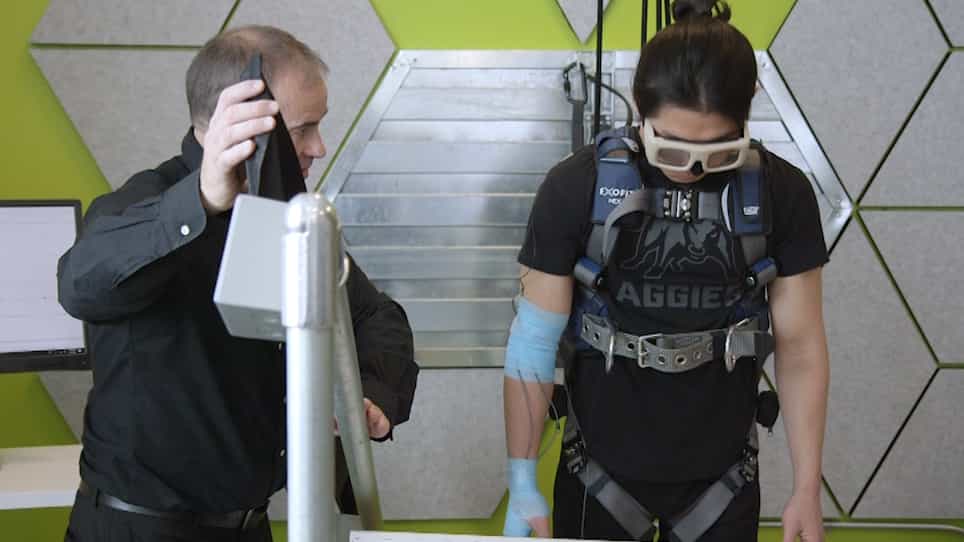
相关概念视频
 01:16
Hydraulic Jump: Problem Solving
35
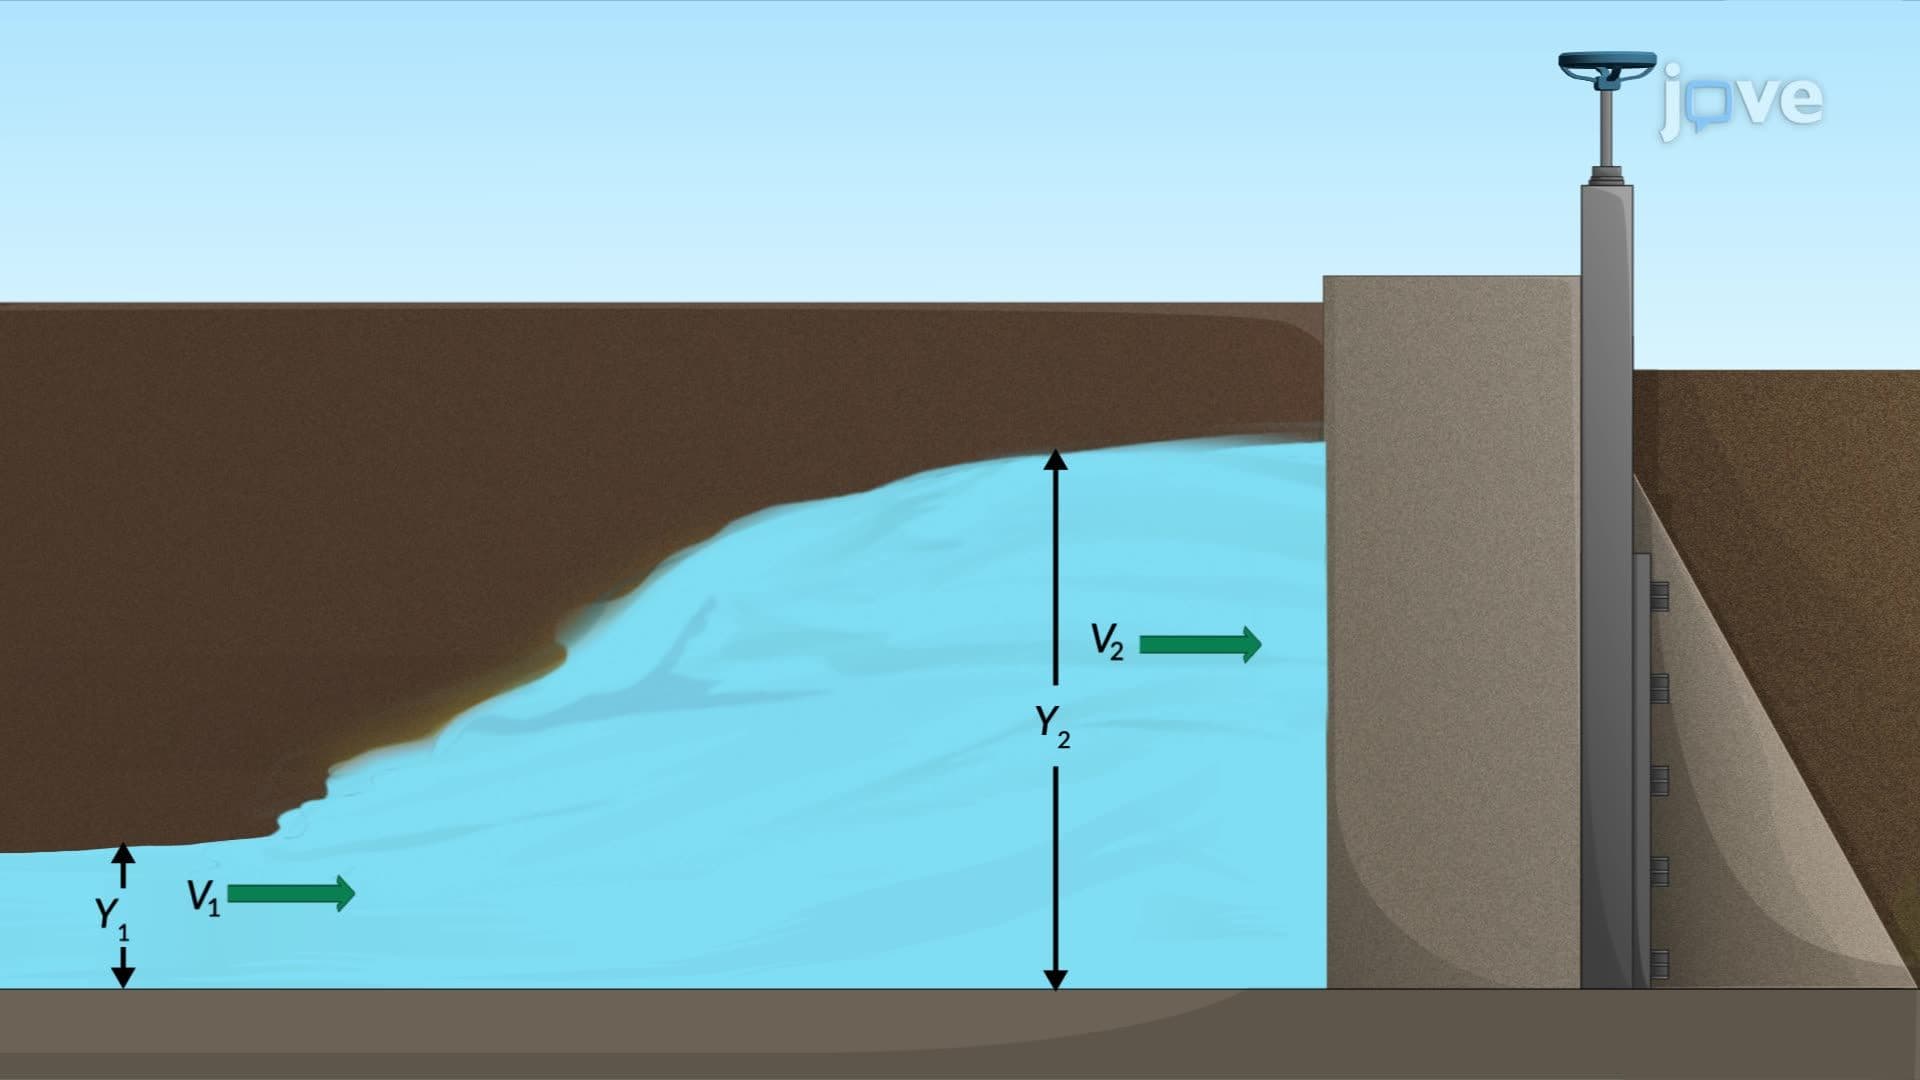
To analyze a hydraulic jump in a rectangular channel with a flow speed of 6 meters per second, follow these steps:Calculate Effective Upstream Velocity:When the downstream gate closes, a hydraulic jump forms, traveling upstream at 2 meters per second. This wave speed combines with the initial channel flow velocity, creating an effective upstream velocity.Identify Flow Velocities Before and After the Hydraulic Jump:Upstream of the hydraulic jump, the effective flow velocity includes both the...
35
 01:24
Muscle Coordination and Action
1.3K
Muscle coordination is a complex and finely tuned process essential for smooth and purposeful movements like flexion, extension, adduction, abduction, and rotation. The human body orchestrates the actions of various muscles working in concert, each with a specific role. Four functional types describe how muscles work together: agonist, antagonist, synergist, and fixator.
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
1.3K
 01:24
One-Degree-of-Freedom System
444
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
444
 01:26
PD Controller: Design
159
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
159
 01:29
Hydraulic Jump
34
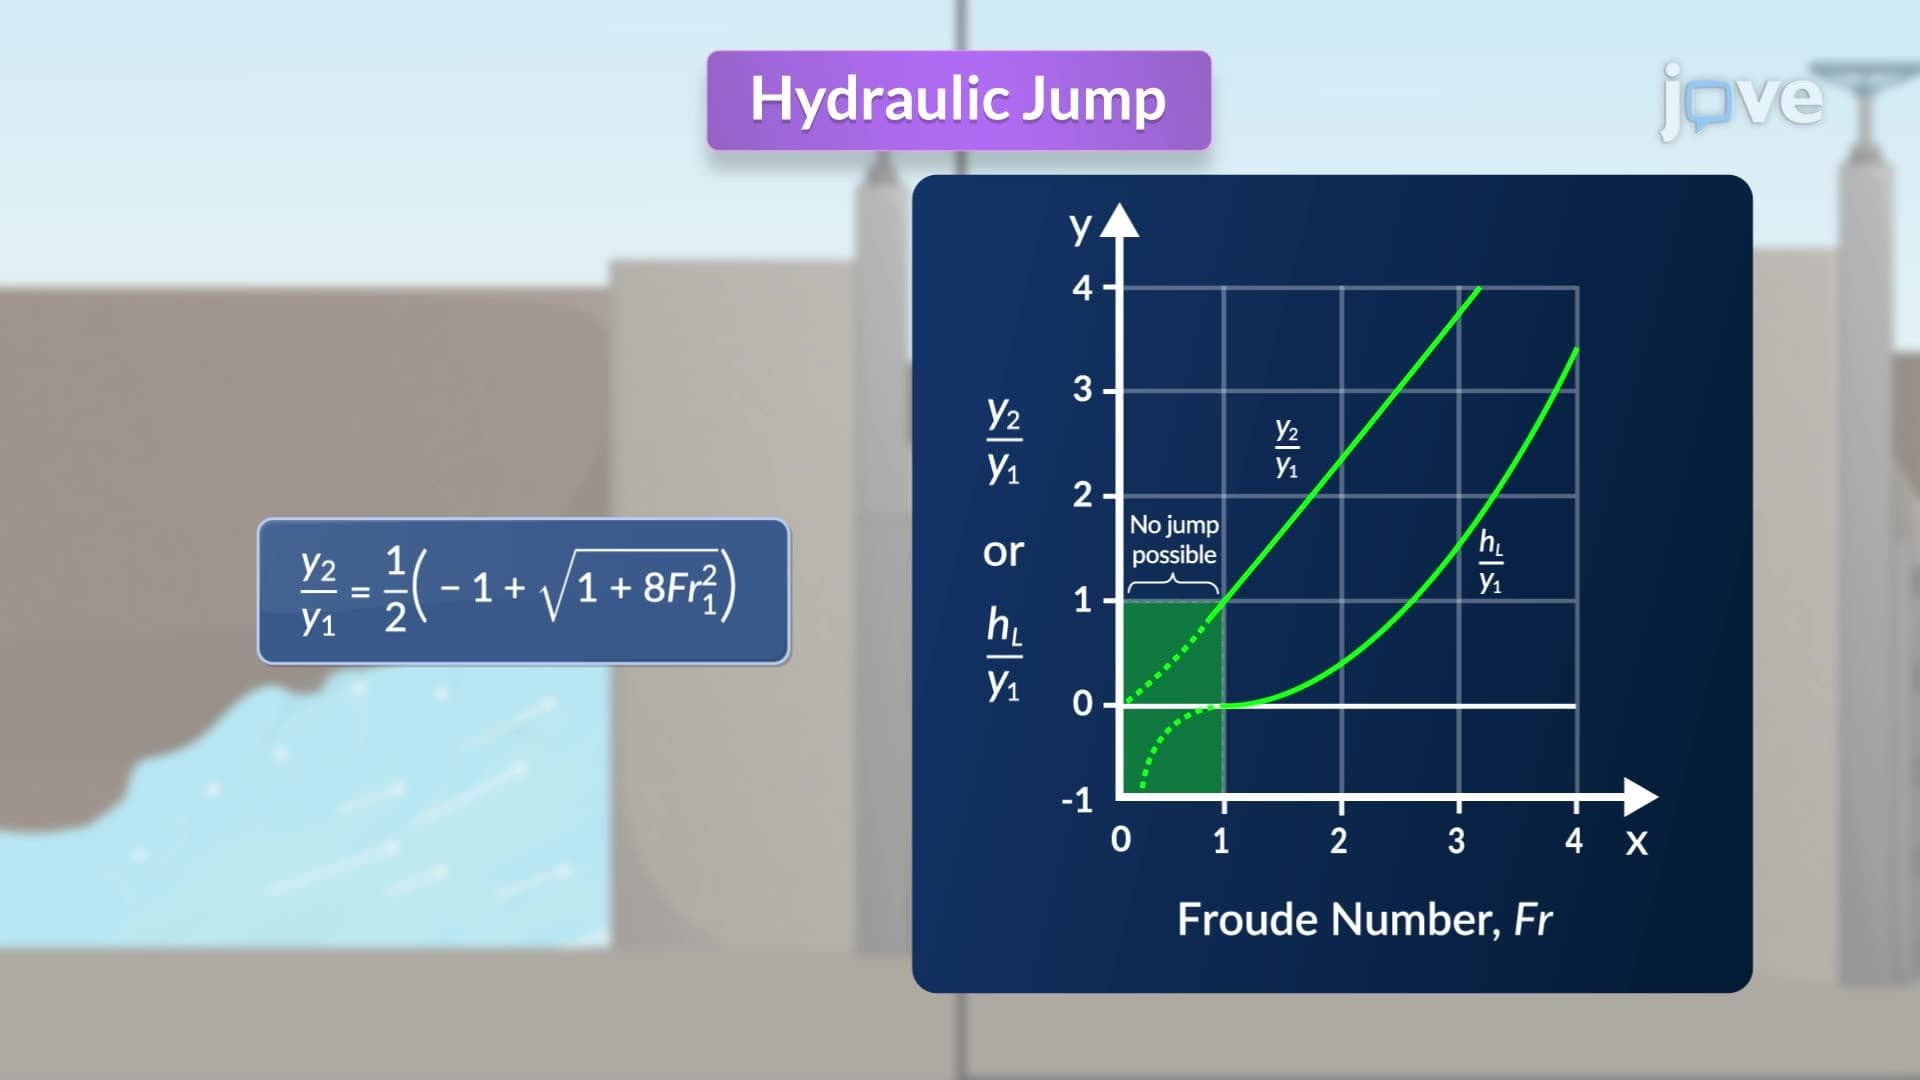
A hydraulic jump is a sudden rise in fluid depth in open channels, occurring when high-velocity (supercritical) flow transitions to low-velocity (subcritical) flow. This phenomenon requires an upstream Froude number greater than 1, as flows with Fr1<1 remain subcritical, making a hydraulic jump impossible due to the need for negative head loss, which violates thermodynamic principles.The characteristics of a hydraulic jump depend on the upstream Froude number and are classified as...
34