
机器人鸟的结构设计和动态建模 基于鸟类飞行特征的机器人鸟态度转换机制
Wenyang Pu1, Qiang Shen1, Yiming Lu1
1School of Mechatronical Engineering, Beijing Institute of Technology, Beijing 100081, China.
Biomimetics (Basel, Switzerland)
|March 26, 2025

概括
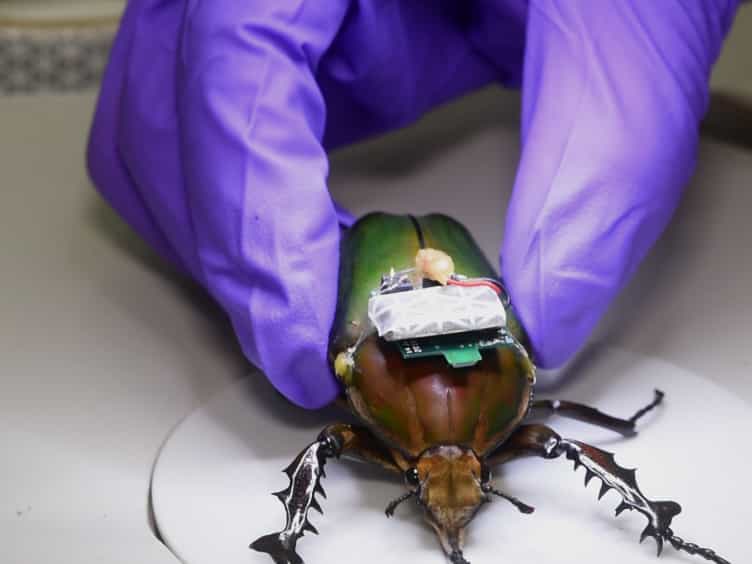
这项研究引入了机器人鸟翅膀的新型多发动机机制,使得鸟类类似的折叠和展开,以提高飞行能力. 这项创新改进了机器人飞机器人的生物模拟和态度控制.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 生物模拟学是一种生物模拟学.
- 航空航天工程 航空航天工程
背景情况:
- 鸟类在飞行控制方面表现出动态的翅膀形态变化.
- 现有的机器人鸟缺乏有效的翅膀折叠机制,限制了生物模拟和机动性.
- 多式联机飞行需要复杂的翅膀关节,而不仅仅是简单的飞.
研究的目的:
- 开发一种机器人机翼机制,能够双向折叠和展开.
- 为了实现鸟类般的翅膀灵活性和对飞机器人的姿态控制.
- 为了使生物灵感的空中机器人能够实现多式飞行能力.
主要方法:
- 设计了一种使用曲棍摇摆结构的多发动机姿态转换机制.
- 开发了一种动力学模型来分析机翼运动期间的链接约束.
- 一个原型被建造并使用运动捕捉系统进行测试.
主要成果:
- 该机制成功地将翅膀在折叠和伸展状态之间进行过渡.
- 在不同飞行阶段,协调的机动操作复制了类似鸟类的翅膀运动.
- 运动捕捉数据验证了动力学模型的准确性.
结论:
- 开发的机制使机器人鸟类具有类似鸟类的翅膀灵活性和姿态控制.
- 这种解决方案解决了现有机器人鸟类生物仿真设计的局限性.
- 这些发现为更先进的生物灵感空中机器人铺平了道路,这些机器人具有多式联机飞行能力.

相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
199
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
199
 01:24
Relative Motion Analysis - Velocity
333
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
333
 01:10
Relative Motion Analysis - Acceleration
319
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
319
 01:30
Kinematic Equations for Rotation
300
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
300
 01:23
Simplification of a Force and Couple System: II
246
In a three-dimensional system, multiple forces can act on an object. These forces can be combined into a single equivalent force, known as the resultant force. Similarly, the moments generated by these forces can be combined into a single equivalent moment, the resultant couple moment. In certain situations, these two entities may not be mutually perpendicular, meaning they do not have a 90-degree angle between them. This unique condition requires a deeper understanding of the interplay between...
246
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
378
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
378