

导向陀螺系统有两个吉姆巴和磁悬挂陀螺,使用自适应型控制规律
Romulus Lungu1,2, Constantin-Adrian Mihai3, Alexandru-Nicolae Tudosie1
1Faculty of Electrical Engineering, University of Craiova, 200585 Craiova, Romania.
Micromachines
|March 27, 2025

概括
这项研究引入了一种用于导弹指导的新型双杆磁悬挂陀螺系统 (DGMSGG). 该DGMSGG使用活磁轴承和自适应控制来准确地将导弹定向其目标.
科学领域:
- 航空航天工程 航空航天工程
- 控制系统工程 控制系统工程
- 机器人技术 机器人技术 机器人技术
背景情况:
- 导弹指导系统需要精确的方向控制.
- 传统的陀螺系统在准确性和稳定性方面存在局限性.
- 活磁轴承为旋转器悬挂提供了先进的解决方案.
研究的目的:
- 设计和开发用于自导导弹的双磁悬挂陀螺系统 (DGMSGG).
- 实施适应性控制策略,以提高指导准确度.
- 通过数值模拟来验证系统的性能.
主要方法:
- 一个双杆结构的设计与一个旋转器在活性磁轴承 (AMBs).
- 使用动态反转,PD/PID补偿器,状态观察器,参考模型和神经网络的自适应控制系统的开发.
- 在Simulink/Matlab中进行数学建模和数值模拟.
主要成果:
- 该DGMSGG成功地将旋转器的视线与目标的导线平行.
- 适应性控制系统有效地管理陀螺旋转子和杆动力学.
- 模拟证实了稳定的稳定和定向制度.
结论:
- 拟议的DGMSGG具有自适应控制,为导弹指导提供了强大的解决方案.
- 该系统可为拦截提供精确的并行接近指导.
- 经过验证的模型作为未来指导系统开发的基础.
关键词:
总监局GMSGG总监局是什么意思控制 控制 控制 控制吉姆巴尔 gimbal 吉姆巴尔 gimbal 吉姆巴尔 gimbal 吉姆巴尔 gimbal 吉姆巴尔 gimbal 吉姆巴尔 gimbal 吉姆巴尔 gimbal 吉姆巴尔 gimbal 吉姆巴尔 gimbal这是指导的指导,指导的指导.陀螺系统 陀螺系统磁性悬挂磁性悬挂是一种磁性悬挂.导弹导弹是指导弹,导弹导弹是指导弹.更多相关视频
 09:13
Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
27.7K
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
1.5K
相关概念视频
 01:02
Gyroscope
2.9K
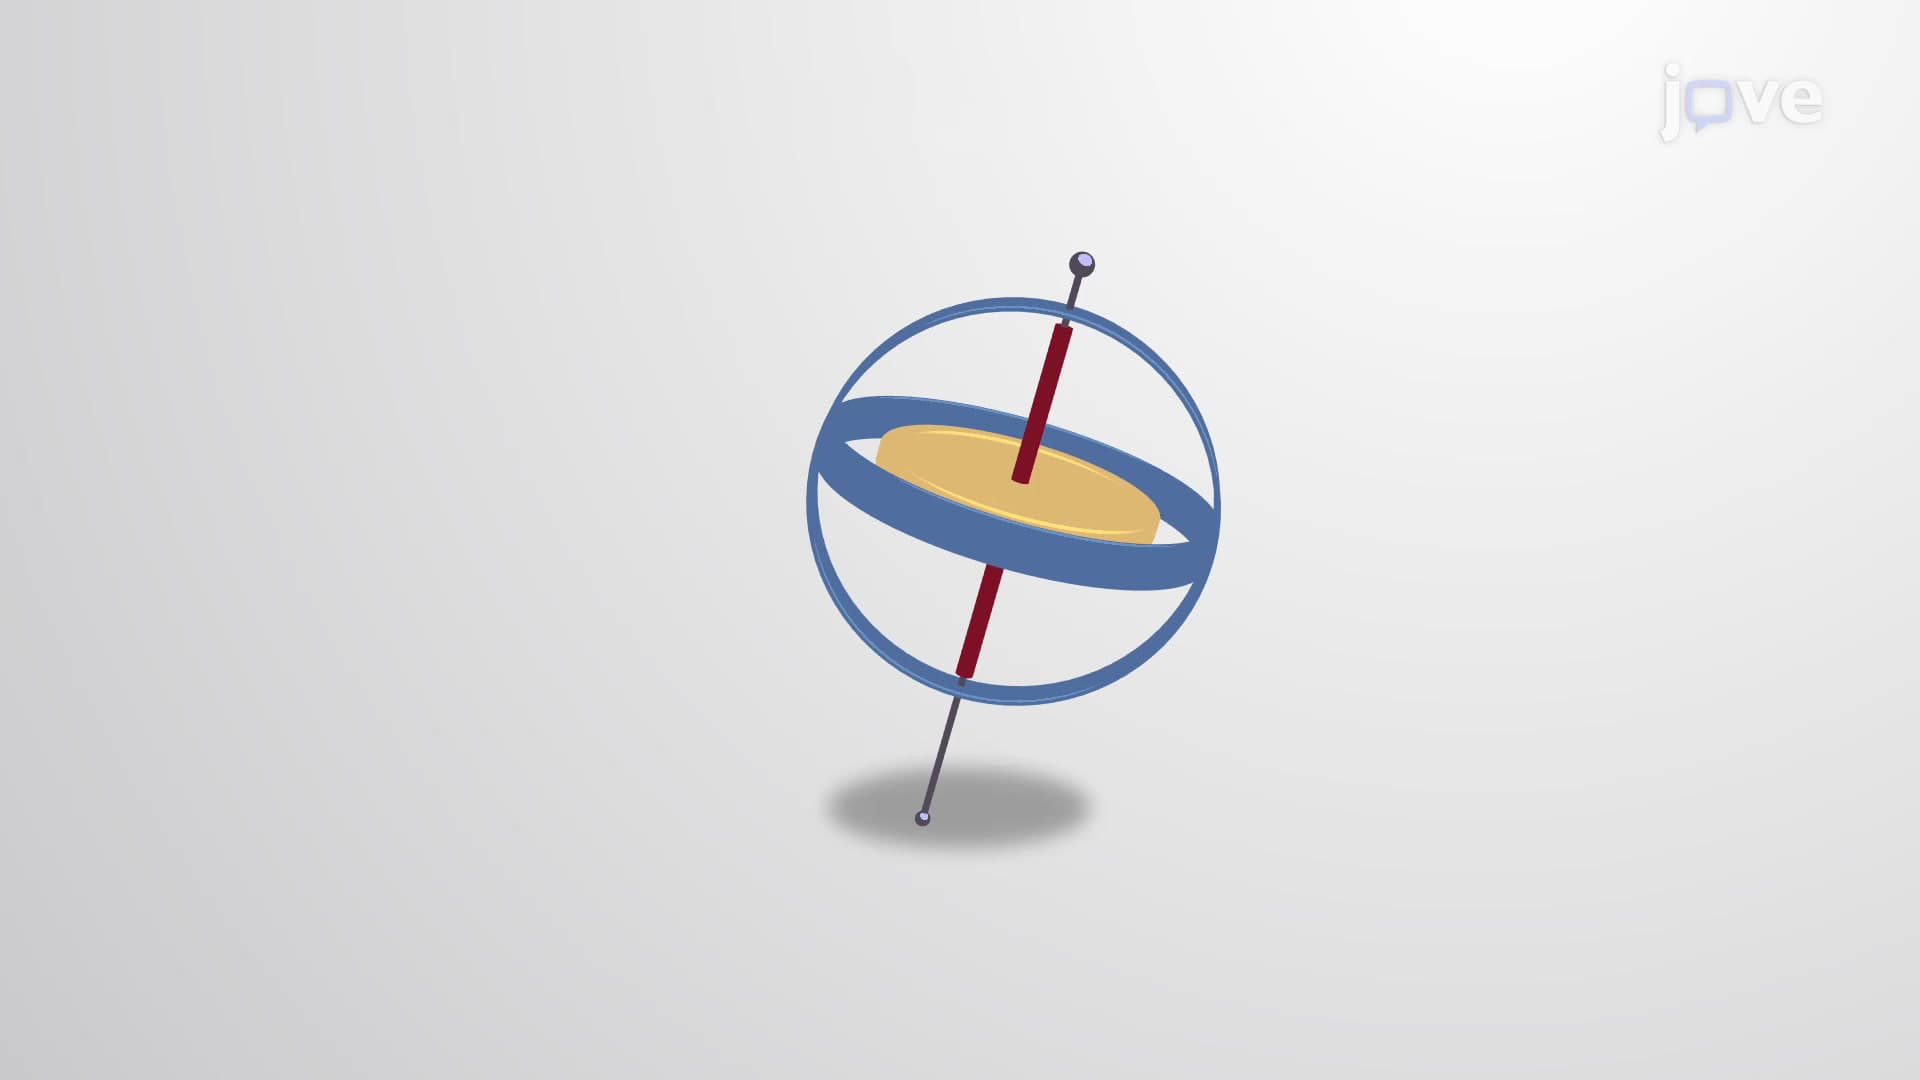
A gyroscope is defined as a spinning disk in which the axis of rotation is free to assume any orientation. When spinning, the orientation of the spin axis is unaffected by the orientation of the body that encloses it. The body or vehicle enclosing the gyroscope can be moved from place to place, while the orientation of the spin axis remains the same. This makes gyroscopes very useful in navigation, especially where magnetic compasses cannot be used, such as in crewed and crewless spacecraft,...
2.9K
 01:24
Gyroscope: Precession
3.9K
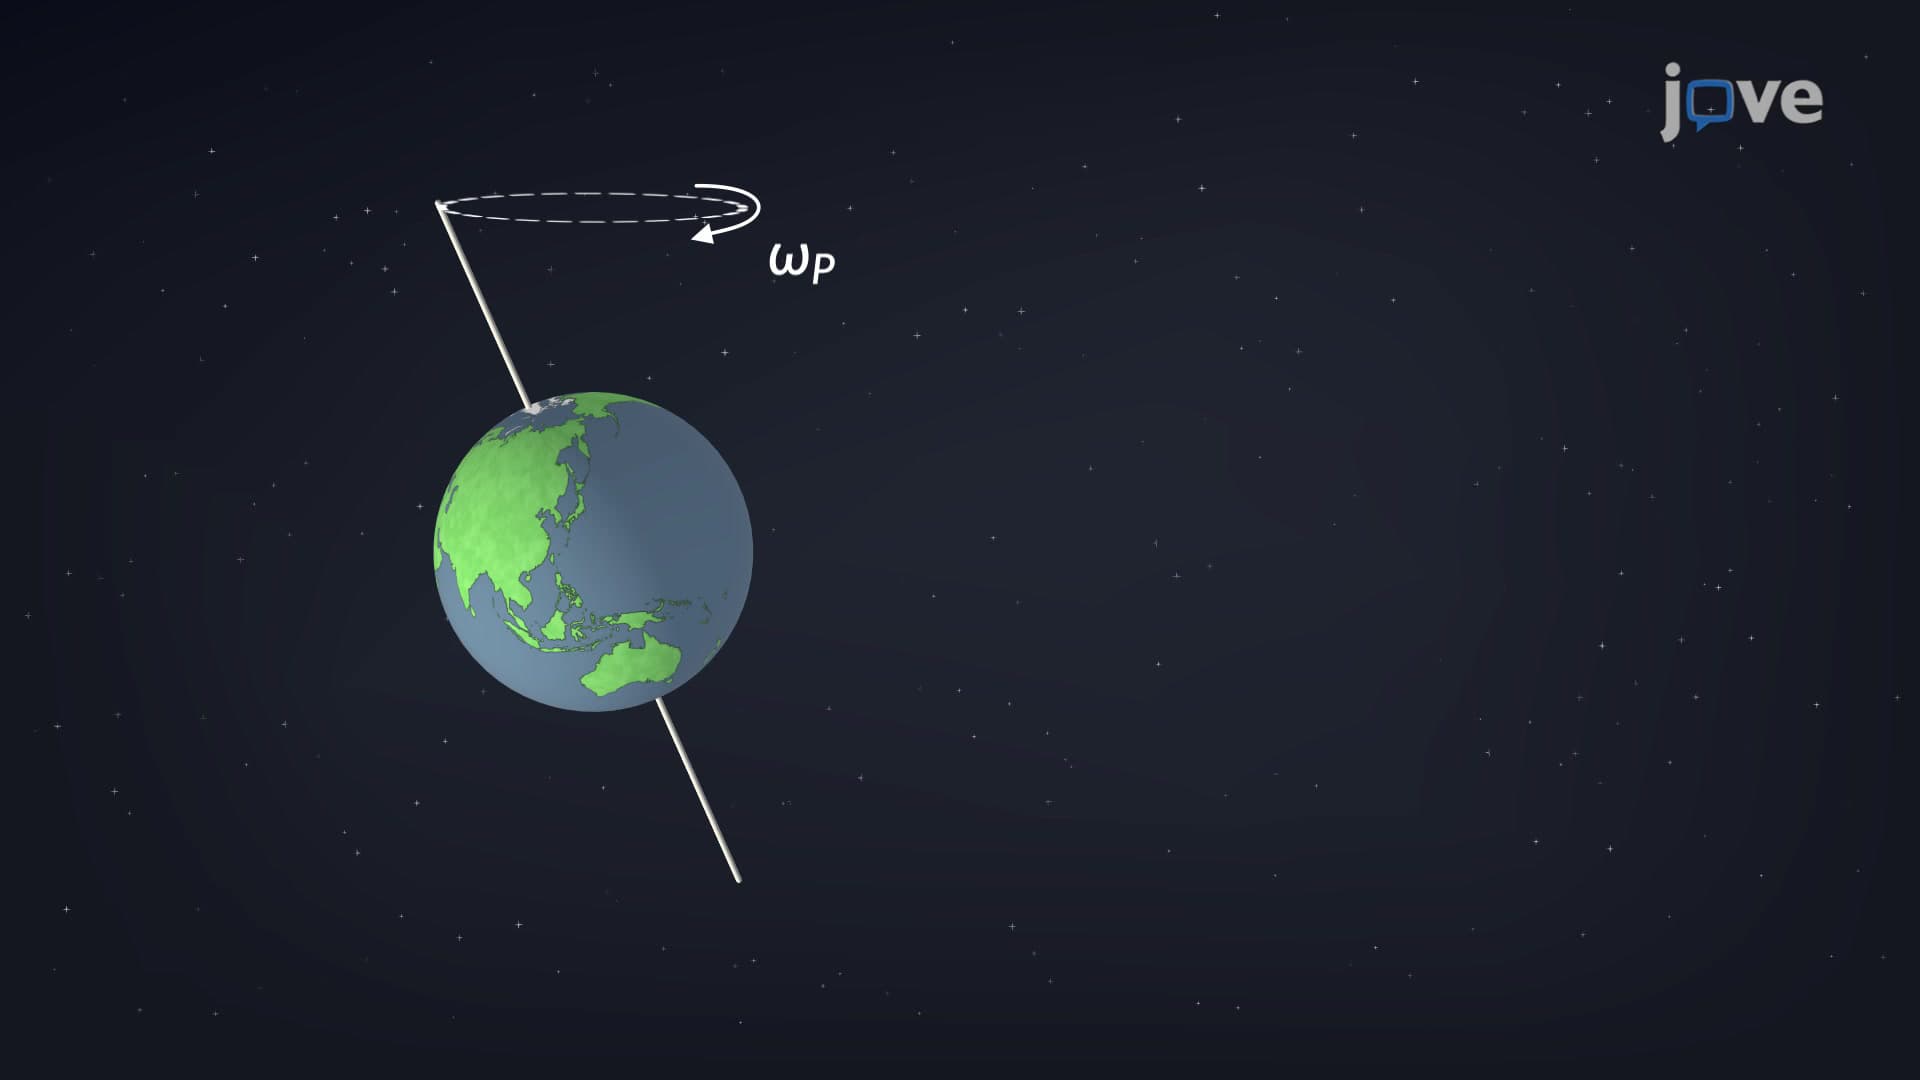
Precession can be demonstrated effectively through a spinning top. If a spinning top is placed on a flat surface near the surface of the Earth at a vertical angle and is not spinning, it will fall over due to the force of gravity producing a torque acting on its center of mass. However, if the top is spinning on its axis, it precesses about the vertical direction, rather than topple over due to this torque. Precessional motion is a combination of a steady circular motion of the axis and the...
3.9K
 01:17
Open and closed-loop control systems
592
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
592
 01:26
Feedback control systems
261
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
261
 01:22
Controller Configurations
78
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
78
 01:22
Multi-input and Multi-variable systems
93
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
93