在学龄前儿童的时间连续关节动力学变化,超过走路的姿势阶段
Marketa Rygelova1, Jaroslav Uchytil1, Joseph Hamill2
1Department of Human Movement Studies, University of Ostrava, Ostrava, Czech Republic.
Gait & posture
|March 28, 2025

概括
统计参数映射 (SPM) 揭示了学龄前儿童下肢行走动力学的显著差异. 这种方法可以更清楚地了解儿童步行发育中的与年龄相关的变化.
科学领域:
- 儿科步态分析 小儿步态分析
- 发展的生物力学.
- 汽车发展 汽车发展
背景情况:
- 在不同年龄的儿童中比较步态动力学需要先进的分析工具.
- 统计参数映射 (SPM) 是分析步态波形差异的合适方法.
- 专注于曲线最大/最小的传统方法对与年龄相关的步态变化描述性较低.
研究的目的:
- 为了研究通常发育的学龄前儿童在步行过程中下肢运动波形的差异.
- 确定步态在2,3岁和6岁之间是否以及如何演变.
主要方法:
- 采用了横截面研究设计.
- 使用统计参数映射 (SPM) 来比较步态动力学.
- 从42名典型发育的2,3岁和6岁的学前儿童中收集了动力学数据.
主要成果:
- 在年龄组之间观察到足部内部旋转和膝盖旋转/绑架波形的显著差异.
- 与3岁和6岁的孩子相比,两岁的孩子表现出明显的足部内部旋转模式.
- 膝盖动力学,包括内部旋转和绑架,在立场阶段显示了年龄相关的变化.
结论:
- 使用SPM比较步态动力波形,可以更全面地了解发育变化.
- 这种方法提高了不同学前年龄段的步态模式差异的清晰度.
- SPM是描述儿童规范步态发展的一个有价值的工具.
相关概念视频
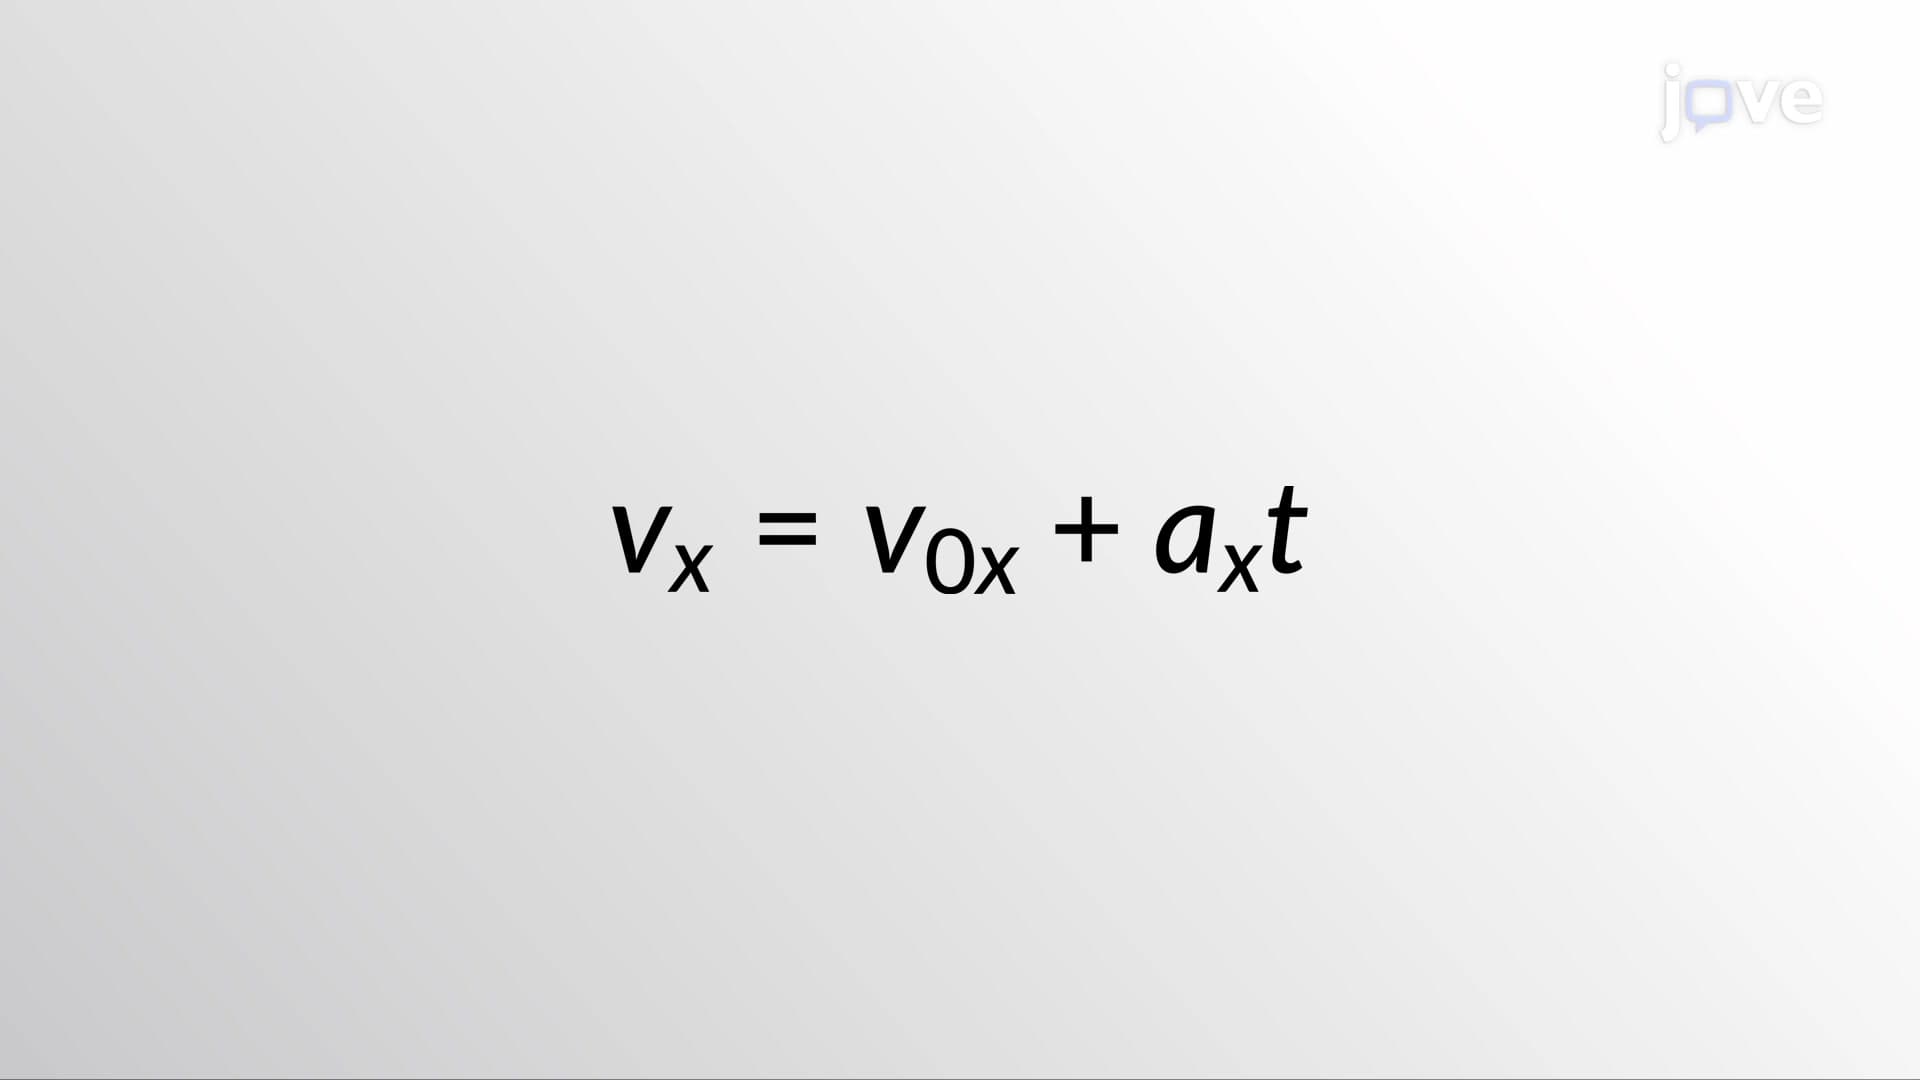 01:26
Kinematic Equations - I
13.2K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
13.2K
 01:17
Kinematic Equations - II
12.1K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
12.1K
 01:18
Kinematic Equations - III
9.9K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
9.9K
 01:15
Kinematic Equations: Problem Solving
24.3K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
24.3K
 01:09
Changes in the Appendicular Skeleton with Age
3.2K
The upper and lower limb initially develops as a small bulge called a limb bud, which appears on the lateral side of the early embryo. The upper limb bud appears near the end of the fourth week of development, with the lower limb bud appearing shortly after.
Initially, the limb buds consist of a core of mesenchyme covered by a layer of ectoderm. The ectoderm at the end of the limb bud thickens to form a narrow crest called the apical ectodermal ridge. This ridge stimulates the underlying...
Initially, the limb buds consist of a core of mesenchyme covered by a layer of ectoderm. The ectoderm at the end of the limb bud thickens to form a narrow crest called the apical ectodermal ridge. This ridge stimulates the underlying...
3.2K
 01:30
Kinematic Equations for Rotation
1.1K
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
1.1K