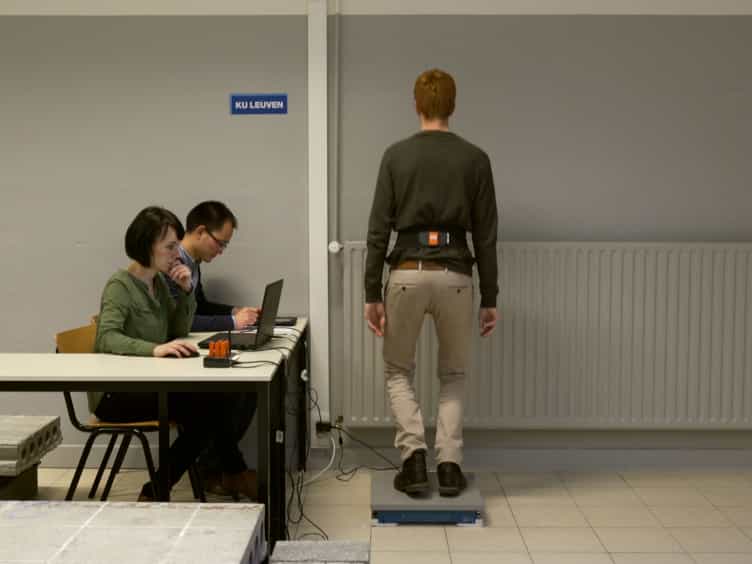
步态动力学:用于分析人类走路和跑步的生成基础模型
Tian Tan1, Tom Van Wouwe2, Keenon F Werling3
1Department of Radiology, Stanford University.
Research square
|April 1, 2025

概括
一个新的深度学习模型,GaitDynamics,准确地从各种数据中预测人类步态动态. 这种基础模型提供低成本,快速分析,用于预防伤害,治疗疾病和绩效指导.
科学领域:
- 生物力学 生物力学
- 机器学习 机器学习
- 人类运动分析分析
背景情况:
- 人类步行分析对健康和表现至关重要,但成本昂贵,传统的实验室实验和模拟限制了它.
- 对于步态分析的现有深度学习模型通常在有限的数据集上进行训练,并且只能预测单个输出.
研究的目的:
- 开发GaitDynamics,这是一个用于人类步态分析的生成基础模型,其训练在一个大而多样化的数据集上.
- 为了证明模型在各种与步态相关的预测任务中的多功能性.
主要方法:
- 训练了一个生成的基础模型,GaitDynamics,在一个大型数据集上,包括各种人口统计和步态模式.
- 验证了模型在任务中的性能,包括估计地面反应力,预测步态修改的影响以及分析运行速度的变化.
主要成果:
- 盖特动力学准确地从动力学中估计地面反应力,即使缺少数据和未代表的群体.
- 该模型预测了步态修改对膝盖负荷和运动/力变化与跑步速度的影响.
- 预测是准确的,快速的 (秒),和强大的,利用灵活的输入.
结论:
- GaitDynamics为人类步态分析提供了一个低成本,多功能和准确的解决方案.
- 该模型在伤害预防,疾病管理和性能优化等领域有很大的应用潜力.
- 所有相关的数据,代码和训练模型都公开可用,以促进研究和应用.
更多相关视频
相关概念视频
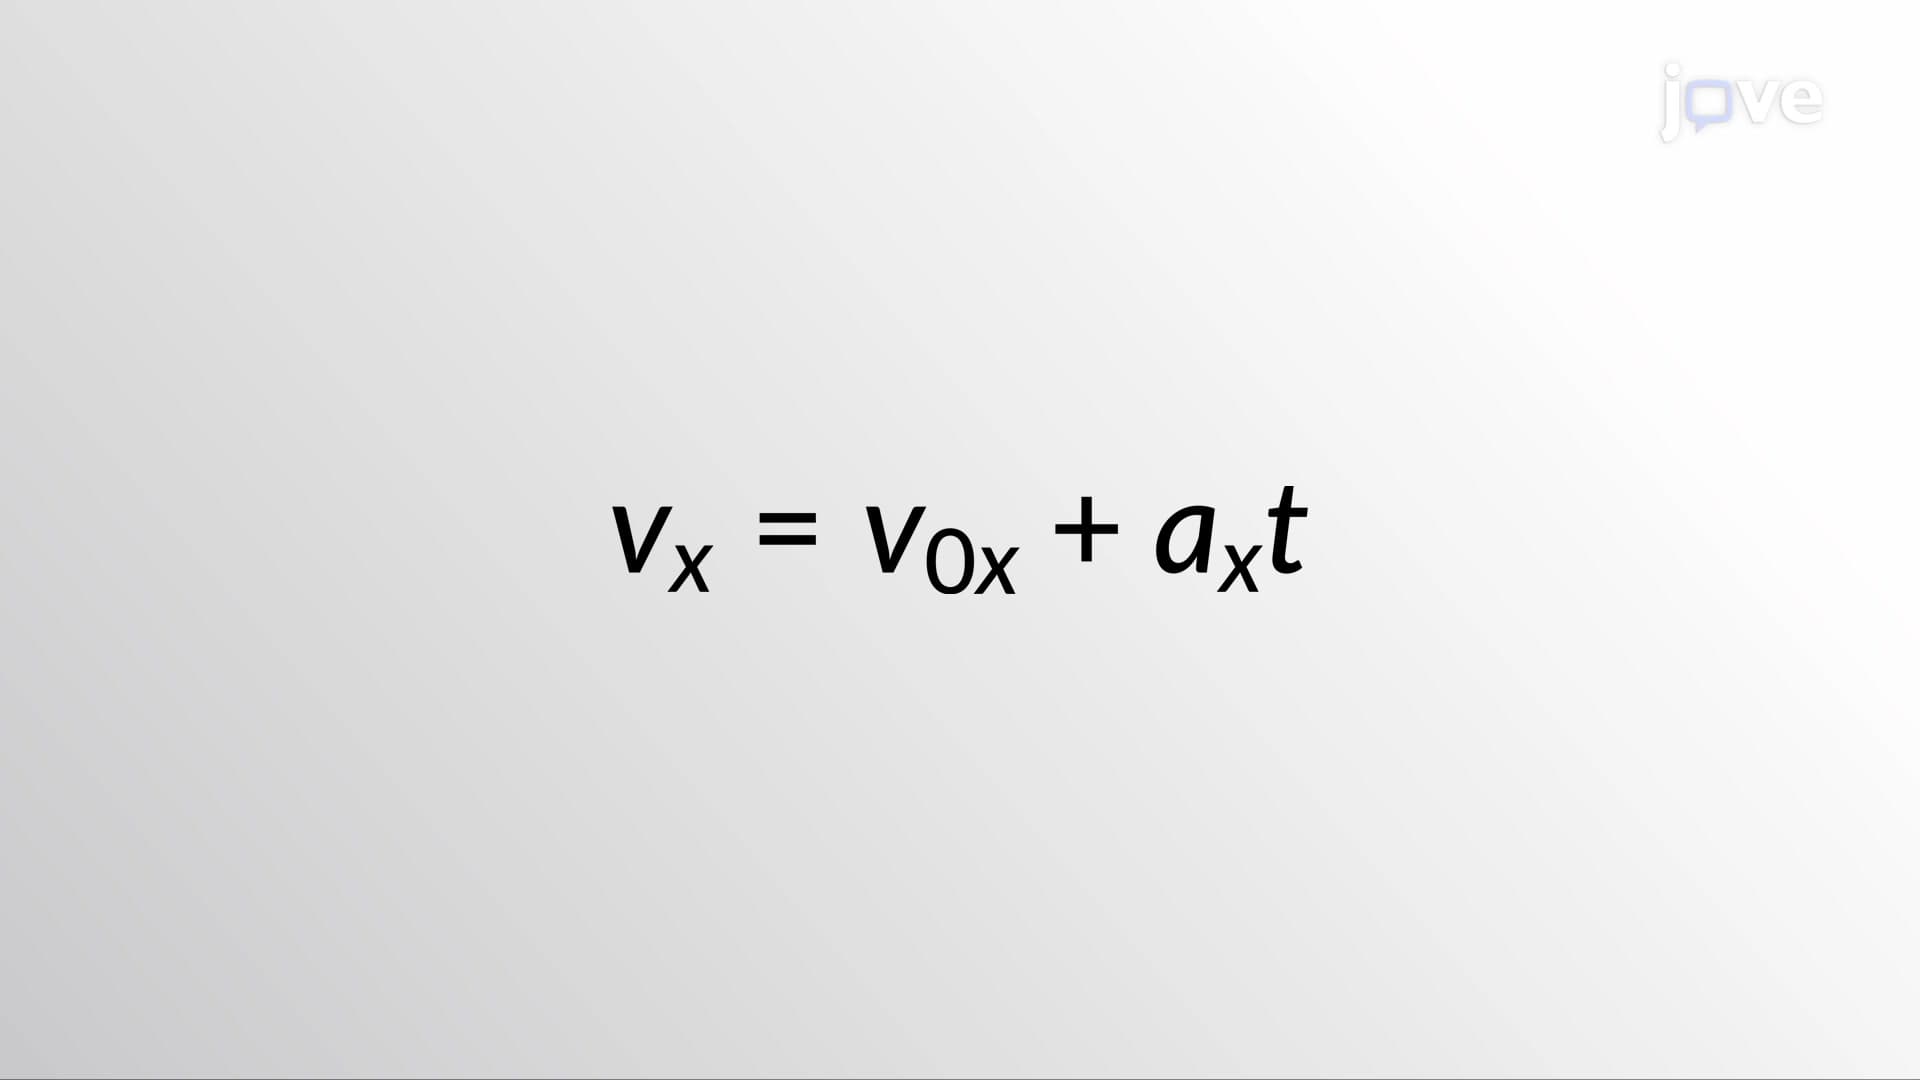 01:26
Kinematic Equations - I
10.2K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
10.2K
 01:18
Hierarchy of Motor Control
2.4K
The hierarchy of motor control refers to the different levels of organization and processing involved in controlling movement in the body. These levels range from higher cortical areas involved in planning and decision-making to lower spinal cord reflexes that respond automatically to external stimuli.
2.4K