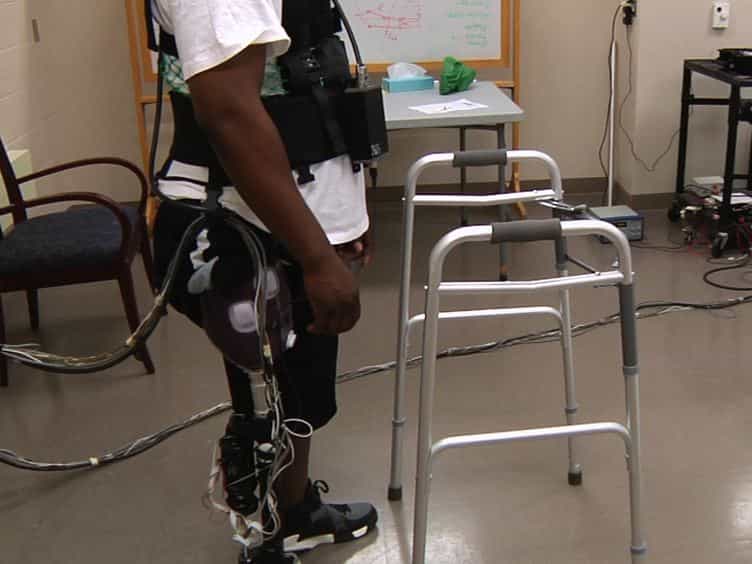
具有中央模式生成器的等级增强学习,使四足机器人模拟器能够在各种地形上行走
Toshiki Watanabe1, Akihiro Kubo2, Kai Tsunoda1
1Kyoto University, Kyoto, Japan.
Scientific reports
|April 2, 2025

概括
我们开发了一种新的深度强化学习方法,用中央模式生成器 (HRL-CPG) 进行层次强化学习,用于机器人控制. 这种方法使机器人能够在各种环境中快速适应并实现稳定的步态.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 人工智能的人工智能
- 控制理论 控制理论
背景情况:
- 为机器人等动态系统优化控制策略是复杂的.
- 中央模式生成器 (CPG) 对于生物运动至关重要,并激发了机器人控制.
- 深度强化学习 (DRL) 提供了一种数据驱动的政策优化方法.
研究的目的:
- 介绍一种新的DLR方法,HRL-CPG,用于优化层次结构化的控制政策.
- 评估HRL-CPG在现实世界机器人控制场景中的适用性.
- 为了证明HRL-CPG在实现稳定的运动中的效率.
主要方法:
- 采用了数据驱动的深度强化学习方法.
- 该方法将一个中央模式生成器集成到一个层次化的强化学习框架 (HRL-CPG) 中.
- 研究人员测试了HRL-CPG方法在机器人控制任务中的有效性.
主要成果:
- 在较少的试验中实现了稳定的步行运动.
- 该HRL-CPG方法证明了高效的学习和适应.
- 在模拟或真实机器人控制中观察到成功的应用.
结论:
- 拟议的HRL-CPG方法是基于DRL的机器人控制的可行候选者.
- HRL-CPG使动态系统能够在实际的时间框架内适应各种环境.
- 这种方法促进了适应性和强大的机器人机动系统的开发.

相关概念视频
 02:16
Stereotype Content Model
13.1K
The Stereotype Content Model (SCM) was first proposed by Susan Fiske and her colleagues (Fiske, Cuddy, Glick & Xu, 2002; see also Fiske, 2012 and Fiske, 2017). The SCM specifies that when someone encounters a new group, they will stereotype them based on two metrics: warmth—or that group’s perceived intent, and how likely they are to provide help or inflict harm—and competence—or their ability to carry out that objective. Depending on the warmth-competence...
13.1K
 01:14
Mechanical Efficiency of Real Machines
1.6K
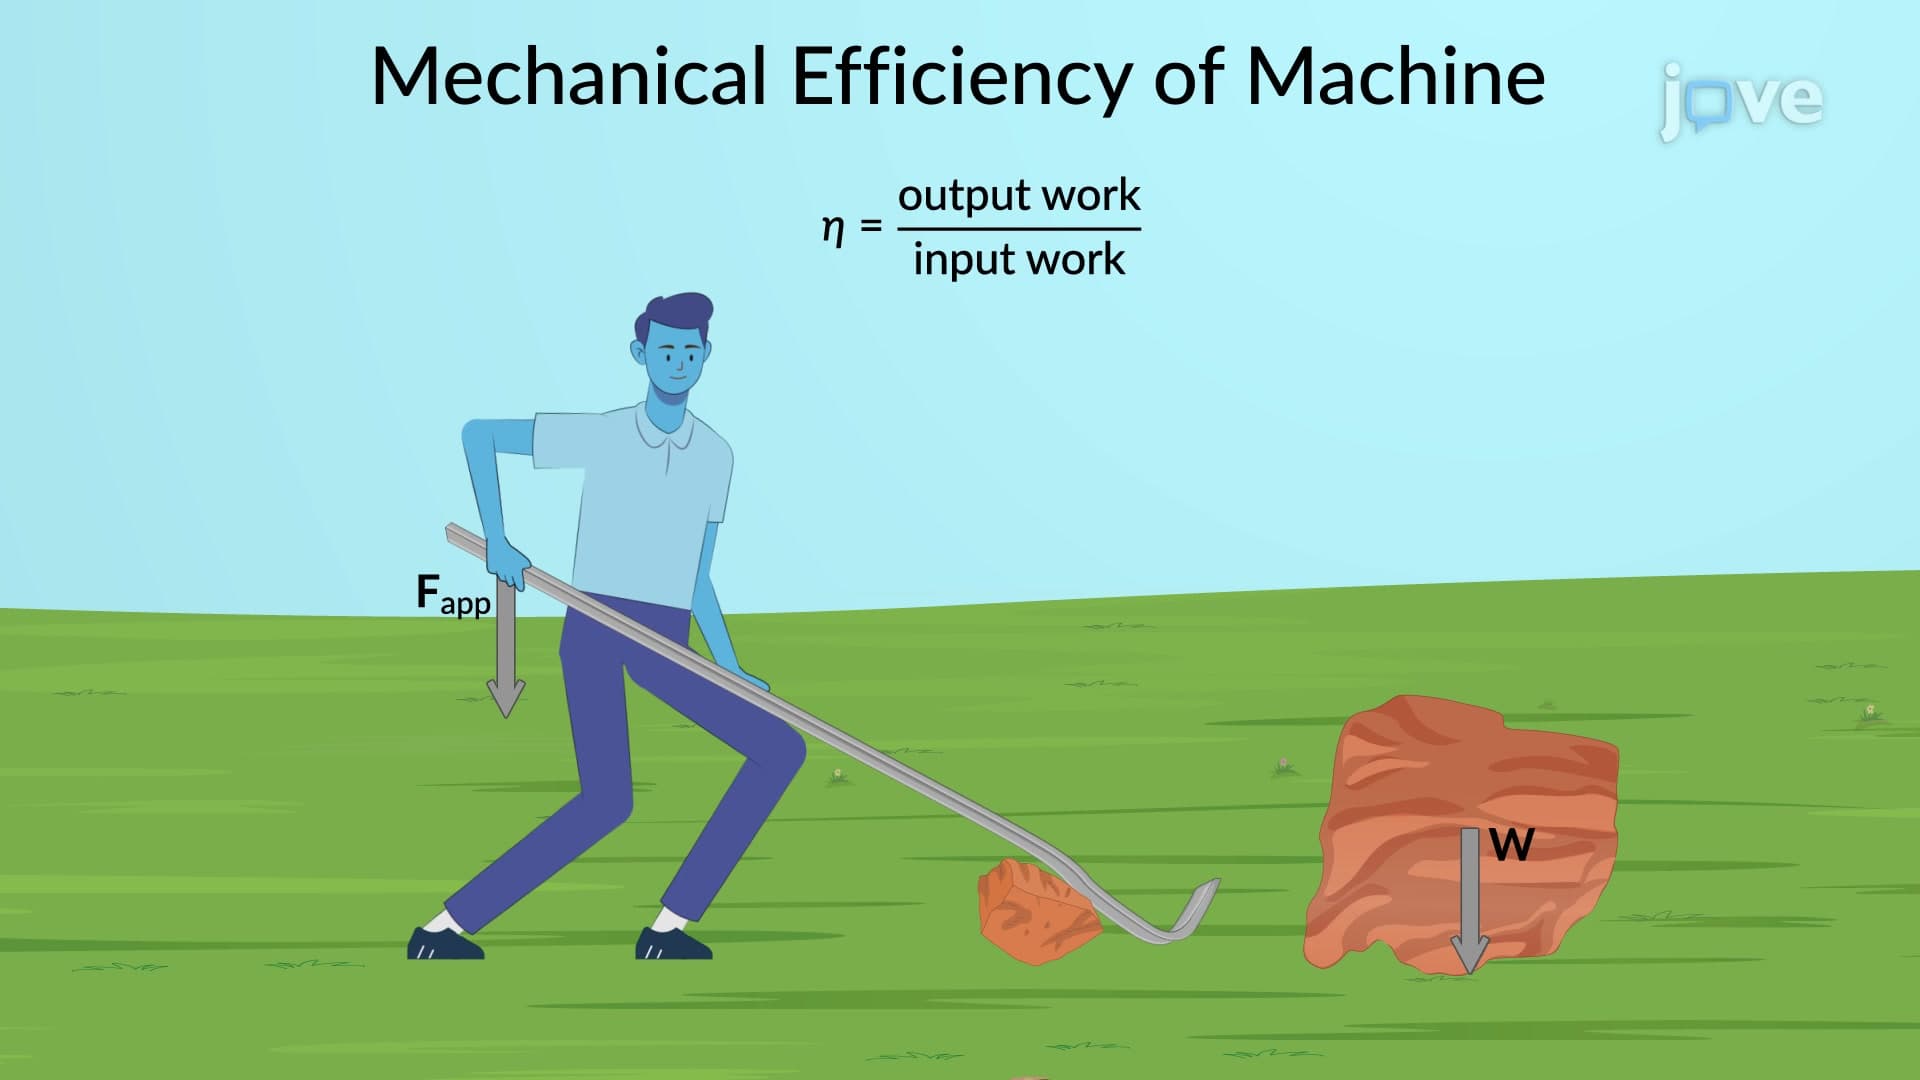
The mechanical efficiency of a machine is a fundamental concept that describes how effectively a machine can convert input work into output work. According to this concept, the efficiency of a machine is equal to the ratio of the output work to the input work. An ideal machine, meaning a machine that has no energy losses, has an efficiency of one. This implies that the input work and the output work are equal.
However, in reality, no machine can be truly ideal, and all of them experience some...
However, in reality, no machine can be truly ideal, and all of them experience some...
1.6K
 01:22
Machines: Problem Solving I
841
A toggle clamp is a mechanical device commonly used for holding and clamping objects in various applications, such as woodworking, metalworking, and assembly operations. Consider a toggle clamp subjected to a force of 200 N at the handle. The vertical clamping force can be calculated, provided the dimensions of the toggle clamp are known.
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
841
 01:30
Machines: Problem Solving II
791
Machines are complex structures consisting of movable, pin-connected multi-force members that work together to transmit forces. Consider a lifting tong carrying a 100 kg load. It comprises movable sections DAF and CBG linked together with member AB.
791
 01:18
Hierarchy of Motor Control
5.6K
The hierarchy of motor control refers to the different levels of organization and processing involved in controlling movement in the body. These levels range from higher cortical areas involved in planning and decision-making to lower spinal cord reflexes that respond automatically to external stimuli.
5.6K
 01:30
Simplified Synchronous Machine Model
1.0K
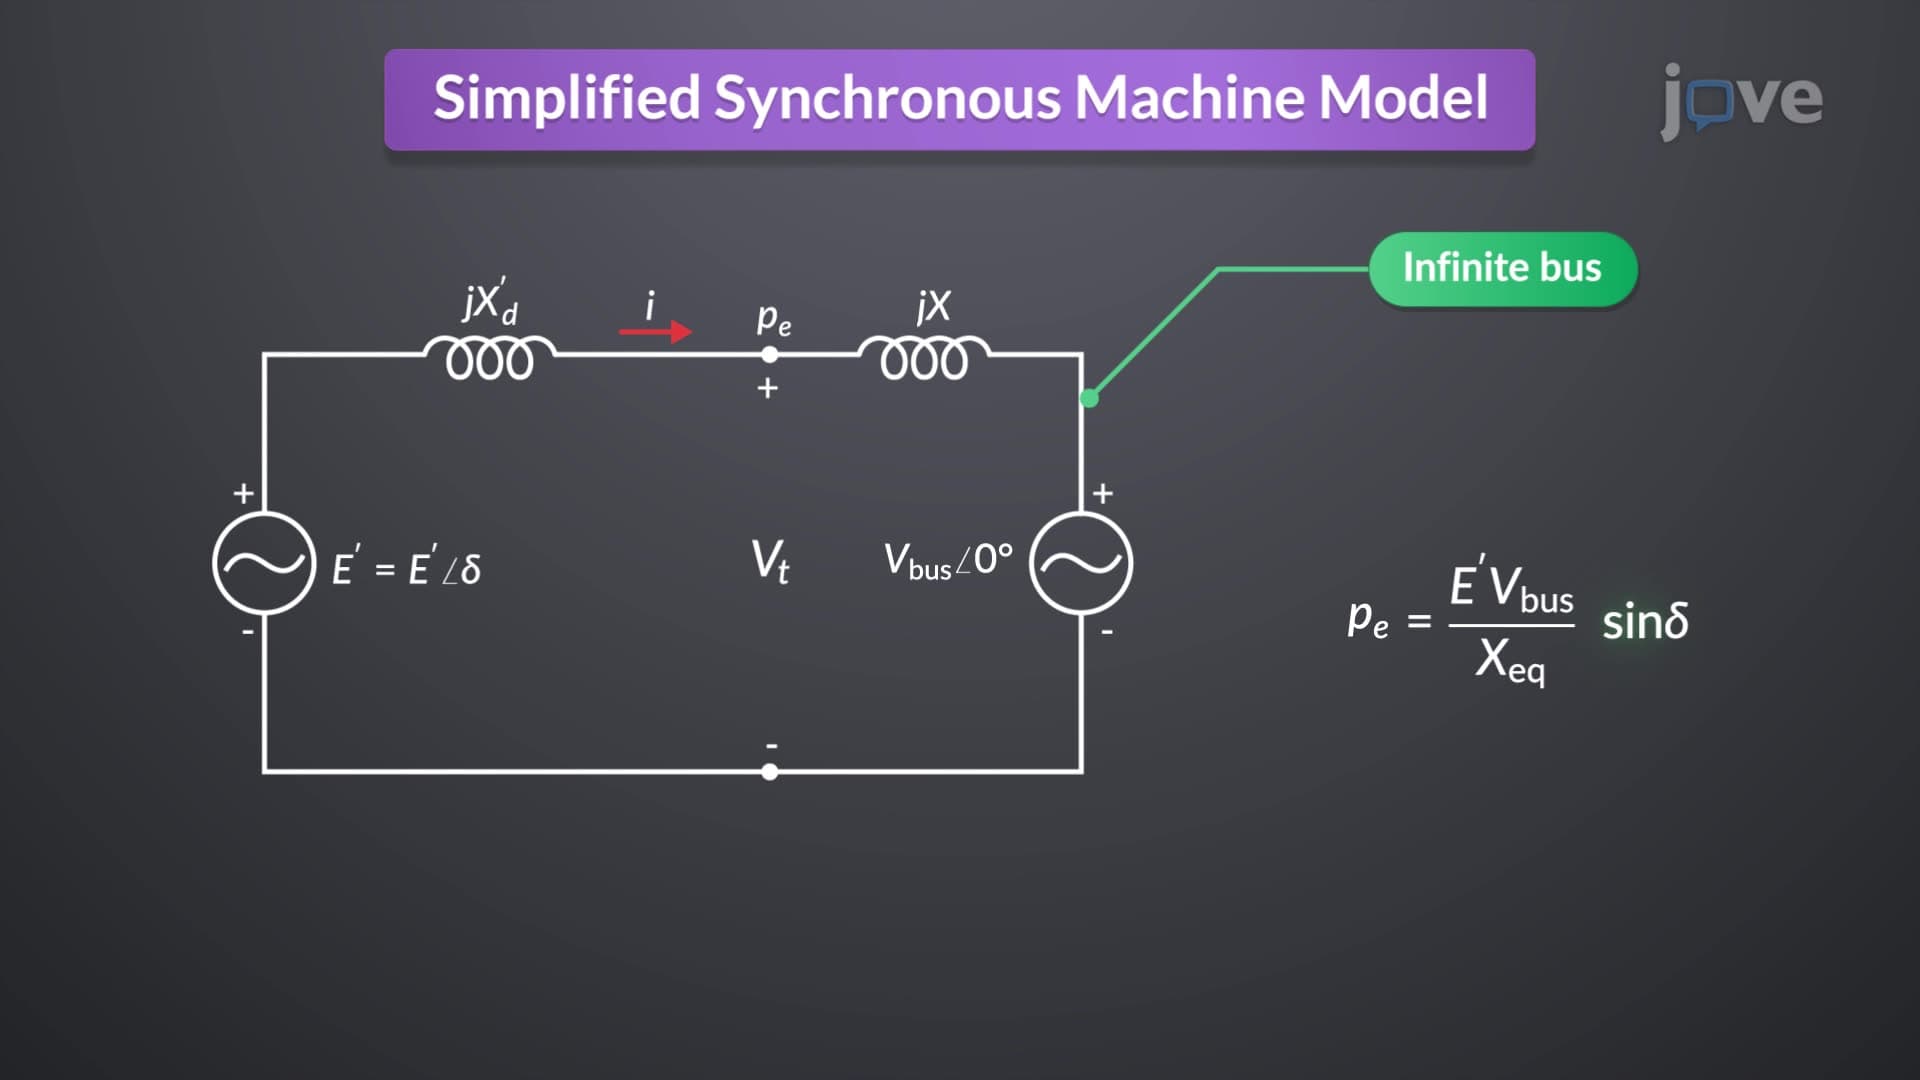
The Synchronous Machine Model is a fundamental tool in analyzing and ensuring the transient stability of power systems. This model simplifies the representation of a synchronous machine under balanced three-phase positive-sequence conditions, assuming constant excitation and ignoring losses and saturation. The model is pivotal for understanding the behavior of synchronous generators connected to a power grid, particularly during transient events.
In this model, each generator is connected to a...
In this model, each generator is connected to a...
1.0K