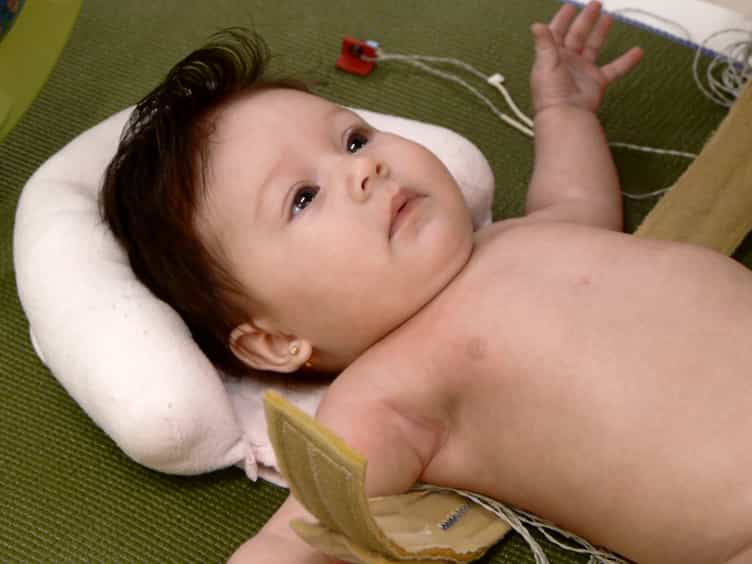

根据长期短期记忆 (LSTM) 网络,预测婴儿爬行时肘部和膝关节的运动轨迹
Jieyi Mo1, Qiliang Xiong2, Ying Chen1
1Department of Biomedical Engineering, Nanchang Hangkong University, Jiangxi, China.
Biomedical engineering online
|April 2, 2025

概括
这项研究表明,长短期记忆 (LSTM) 网络可以准确预测婴儿爬行轨迹,这是开发用于运动康复的高级辅助爬行机器人的关键步骤.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 生物医学工程 生物医学工程
- 机器学习 机器学习
背景情况:
- 婴儿爬行对于运动发育和康复至关重要.
- 辅助爬行设备需要精确的运动轨迹生成.
- 深度学习,就像LSTM一样,显示出预测运动模式的前景.
研究的目的:
- 探索使用LSTM网络来预测婴儿爬行轨迹的可行性.
- 推进机器人爬行康复系统的控制.
- 为了研究婴儿关节运动的预测准确性.
主要方法:
- 收集了来自20名健康婴儿 (8-15个月) 的联合轨迹数据.
- 实施了LSTM网络来预测肘部和膝关节的角度.
- 使用MAE,MSE和CC指标评估了24个输入-输出时间框架组合.
主要成果:
- LSTM网络实现了高预测准确度 (高达99.9%的CC).
- 较小的输出窗口大小 (5 个步骤) 会导致更低的预测错误.
- 通过30个输入和5个输出时间步骤实现了最佳性能.
结论:
- 对于预测婴儿爬行轨迹来说,LSTM网络是可行的.
- 研究结果支持将康复机器人与外骨控制系统集成.
- 进一步的研究可以优化模型以改善辅助设备控制.
相关概念视频
 01:25
Relative Motion Analysis using Rotating Axes
437
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
437
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
378
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
378
 01:23
Curvilinear Motion: Rectangular Components
376
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
376
 01:24
Absolute Motion Analysis- General Plane Motion
197
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
197
 01:15
Kinematic Equations: Problem Solving
11.8K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
11.8K
 01:24
Relative Motion Analysis - Velocity
332
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
332