相关实验视频
Updated: May 16, 2025
04:48

Swin-PSAxialNet: An Efficient Multi-Organ Segmentation Technique
Published on: July 5, 2024
331
联合Former:一个统一的框架,用于视频对象分割的联合建模

概括
联合格式统一功能提取和匹配视频对象分割 (VOS),改善细节捕获和对干扰因素的稳定性. 这种新的框架在多个具有挑战性的基准上取得了最先进的结果.
科学领域:
- 计算机视觉 计算机视觉
- 人工智能的人工智能
- 机器学习 机器学习
背景情况:
- 目前的视频对象细分 (VOS) 方法使用脱的提取然后匹配管道.
- 这种方法将frame-to-frame信息传播限制在高级特征上,阻碍细粒度细节的捕获和对干扰因素的稳定性.
研究的目的:
- 提出一个统一的视频对象分割 (VOS) 框架,JointFormer,这种联合模型具有提取功能,对应匹配和内存.
- 通过实现广泛的多层特征传播和整合长期,整体的目标信息来提高VOS性能.
主要方法:
- 联合Former使用一个联合建模块,使用注意力操作来同时提取和传播特征.
- 一个带有在线更新机制的压缩内存令牌聚合了目标特征,用于智的时间信息传播.
- 该框架促进实例特征学习和全球建模一致性.
主要成果:
- 在DAVIS 2017和YouTube-VOS基准上,JointFormer取得了新的最先进的表现.
- 该模型表现出卓越的概括性和稳定性,在各种新基准 (MOSE,VISOR,VOST,LVOS) 上取得了最佳表现.
- 废除研究证实了JointFormer在综合特征学习和匹配方面的有效性.
结论:
- 统一的JointFormer框架显著提升了视频对象细分能力.
- 它的联合建模方法和压缩内存机制在各种VOS挑战中提供了卓越的性能和概括性.
- 对于复杂的视频对象分割任务,JointFormer提供了一个更有效和更强大的解决方案.

相关概念视频
 01:20
Structural Classification of Joints
3.1K
Joints, also known as articulations, are classified based on their structural characteristics, i.e., based on whether the articulating surfaces of the adjacent bones are directly connected by fibrous connective tissue or cartilage, or whether the articulating surfaces contact each other within a fluid-filled joint cavity. These differences serve to divide the joints of the body into three structural classifications.
A fibrous joint is where the adjacent bones are united by fibrous connective...
A fibrous joint is where the adjacent bones are united by fibrous connective...
3.1K
 01:12
Modeling and Similitude
138
Scaled modeling is a fundamental technique in engineering, enabling the study of large and complex systems by creating smaller, manageable replicas that recreate critical characteristics of the original. In hydrology and civil infrastructure, for example, scaled models of dams help analyze water flow, turbulence, and pressure. This method allows for accurate predictions of real-world behavior within a controlled environment, significantly reducing the cost and time involved in full-scale...
138
 01:09
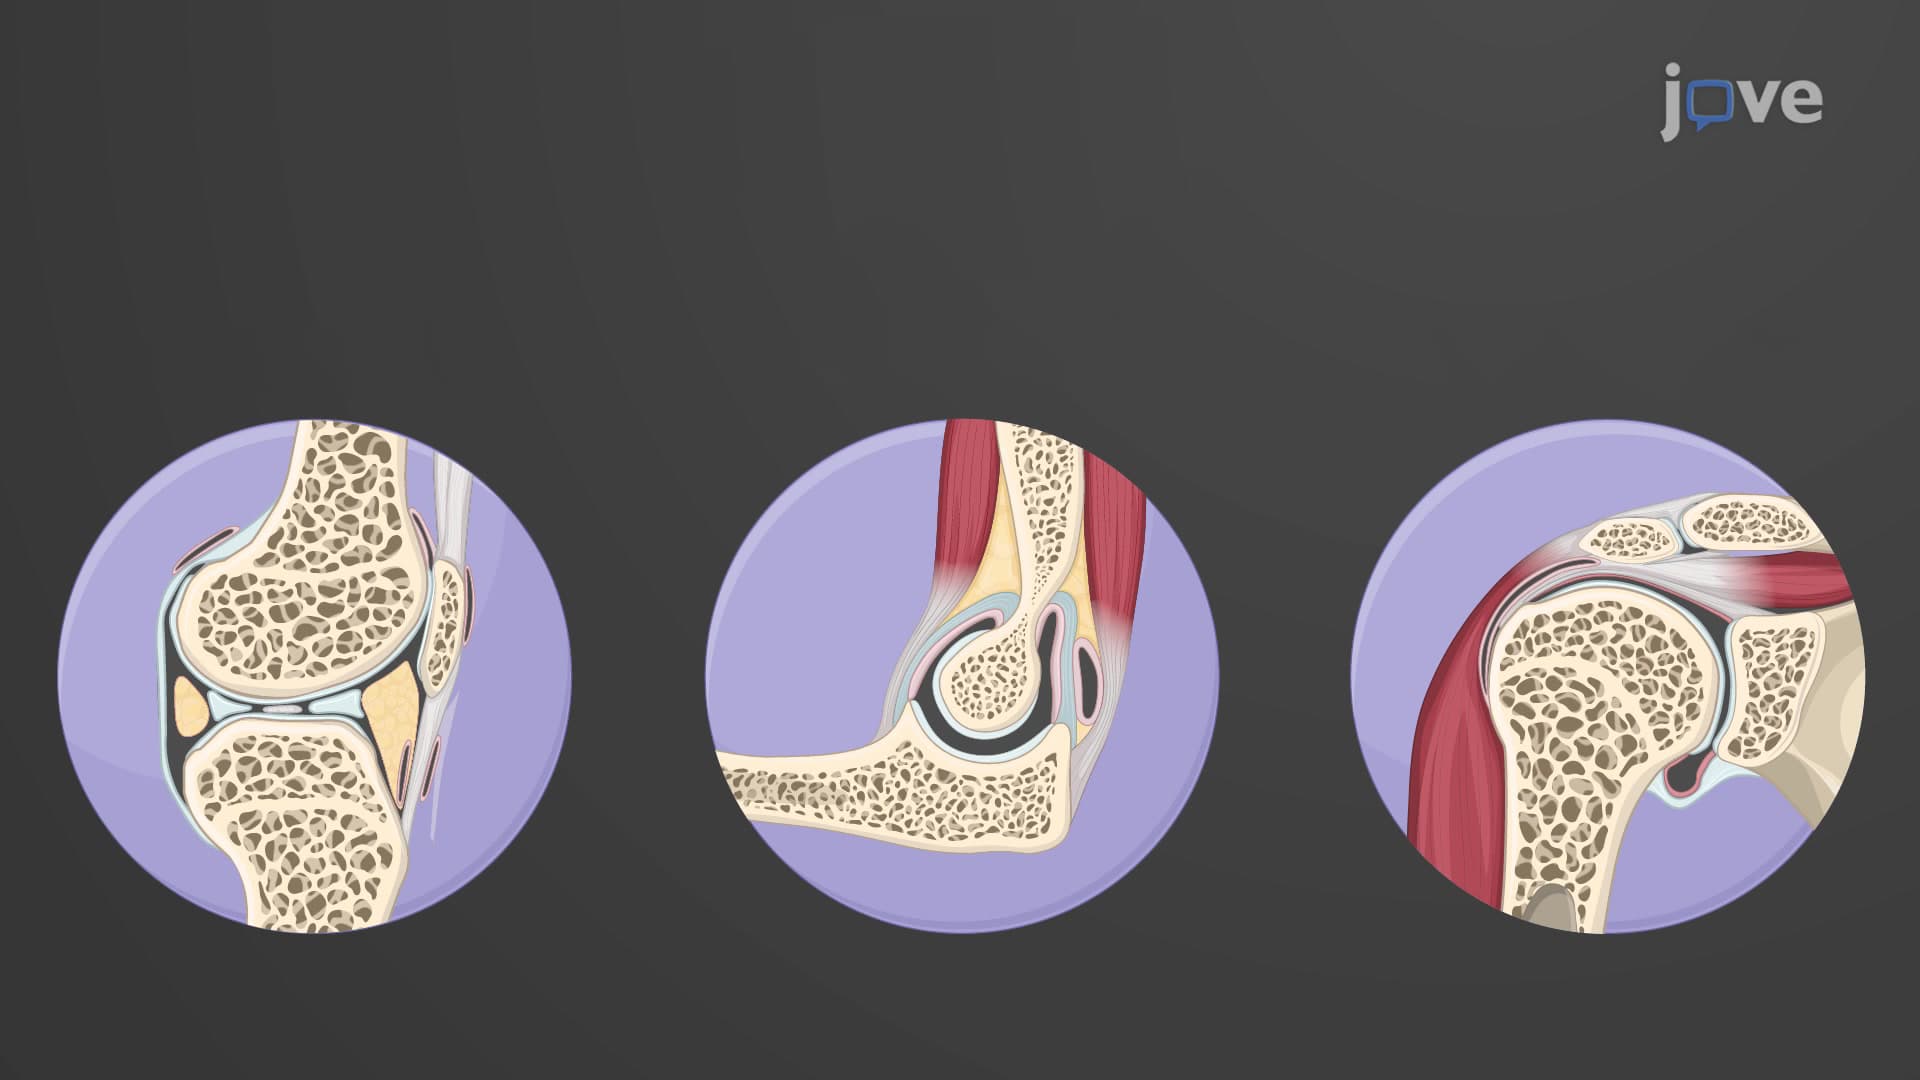
Functional Classification of Joints
3.7K
Functional Classification of Joints
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An...
3.7K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
378
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
378
 01:25
Relative Motion Analysis using Rotating Axes
436
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
436
 01:06
Virtual Work for a System of Connected Rigid Bodies
355
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
355