

对于未知控制方向的MIMO非线性系统,规定的性能观察员-控制器设计
Guan-Qun Chen1, Wen-Bo Xie2, Dong Qu1
1School of Artificial Intelligence, Shanghai University, Shanghai, 200444, PR China.
ISA transactions
|April 5, 2025

概括
这项研究引入了一个新的观察者控制器,用于未知输入方向的非线性系统,确保受限制的跟踪错误,以提高无人驾驶表面车辆等应用中的性能.
科学领域:
- 控制系统工程 控制系统工程
- 非线性系统分析 非线性系统分析
- 机器人技术和自主系统
背景情况:
- 多输入多输出 (MIMO) 非线性系统带来了重要的控制挑战,特别是未知的输入方向.
- 准确的状态估计和精确的轨迹跟踪对于自主系统的有效运行至关重要.
- 现有的控制方法往往在不确定性下难以保证性能约束.
研究的目的:
- 开发一个能够处理未知输入方向的多输入多输出 (MIMO) 非线性系统的观察者控制器.
- 通过整合规定的性能控制技术来确保受限的跟踪错误.
- 在实际应用中验证拟议的方法,例如无人驾驶地面车辆 (USV) 轨迹跟踪.
主要方法:
- 一个新的观察者设计,包括相当的输出注入和规定的性能,以限制估计错误.
- 使用Nussbaum函数和规定的性能控制 (PPC) 来管理未知的控制方向的控制器设计.
- 在无人地面车辆 (USV) 上进行模拟和实验验证,用于轨迹跟踪控制.
主要成果:
- 建议的观察者有效地限制了估计错误,即使存在系统非线性和未知的动态.
- 集成的观察者控制器成功实现了受约束的跟踪性能,证明了对未知的控制方向的稳定性.
- 该方法在无人驾驶地面车辆 (USV) 的轨迹跟踪控制任务中显示出显著的有效性.
结论:
- 开发的观察者控制器为控制未知输入方向的MIMO非线性系统提供了强大的解决方案.
- 规定的性能控制和Nussbaum函数的集成为实现受约束的控制目标提供了一个强大的方法.
- 对USV轨迹跟踪的成功应用凸显了拟议的控制战略的实际可行性和有效性.


相关概念视频
 01:22
Controller Configurations
75
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
75
 01:26
Feedback control systems
256
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
256
 01:22
Multi-input and Multi-variable systems
91
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
91
 01:21
Transfer Function in Control Systems
259
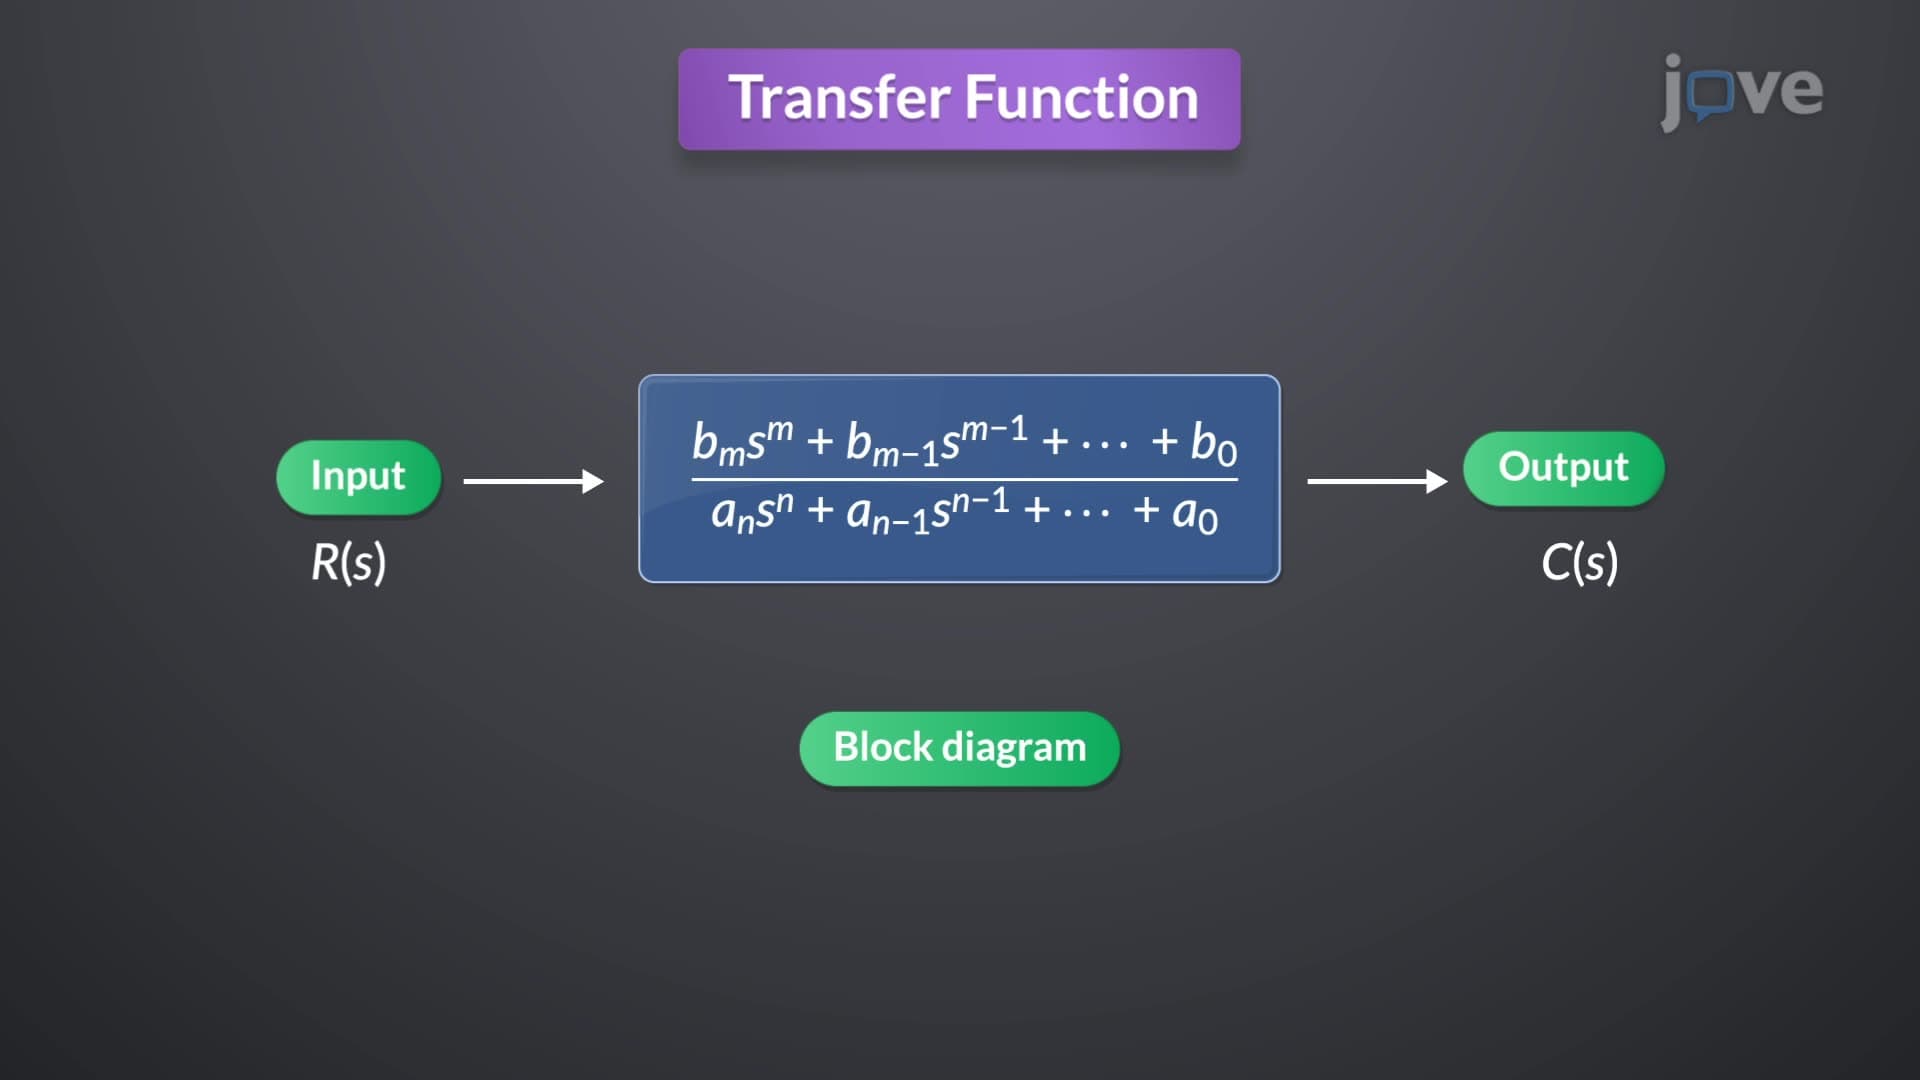
The transfer function is a fundamental concept in the analysis and design of linear time-invariant (LTI) systems. It offers a concise way to understand how a system responds to different inputs in the frequency domain. It serves as a bridge between the time-domain differential equations that describe system dynamics and the frequency-domain representation that facilitates easier manipulation and analysis.
To derive the transfer function, consider a general nth-order linear time-invariant...
To derive the transfer function, consider a general nth-order linear time-invariant...
259
 01:23
Linear time-invariant Systems
190
A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
190
 01:17
Open and closed-loop control systems
581
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
581