

一个手腕机器人与电缆差分调动的动力学兼容性:通过被动关节的错位补偿的影响
Haider A Chishty1, Andrea Zonnino1, Andria J Farrens1
1Human Robotics Laboratory, Department of Biomedical and Mechanical Engineering, University of Delaware, Newark, DE 19713 USA.
IEEE transactions on medical robotics and bionics
|April 7, 2025

概括
我们开发了两种手腕外骨架设计,以测试运动兼容性. 虽然一个设计 (UDW-NC) 更好地处理关节错位,但它比另一个设计 (UDW-C) 引入了更多的摩擦和更不精确的扭矩传递.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 生物力学 生物力学
- 人与机器人的交互
背景情况:
- 手腕外骨架旨在增强人类的运动,并使康复成为可能.
- 实现人类和机器人关节之间的动力学兼容性对于有效和安全的互动至关重要.
- 设计选择对外骨的性能产生重大影响,特别是关节对齐和摩擦.
研究的目的:
- 为了比较两种不同的设计策略,在2-DOF手腕外骨架中实现动力学兼容性.
- 评估不同外骨架设计中强度与失调,摩擦和扭矩传递精度之间的权衡.
主要方法:
- 开发了两个UDiffWrist (UDW) 外骨架版本:UDW-C (依赖对齐) 和UDW-NC (通过被动关节独立对齐).
- 在不同的关节对齐条件下量化性能的表征实验.
- 对相互作用扭矩,库伦摩擦和扭矩转移精度的分析.
主要成果:
- 与UDW-C相比,UDW-NC表现出更强大的对关节错位的稳定性,与UDW-C相比,最大相互作用扭矩的增加较小 (p = 0.003).
- 在UDW-NC表现出显著更高的库伦摩擦 (p < 0.001),这也增加了更多的 misalignment.
- 与UDW-NC相比,UDW-C的扭矩传递精度被发现在UDW-C中优越.
结论:
- 对于有限的2-DOF手腕运动,UDW-NC的改进动力兼容性可能会因增加摩擦和减少扭矩传递精度而被否定.
- UDW-C设计提供了更好的扭矩精度,这表明在手腕外骨架设计中,在对齐容忍度和性能忠实性之间存在潜在的权衡.


相关概念视频
 01:27
Support Reactions in Three Dimensions
843
Support reactions in three dimensions help maintain the stability and equilibrium of various structures and systems. These reactions prevent the system from translating and rotating, ensuring the design can withstand external forces and perform its intended function efficiently and safely. Some of the supports providing support reactions in three dimensions are discussed below:
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
843
 01:30
Machines: Problem Solving II
270
Machines are complex structures consisting of movable, pin-connected multi-force members that work together to transmit forces. Consider a lifting tong carrying a 100 kg load. It comprises movable sections DAF and CBG linked together with member AB.
270
 01:24
Frames: Problem Solving I
378
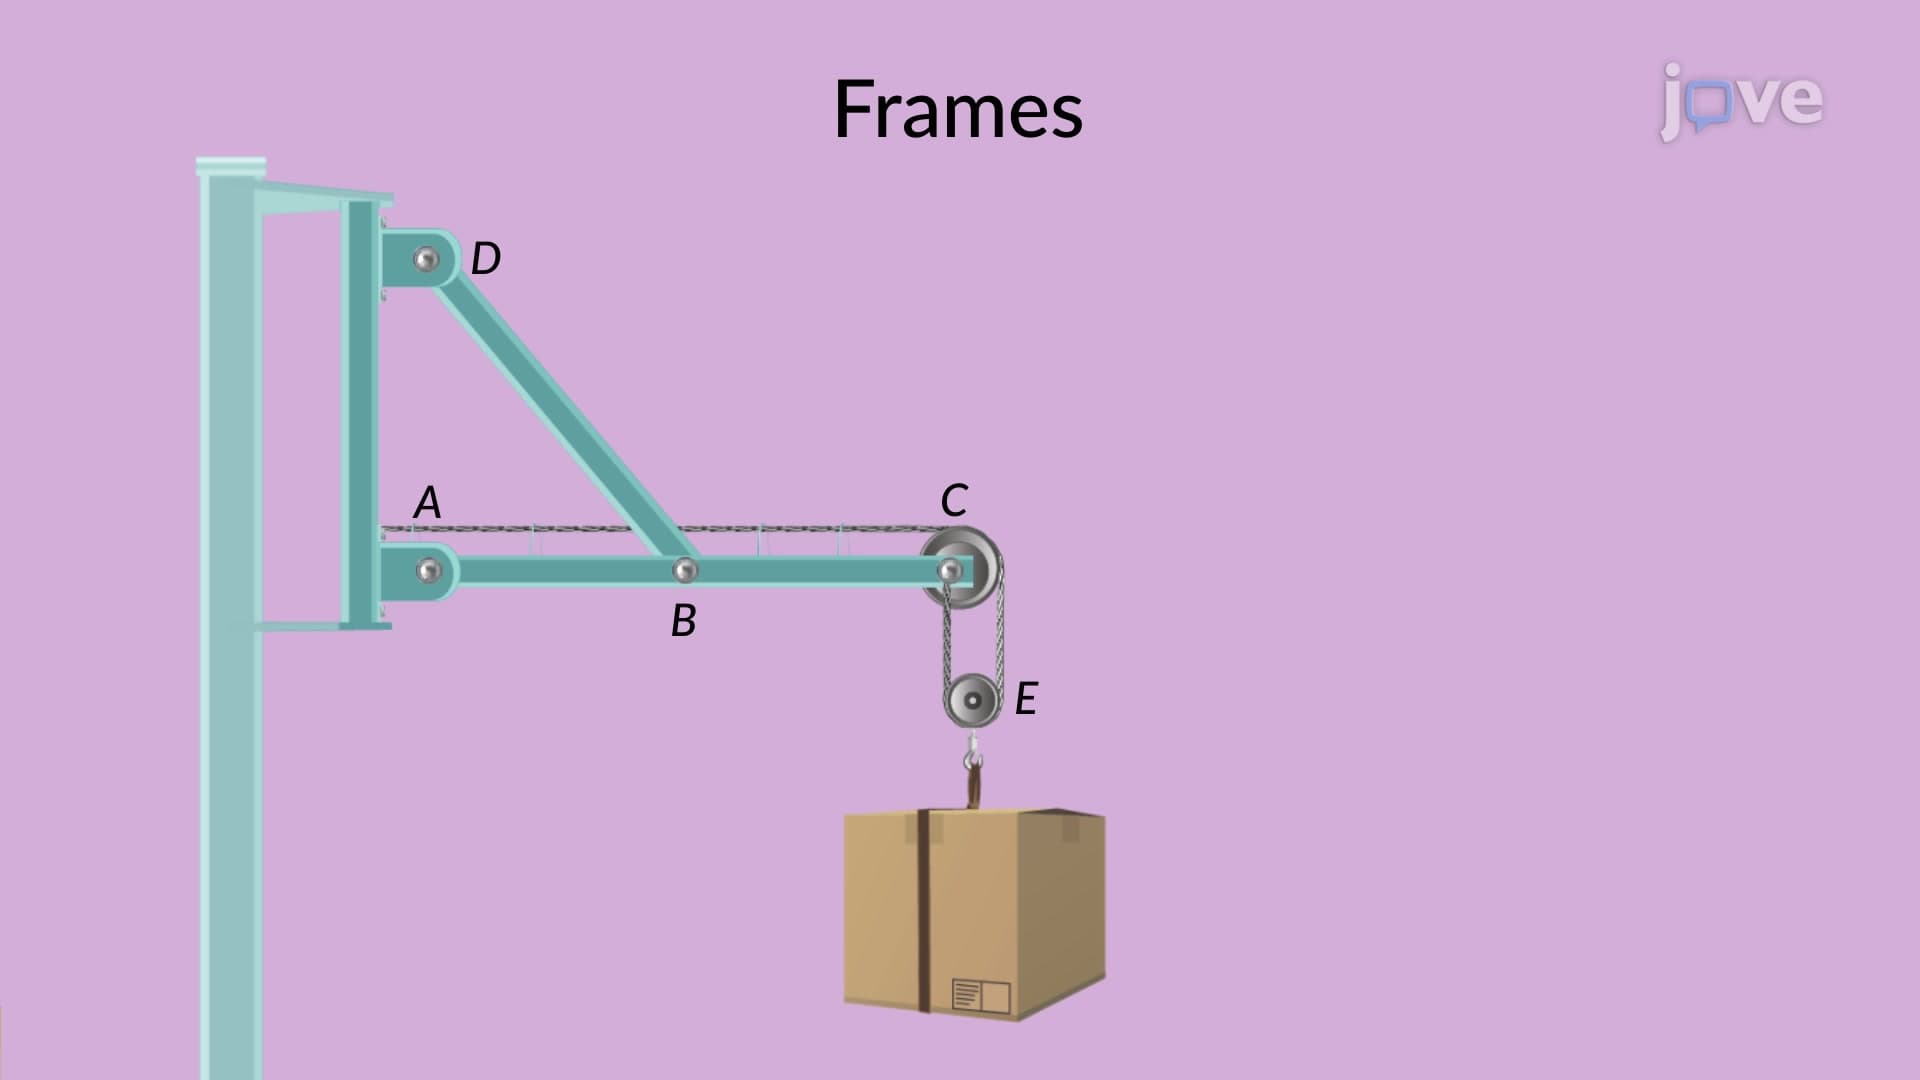
Consider a jib crane with an external load suspended from the pulley. The dimensions of the crane members are shown in the figure. A systematic analysis of the frame structure is required to determine the reaction forces at the pin joints, assuming that the pulleys are frictionless.
378
 01:23
Journal Bearings
607
Journal bearings are mechanical components that support and provide lateral stability to rotating shafts and axles. They are crucial in reducing friction, wear, and vibration in machinery such as engines, turbines, and pumps. The principle behind journal bearings is forming a thin lubricant film between the bearing surface and the rotating shaft, which minimizes direct contact and reduces frictional forces.
To better understand the concept of journal bearings, consider a rope winch with dry or...
To better understand the concept of journal bearings, consider a rope winch with dry or...
607
 01:10
Deformation in a Circular Shaft
251
One of the distinctive characteristics of circular shafts is their ability to maintain their cross-sectional integrity under torsion. In other words, each cross-section continues to exist as a flat, unaltered entity, simply rotating like a solid, rigid slab. To understand the distribution of shearing stress within such a shaft, consider a cylindrical section inside this circular shaft. This section has a length of L and a radius of R, with one end fixed. The radius of the cylindrical section is...
251
 01:24
Relative Motion Analysis - Velocity
332
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
332