技术报告:角膜转移图的计算和解释
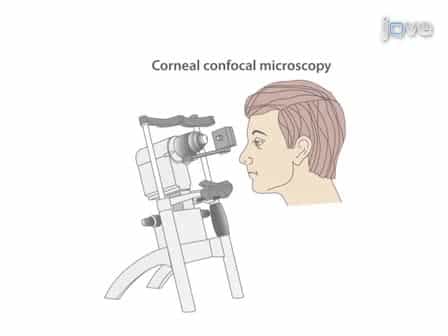

概括
转移矩阵揭示了角膜生物力学,将光学特性与角膜检测联系起来. 从这些矩阵中获得的新角膜图可能有助于早期诊断和监测病情.
科学领域:
- 眼科医生 眼科 眼科
- 生物医学光学 生物医学光学
- 角质生物力学 角质生物力学
背景情况:
- 转移矩阵是线性光学中已知的工具.
- 它们在角膜分析中的应用提供了超越传统光线追踪的新见解的潜力.
- 了解ABCD条目与角膜变量之间的关系是关键.
研究的目的:
- 探索角膜转移矩阵的四个条目 (A,B,C,D) 的解释.
- 为了将这些条目与熟悉的角膜参数相关联,例如曲率半径,厚度和折射力.
- 为了研究转移矩阵的潜力,用于检测角.
主要方法:
- 用Scheimpflug断层扫描数据计算了大约12,000点的角膜转移矩阵.
- 生成了A,B,C和D条目的角膜点对点地图.
- 转移矩阵的痕迹也被计算出来.
主要成果:
- A,B,C和D图表与临床图表的包度 (B) 和角膜功率 (C) 有相似之处.
- 条目A与一个新的变量相关,角膜应激贡献 (CCS),对形检测有用.
- 输入D似乎与后角膜表面参数有关,痕迹显示了角膜的独特模式.
结论:
- 角膜转移矩阵条目 (A,B,C,D) 提供了临床相关的信息,包括精度,角膜功率和CCS.
- 转移矩阵的痕迹产生了一个新的地图,将CCS和后角膜参数结合起来.
- 这张新的地图显示了形检测和患者随访的前景.
更多相关视频
 07:51
Full-Field Optical Coherence Microscopy for Histology-Like Analysis of Stromal Features in Corneal Grafts
Published on: October 21, 2022
1.6K
 12:36
A Human Corneal Organ Culture Model of Descemet's Stripping Only with Accelerated Healing Stimulated by Engineered Fibroblast Growth Factor 1
Published on: July 22, 2022
4.5K
相关概念视频
 01:24
Relative Motion Analysis - Velocity
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:25
Relative Motion Analysis using Rotating Axes
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:10
Relative Motion Analysis - Acceleration
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...