
基于memristor的超混沌系统的设计和特征分析
Zhixia Ding1, Mengyan Li1, Liheng Wang1
1School of Electrical and Information Engineering, Wuhan Institute of Technology, Wuhan 430205, China.
Chaos (Woodbury, N.Y.)
|April 10, 2025

概括
这项研究引入了一种新的分数离散记忆器模型,增强记忆器的特性,并使新的超混沌系统成为可能. 该系统具有可调整的复杂性和多稳定性,通过电路模拟进行验证.
科学领域:
- 非线性动力学是一种非线性动力学.
- 混沌理论 混沌理论
- 记忆器应用程序 应用程序
背景情况:
- 离散的记忆混乱系统具有不连续的轨迹.
- 理想的整数顺序的memristor模型对实际设备缺乏准确性.
研究的目的:
- 介绍一个格伦瓦尔德-列特尼科夫类型的二次三变量分数离散记忆器模型.
- 增强memristors的非线性和内存特性.
- 构建一个新的四维分数离散记忆的混乱系统.
主要方法:
- 开发了一个分数离散的memristor模型.
- 结合非均,不相称的顺序memristors创建一个超混沌的系统.
- 分析动力学使用吸引力相图,分叉图,利亚普诺夫指数和变.
主要成果:
- 拟议的系统表现出更大的超混沌区域和更高的复杂性.
- 观察到丰富的多稳定行为,包括共存的吸引力和增强的偏移.
- 证明了不相称顺序参数用于控制混乱状态的调整性.
结论:
- 分数离散记忆器模型准确地反映了实际设备的特性.
- 新的超混沌系统提供了先进的结构和灵活的内存效果优化.
- 电路模拟验证了系统的数值发现.
相关概念视频
 01:18
Second Order systems II
72
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
72
 01:21
First Order Systems
78
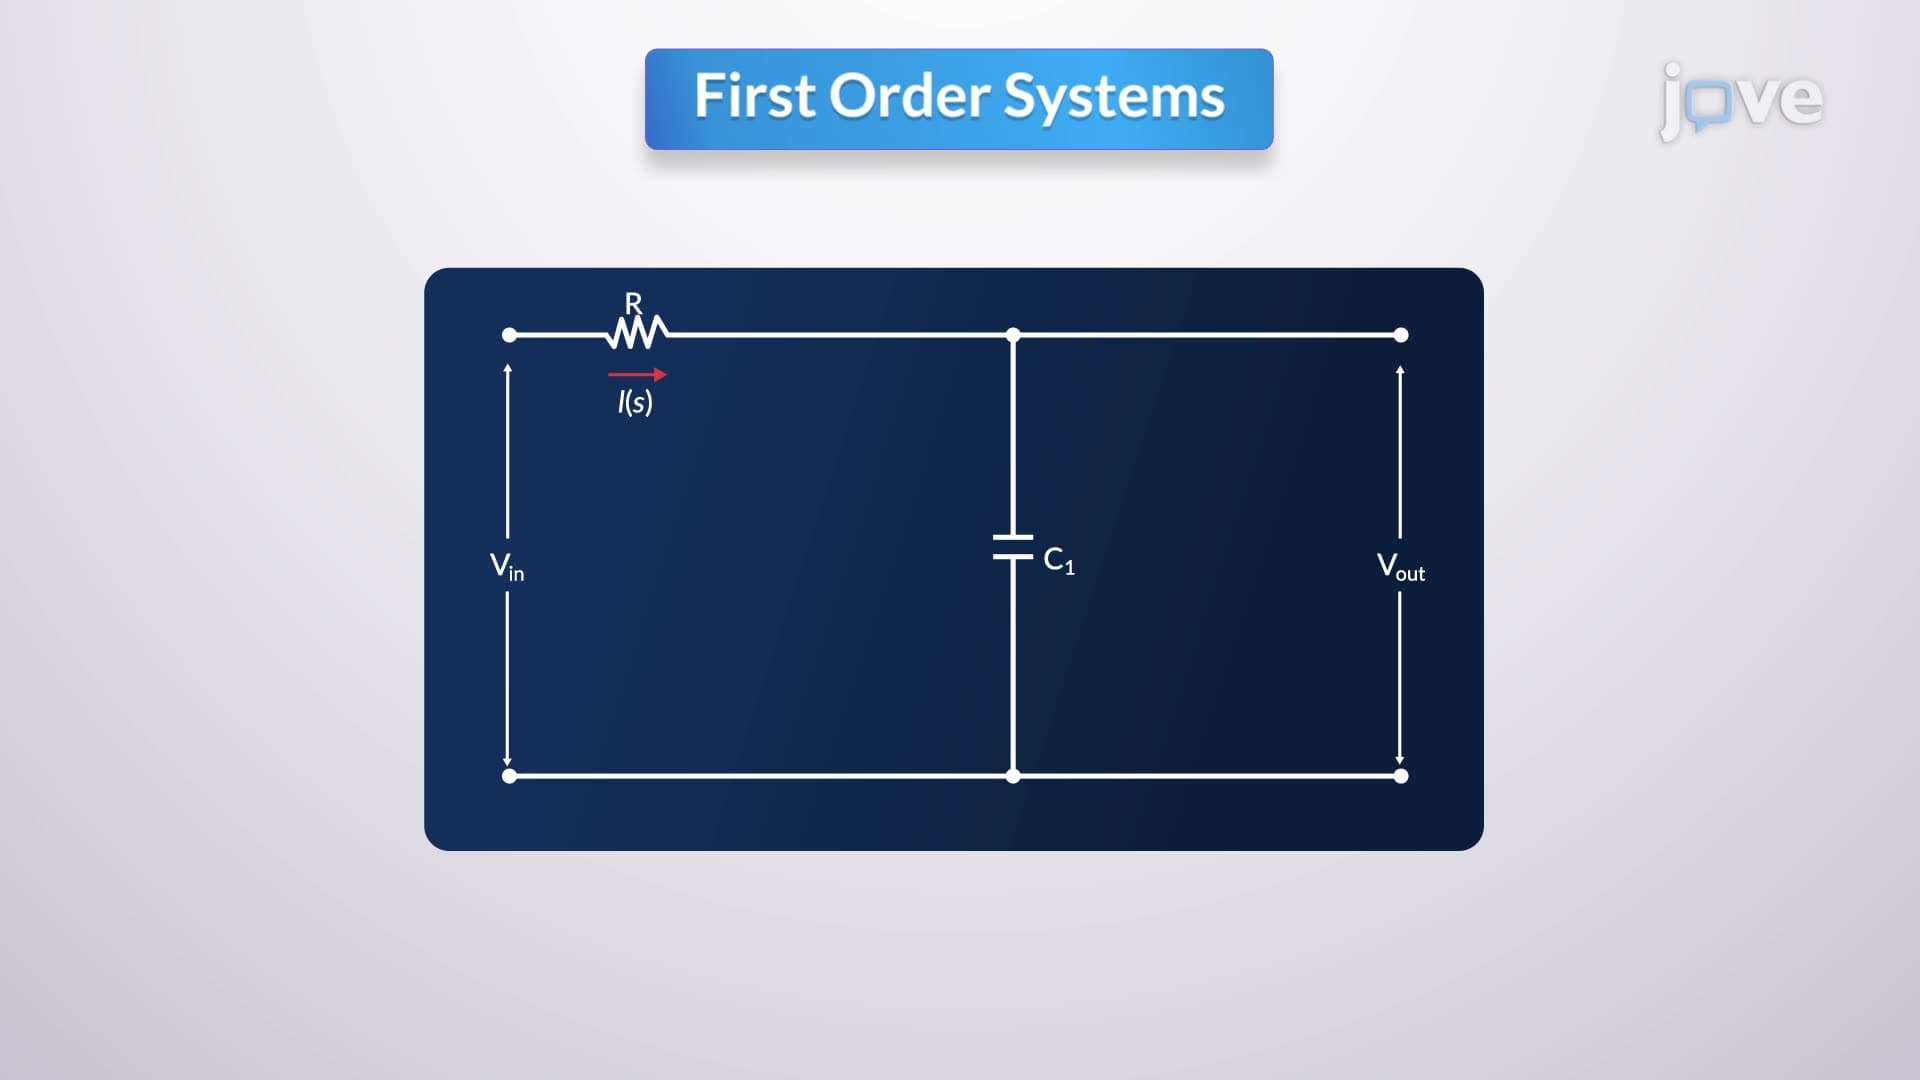
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
78
 01:24
One-Degree-of-Freedom System
440
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
440
 01:17
Second-Order Circuits
1.2K
Integrating two fundamental energy storage elements in electrical circuits results in second-order circuits, encompassing RLC circuits and circuits with dual capacitors or inductors (RC and RL circuits). Second-order circuits are identified by second-order differential equations that link input and output signals.
Input signals typically originate from voltage or current sources, with the output often representing voltage across the capacitor and/or current through the inductor. For example, in...
Input signals typically originate from voltage or current sources, with the output often representing voltage across the capacitor and/or current through the inductor. For example, in...
1.2K
 01:30
RLC Series Circuits
2.8K
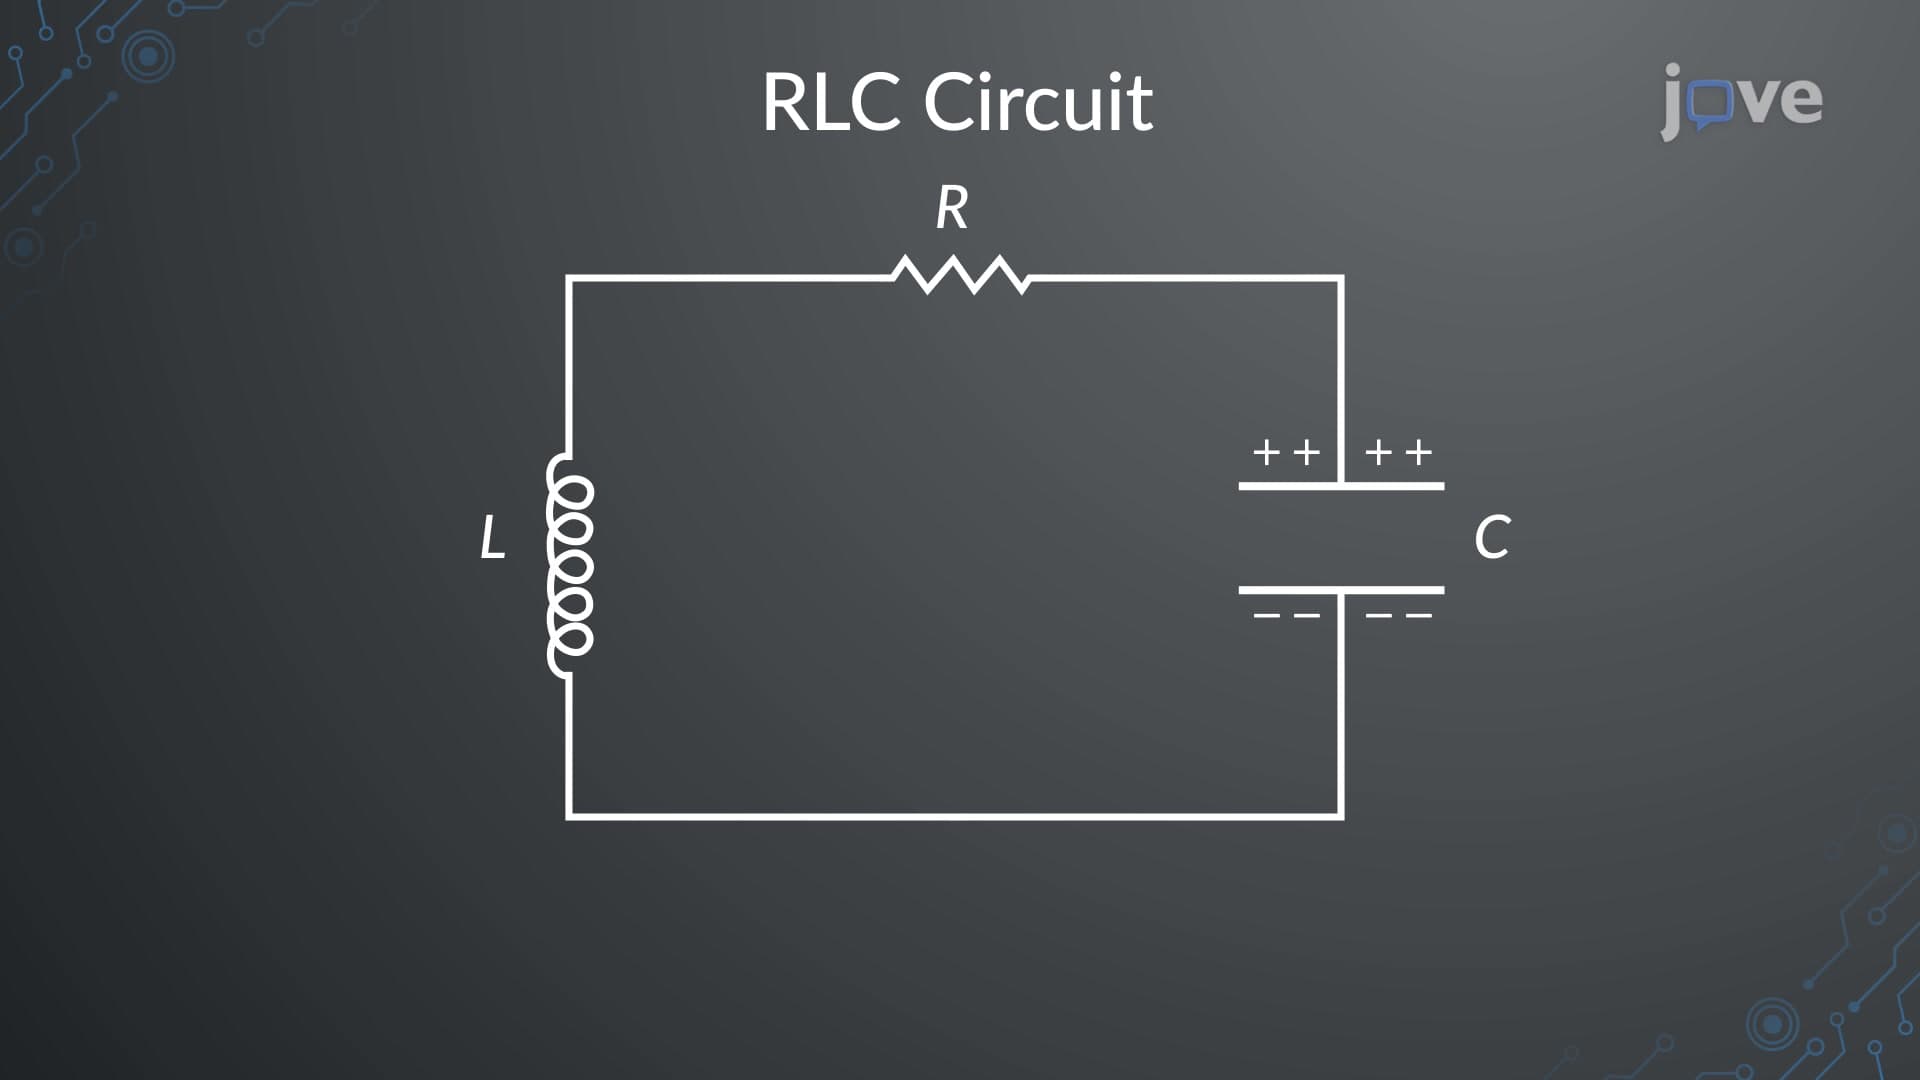
An RLC series circuit comprises an inductor, a resistor, and a charged capacitor connected in series. When the circuit is closed, the capacitor begins to discharge through the resistor and inductor by transferring energy from the electric field to the magnetic field. Here, the resistor connected to the circuit causes energy losses; therefore, on the complete discharge of the capacitor, the magnetic field energy acquired by the inductor is less than the original electric field energy of the...
2.8K
 01:20
Second Order systems I
119
A servo system exemplifies a second-order system, featuring a proportional controller and load elements that ensure the output position aligns with the input position. The relationship between these components is described by a second-order differential equation. Applying the Laplace transform under zero initial conditions yields the transfer function, showing how inputs are converted to outputs in the system.
By reinterpreting the system, one can derive the closed-loop transfer function, which...
By reinterpreting the system, one can derive the closed-loop transfer function, which...
119