
一个6轴混合机器人的摩擦补偿方法,考虑联合惯性变化
Qi Liu1,2, Sitong Shen1,2, Yue Ma1,2
1Tianjin Key Laboratory for Advanced Mechatronic System Design and Intelligent Control, School of Mechanical Engineering, Tianjin University of Technology, Tianjin 300384, China.
iScience
|April 14, 2025

概括
这项研究通过结合关节惯性变化来增强机器人的摩擦补偿. 新方法提高了跟踪精度,特别是在高惯性配置中.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 机械工程 机械工程
- 控制系统 控制系统
背景情况:
- 摩擦显著影响机械系统的性能.
- 精确的摩擦补偿对于精确的机器人运动至关重要.
- 传统模型往往忽略了诸如惯性变化的动态变化.
研究的目的:
- 为6轴混合机器人 (TriMule) 开发一种有效的摩擦补偿方法.
- 为了解决改变关节惯性对摩擦补偿的影响.
- 为了提高不同惯性条件下的机器人系统的追踪精度.
主要方法:
- 在斯特里贝克摩擦模型中引入了联合惯性条款.
- 开发了一种改进的补偿方法,使用辐射基函数插值.
- 通过对TriMule机器人原型的实验验证实了这一方法.
主要成果:
- 拟议的摩擦补偿方法有效考虑了关节惯性变化.
- 使用辐射基函数插值的方法提供了简化的计算.
- 实验结果表明,在高惯性配置下,跟踪精度提高了高达25.73%.
结论:
- 考虑关节惯性变化对于先进的摩擦补偿至关重要.
- 提出的方法为机器人系统提供了一个实用和有效的解决方案.
- 这项工作有助于提高机器人应用中的精度和性能.

相关概念视频
 01:05
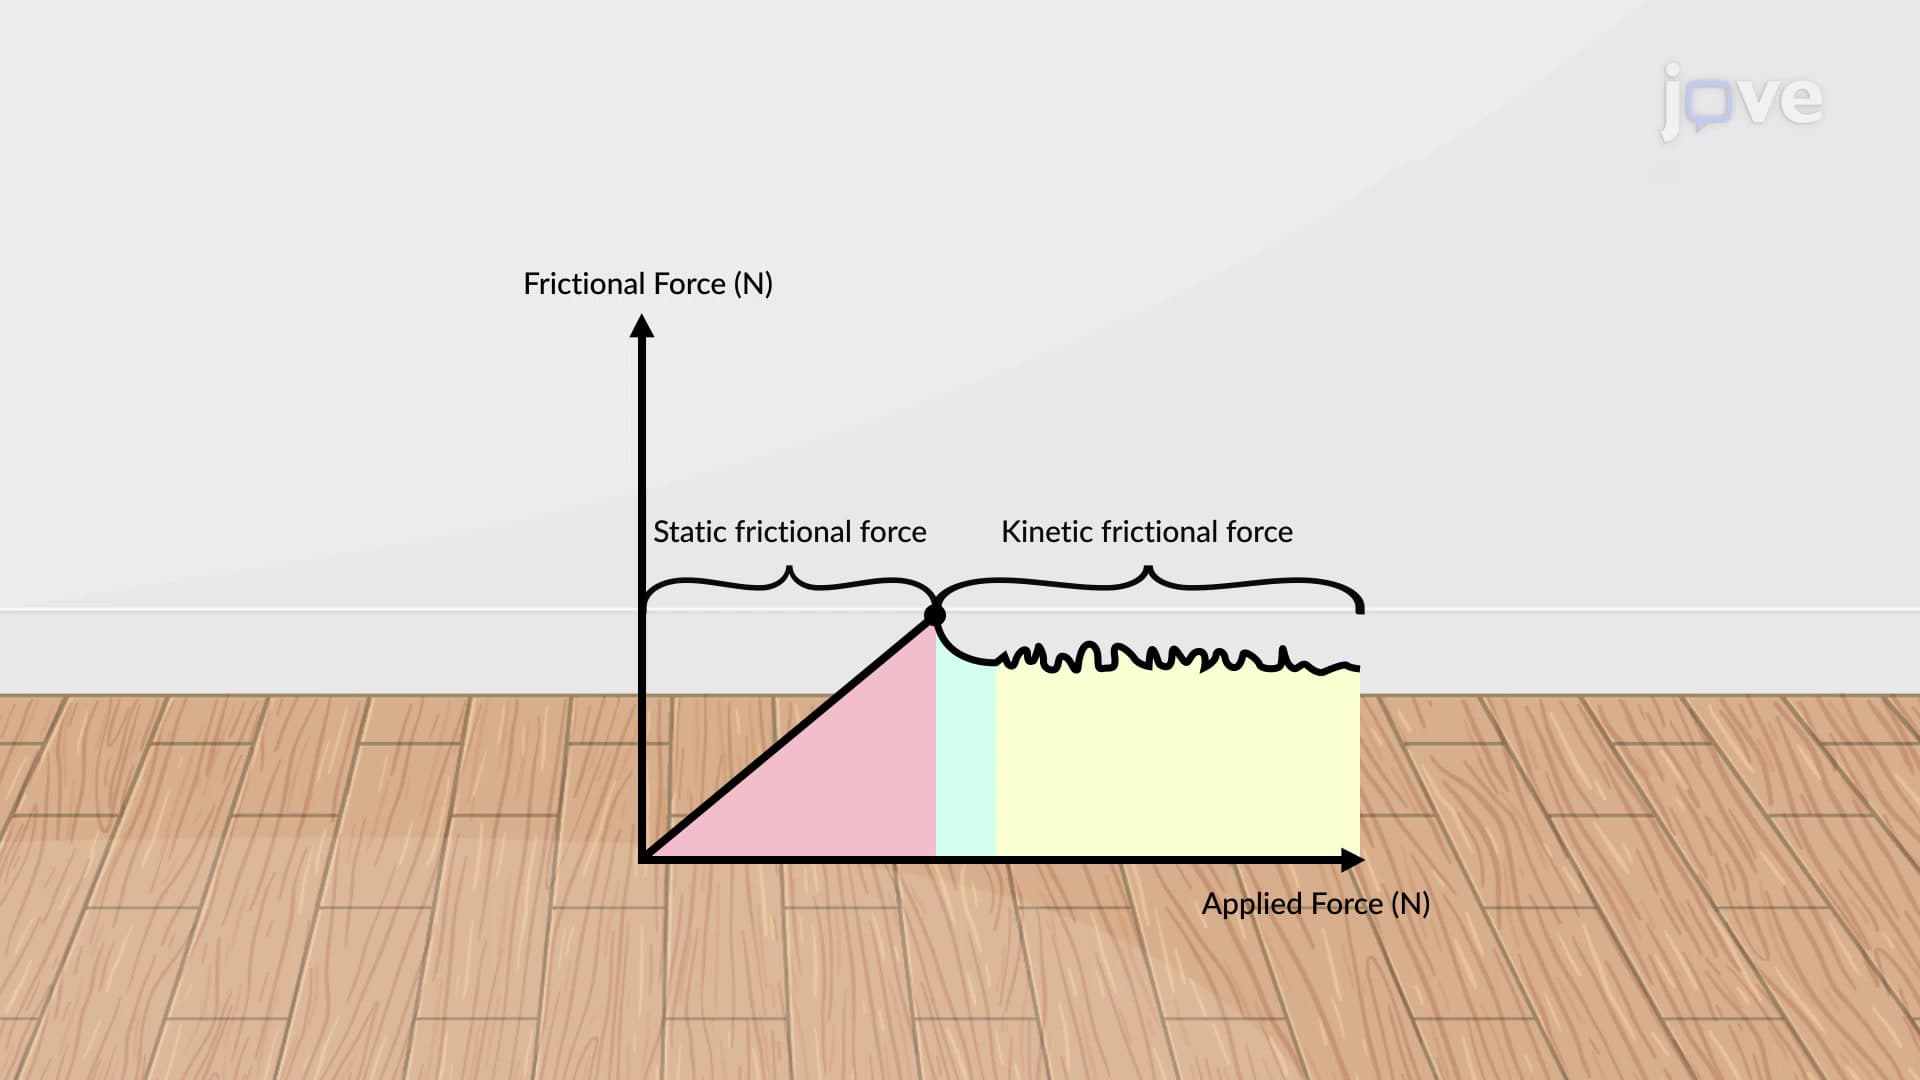
Static and Kinetic Frictional Force
14.9K
One of the simpler characteristics of sliding friction is that it is parallel to the contact surfaces between systems, and is always in a direction that opposes the motion or attempted motion of the systems relative to each other. If two systems are in contact and moving relative to one another, then the friction between them is called kinetic friction. For example, kinetic friction slows a hockey puck sliding on ice.
However, if two systems are in contact and are stationary relative to one...
However, if two systems are in contact and are stationary relative to one...
14.9K
 01:16
Equation of Motion: General Plane motion - Problem Solving
160
Consider a lawn roller with a mass of 100 kg, a radius of 0.2 meters, and a radius of gyration of 0.15 meters. A force of 200 N is applied to this roller, angled at 60 degrees from the horizontal plane. What will be the angular acceleration of the lawn roller?
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
160
 01:26
Kinetic Friction
869
Consider a truck trying to pull a stationary car. As the truck exerts a force on the car, static friction is created at the point of contact between the two surfaces. This frictional force resists the car's movement and keeps it at rest. However, when the applied force by the truck surpasses the limiting static frictional force, an interesting phenomenon occurs. The frictional force at the interface reduces to a lower value, known as the kinetic frictional force. At this point, the car...
869
 01:30
Kinematic Equations for Rotation
297
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
297
 01:10
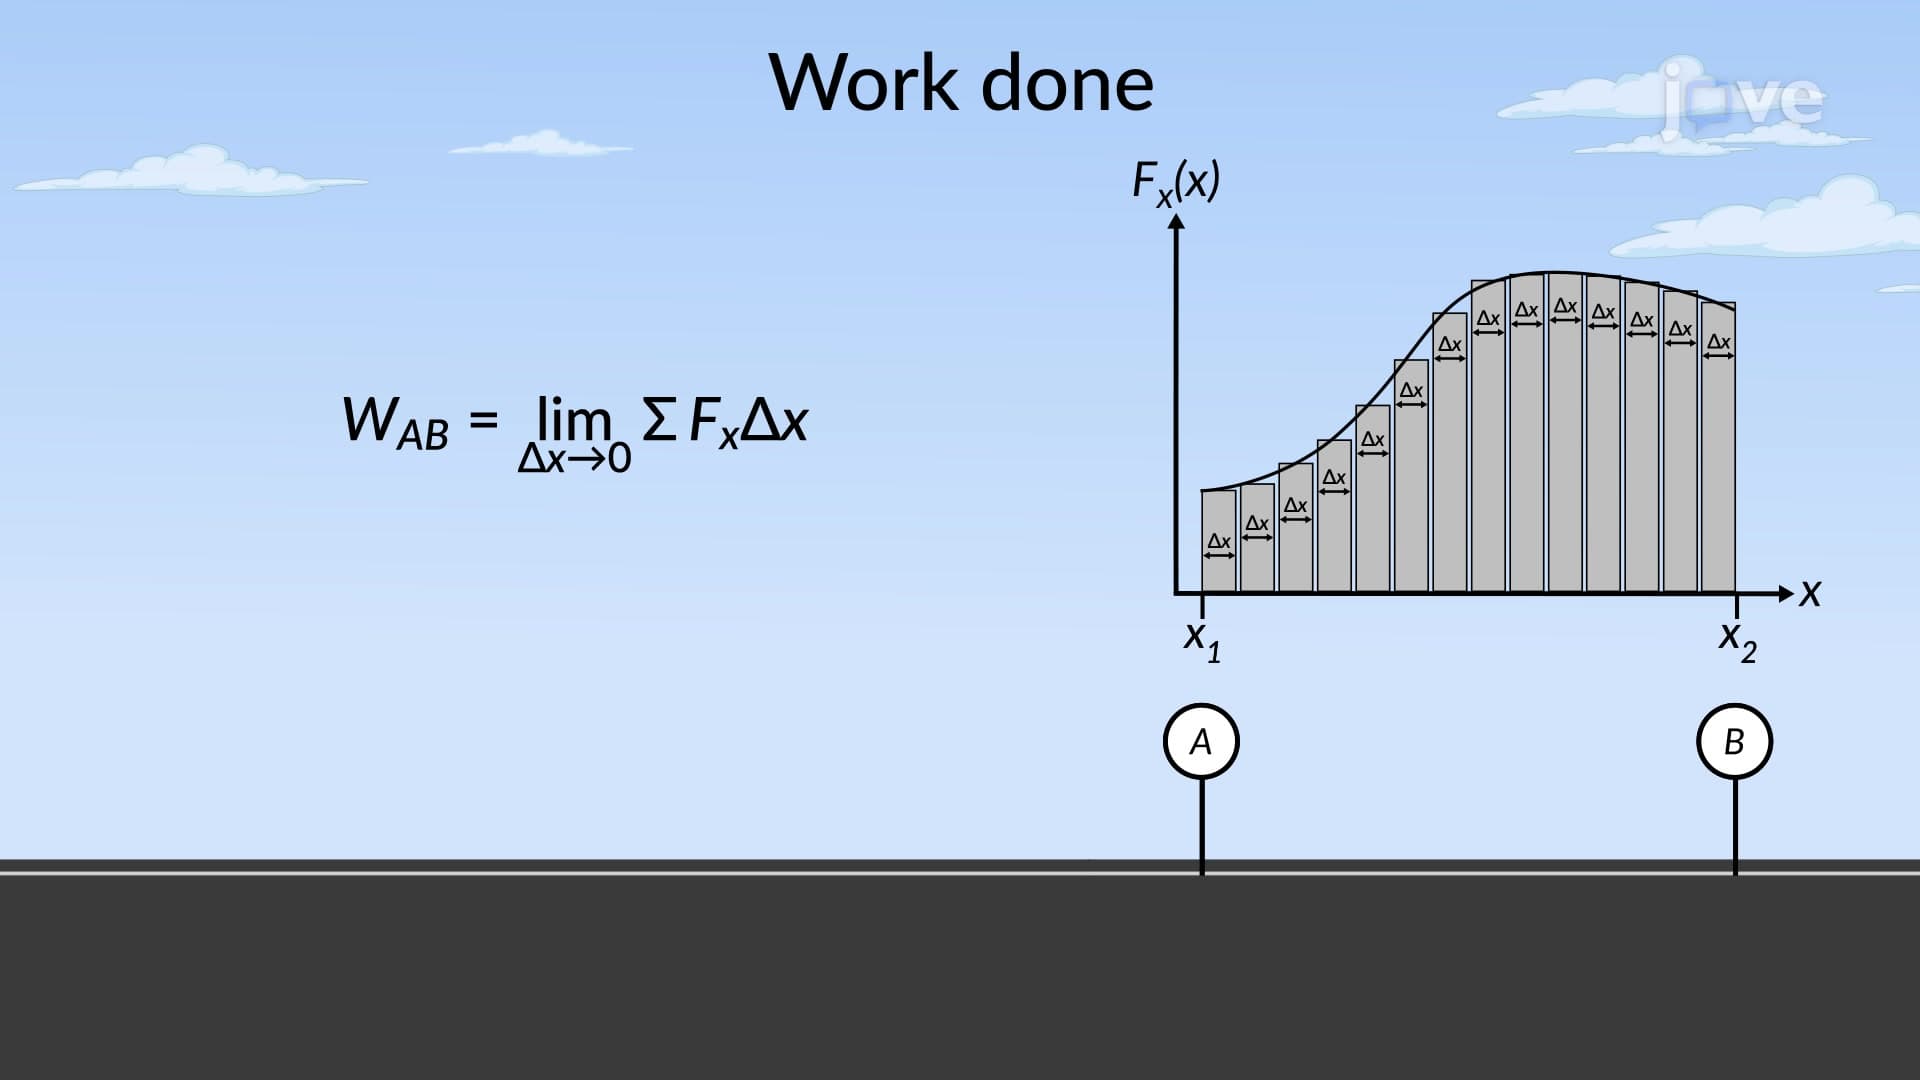
Work and Energy for Variable Forces
3.3K
When an object is acted upon by a variable force, the amount of work done and the change in energy of the object can be more complex to calculate compared to when a constant force is applied. Work is the product of force and displacement, while energy is the capacity of a system to do work. When a constant force is applied to an object, the work done can be calculated as the product of the force and the distance moved in the direction of the force. However, when a variable force is applied, the...
3.3K
 01:15
Kinematic Equations: Problem Solving
11.8K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
11.8K