相关实验视频
Updated: May 12, 2025

10:09

Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
6.5K
非单一的快速预定义时间收滑动模式控制用于建筑机器人
Chun-Wu Yin1, Yun-Peng Ding1, Hou-Jun Sun2
1College of Information and Control Engineering, Xi'an University of Architecture and Technology, Xi'an, Shaanxi 710055, China.
ISA transactions
|April 16, 2025

概括
本研究介绍了一种新的控制策略,用于施工机器人从任何起始角度准确追踪所需的轨迹. 该方法确保了精确的角度跟踪,并减少了控制扭矩的喋喋不休.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统工程 控制系统工程
- 机械工程 机械工程
背景情况:
- 建筑机器人需要精确的轨迹跟踪来完成复杂的任务.
- 现有的控制方法与任意的初始条件作斗争,并确保快速收.
- 控制扭矩喋喋不休是机器人控制中的一个持续的问题.
研究的目的:
- 为工程机器人开发一个强大的控制策略,以实现完整而准确的轨迹跟踪.
- 为不确定的机器人动态设计具有预定义时间收的滑动模式控制器.
- 为了解决机器人轨迹跟踪中任意初始值的挑战.
主要方法:
- 对建筑机器人轨迹跟踪控制特征的分析.
- 建议扩展所需轨迹控制策略,包括到达和精确跟踪阶段.
- 使用改进的非单一快速滑动模式表面和一种新的稳定性标准,设计了一个预定义的时间收滑动模式控制器.
- 整合一个国家观察员加强控制.
主要成果:
- 拟议的算法在指定的时间内实现了角度跟踪错误的趋同到零.
- 证明了原始所需轨迹的完整和准确跟踪.
- 实现了 0.0004 rad 的角度跟踪误差,代表了 33% 的精度改进.
- 成功地缓解了控制扭矩喋喋不休的问题.
结论:
- 开发的控制策略有效地使建筑机器人能够准确地跟踪所需的轨迹,无论初始条件如何.
- 预定义的时间收滑动模式控制器为不确定的机器人系统提供了卓越的性能和稳定性.
- 这些发现有助于提高自动化建筑操作的精度和效率.


相关概念视频
 01:22
Controller Configurations
72
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
72
 01:24
One-Degree-of-Freedom System
439
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
439
 01:30
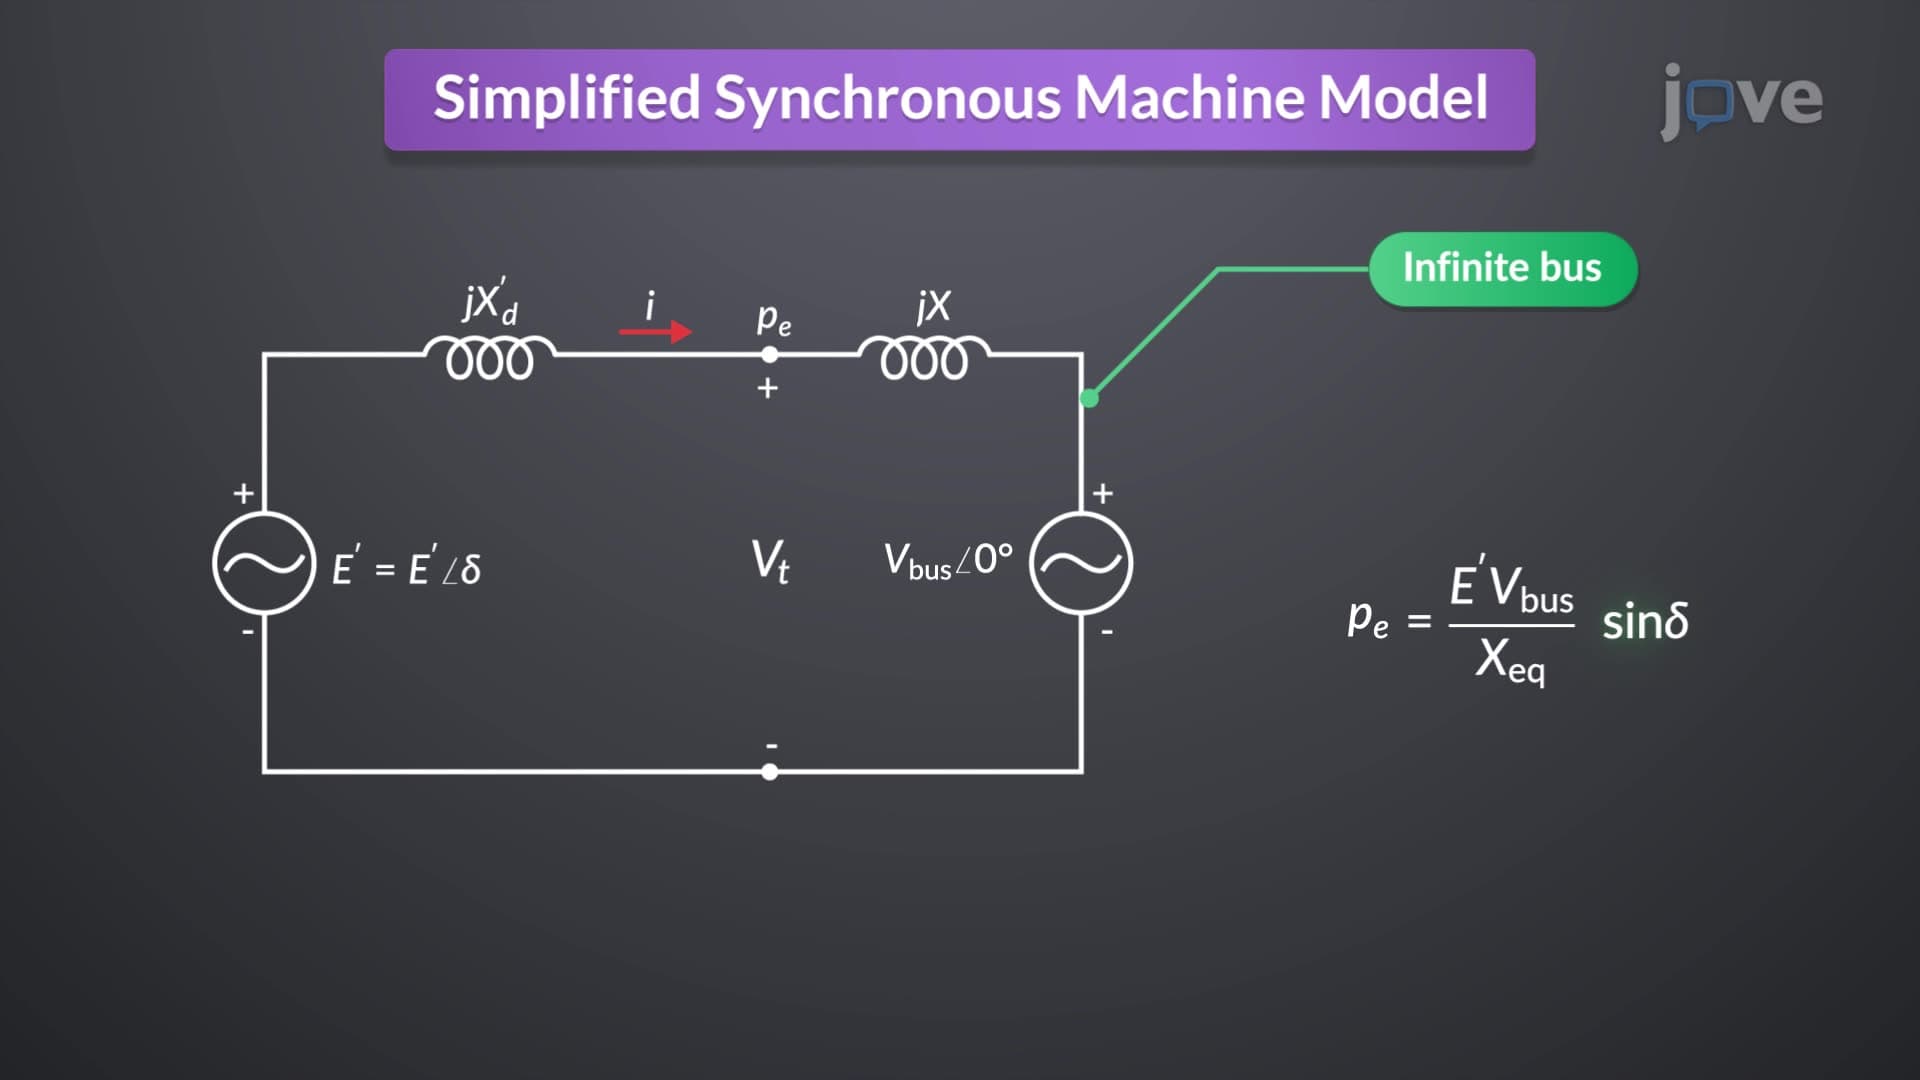
Simplified Synchronous Machine Model
149
The Synchronous Machine Model is a fundamental tool in analyzing and ensuring the transient stability of power systems. This model simplifies the representation of a synchronous machine under balanced three-phase positive-sequence conditions, assuming constant excitation and ignoring losses and saturation. The model is pivotal for understanding the behavior of synchronous generators connected to a power grid, particularly during transient events.
In this model, each generator is connected to a...
In this model, each generator is connected to a...
149
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
374
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
374
 01:17
Open and closed-loop control systems
567
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
567
 01:10
Relative Motion Analysis - Acceleration
313
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
313