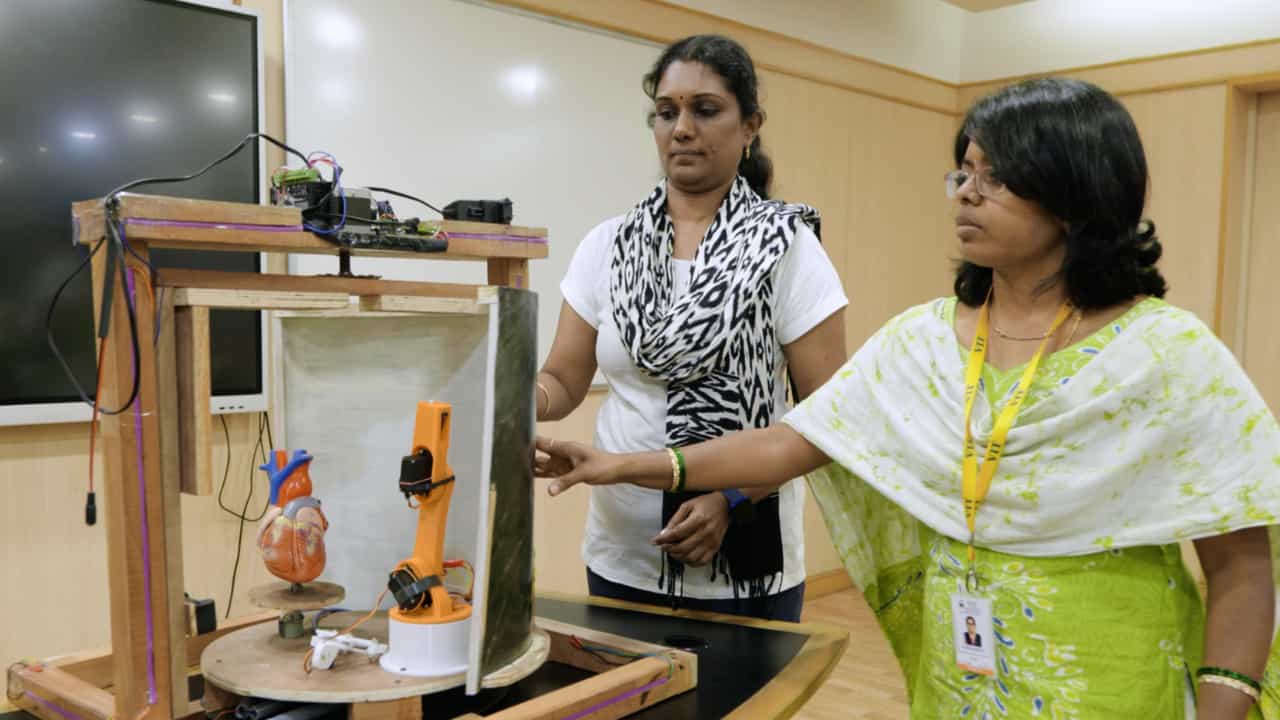
使用2DOF机器人手臂进行视觉控制的自主物体跟踪
Umesh Kumar Sahu1, Mebin K S1, Abhinav K1
1Department of Mechatronics, Manipal Institute of Technology, Manipal Academy of Higher Education, Manipal, Karnataka, 576104, India.
Scientific reports
|April 18, 2025

概括
本研究介绍了一种基于深度学习的系统,用于使用2DOF机器人手臂精确的实时对象跟踪. 基于视觉的控制增强了各种应用的自主功能,提高了准确性和响应时间.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 计算机视觉 计算机视觉
- 人工智能的人工智能
背景情况:
- 使用机器人操纵器实时跟踪对象对于制造业和医疗保健等应用至关重要.
- 传统系统在传感器监控,稳定性和复杂性方面面临挑战.
- 现有的视觉伺服方法有局限性,这项研究旨在克服这些局限性.
研究的目的:
- 为机器人手臂设计一个精确和响应的物体跟踪系统.
- 消除与传统追踪机制相关的复杂性.
- 开发一种基于视觉的自主控制系统,用于移动物体跟踪.
主要方法:
- 基于图像的视觉伺服 (IBVS) 方法用于2度自由度 (DOF) 的机器人手臂.
- 基于深度学习的对象检测框架被用于实时对象识别和定位.
- 设计了一种基于视觉的控制技术,整合了对象检测系统的实时响应.
主要成果:
- 拟议的深度学习控制器在视觉伺服任务中表现出高精度和快速响应时间.
- 使用CoppeliaSim的模拟和使用2DOF机器人臂的实验验证证证了该策略的有效性.
- 该系统成功地自主跟踪移动的物体.
结论:
- 开发的基于深度学习的视觉控制策略为机器人手臂对象跟踪提供了强大的解决方案.
- 该方法通过减少对复杂机制和多个传感器的依赖来简化传统方法.
- 对数据驱动学习技术的进一步探索可以提高控制方案的适应性和稳定性.

相关概念视频
 01:24
One-Degree-of-Freedom System
446
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
446
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
382
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
382
 01:25
Relative Motion Analysis using Rotating Axes
441
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
441
 01:22
Controller Configurations
81
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
81
 01:15
Torque Free Motion
446
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
446
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
316
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
316