

一种动态建模方法,用于控制六度自由度的磁铁轨道平面电机与参考轨迹跟踪
Qi-Yu Hu1, Ze-Qi Lu2,3, Jian-Hua Zhang4
1Shanghai Institute of Applied Mathematics and Mechanics, Shanghai Key Laboratory of Mechanics in Energy Engineering, Shanghai Frontier Science Center of Mechanoinformatics, School of Mechanics and Engineering Science, Shanghai University, Shanghai, 200072, China.
Scientific reports
|April 22, 2025

概括
这项研究引入了磁悬浮平面电机 (MLPM) 的新动态建模方法,以改善6-DOF控制. 这种方法提高了精确的运动控制系统的轨迹跟踪精度.
科学领域:
- 机械电子和控制系统
- 电磁和磁悬浮是电磁和磁悬浮的重要组成部分.
背景情况:
- 磁悬浮平面电机 (MLPM) 提供高精度定位,但由于复杂的非线性动力学限制了6度自由度 (6-DOF) 控制,因此面临挑战.
- 现有的控制方法在MLPM中与固有的非线性和合效应作斗争,阻碍了最佳性能.
研究的目的:
- 为MLPMs开发一个强大的6DOF动态建模方法,以增强参考轨迹跟踪.
- 建立一个统一的控制框架,以解决动力学非线性和全DOF合效应,以提高精度.
主要方法:
- 一种结合磁流分析线性化和电磁合场脱的新方法,用于统一控制.
- 波谱分析和双参考坐标转换用于精确的电磁力/扭矩分布分析.
- 使用数值模拟和实验装置进行开发和验证.
主要成果:
- 与传统方法相比,在大曲率旋转下,实现了5.3倍降低关预测错误.
- 验证了改进的建模精度和稳定性,用于高精度的运动控制和长冲程轨迹跟踪.
- 实验结果证实了拟议的理论轨迹跟踪方法的有效性.
结论:
- 拟议的动态建模方法显著提高了MLPM中6-DOF控制的精度和稳定性.
- 这项研究弥合了理论建模和先进的磁悬浮系统的工业应用之间的差距.
- 这些发现为开发下一代高精度定位系统提供了宝贵的见解.


相关概念视频
 01:24
One-Degree-of-Freedom System
436
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
436
 01:21
Linear Approximation in Time Domain
56
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
56
 01:13
Linear Momentum in Control Volume
620
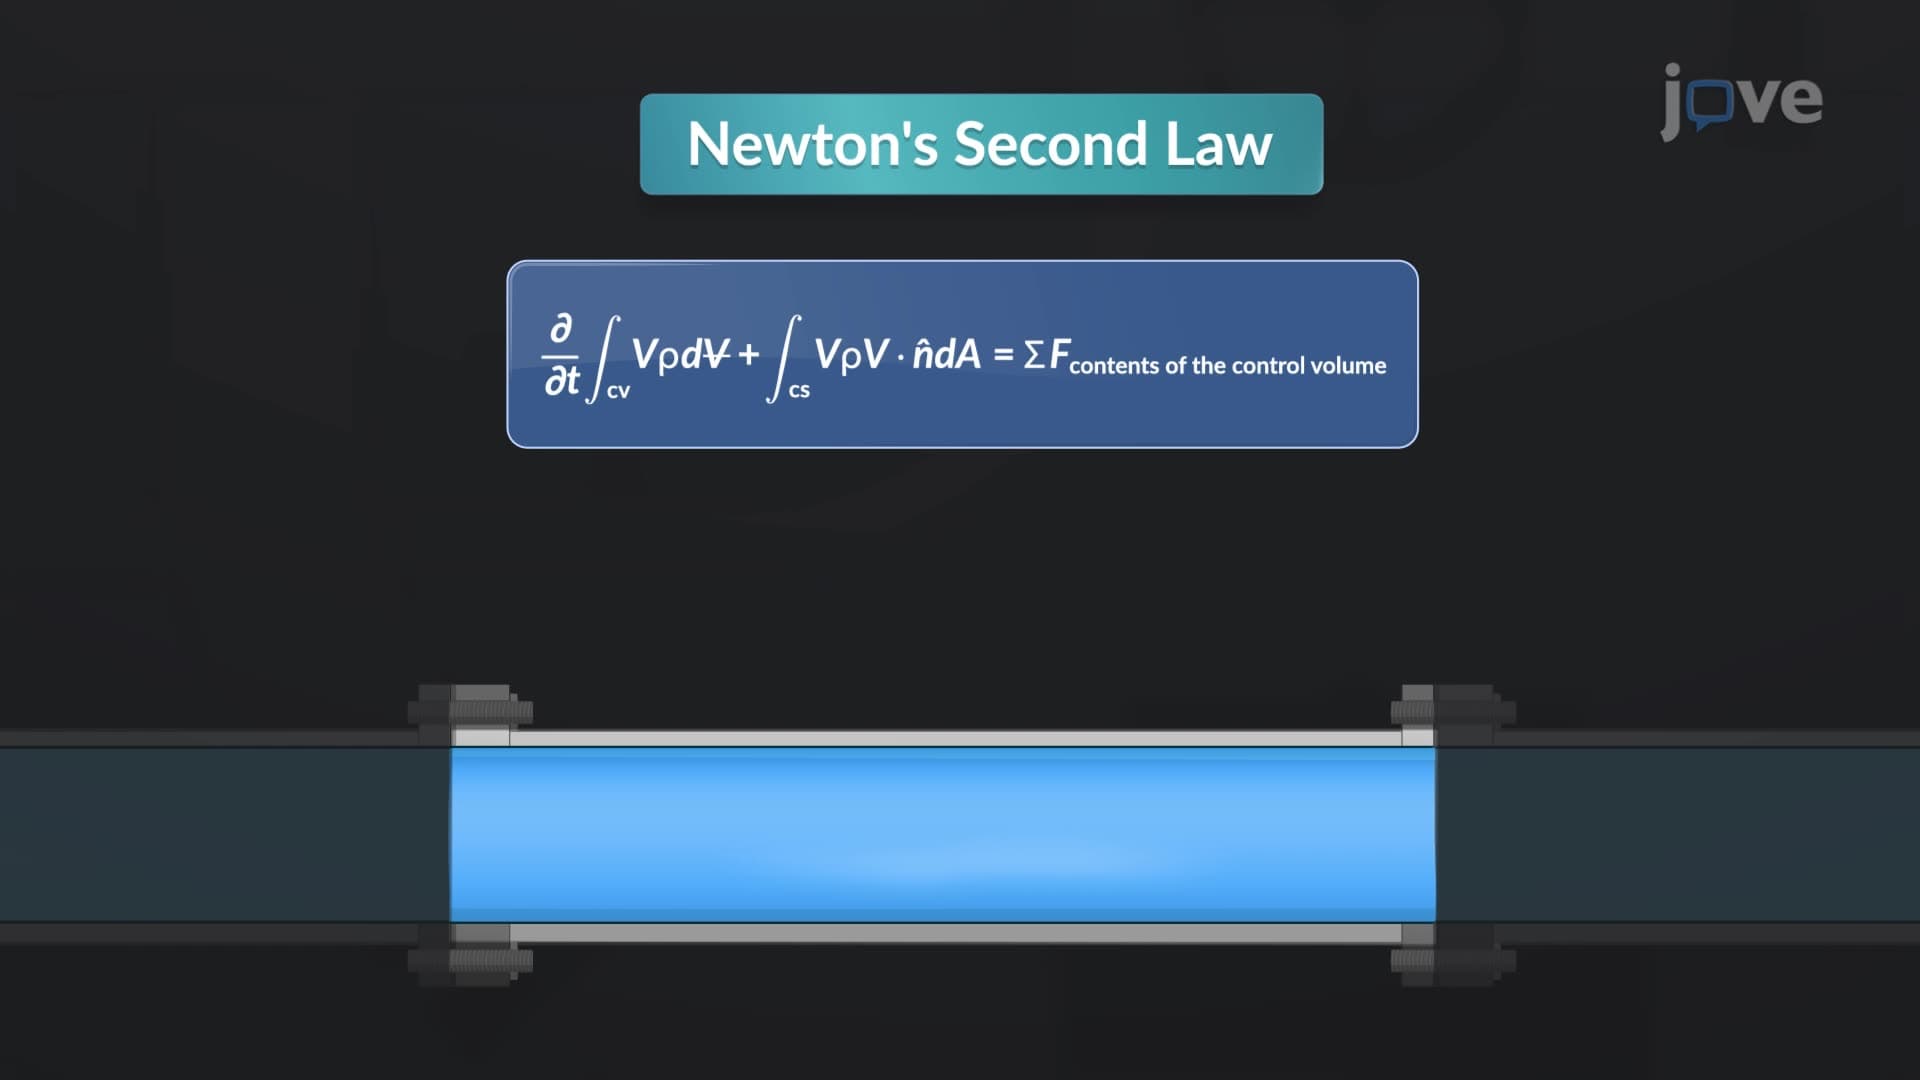
Newton's second law is applied to obtain the linear momentum in a control volume in a fluid system. According to this law, the rate of change of linear momentum is equal to the sum of external forces acting on the system. When a control volume matches the fluid system at a specific moment, the forces acting on both are identical. Reynolds transport theorem helps explain this by breaking down the system's linear momentum into two components: the rate of change of linear momentum within...
620
 01:15
Kinematic Equations: Problem Solving
11.7K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
11.7K
 01:16
Equation of Motion: General Plane motion - Problem Solving
159
Consider a lawn roller with a mass of 100 kg, a radius of 0.2 meters, and a radius of gyration of 0.15 meters. A force of 200 N is applied to this roller, angled at 60 degrees from the horizontal plane. What will be the angular acceleration of the lawn roller?
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
159
 01:30
Three-Dimensional Force System:Problem Solving
577
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
577