

冗余执行-4R符合并行指向机制的运动静态建模和工作空间分析
Jun Ren1, Yikang Shu1, Youwei Lin1
1Hubei Key Laboratory of Modern Manufacturing Quantity Engineering, School of Mechanical Engineering, Hubei University of Technology, Wuhan 430068, China.
Micromachines
|April 26, 2025

概括
冗余驱动显著提高了符合标准的并行指向机制 (CPPM) 的工作空间. 这种方法可以扩大和对称工作空间,增加100%的运动范围,并实现3D运动.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 机械工程 机械工程
- 合规机制 合规机制
背景情况:
- 合规并行机制 (CPPM) 由于灵活的链约束,工作空间有限.
- 微/纳米尺度的柔性链限制了变形范围,阻碍了性能.
研究的目的:
- 为了优化2-自由度 (2-DOF) n-4R CPPMs的工作空间性能.
- 通过冗余执行来最大限度地扩大工作空间.
主要方法:
- 对于冗余执行的n-4R CPPM,已建立的动静态和灵活的链位移模型.
- 使用有限元 (FE) 模拟与空间指向轨迹对准动静态模型的准确性.
- 通过冗余执行,优化了3-4R和4-4R CPPM 的工作空间性能.
主要成果:
- 在分析和FE结果之间实现了高一致性 (误差<2.1%),证实了模型的准确性.
- 与非冗余情况下相比,通过冗余执行证明了显著的工作空间扩大和对称.
- 观察到最大俯仰角和y方向运动范围的100%增加.
- 展示了从平面到3D工作空间形状的过渡.
结论:
- 冗余执行是扩大n-4R CPPM的工作空间的有效策略.
- 非冗余系统的工作空间是冗余执行系统的工作空间的一个子集.
- 这种优化使得微/纳米级应用程序中的增强指点功能成为可能.


相关概念视频
 01:15
Kinematic Equations: Problem Solving
11.7K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
11.7K
 01:23
Simplification of a Force and Couple System: II
239
In a three-dimensional system, multiple forces can act on an object. These forces can be combined into a single equivalent force, known as the resultant force. Similarly, the moments generated by these forces can be combined into a single equivalent moment, the resultant couple moment. In certain situations, these two entities may not be mutually perpendicular, meaning they do not have a 90-degree angle between them. This unique condition requires a deeper understanding of the interplay between...
239
 01:30
Three-Dimensional Force System:Problem Solving
577
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
577
 01:06
Virtual Work for a System of Connected Rigid Bodies
345
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
345
 01:14
Stability of structures
147
In mechanical engineering, the stability of systems under various forces is critical for designing durable and efficient structures. One fundamental way to explore these concepts is by analyzing systems like two rods connected at a pivot point, O, with a torsional spring of spring constant k at the pivot point. This system is similar in appearance to a scissor jack used to change tires on a car. In this case, the arms of the linkage (equivalent to the rods in this system) are entirely vertical,...
147
 01:30
Free-body Diagrams: Problem Solving
543
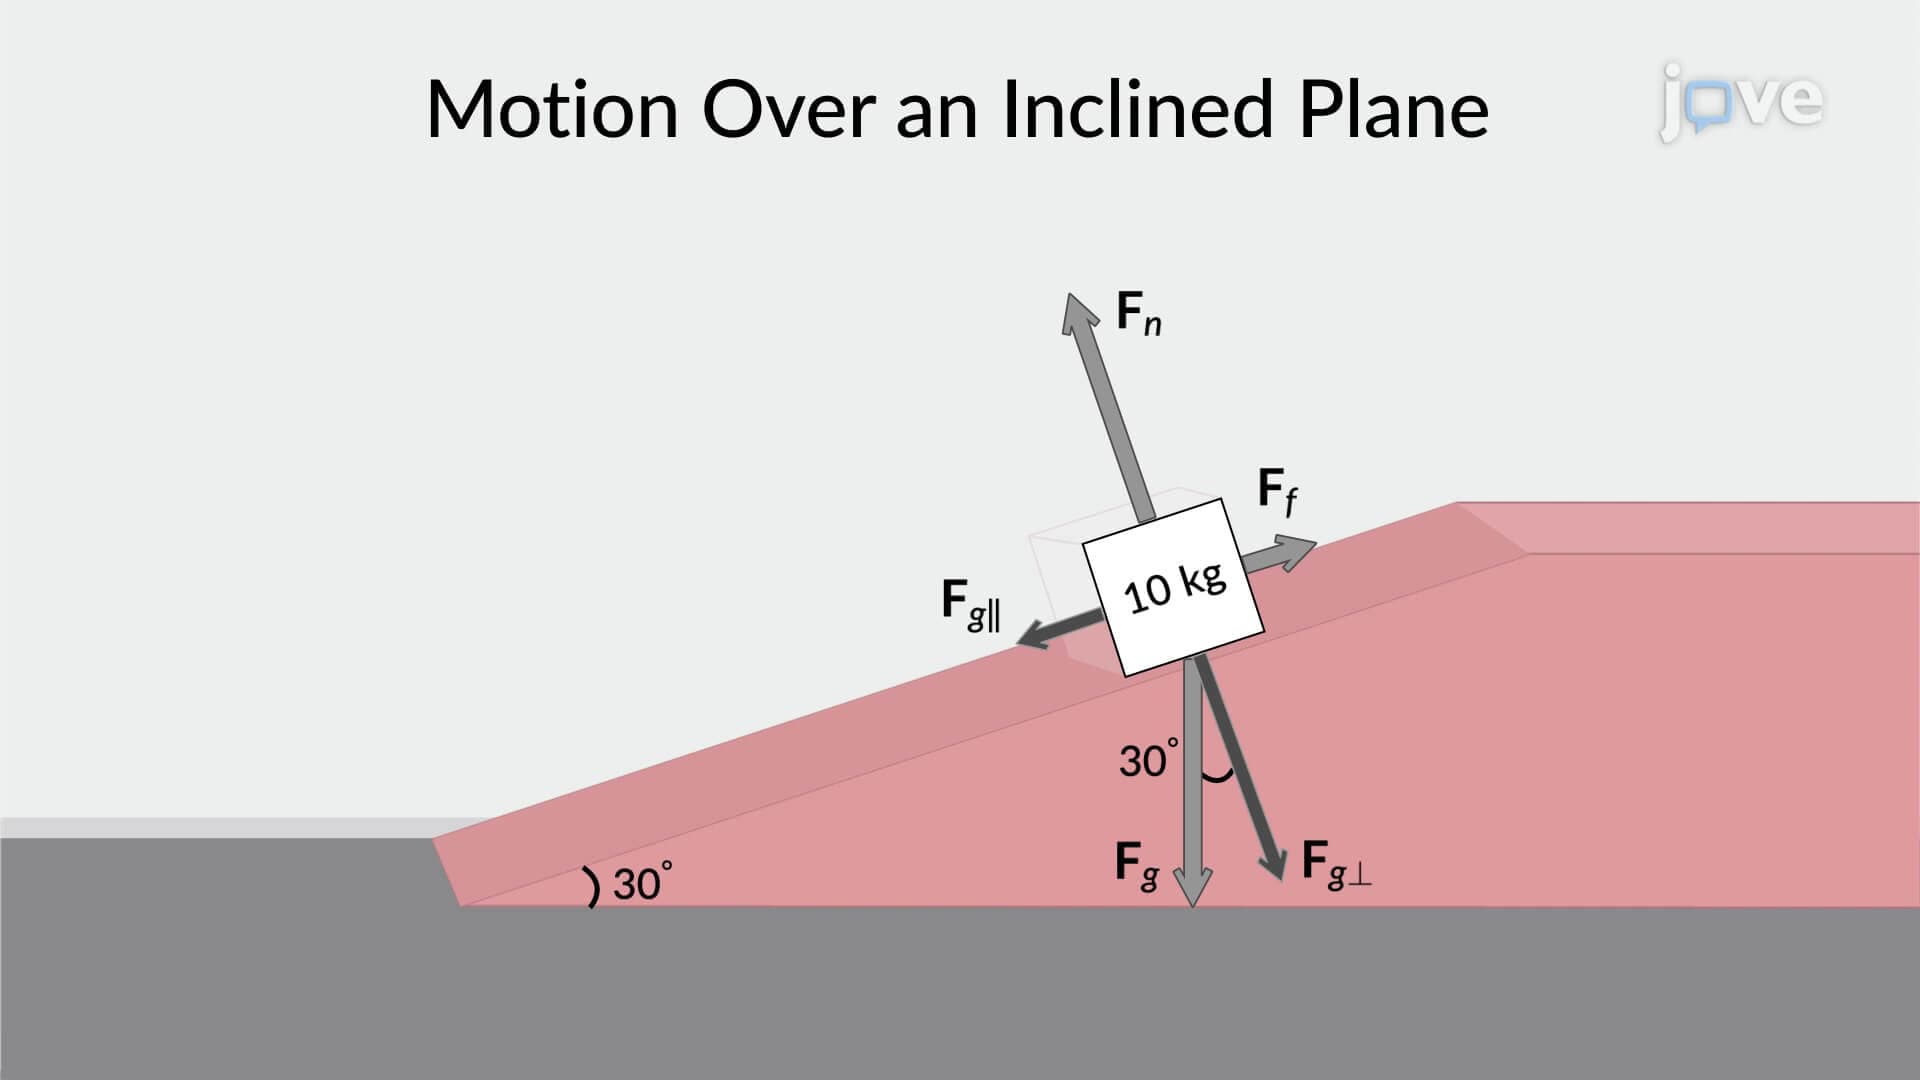
Free-body diagrams are essential tools for physicists and engineers studying the motion of objects. Free-body diagrams are graphical representations of the object or system under consideration, and they focus solely on the essential forces acting on the object. This tool helps break down complex problems into simpler models that are easier to understand and solve.
For example, consider a block with a mass of 10 kg released on an inclined plane at an angle of 30° to the horizontal, where...
For example, consider a block with a mass of 10 kg released on an inclined plane at an angle of 30° to the horizontal, where...
543