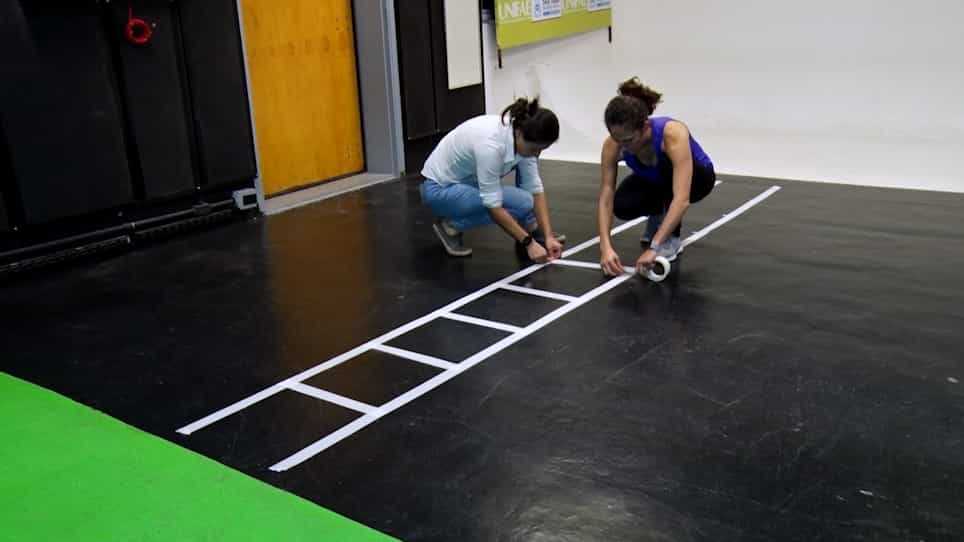

A-frame和之前的跳跃之间的距离改变对敏捷犬前肢动态的影响
Claire Bidwell1, Scott Blake1, David Marlin2
1Anglia Ruskin University, Agriculture, animal and Environmental Sciences School, Lordship Road, Chelmsford CM1 3RR, United Kingdom.
Veterinary journal (London, England : 1997)
|April 26, 2025

概括
当A框架障碍物之前跳出更远的距离时,狗敏捷犬的伤害较少. 这项研究发现,障碍物之间的5米距离可以缓和速度和减速,从而减少前肢受伤.
科学领域:
- 狗的生物力学 狗的生物力学
- 兽医运动医学 兽医运动医学
- 动物的运动 动物的运动.
背景情况:
- A-frame障碍物是狗灵活性中受伤的常见原因之一.
- 有限的研究存在于导航A的狗的生物力学.
- 了解前面的障碍距离对A-frame性能的影响对于预防伤害至关重要.
研究的目的:
- 在A框架上研究敏捷犬的动力学和动力学.
- 分析先前跳跃和A框架之间的不同距离对狗表现的影响.
- 为了确定与狗的A-frame相关伤害相关的生物力学因素.
主要方法:
- 使用惯性测量单元和视频分析记录了6只敏捷犬.
- 狗在10米,7.5米和5米的距离跳跃后穿过A框.
- 收集的数据包括速度,加速度,减速,手腕超延伸和峰值垂直力.
主要成果:
- 跨越距离时,没有观察到手腕超延伸或垂直力峰值的显著差异.
- 最大接近速度,加速和减速随着距离A-frame的距离减少而减少.
- 与10米距离相比,障碍物之间的5米距离显著降低了速度和改变了减速模式.
结论:
- 前一个跳跃和A框架之间的距离会影响狗的接近动态.
- 较短距离 (5米) 的减速可能是前肢受伤的一个因素.
- 将障碍物距离更远可以帮助减轻敏捷犬的受伤风险,为基于证据的指导方针提供进一步研究.
相关概念视频
 01:10
Relative Motion Analysis - Acceleration
313
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
313
 01:16
Hydraulic Jump: Problem Solving
29
To analyze a hydraulic jump in a rectangular channel with a flow speed of 6 meters per second, follow these steps:Calculate Effective Upstream Velocity:When the downstream gate closes, a hydraulic jump forms, traveling upstream at 2 meters per second. This wave speed combines with the initial channel flow velocity, creating an effective upstream velocity.Identify Flow Velocities Before and After the Hydraulic Jump:Upstream of the hydraulic jump, the effective flow velocity includes both the...
29
 01:24
Relative Motion Analysis - Velocity
328
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
328
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
310
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
310
 01:04
Social Facilitation
31.5K
Not all intergroup interactions lead to negative outcomes. Sometimes, being in a group situation can improve performance. Social facilitation occurs when an individual performs better when an audience is watching than when the individual performs the behavior alone. This typically occurs when people are performing a task for which they are skilled.
31.5K