

在猛禽的拉出动作期间,用于提升升高的大型动态投
Erwin R Gowree1, Joao Dinis Tome2, Alejandro Dominguez Escamilla2
1Department of Aerodynamics, Energy and Propulsion, ISAE-SUPAERO, Toulouse, France. erwin-ricky.gowree@isae-supaero.fr.
Scientific reports
|April 30, 2025

概括
猛禽在拉升机动中通过动态投来实现高起重,超过静态条件. 在实时实验和模拟中观察到的这一发现,可能会激发新的飞行器设计.
科学领域:
- 空气动力学 在空气动力学.
- 生物启发的工程是生物启发的工程.
- 流体力学的流体力学
背景情况:
- 猛禽在拉动动作时需要高升力系数,超过静态投球能力.
- 像游牧猎这样的掠食鸟上空的流动,以大型旋转结构为特征.
研究的目的:
- 为了研究猛禽拉升机动中高起重生成背后的机制.
- 为了证明动态投在实现高提升系数方面的作用.
- 探索自然启发的自主飞行器的潜在应用.
主要方法:
- 计算流体动力学 (CFD) 模拟使用直接数值模拟 (DNS) 和格子-博尔兹曼法 (LBM).
- 不稳定的雷诺兹平均纳维埃-斯托克斯 (URANS) 模拟.
- 在静态模型上对实体实验和风洞研究数据的分析.
主要成果:
- 在拉升过程中动态投球显著增加了与静态条件相比的升力系数.
- 高提升是通过动态投来实现的,以满足在负载因子大于1的条件下的要求.
- 在三角洲翼模型上的模拟复制了猛禽中观察到的旋流结构.
结论:
- 猛禽很可能使用动态投来产生必要的高起重力在拉升机动.
- 这种以前与自然观测无关的生物机制,为设计先进的空中系统提供了洞察力.
- 这些发现可以为开发能够高G机动的以自然为灵感的自主飞行器提供信息.
相关概念视频
 01:23
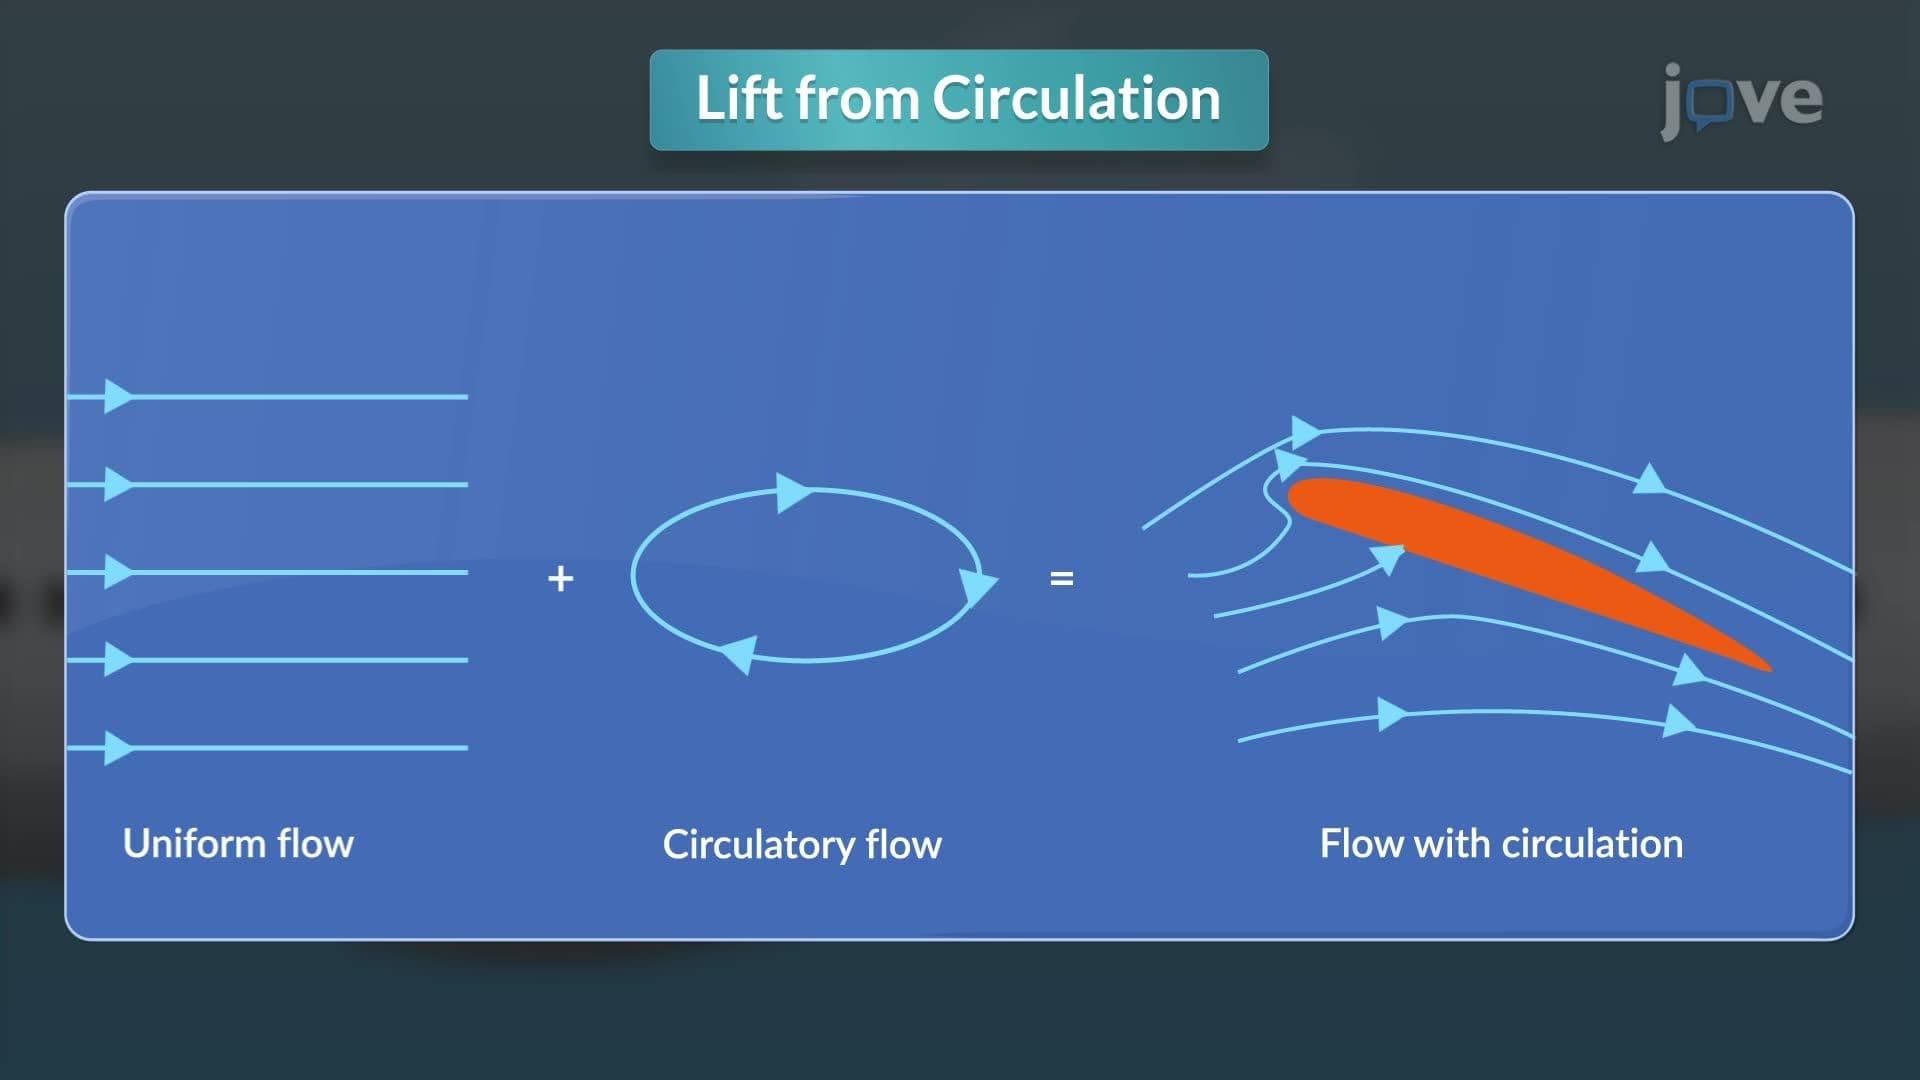
Lift
32
Lift is a fundamental aerodynamic force that acts perpendicular to the direction of airflow. It plays a central role in achieving and sustaining flight and in stabilizing various vehicles. Lift primarily originates from pressure differences created across surfaces, such as an airfoil. A lower pressure region forms above the wing, while a higher pressure region forms below it, generating an upward force. This differential results from the shape and orientation of the airfoil, enabling the wing...
32
 01:24
Absolute Motion Analysis- General Plane Motion
193
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
193
 00:48
Optimal Foraging
11.8K
How animals obtain and eat their food is called foraging behavior. Foraging can include searching for plants and hunting for prey and depends on the species and environment.
11.8K
 01:26
Impact: Problem Solving
199
In an experiment conducted during a Mars mission, a rover propels a projectile with an initial velocity, and the projectile rebounds after colliding with the Martian surface. To ascertain the maximum height attained by the projectile after this collision, the known restitution coefficient and acceleration due to gravity are employed.
By designating the launch point as the origin and utilizing kinematic equations, the vertical component of the projectile's velocity at the point of impact is...
By designating the launch point as the origin and utilizing kinematic equations, the vertical component of the projectile's velocity at the point of impact is...
199
 01:54
Convergent Evolution
27.1K
Evolution shapes the features of organisms over time, ensuring that they are suited for the environments in which they live. Sometimes, selection pressure leads to the rise of similar but unrelated adaptations in organisms with no recent common ancestors, a process known as convergent evolution.
27.1K
 01:17
Dynamics Of Circular Motion: Applications
7.6K
Suppose a car moves on flat ground and turns to the left. The centripetal force causing the car to turn in a circular path is due to friction between the tires and the road. For this, a minimum coefficient of friction is needed, or the car will move in a larger-radius curve and leave the roadway. Let's now consider banked curves, where the slope of the road helps in negotiating the curve. The greater the angle of the curve, the faster one can take the curve. It is common for race tracks for...
7.6K