
在振荡器中具有非线性缓冲奇点和指数项的自持和混乱的振荡与外游和不对称性
L-S Banga1,2, R Mboyo Kouayep1,3, J M'Boliguipa2
1Laboratory of Modeling and Simulation in Engineering, Biomimetics and Prototypes, and TWAS Research Unit, Department of Physics, Faculty of Science, University of Yaoundé I, Box 812, Yaoundé, Cameroon.
Chaos (Woodbury, N.Y.)
|May 2, 2025

概括
这项研究探讨了非线性微分方程,揭示了缓冲项中的奇点可以意外地产生混乱的动态. 使用微控制器的实验证实了非线性振荡器中的这些发现.
科学领域:
- 非线性动力学是一种非线性动力学.
- 混沌理论 混沌理论
- 电气工程 电气工程
背景情况:
- 非线性振荡器在各种科学领域具有根本性的作用.
- 了解复杂的动态,包括混乱,对于预测系统行为至关重要.
- 现有的模型往往简化了缓冲术语,可能错过了重要的现象.
研究的目的:
- 为了研究二次非线性微分方程的动力学,使用新的缓解术语.
- 通过阻尼中的奇点来探索混乱行为的产生.
- 使用微控制器实验验证理论预测.
主要方法:
- 用理性缓解 (奇点) 和指数式缓解项对非线性微分方程的理论分析.
- 使用带有离散电气元件和微控制器的混合电路进行实验实施.
- 对系统动态的观察和分析,包括混乱的行为和振荡.
主要成果:
- 理性缓冲条件中的奇点可以诱导混乱的动态,甚至在自主系统中.
- 指数式缓解术语导致不对称的自我维持的振荡和混乱的动态.
- 使用基于微控制器的电路的实验结果证实了理论预测.
结论:
- 缓冲项中的奇点代表了在非线性系统中产生混乱的新机制.
- 该研究引入了一种独特的混合电路方法,用于非线性动力学研究.
- 这些发现为非线性振荡器的复杂行为提供了新的见解.
相关概念视频
 01:20
Types of Damping
6.3K
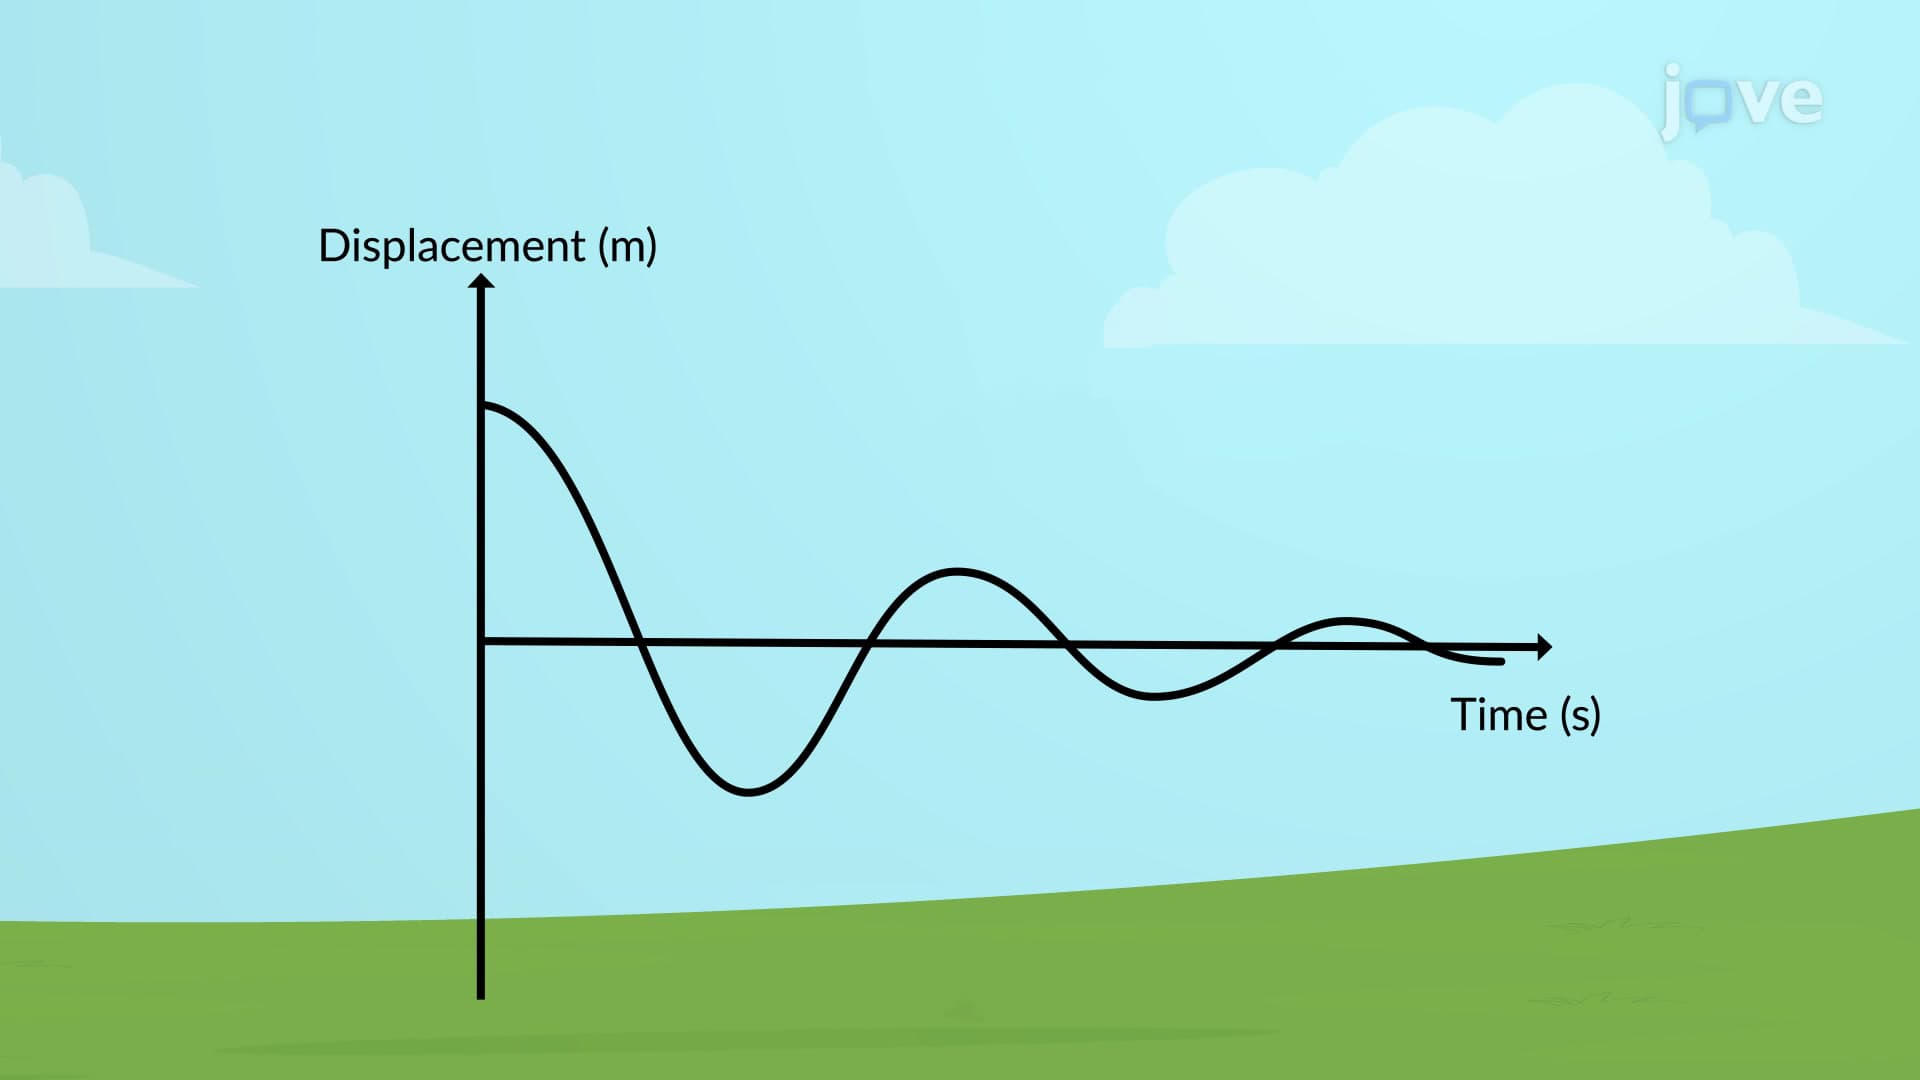
If the amount of damping in a system is gradually increased, the period and frequency start to become affected because damping opposes, and hence slows, the back and forth motion (the net force is smaller in both directions). If there is a very large amount of damping, the system does not even oscillate; instead, it slowly moves toward equilibrium. In brief, an overdamped system moves slowly towards equilibrium, whereas an underdamped system moves quickly to equilibrium but will oscillate about...
6.3K
 01:07
Damped Oscillations
5.6K
In the real world, oscillations seldom follow true simple harmonic motion. A system that continues its motion indefinitely without losing its amplitude is termed undamped. However, friction of some sort usually dampens the motion, so it fades away or needs more force to continue. For example, a guitar string stops oscillating a few seconds after being plucked. Similarly, one must continually push a swing to keep a child swinging on a playground.
Although friction and other non-conservative...
Although friction and other non-conservative...
5.6K
 01:06
Forced Oscillations
6.4K
When an oscillator is forced with a periodic driving force, the motion may seem chaotic. The motions of such oscillators are known as transients. After the transients die out, the oscillator reaches a steady state, where the motion is periodic, and the displacement is determined.
6.4K
 01:04
Oscillations about an Equilibrium Position
5.2K
Stability is an important concept in oscillation. If an equilibrium point is stable, a slight disturbance of an object that is initially at the stable equilibrium point will cause the object to oscillate around that point. For an unstable equilibrium point, if the object is disturbed slightly, it will not return to the equilibrium point. There are three conditions for equilibrium points—stable, unstable, and half-stable. A half-stable equilibrium point is also unstable, but is named so...
5.2K
 01:12
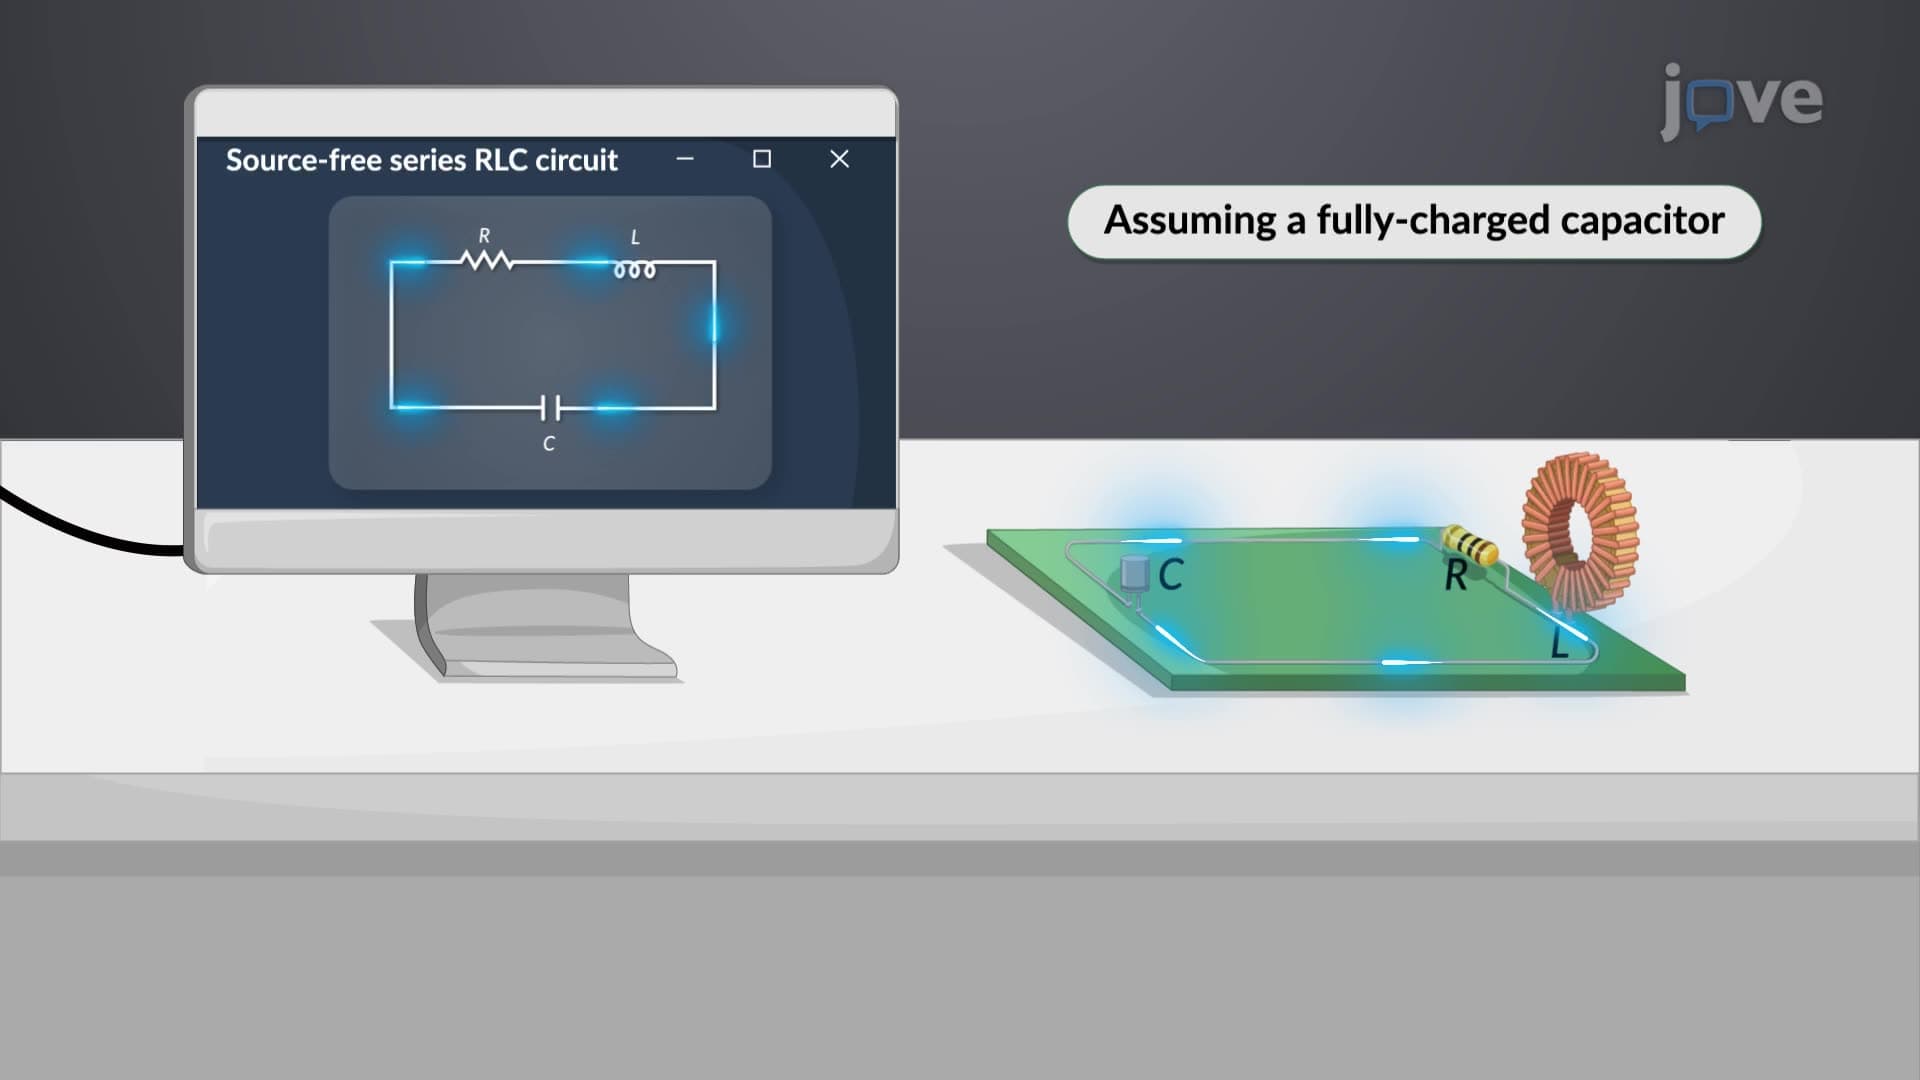
Types of Responses of Series RLC Circuits
729
A second-order differential equation characterizes a source-free series RLC circuit, marking its distinct mathematical representation. The complete solution of this equation is a blend of two unique solutions, each linked to the circuit's roots expressed in terms of the damping factor and resonant frequency.
729
 01:18
Second Order systems II
62
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
62