使用对立式学习曲线的图像镜头闪光灯去除

概括
这项研究通过改进图像处理管道和开发用于恢复多个光源的新策略来增强镜头耀斑的去除. 这项研究确保了在各种设备上更好的概括性,从而提高了图像质量.
科学领域:
- 计算机视觉 计算机视觉
- 图像处理 图像处理
- 深度学习 (Deep Learning) 是一种深度学习.
背景情况:
- 不同质的闪光灯工件降低了图像质量,并影响了计算机视觉任务.
- 综合训练数据以消除闪光灯是具有挑战性的,因为目前的方法存在局限性,例如忽视图像信号处理管道 (ISP) 中的自动曝光和音调映射.
- 现有的光源回收方法与具有不同特性的多个光源作斗争.
研究的目的:
- 通过重新访问ISP和增强合成管道来提高镜片闪光灯去除性能.
- 开发一种更可靠的策略来回收多个光源.
- 为了提高深度耀斑移除模型在不同设备上的概括能力.
主要方法:
- 重新审视ISP,并在合成管道中重塑自动曝光原则.
- 实施新的光源回收策略,使用基于照度水平的凸平均值.
- 采用对抗曲线学习 (ACL) 范式,在各种摄像机ISP之间进行更好的概括.
主要成果:
- 拟议的管道通过区分局部和全球照明来产生更现实的图像,防止转移和过度和.
- 该ACL范式增强了模型的概括性,克服了设备特定ISP的局限性.
- 新的光源回收策略有效地处理多个光源,没有硬值.
结论:
- 开发的解决方案显著提高了镜头闪光灯去除性能.
- 这种方法使得该领域在处理更一般的成像情况方面取得了进展.
- 引入了一个新的数据集,用于在各种消费电子产品中测试闪光灯移除泛化.
相关概念视频
 01:16
Focusing of Light in the Eye
1.5K
Light rays enter the eye through the cornea, a transparent dome-shaped tissue that is the eye's outermost layer. The cornea bends or refracts, light rays traveling to the pupil. The shape of the cornea determines how much of the light is bent and whether the image will be focused correctly on the retina at the back of the eye. Once the light has passed through both refraction layers, it converges into a single focal point onto a small area. This is where photoreceptors start transforming...
1.5K
 01:17
Curve Equations
18
Curves are essential geometric elements characterized by tangent distance, chord length, middle ordinate, and total arc length. These measurements are crucial in understanding a curve's geometric and spatial properties and are defined by the relationship between its radius and its central angle.The tangent distance (T) refers to the straight-line measurement from the intersection point of two tangents to either the start or end of the curve. This distance is influenced by the curve's radius (R)...
18
 01:29
Sight Distance in a Vertical Curve
15
Sight distance on vertical curves is critical in roadway design. It ensures drivers can see far enough ahead to identify and respond to hazards effectively. This directly impacts safety, driver comfort, and the overall efficiency of the transportation network.Vertical curves are classified into crest and sag curves based on their geometry. For crest curves, sight distance is determined by the line of sight between a driver's eye and a small object on the road's surface. Design parameters for...
15
 01:20
Calibration Curves: Linear Least Squares
1.1K
A calibration curve is a plot of the instrument's response against a series of known concentrations of a substance. This curve is used to set the instrument response levels, using the substance and its concentrations as standards. Alternatively, or additionally, an equation is fitted to the calibration curve plot and subsequently used to calculate the unknown concentrations of other samples reliably.
For data that follow a straight line, the standard method for fitting is the linear...
For data that follow a straight line, the standard method for fitting is the linear...
1.1K
 01:23
Curvilinear Motion: Rectangular Components
359
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
359
 01:27
Curvilinear Motion: Normal and Tangential Components
354
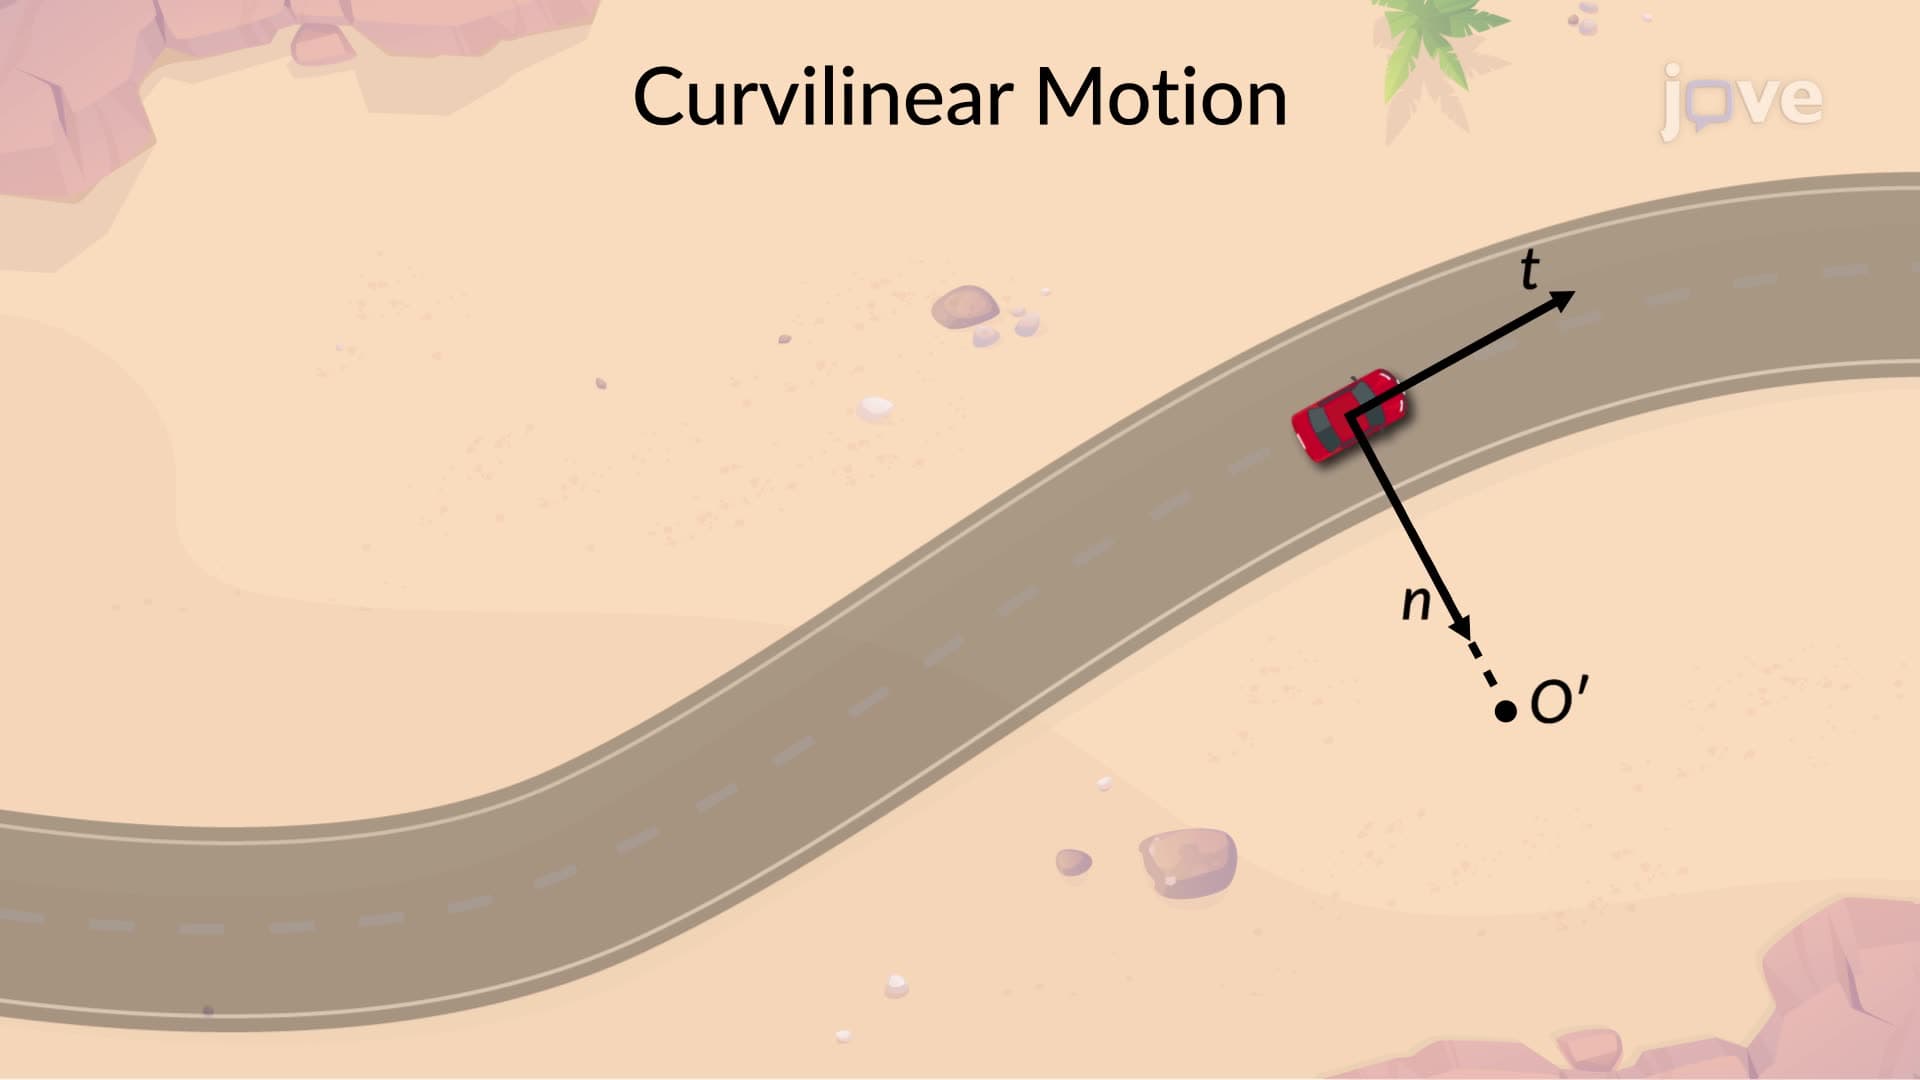
When a car traverses a curved road, its motion can be elucidated by breaking it down into tangential and normal components. The car-centric coordinates attached to the vehicle move with it.
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
354