
对于具有动态不稳定的预测同化过程的指数稳定性
Dan Crisan1, Michael Ghil1,2, Rohan Nuckchady1
1Department of Mathematics, Imperial College London, London SW7 2AZ, United Kingdom.
Chaos (Woodbury, N.Y.)
|May 8, 2025

概括
本研究分析了预测同化 (FA) 过程的稳定性,这对于准确的预测至关重要. 我们发现了条件,即使在动态不稳定和初始条件错误的情况下,也确保了FA的稳定性.
科学领域:
- 数据同化数据同化
- 计算数学是指计算数学.
- 动态系统是动态系统.
背景情况:
- 数据同化将观测数据集成到计算模型中,以便准确预测.
- 数字天气预测在很大程度上依赖于数据同化过程.
- 这些过程的稳定性至关重要,特别是当系统动态不稳定时.
研究的目的:
- 将预测同化 (FA) 过程概念化为一个动态-随机系统.
- 为了研究FA过程的稳定性,关于初始条件变化.
- 在线性和非线性动态下确定FA过程稳定性的条件.
主要方法:
- 线性和非线性动态-随机系统的分析.
- 在非线性动力学分析中应用指数半组.
- 使用Kallianpur-Striebel公式进行线性动力学分析.
主要成果:
- 在线性和非线性动态下确定FA过程稳定性的条件.
- 证明了对非线性动力学预期的瓦瑟斯坦距离的时间约束均.
- 证明了线性动态的弱和瓦瑟斯坦拓收.
结论:
- 尽管动态不稳定和初始条件错误,但FA过程可以保持稳定.
- 正确和不正确初始化的FA过程之间的瓦斯斯坦距离在特定条件下以指数级快速收.
- 这项研究为了解FA过程稳定性提供了严格的框架.
相关概念视频
 01:28
Stability
67
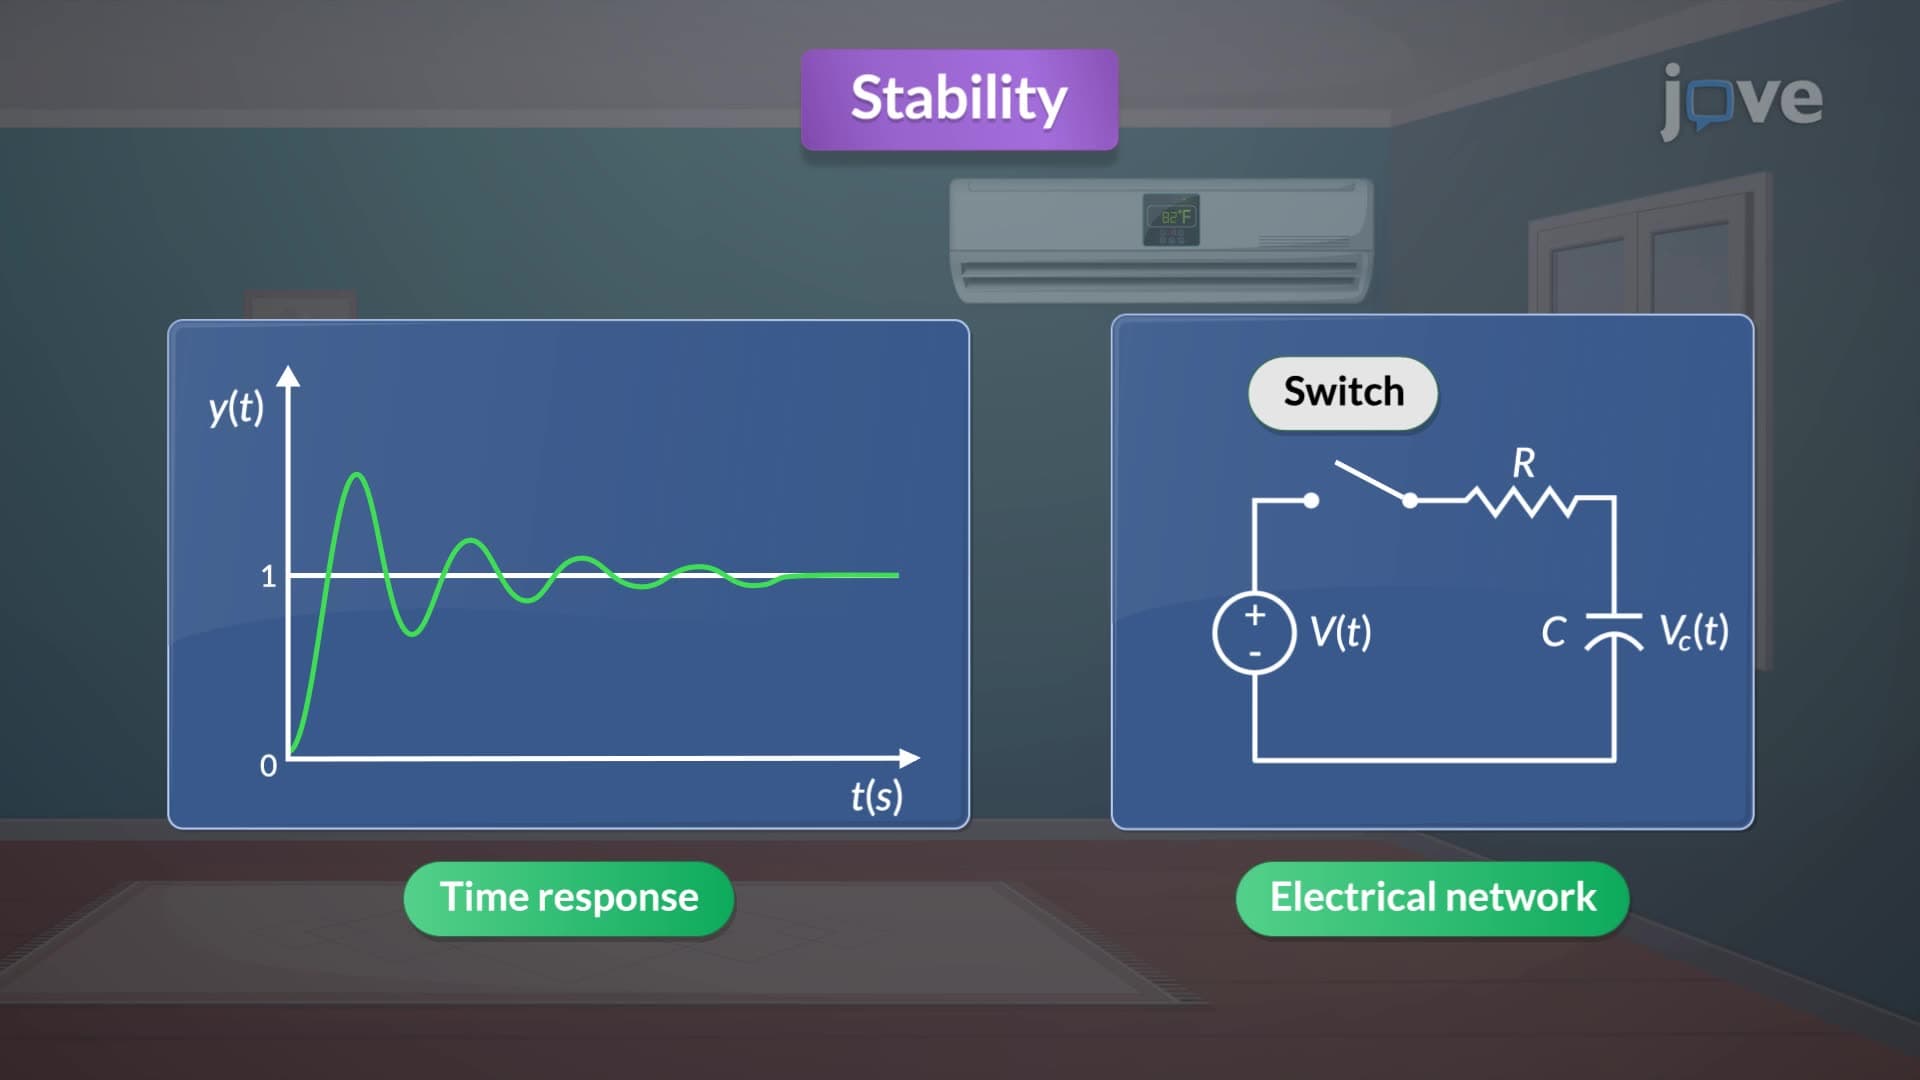
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
67
 01:24
BIBO stability of continuous and discrete -time systems
298
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
298
 01:24
Pole and System Stability
213
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
213
 01:23
Stability of Equilibrium Configuration
414
Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
414
 01:25
Multimachine Stability
103
Multimachine stability analysis is crucial for understanding the dynamics and stability of power systems with multiple synchronous machines. The objective is to solve the swing equations for a network of M machines connected to an N-bus power system.
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
103
 01:18
Second Order systems II
68
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
68