使用单个加速度计在不同的身体位置分析狗的运动 - - 一种新的方法
Rainer da Silva Reinstein1, Franciéli Mallmann Pozzobon1, Pâmela Caye1
1Postgraduate Program in Veterinary Medicine, Center for Rural Sciences, Federal University of Santa Maria, Santa Maria, Brazil.
Frontiers in veterinary science
|May 15, 2025

概括
一个单一的三轴加速度计有效地分析狗的步态,区分不同大小的狗之间的运动模式. 胸骨和骨盆是生物力学和临床研究的理想监测区域.
科学领域:
- 兽医生物力学 兽医生物力学
- 动物的运动分析.
- 可穿戴式传感器技术的技术.
背景情况:
- 传统的狗步态分析方法 (力平台,3D动力学) 是准确的,但昂贵,需要专门的设备.
- 在兽医研究和临床环境中,需要更容易获得和更实用的方法来分析狗的运动.
研究的目的:
- 为了评估单个三轴加速度计在不同解剖区域分析健康狗的步态模式的有效性.
- 为了确定加速度计数据是否可以根据狗的大小和运动阶段来区分运动特征.
- 为了确定最佳的解剖位置,用于加速度计放置在狗的步态分析.
主要方法:
- 24只健康的狗被分为两个体重组 (≤15公斤和>15公斤).
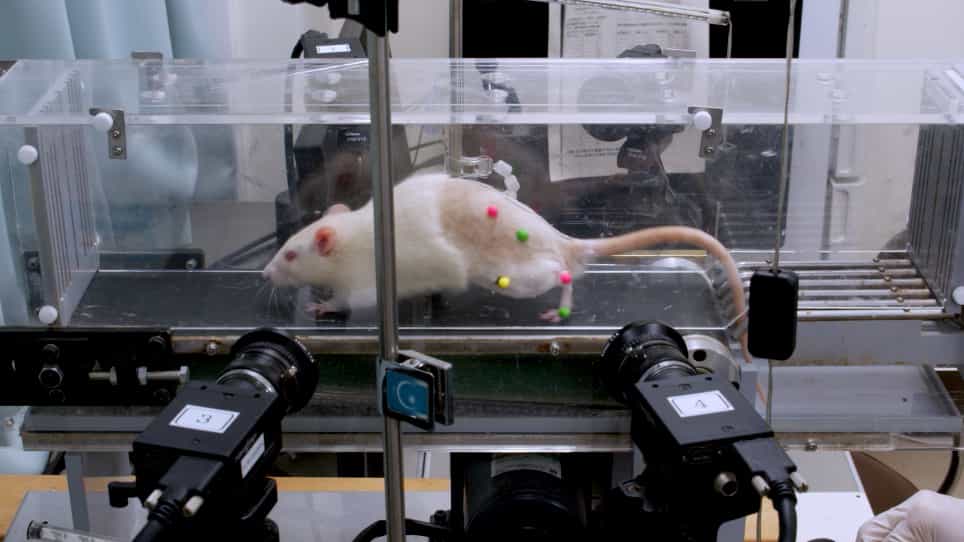
- 一个无线三轴加速度计被安装在子,胸骨,骨盆和右膝盖上,用于收集行走和慢跑期间的数据.
- 数据使用里埃分析处理了波频率,并分析了加速峰值和自相关性,以评估步态对称性.
主要成果:
- 较大的狗 (>15公斤) 与较小的狗 (≤15公斤) 相比,表现出较低的运动频率和更稳定的步态模式,特别是在慢跑时.
- 骨盆和膝盖显示出最高的加速度峰值,而波频率在身体各个区域之间没有显著差异.
- 自相对应分析表明,较大的狗的胸骨和骨盆区域的运动稳定性更大.
结论:
- 一个单一的三轴加速度计提供了一种实用和有效的方法来分析狗的步态,区分基于体重的运动差异.
- 胸骨和骨盆被确定为这种技术的理想监测区域.
- 这种方法在兽医生物力学研究和临床诊断/监测狗走路异常方面具有潜在的应用.
相关概念视频
 01:10
Relative Motion Analysis - Acceleration
317
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
317
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
314
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
314
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
378
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
378