互动染可照亮和可动画的高斯斯化身的互动染

概括
这项研究介绍了一种快速的方法,可以使用高斯斯喷涂 (Gaussian Splatting) 来从视频中创建可动画数字化身. 它可以在新的视图和照明条件下实时染可照明的化身.
科学领域:
- 计算机图形 计算机图形
- 计算机视觉 计算机视觉
- 数字人类 数字人类
背景情况:
- 从视频中创建可点亮和可动画的数字化身对于虚拟现实和数字人类应用至关重要.
- 使用神经辐射场或光线跟踪的现有方法受训和染时间缓慢.
研究的目的:
- 提出一种简单,高效的方法,将车身材料和照明从稀疏视图或单眼化身视频中分离出来.
- 为了使新的视角,姿势和照明条件下的化身能够进行交互式的率染.
主要方法:
- 使用高斯斯普拉丁来表示头像的几何形状和外观.
- 通过签名距离函数和插入属性到高斯核获得正规的体格网.
- 使用前方皮肤和结合可学习的环境照明进行遮阳,将高斯人变形为摆立空间.
- 实现快速的影子建模通过拉斯特化摆设的身体网格.
主要成果:
- 实现了交互式速率 (6.9 fps),用于染可动画和可重新点亮的化身.
- 与以前的方法相比,在合成和真实数据集上展示了更高质量的结果.
- 展示了在新的观点,姿势和动态环境照明下染化身的能力.
结论:
- 拟议的基于高斯斯喷涂的方法为数字化化身的创建提供了显著的速度和质量的改进.
- 这种方法促进了数字人类的实时染和动画,推进了虚拟现实应用.
- 材料和照明的脱允许在各种条件下灵活控制化身的外观.
相关概念视频
 01:27
Support Reactions in Three Dimensions
854
Support reactions in three dimensions help maintain the stability and equilibrium of various structures and systems. These reactions prevent the system from translating and rotating, ensuring the design can withstand external forces and perform its intended function efficiently and safely. Some of the supports providing support reactions in three dimensions are discussed below:
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
854
 01:25
Relative Motion Analysis using Rotating Axes
439
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
439
 02:19
Morphogenesis
24.0K
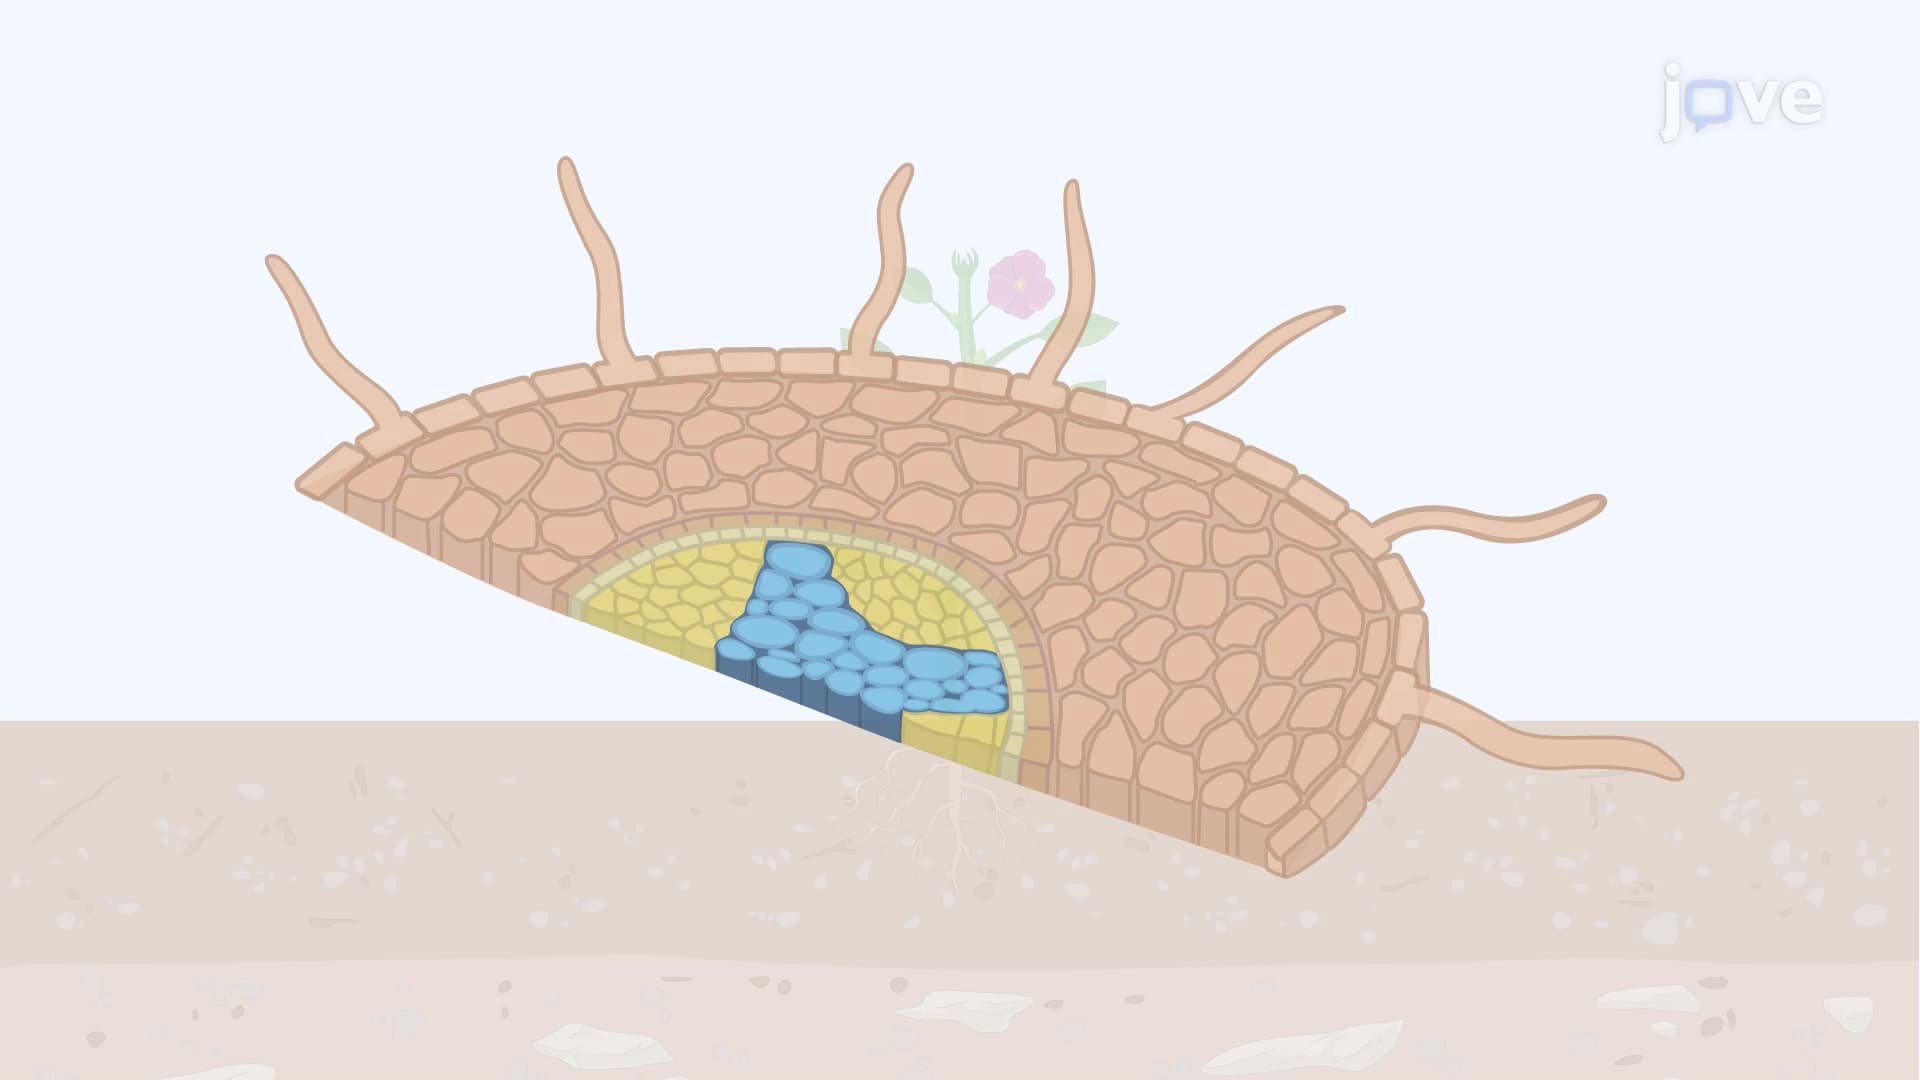
Plant morphogenesis—the development of a plant’s form and structure—involves several overlapping developmental processes, including growth and cell differentiation. Precursor cells differentiate into specific cell types, which are organized into the tissues and organ systems that make up the functional plant.
24.0K
 01:22
Planar Rigid-Body Motion
368
Understanding the movement of a rigid body in planar motion involves recognizing that every particle within this body is traversing a path that maintains a consistent distance from a specific plane. This concept is fundamental in the study of physics and mechanical engineering, and it allows us to comprehend better how objects move in space.
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
368
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
378
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
378
 01:06
Virtual Work for a System of Connected Rigid Bodies
356
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
356