

分布式扩展状态观察者设计用于严格反的非线性领导系统
Jixing Lv1, Changhong Wang1, Yonggui Kao2
1School of Astronautics, Harbin Institute of Technology, Harbin 150001, China.
ISA transactions
|May 21, 2025

概括
本研究引入了一种新方法来估计领导者系统的状态和不确定性,用于领导者跟随控制. 拟议的分布式观察员确保在保证的时间框架内准确地重建状态,即使通信有限.
科学领域:
- 控制理论 控制理论
- 非线性系统是非线性系统.
- 分布式估计 分布式估计
背景情况:
- 准确的领导状态和动态估计对于有效的领导跟随控制系统至关重要.
- 现有的方法经常与非线性系统,不确定的动态和定向通信约束作斗争.
- 需要有效的分布式估计方案来最大限度地降低通信负载至关重要.
研究的目的:
- 为非线性领导系统开发分布式状态和不确定性估计方案.
- 为应对霍尔德不断增长的非线性,匹配的不确定性和定向通信拓所带来的挑战.
- 为了使追随者能够在规定的时间内准确地估计领导者的状态和不确定性.
主要方法:
- 关于使用两个分布式扩展状态观察员 (DESO) 的新型规定的时间分布式估计方案的建议.
- 在用户定义的时间内开发一个规定的时间DESO (PTDESO) 准确的领导状态和不确定性重建.
- 构建一个高收益的DESO (HGDESO) 对于异交对接和有界的观测误差后规定的时间.
主要成果:
- 每个追随者都使用邻居和领导者的有限的单维输出估计来重建领导者的状态和不确定性.
- 该PTDESO保证状态和不确定性估计在规定的时间内,独立于初始条件.
- 在规定的时间之后,HGDESO确保了非对称的收,并保持了在起源的小邻里内观察误差.
结论:
- 拟议的分布式估计方案有效地解决了针对定向拓的非线性领导系统的状态和不确定性估计.
- 通过只要求单维输出估计,观察员可以显著降低通信负载.
- 通过多个操纵器和海洋表面车辆的实践实例来验证,证明了强大的性能.
相关概念视频
 01:26
Feedback control systems
264
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
264
 01:18
Second Order systems II
76
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
76
 01:23
Root Loci for Positive-Feedback Systems
85
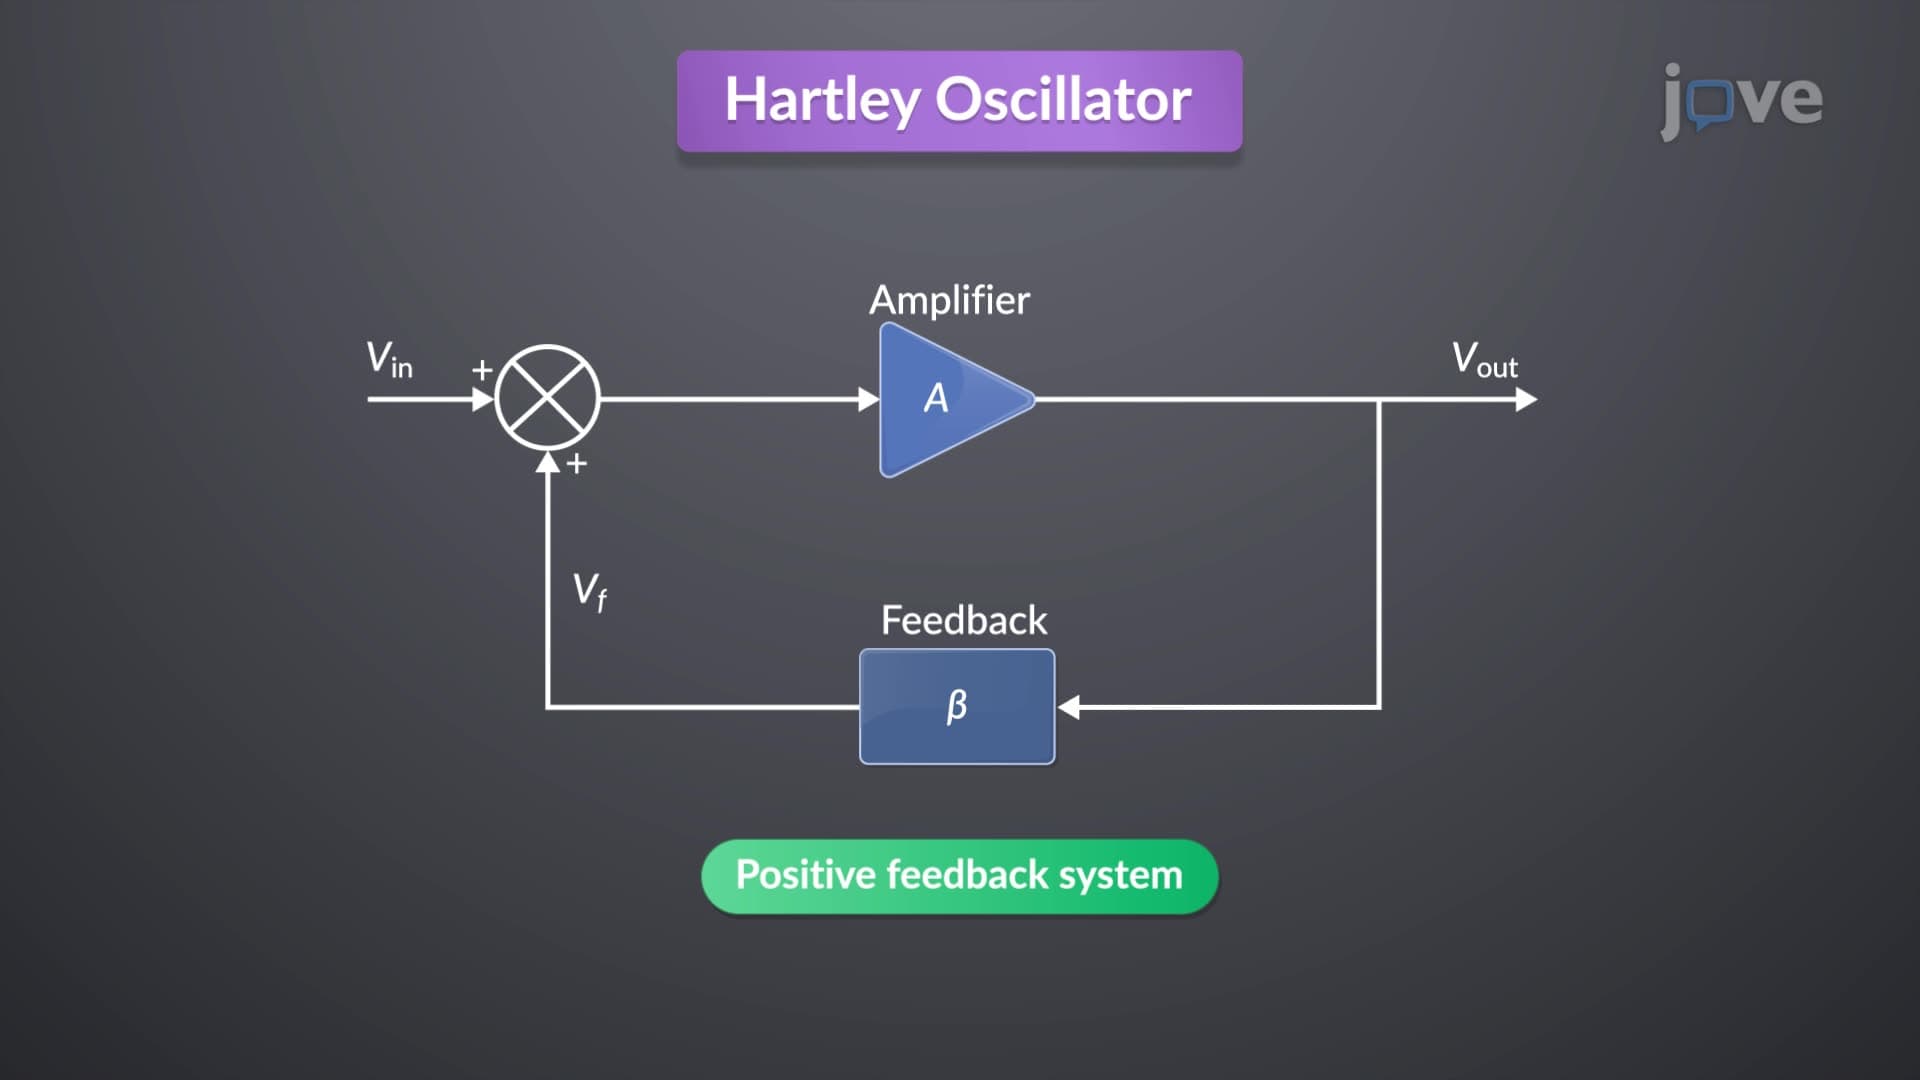
The Hartley oscillator is a positive feedback system that sustains oscillations by feeding the output back to the input in phase, thereby reinforcing the signal. Positive feedback systems can be viewed as negative feedback systems with inverted feedback signals. In these systems, the root locus encompasses all points on the s-plane where the angle of the system transfer function equals 360 degrees.
The construction rules for the root locus in positive feedback systems are similar to those in...
The construction rules for the root locus in positive feedback systems are similar to those in...
85
 01:21
Linear Approximation in Time Domain
59
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
59
 01:27
State Space Representation
158
The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
Consider an RLC circuit, a...
158
 01:21
Control System Problem
94
In an open-loop system, such as a basic thermostat, the poles of the transfer function influence the system's response but do not determine its stability. However, when feedback is introduced to form a closed-loop system, such as an advanced thermostat that adjusts heating based on room temperature, stability is governed by the new poles of the closed-loop transfer function.
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
94