
基于奇拉元表面的太赫兹波的旋转复杂相位和振幅操纵
Li Luo1,2, Jialuo Ding1,2, Yuxin Zou1,2
1Sichuan Province Key Laboratory of Optoelectronic Sensor Devices and Systems, College of Optoelectronic Engineering (Chengdu IC Valley Industrial College), Chengdu University of Information Technology, Chengdu 610225, China. li_jie_d@tju.edu.cn.
Nanoscale
|May 23, 2025

概括
这项研究引入了一种新方法,用于控制使用性超表面的循环偏振光. 这种方法通过专注于参数空间来简化超表面设计,从而使广度和相位的独立操纵成为可能.
科学领域:
- 微纳米光学 微纳米光学
- 地表表面设计设计.
- 特拉赫兹 (THz) 技术的使用.
背景情况:
- 循环偏振 (CP) 波的独立控制在微纳米光学中至关重要.
- 超表面提供了一个解决方案,但面临着设计复杂性,涉及参数和极化空间.
- 同时控制CP波的振幅和相位仍然具有挑战性.
研究的目的:
- 提出一种新的方案,用于旋转多重复的振幅和CP波的相位控制.
- 通过专注于参数空间来简化超表面设计.
- 为了证明CP波的独立控制,使用奇拉元表面.
主要方法:
- 通过打破平面内镜面对称性和元原子的第二阶旋转对称性来设计性元表面.
- 展示了在太赫兹频段运行的两种类型的超表面.
- 通过展示聚焦和偏移波线的功能设备验证了该方案.
主要成果:
- 使用奇拉相实现了共极化的THz波的旋转多重相控制,使用奇拉相的反射效率>71.7%.
- 证明了反射的CP波的相位和振幅的联合控制.
- 通过奇拉相和循环二重化,独立控制的CP波.
结论:
- 拟议的方案简化了用于旋转复杂振幅相位操纵的超表面设计.
- 探索奇拉元原子的参数空间可以独立控制CP波.
- 这项工作为设计用于光学应用的先进超表面提供了新的途径.
相关概念视频
 01:09
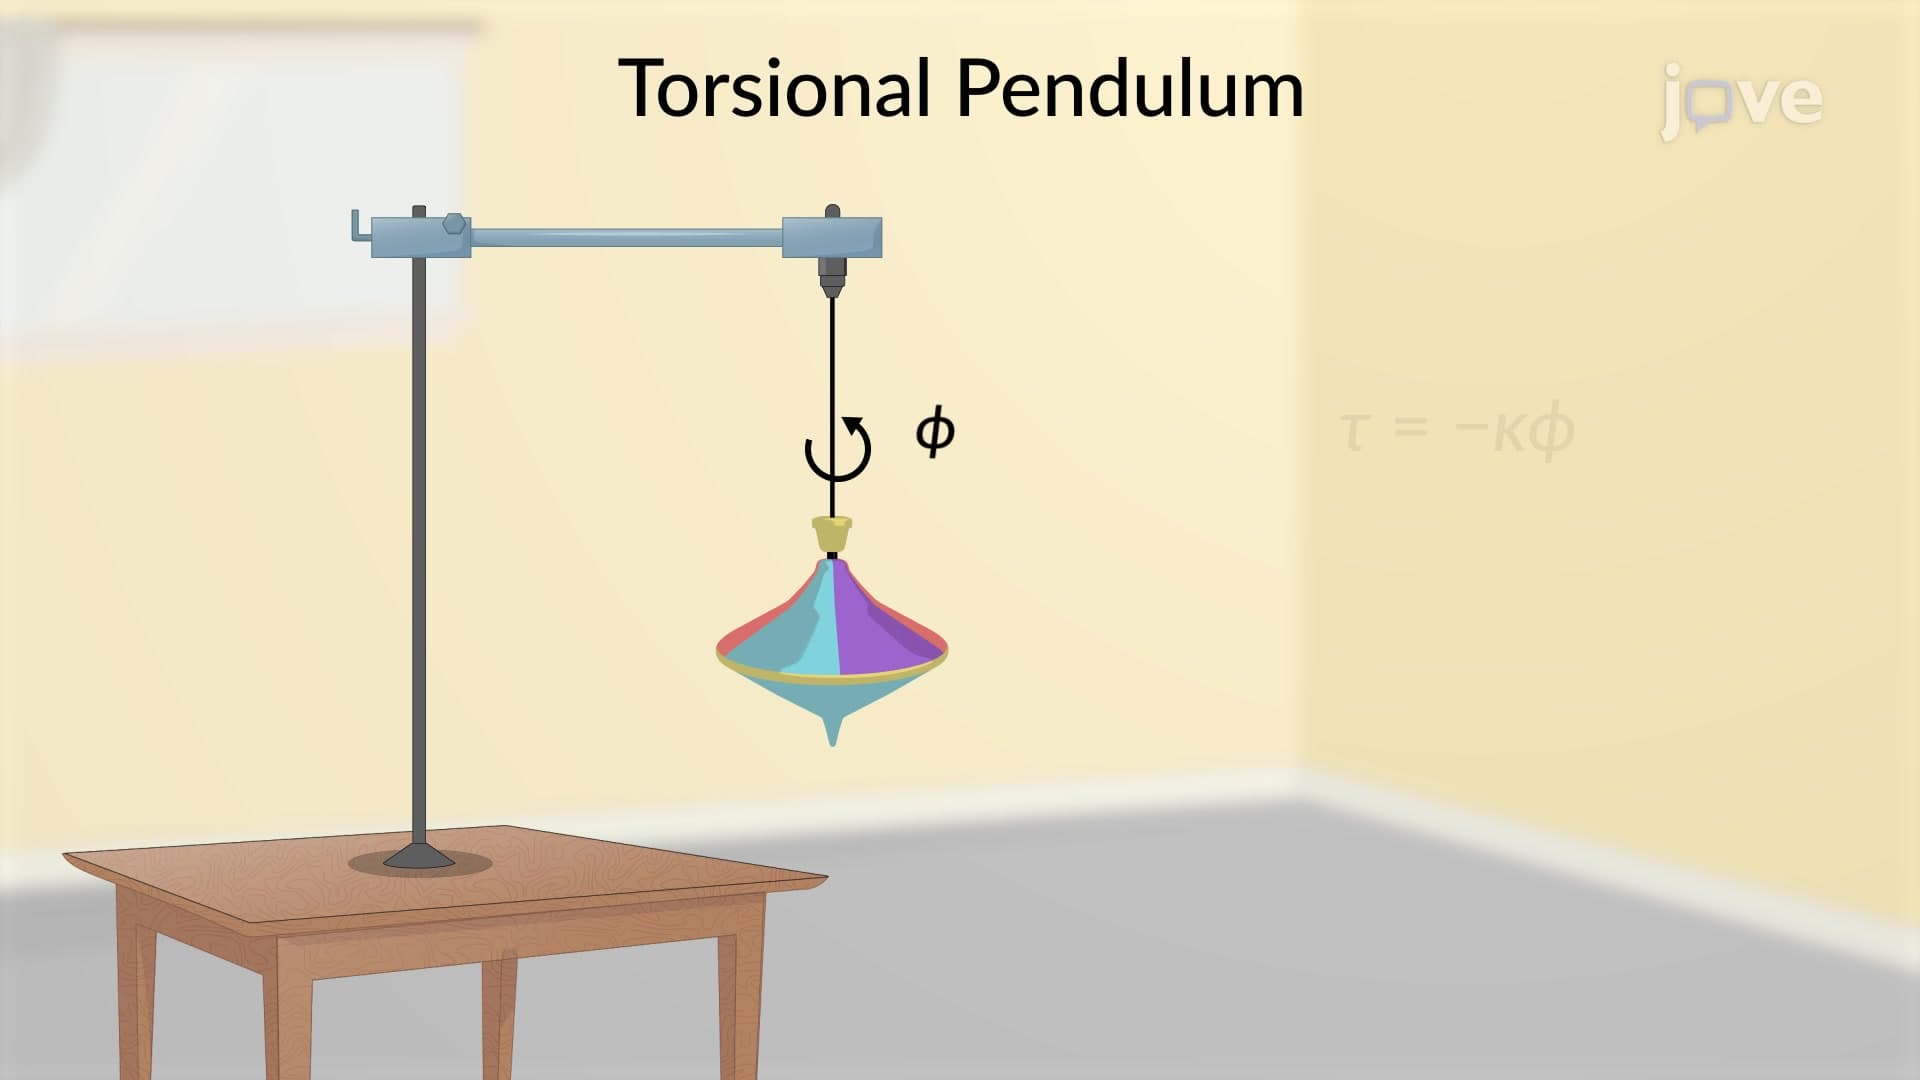
Torsional Pendulum
A torsional pendulum involves the oscillation of a rigid body in which the restoring force is provided by the torsion in the string from which the rigid body is suspended. Ideally, the string should be massless; practically, its mass is much smaller than the rigid body's mass and is neglected.
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
 01:26
Rotational Motion about a Fixed Axis
A rigid body's rotation around a fixed axis makes every point within it trace a circular path around a specific line or point. The term given to this type of spinning is defined by the angular position, symbolized by the angle θ. This angle is gauged from a static reference line to the revolving object. From this angular position, any variation is referred to as angular displacement, denoted by dθ. The extent of this displacement can be calculated in degrees, radians, or revolutions, where one...
 01:25
Relative Motion Analysis using Rotating Axes
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:15
Torque Free Motion
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
 01:24
Polar Coordinates
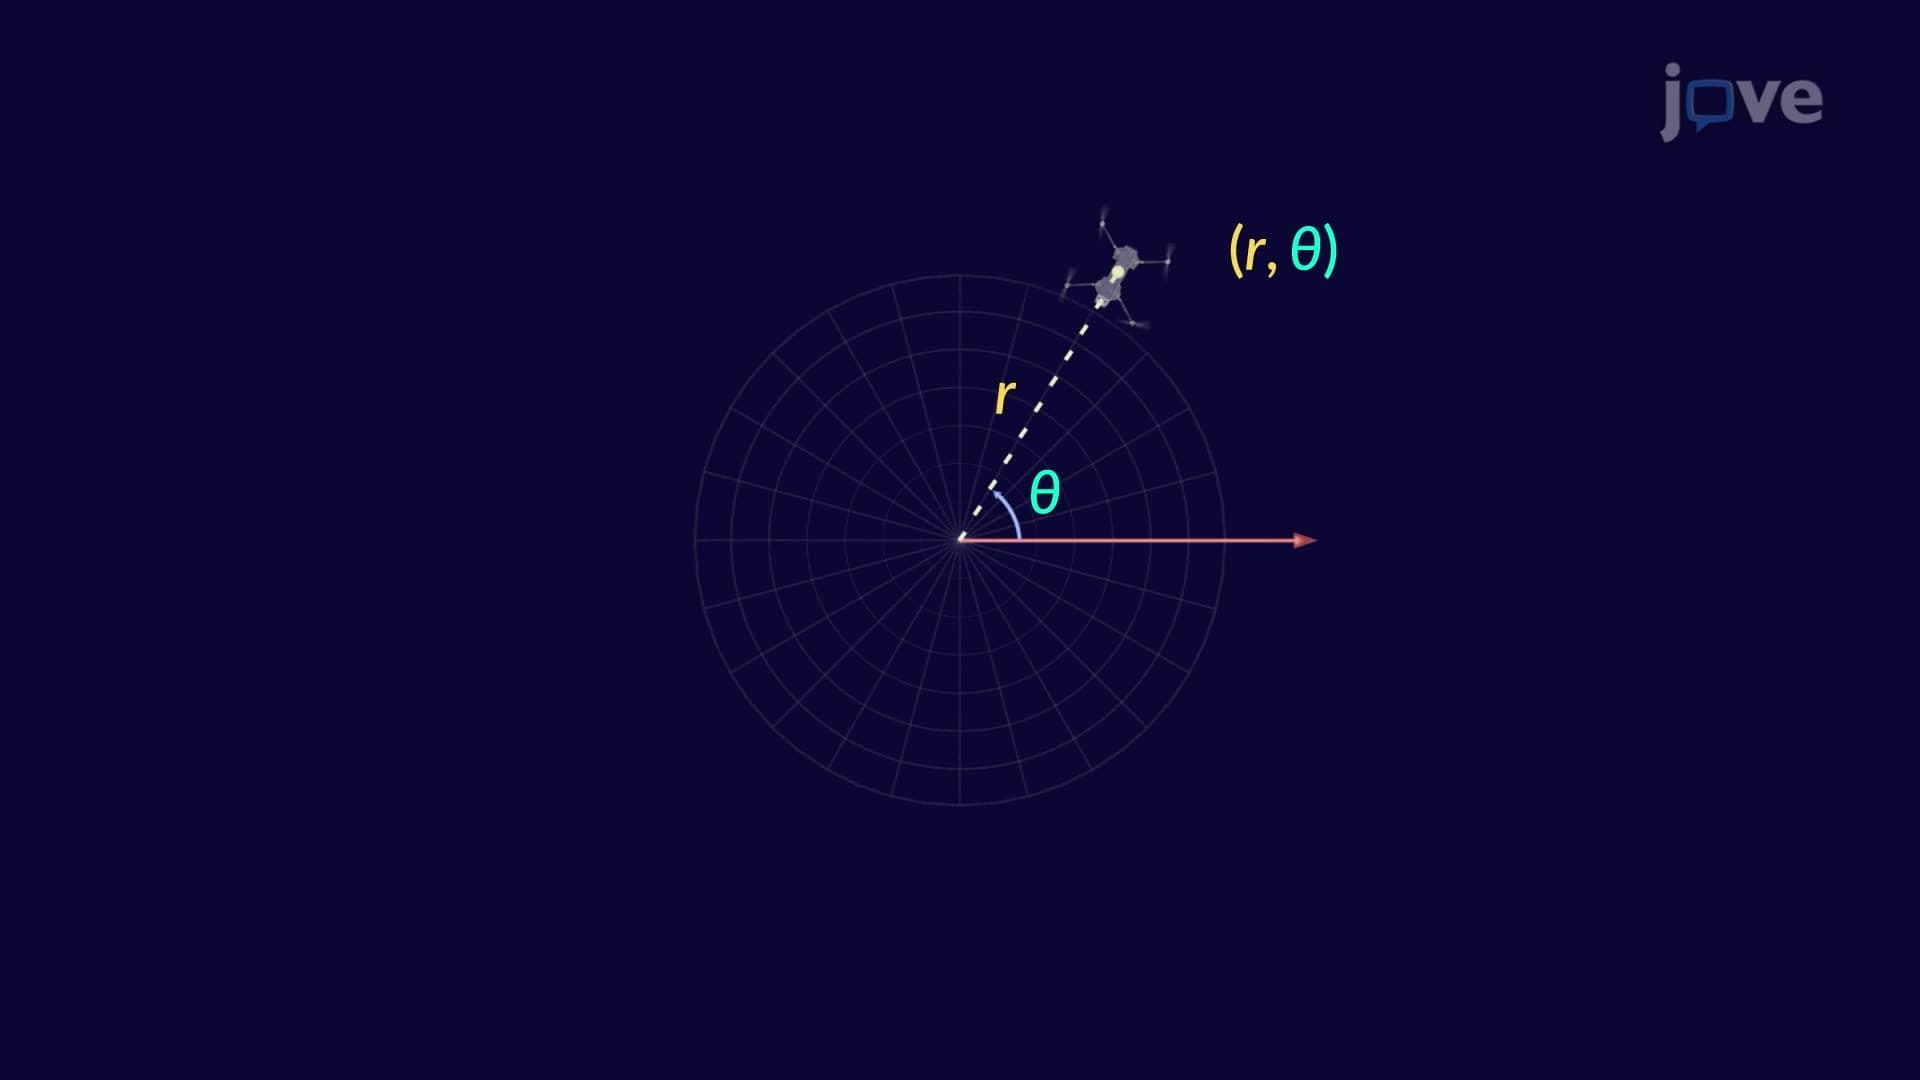
The polar coordinate system offers an alternative to the Cartesian coordinate system for specifying points in a plane, using a distance and an angle instead of x and y coordinates. This system is particularly advantageous in situations involving circular or rotational symmetry, such as in physics or engineering problems involving waves, oscillations, or orbital paths.Defining Polar CoordinatesIn polar coordinates, a point is represented as P(r, ��), where r is the radial distance from a fixed...
 01:20
Transformations of Functions III
Transformations modify the graphical representation of a function without changing its fundamental form. One common transformation is reflection, which flips the graph across a designated axis. When the vertical coordinates of all points are multiplied by the negative one, the entire graph is mirrored over the horizontal axis. This transformation reverses the vertical orientation of peaks and troughs, akin to signal inversion in electrical systems, where a waveform is flipped, but the timing of...