
进入虚空:绘制高维数据中看不见的空白

概括
本研究介绍了一种使用空空间搜索算法 (ESA) 和GapMiner发现高维数据集中有价值的配置的新管道. 该系统由深度神经网络 (DNN) 增强,在找到最佳解决方案方面优于传统方法.
科学领域:
- 数据挖掘和分析数据
- 机器学习 机器学习
- 高维数据探索研究
背景情况:
- 探索高维数据集往往会让有价值的"空"区域未被检查.
- 传统的方法很难系统地识别和利用这些未知数据空白.
研究的目的:
- 开发一个全面的管道,以探索高维数据集中尚未开发的机会.
- 在空数据区域内识别和利用新的配置.
主要方法:
- 使用视觉分析系统 (GapMiner) 和一个新的空空间搜索算法 (ESA).
- 将用户交互与深度神经网络 (DNN) 集成,用于代数据集增强和配置发现.
- 采用梯度上升和精细的空空间搜索,由训练有素的DNN引导进行自主优化.
主要成果:
- 管道成功地确定了空区域的中心点,代表了潜在的有价值配置.
- 与基于随机化的方法相比,该系统展示了优越的新型配置的持续生成.
- 通过多个不同的案例研究来说明有效性.
结论:
- 开发的方法提供了一种系统和有效的方法,用于发现高维数据中的新型配置.
- 视觉分析,用户专业知识和DNN的整合增强了对数据空白的探索.
- 这种方法在数据驱动发现的传统方法上提供了显著的进步.
更多相关视频
 09:43
Databases to Efficiently Manage Medium Sized, Low Velocity, Multidimensional Data in Tissue Engineering
Published on: November 22, 2019
6.4K
 08:51
Author Spotlight: Integrated Multi-Omics Analysis for Unveiling Multicellular Immune Signatures in Clinical Heart Attack Cohorts
Published on: September 20, 2024
1.5K
相关概念视频
 01:06
Collisions in Multiple Dimensions: Problem Solving
4.4K
In multiple dimensions, the conservation of momentum applies in each direction independently. Hence, to solve collisions in multiple dimensions, we should write down the momentum conservation in each direction separately. To help understand collisions in multiple dimensions, consider an example.
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
4.4K
 01:05
Collisions in Multiple Dimensions: Introduction
5.6K
It is far more common for collisions to occur in two dimensions; that is, the initial velocity vectors are neither parallel nor antiparallel to each other. Let's see what complications arise from this. The first idea is that momentum is a vector. Like all vectors, it can be expressed as a sum of perpendicular components (usually, though not always, an x-component and a y-component, and a z-component if necessary). Thus, when the statement of conservation of momentum is written for a...
5.6K
 01:18
Uniform Depth Channel Flow: Problem Solving
131
To calculate the flow rate for a trapezoidal channel, first, identify the bottom width, side slope, and flow depth of the channel. The cross-sectional area (A) corresponding to the depth of flow (y), channel bottom width (B), and side slope (θ) is determined by:Next, calculate the wetted perimeter, which includes the bottom width and the sloped side lengths in contact with the water. Using the values of the cross-sectional area and the wetted perimeter, determine the hydraulic radius by...
131
 01:08
Problem Solving: Dimensional Analysis
4.7K
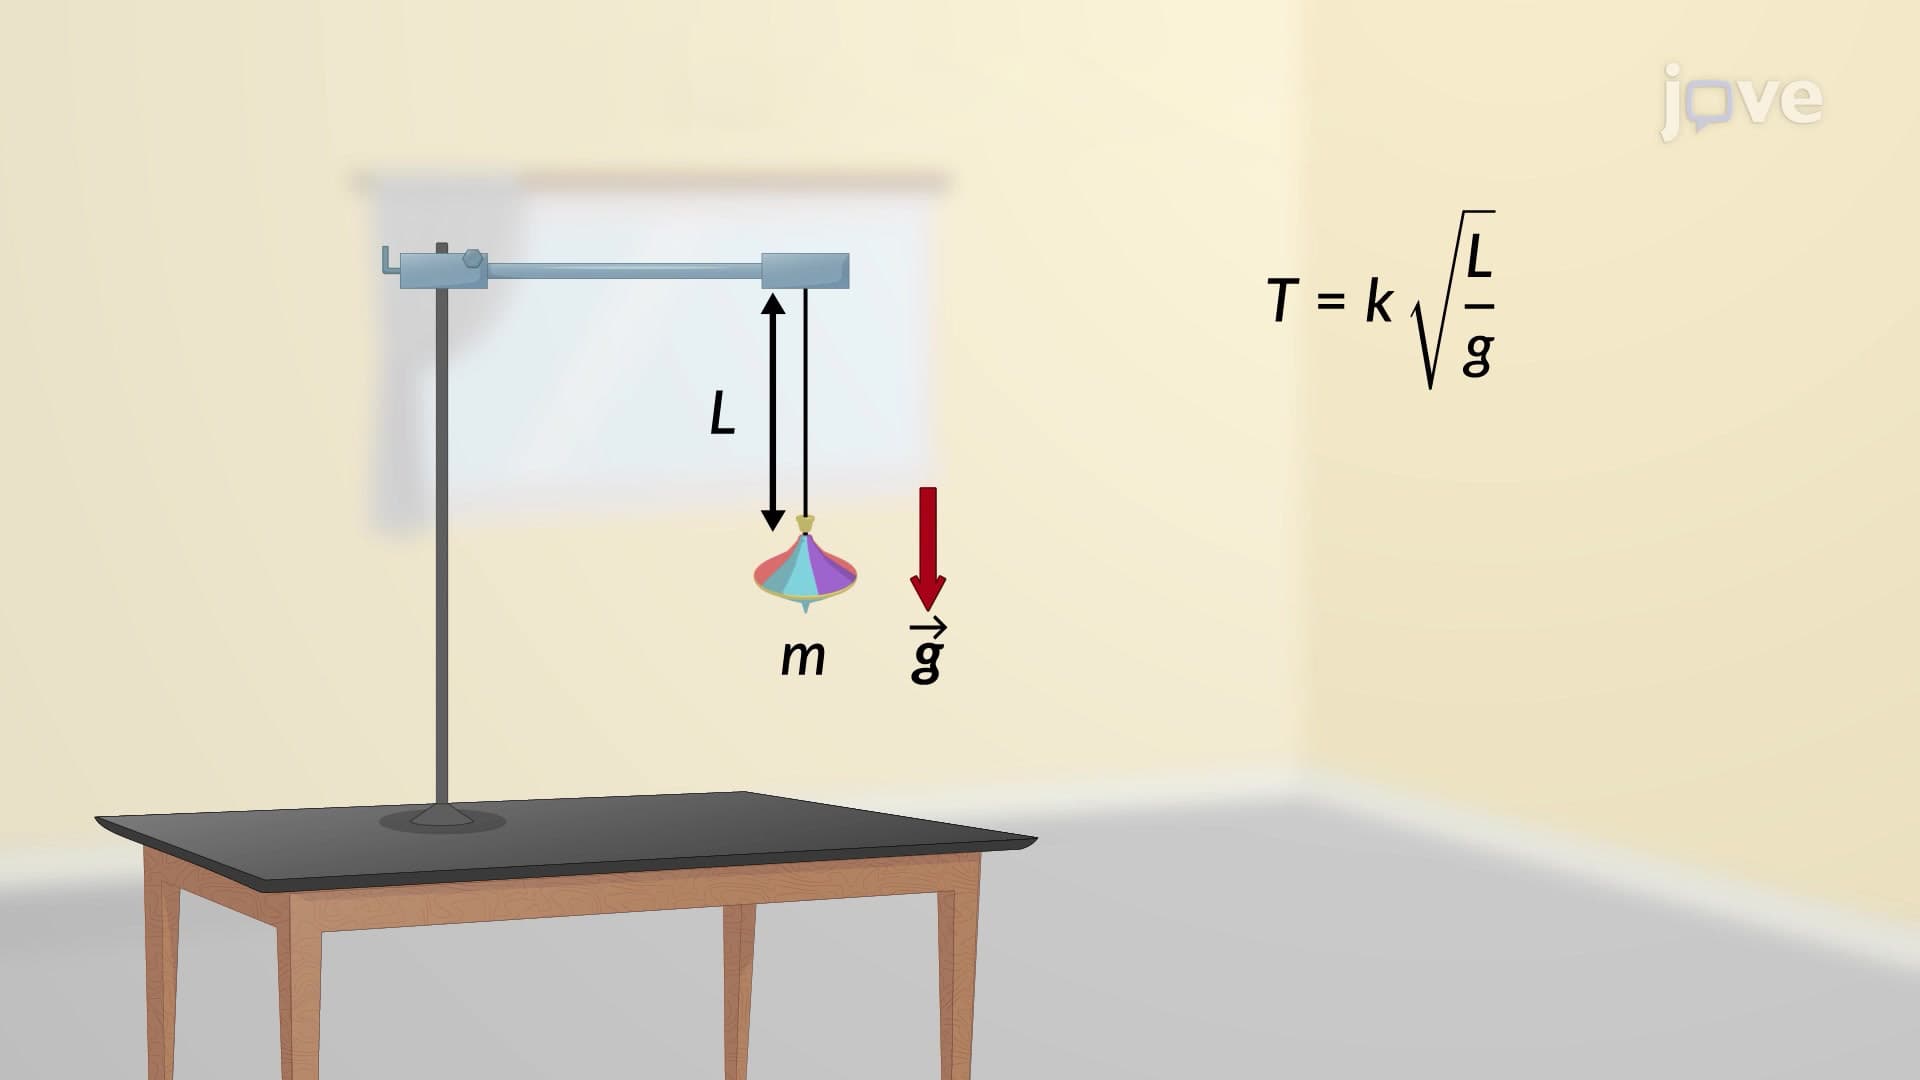
Every mathematical equation that connects separate distinct physical quantities must be dimensionally consistent, which implies it must abide by two rules. For this reason, the concept of dimension is crucial. The first rule is that an equation's expressions on either side of an equality must have the exact same dimension, i.e., quantities of the same dimension can be added or removed. The second rule stipulates that all popular mathematical functions, such as exponential, logarithmic, and...
4.7K
 01:26
Unsoundness of Aggregate due to Volume Change
186
Unsoundness in aggregates due to volume changes is primarily caused by the physical alterations aggregates undergo, such as freezing and thawing, thermal changes, and wetting and drying. Unsound aggregates, when subjected to these changes, result in volume change upon disintegration. This, in turn, contributes to the deterioration of concrete, including scaling, pop-outs, and cracking. Particular types of aggregates, such as porous flints, cherts, and those containing clay minerals, are...
186
 01:05
Difference from Background: Limit of Detection
7.1K
The limit of detection (LOD) is the smallest amount of analyte that can be distinguished from the background noise. The LOD value corresponds to the concentration at which the analyte signal is three times larger than the standard deviation of the blank signal. Below this value, the analyte signal cannot be differentiated from the background noise. It is calculated by dividing the calibration slope by 3 times the standard deviation of the blank signals.
The LOD indicates the presence or absence...
The LOD indicates the presence or absence...
7.1K