SPU+:用于语义点云上采样的维度折叠

概括
使用SPU+的语义点云升级采样 (SPU) 引入了维度折叠,以改进3D点云重建. 这种新的方法增强了特征表示,在升级样本任务中实现了最先进的性能.
科学领域:
- 计算机视觉 计算机视觉
- 3D数据处理 3D数据处理
- 机器学习 机器学习
背景情况:
- 语义点云升级采样 (SPU) 从稀疏的输入中重建密集的3D点云.
- 传统方法面临一个维度瓶,高维特征向量.
- 有效的特征表示对于SPU中的语义任务至关重要.
研究的目的:
- 提出一种新的SPU方法,SPU+,它解决了维度瓶.
- 引入尺寸折叠作为处理高维特征的替代策略.
- 为了在语义点云上采样中实现最先进的性能.
主要方法:
- SPU+将高维特征分解为g维包,以便进行交互.
- 一个3D残余图形卷积块 (3D-RGCB) 可实现高效的3D包卷积.
- 为了进行大规模的提升样本,开发了一个缩放和混合的策略.
主要成果:
- 维度折叠在增强SPU的特征表示方面被证明是有效的.
- SPU+在公开可用的数据集上实现了最先进的性能.
- 覆盖号的分析表明了3D包裹表示的优势.
结论:
- 在语义点云Upsampling中,SPU+提供了显著的进步.
- 尺寸折叠和3D包装表示是关键的创新.
- 提出的方法证明了卓越的性能和效率.
相关概念视频
 01:23
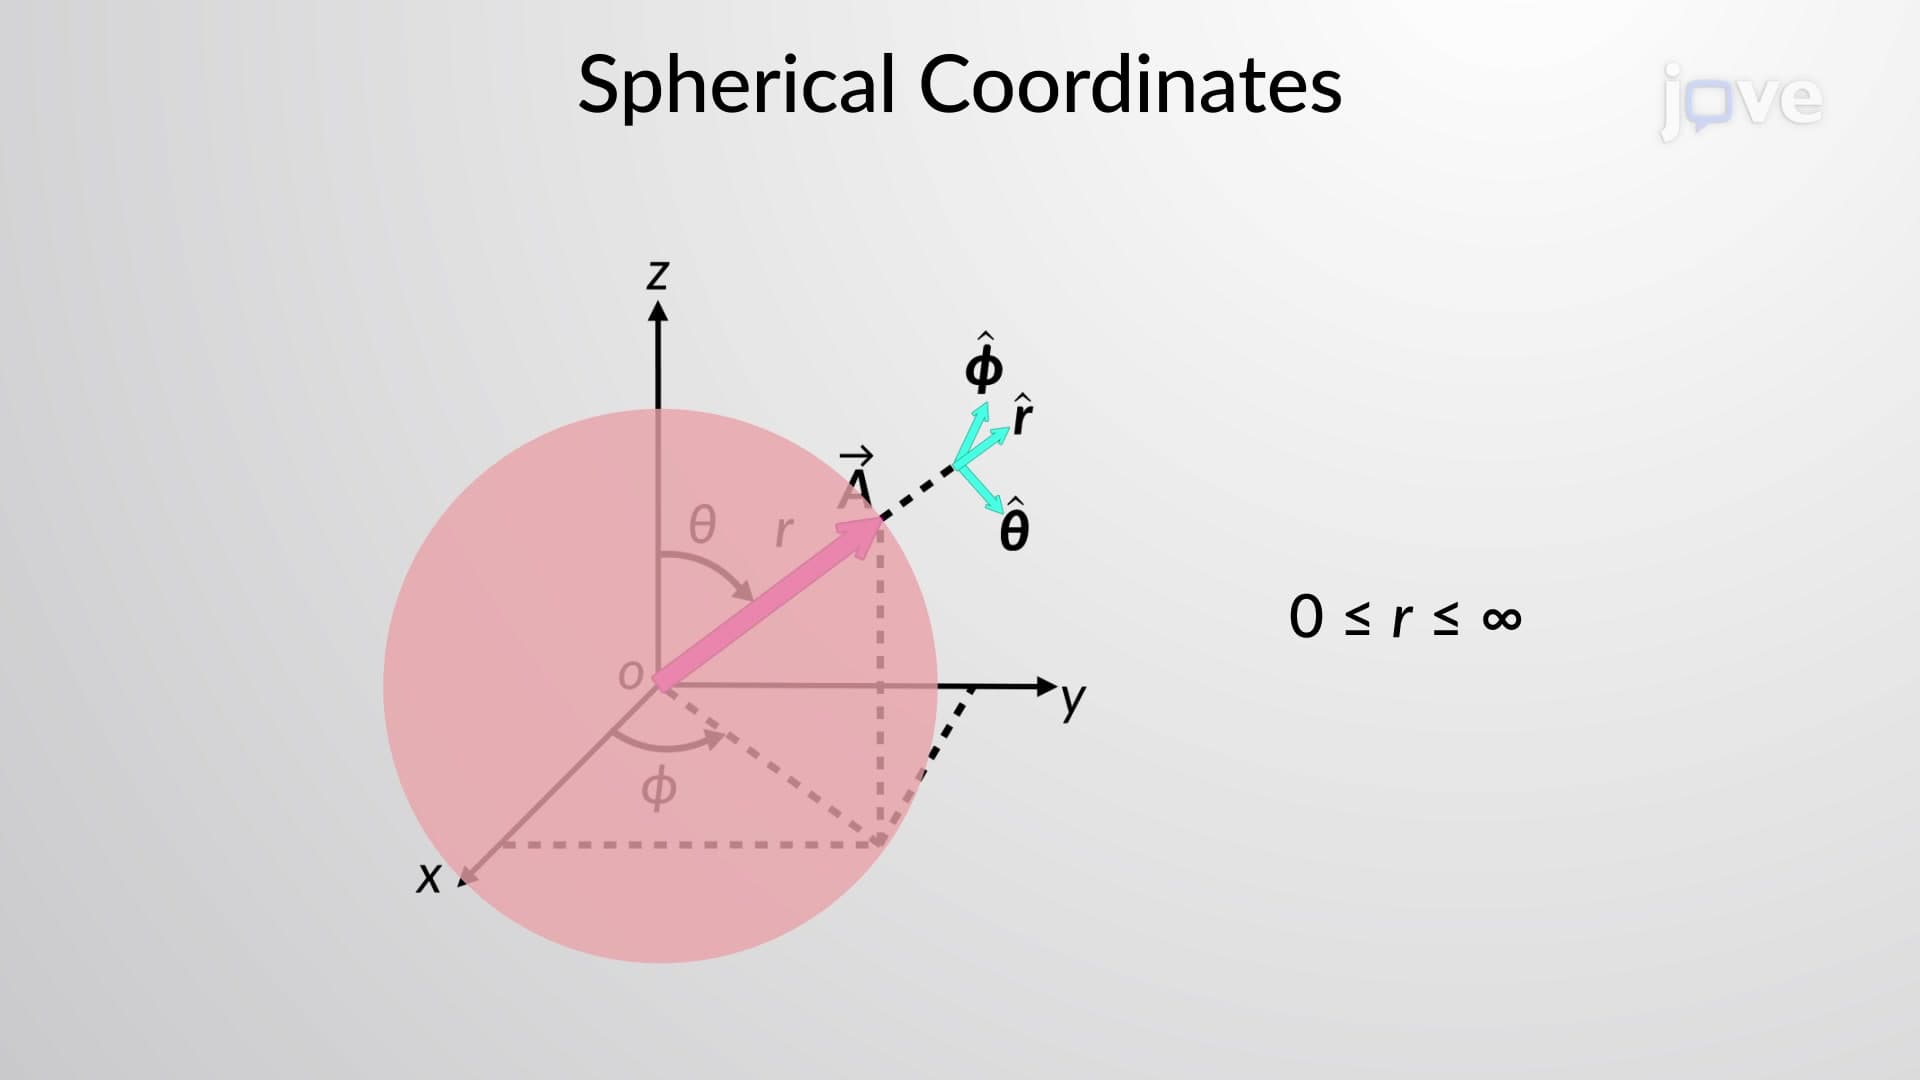
Spherical Coordinates
Spherical coordinate systems are preferred over Cartesian, polar, or cylindrical coordinates for systems with spherical symmetry. For example, to describe the surface of a sphere, Cartesian coordinates require all three coordinates. On the other hand, the spherical coordinate system requires only one parameter: the sphere's radius. As a result, the complicated mathematical calculations become simple. Spherical coordinates are used in science and engineering applications like electric and...
 01:20
Downsampling
When considering a sampled sequence with zero values between sampling instants, one can replace it by taking every N-th value of the sequence. At these integer multiples of N, the original and sampled sequences coincide. This process, known as decimation, involves extracting every N-th sample from a sequence, thereby creating a more efficient sequence.
The Fourier transform of the decimated sequence reveals a combination of scaled and shifted versions of the original spectrum. This...
The Fourier transform of the decimated sequence reveals a combination of scaled and shifted versions of the original spectrum. This...
 01:22
Upsampling
Managing signal sampling rates is essential in digital signal processing to maintain signal integrity. A decimated signal, characterized by a reduced frequency range due to its lower sampling rate, can be upsampled by inserting zeros between each sample. This upsampling process expands the original spectrum and introduces repeated spectral replicas at intervals dictated by the new Nyquist frequency. To refine this zero-inserted sequence, it is passed through a lowpass filter with a cutoff...
 01:15
Depth Perception and Spatial Vision
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.