

安全的物理信息机器学习以实现最佳预定义时间稳定:基于利亚普诺夫的方法

概括
这项研究为非线性系统引入了安全的预定义时间稳定性,确保状态保持边界,并在设定的时间内达到平衡. 一个新的基于物理的机器学习算法解决了最佳控制问题,以提高系统安全性和性能.
科学领域:
- 控制理论 控制理论
- 非线性动态系统非线性动态系统
- 优化优化 优化优化
背景情况:
- 在有限的,预先确定的时间内定义稳定性对于许多工程应用至关重要.
- 确保系统轨迹保持在安全运行范围内,是控制设计的一个关键挑战.
- 最佳控制旨在尽量减少性能指标,同时满足系统约束.
研究的目的:
- 介绍并定义参数依赖的非线性系统的"安全预定义时间稳定性".
- 开发一个基于Lyapunov的定理,以保证安全的预定义时间稳定性.
- 使用反控制器解决最佳安全的预定义时间稳定问题.
主要方法:
- 使用Lyapunov函数,制定安全的预定义时间稳定条件.
- 反控制器的合成,以实现闭环安全的预定义时间稳定性.
- 运用基于物理的机器学习来解决稳定状态的汉密尔顿-雅各比-贝尔曼 (HJB) 方程以获得最佳性.
主要成果:
- 建立了一个Lyapunov定理,为安全的预定义时间稳定提供了足够的条件.
- 控制器是合成的,以确保闭环系统具有安全的预定义时间稳定性.
- 一个基于物理的机器学习算法有效地学习了HJB方程的最佳稳定解决方案.
结论:
- 拟议的框架允许在预先定义的时间内设计可保证安全性和融合的系统控制器.
- 开发的算法提供了解决非线性系统中复杂的最佳控制问题的实用方法.
- 模拟结果验证了基于物理的机器学习方法在安全的预定义时间稳定方面的有效性.
更多相关视频
 07:34
A Simple Stimulatory Device for Evoking Point-like Tactile Stimuli: A Searchlight for LFP to Spike Transitions
Published on: March 25, 2014
10.0K
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
10.5K
相关概念视频
 01:21
Linear Approximation in Time Domain
130
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
130
 01:28
Stability
197
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
197
 01:07
Time-Domain Interpretation of PD Control
186
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
186
 01:25
Multimachine Stability
237
Multimachine stability analysis is crucial for understanding the dynamics and stability of power systems with multiple synchronous machines. The objective is to solve the swing equations for a network of M machines connected to an N-bus power system.
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
237
 01:24
Pole and System Stability
439
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
439
 01:30
Simplified Synchronous Machine Model
339
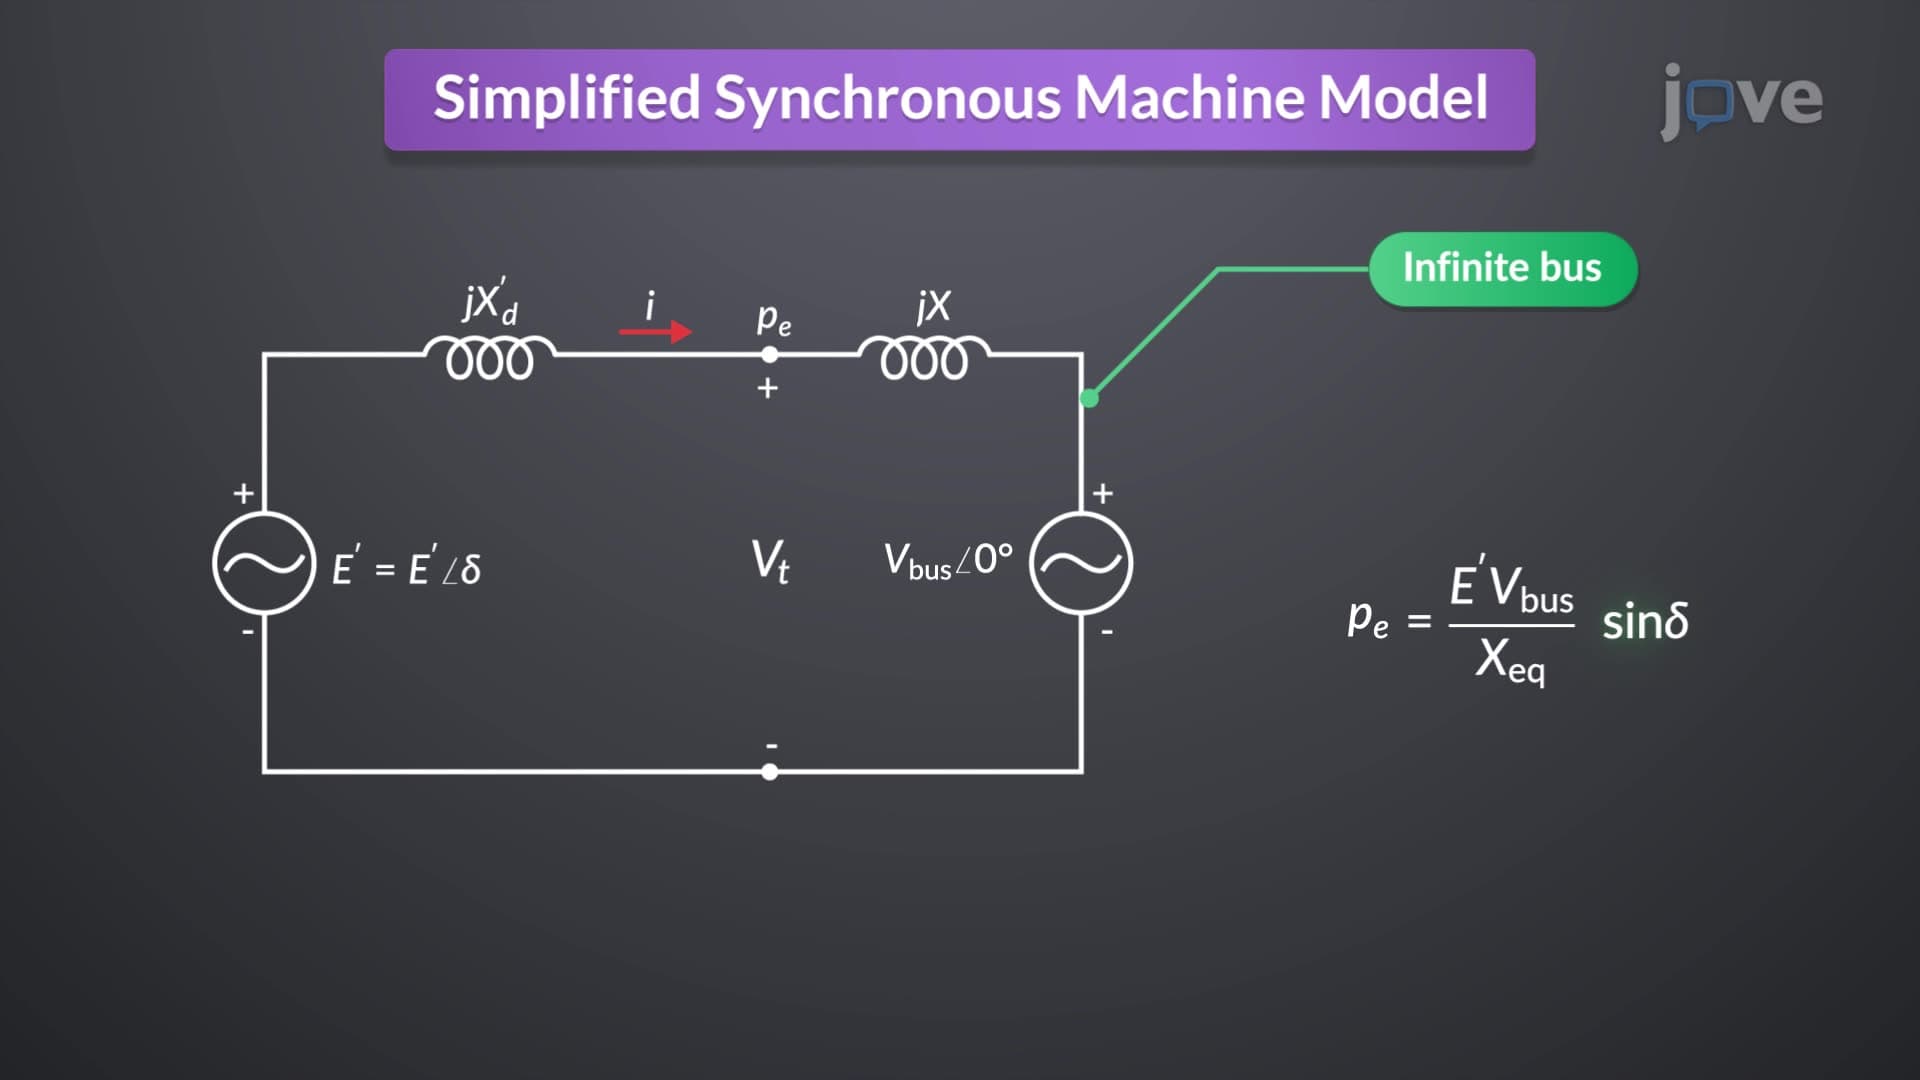
The Synchronous Machine Model is a fundamental tool in analyzing and ensuring the transient stability of power systems. This model simplifies the representation of a synchronous machine under balanced three-phase positive-sequence conditions, assuming constant excitation and ignoring losses and saturation. The model is pivotal for understanding the behavior of synchronous generators connected to a power grid, particularly during transient events.
In this model, each generator is connected to a...
In this model, each generator is connected to a...
339