

适应式学习算法及其与复杂值错误损失网络的融合分析
Guobing Qian1, Bingqing Lin1, Jiaojiao Mei2
1College of Electronic and Information Engineering, Southwest University, Chongqing 400715, PR China.

概括
一个新的复杂错误损失网络 (CELN) 改善了机器学习模型对复杂值数据的预测. 在监督学习任务中,CELN表现出更高的准确性和稳定性,优于现有的方法.
科学领域:
- 机器学习 机器学习
- 监督学习 监督学习
- 信号处理 信号处理
背景情况:
- 损失函数对于评估机器学习模型性能至关重要.
- 现有的模型面临着复杂值信号和参数的挑战.
- 适应式学习算法需要稳定的收特性.
研究的目的:
- 介绍一个新的复杂错误损失网络 (CELN),用于监督学习.
- 解决处理复杂值数据的局限性问题.
- 研究CELN自适应学习算法的收性质.
主要方法:
- 开发了一种新的复杂错误损失网络 (CELN).
- 应用了收缩映射定理来分析算法收.
- 对基准方法进行评估的CELN性能.
主要成果:
- 与基准相比,CELN可将预测误差降低至少4.1%.
- 适应式学习算法证明了向最佳解决方案的稳定趋同.
- 在非高斯噪声环境中,CELN 保持了性能稳定性.
结论:
- CELN提供了一个强大的解决方案,用于使用复杂值数据进行监督学习.
- 该模型的收性质确保可靠的优化.
- 在机器学习损失函数设计方面,CELN取得了重大进展.

相关概念视频
 01:20
Region of Convergence of Laplace Tarnsform
732
The Region of Convergence (ROC) is a fundamental concept in signal processing and system analysis, particularly associated with the Laplace transform. The ROC represents an area in the complex plane where the Laplace transform of a given signal converges, determining the transform's applicability and utility.
Consider a decaying exponential signal that begins at a specific time. When deriving its Laplace transform, the time-domain variable is replaced with a complex variable. This...
Consider a decaying exponential signal that begins at a specific time. When deriving its Laplace transform, the time-domain variable is replaced with a complex variable. This...
732
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
104
Mechanistic models play a crucial role in algorithms for numerical problem-solving, particularly in nonlinear mixed effects modeling (NMEM). These models aim to minimize specific objective functions by evaluating various parameter estimates, leading to the development of systematic algorithms. In some cases, linearization techniques approximate the model using linear equations.
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
104
 01:26
Linear Approximation in Frequency Domain
139
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
139
 01:14
Avoidance Learning and Learned Helplessness
1.9K
Avoidance learning and learned helplessness are critical concepts in understanding behavioral responses to negative stimuli.
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
1.9K
 01:22
Multi-input and Multi-variable systems
152
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
152
 01:17
Region of Convergence
577
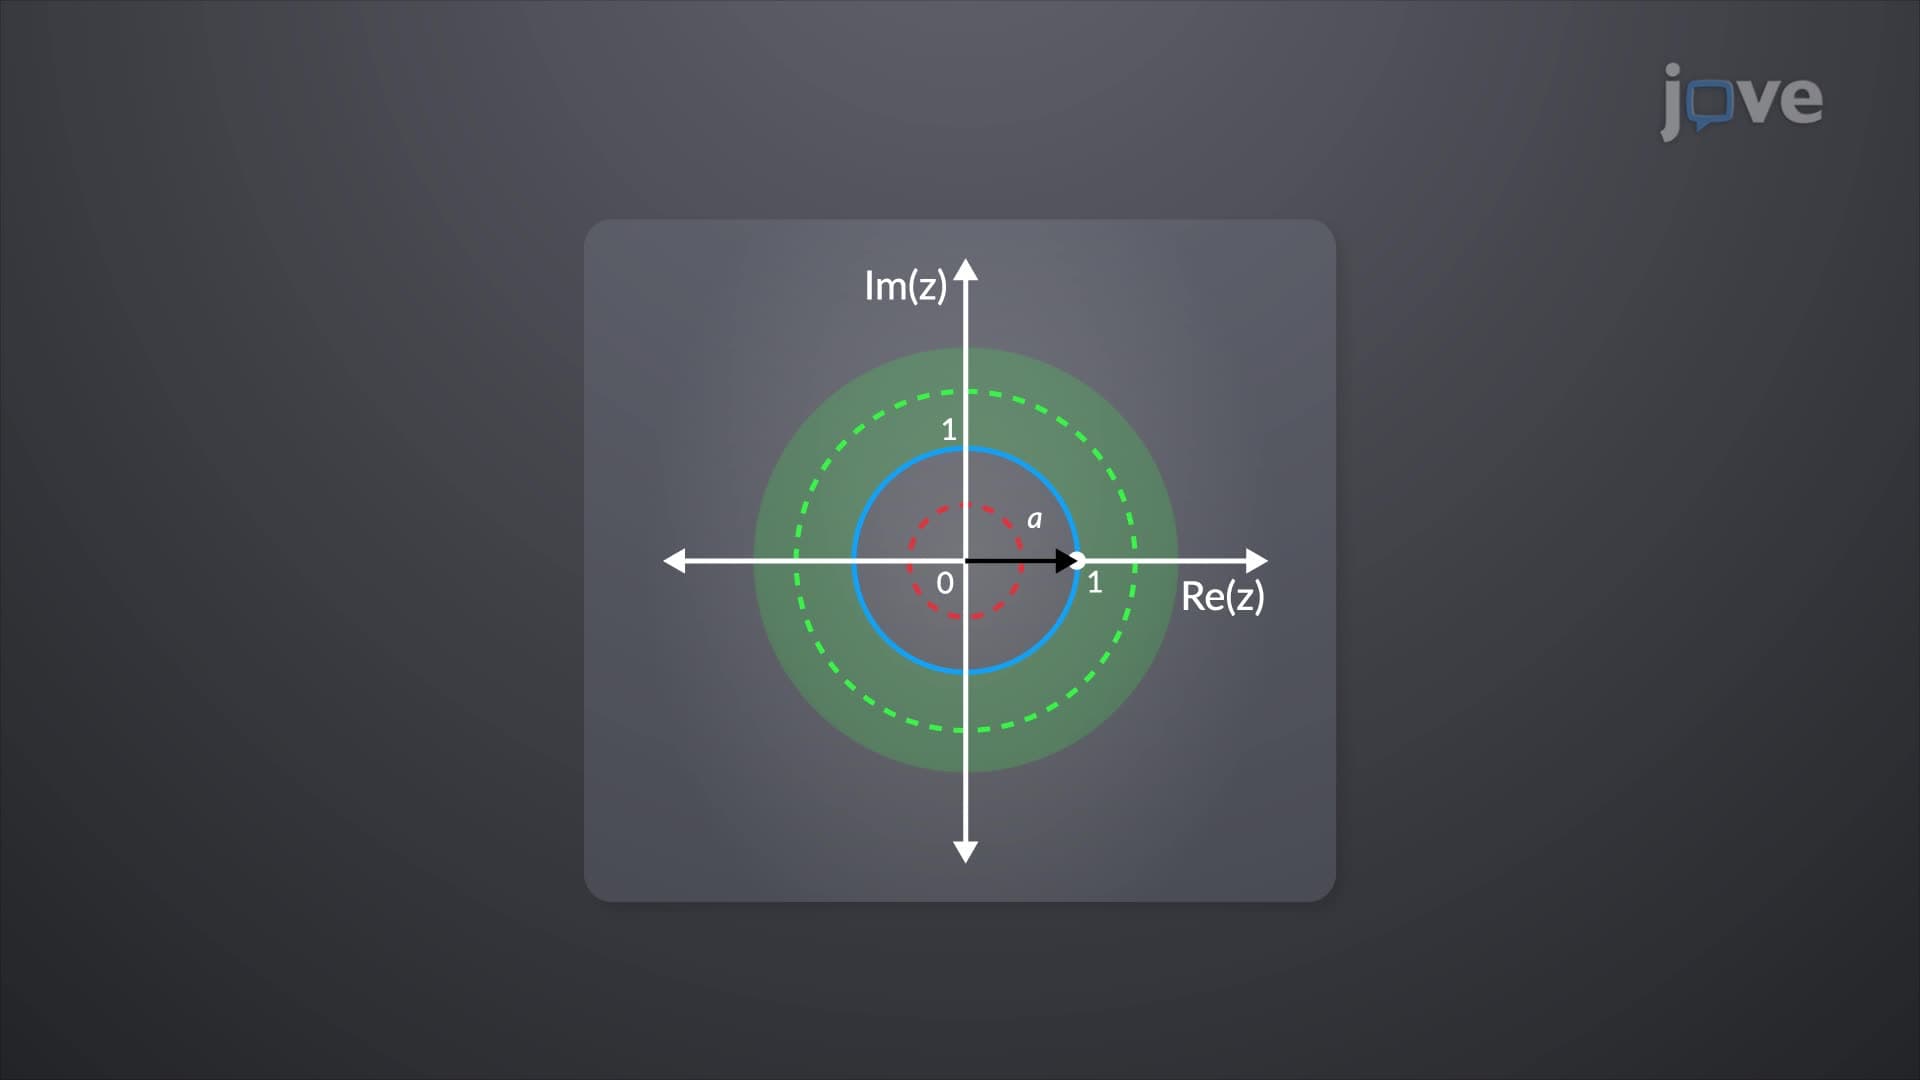
The z-transform is a powerful mathematical tool used in the analysis of discrete-time signals and systems. It is a crucial tool in the analysis of discrete-time systems, but its convergence is limited to specific values of the complex variable z. This range of values, known as the Region of Convergence (ROC), is fundamental in determining the behavior and stability of a system or signal. The ROC defines the region in the complex plane where the z-transform converges, which can take various...
577