
时间尺度上的延迟TS模糊系统的事件触发的有限时间稳定
IEEE transactions on cybernetics
|June 11, 2025

概括
本研究为时间尺度延迟的Takagi-Sugeno (T-S) 模糊系统提供事件触发的有限时间稳定. 这种新的方法简化了控制器,节约了资源,而不需要时间延迟的可区分性.
科学领域:
- 控制系统工程 控制系统工程
- 模糊逻辑系统 模糊逻辑系统
- 非线性控制理论 不线性控制理论
背景情况:
- 塔卡吉-苏杰诺 (T-S) 模糊系统被广泛用于模拟非线性动力学.
- 对于需要快速融合的系统,有限时间稳定至关重要.
- 时间延迟系统在控制设计和分析方面存在独特的挑战.
研究的目的:
- 为时间尺度延迟的TS模糊系统开发事件触发的有限时间稳定标准.
- 设计一个简单的控制器,避免电源功能和延迟状态反.
- 建立一个统一的框架来对这些系统进行有限时间分析.
主要方法:
- 使用比较策略和不平等技术.
- 应用时间尺度理论进行系统分析.
- 开发一个事件触发机制,以减少通信负载.
主要成果:
- 在不需要时间延迟可分化的情况下,推导出有限时间稳定标准.
- 提出了一个简单的控制器结构.
- 该框架统一连续时间和离散时间分析.
- 事件触发机制有效地避免了Zeno行为,并节约了资源.
结论:
- 拟议的方法可以实现事件触发的有限时间稳定,用于时间尺度延迟的TS模糊系统.
- 控制器设计简化,资源效率高.
- 统一框架为分析时间延迟系统提供了更广泛的适用性.
相关概念视频
 01:28
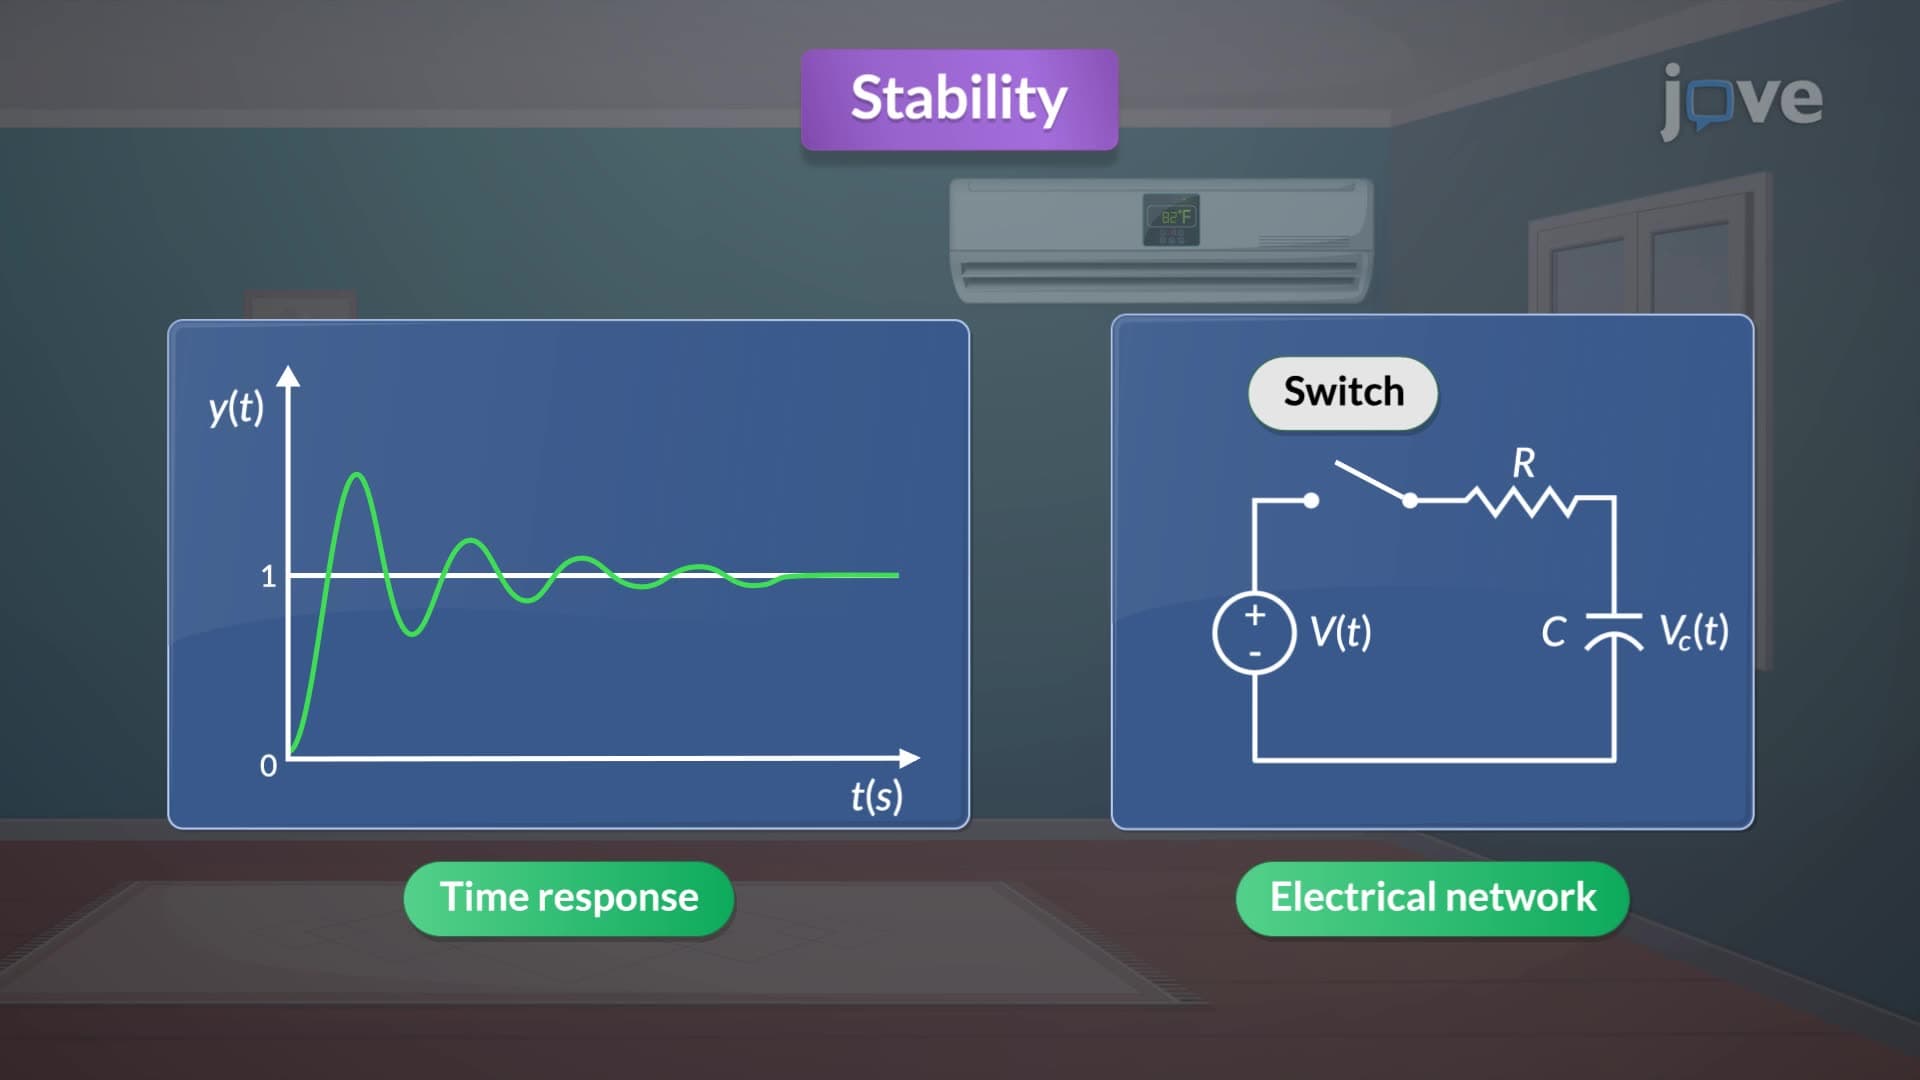
Stability
97
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
97
 01:24
Transient and Steady-state Response
162
In control systems, test signals are essential for evaluating performance under various conditions. The ramp function is effective for systems undergoing gradual changes, while the step function is suitable for assessing systems facing sudden disturbances. For systems subjected to shock inputs, the impulse function is the most appropriate test signal.
These test signals are integral in designing control systems to exhibit two key performance aspects: transient response and steady-state...
These test signals are integral in designing control systems to exhibit two key performance aspects: transient response and steady-state...
162
 01:20
Discrete-Time Fourier Series
234
The Discrete-Time Fourier Series (DTFS) is a fundamental concept in signal processing, serving as the discrete-time counterpart to the continuous-time Fourier series. It allows for the representation and analysis of discrete-time periodic signals in terms of their frequency components. Unlike its continuous counterpart, which utilizes integrals, the calculation of DTFS expansion coefficients involves summations due to the discrete nature of the signal.
For a discrete-time periodic signal x[n]...
For a discrete-time periodic signal x[n]...
234
 01:07
Time-Domain Interpretation of PD Control
85
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
85
 01:21
Linear Approximation in Time Domain
70
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
70
 01:21
First Order Systems
87
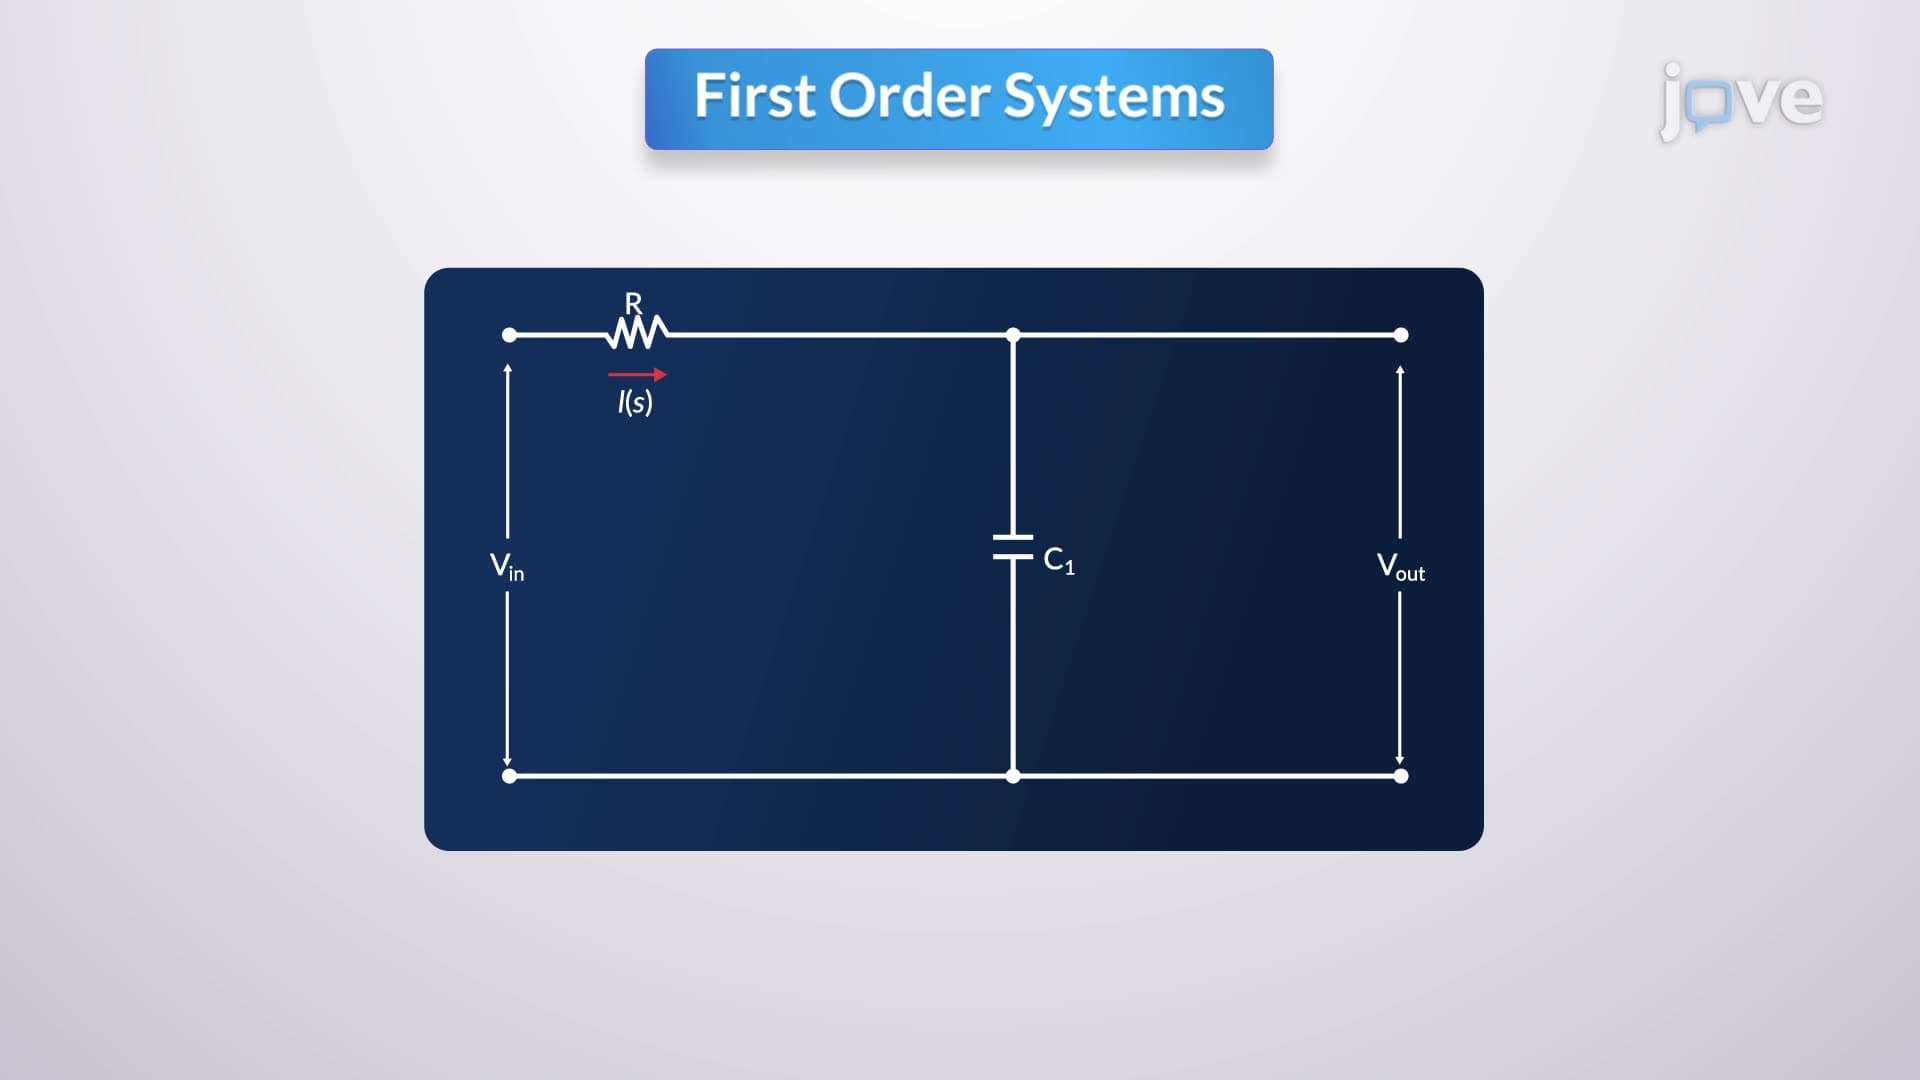
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
87