
在固定漂移期间,运动感知中的不连续性
bioRxiv : the preprint server for biology
|June 12, 2025

概括
人类视觉系统在固定性眼睛漂移期间感知到最小的运动,当刺激与视网膜滑动对齐时. 然而,与眼睛运动相反的刺激被认为是移动的,这种现象受到背景背景的影响.
科学领域:
- 视觉科学 视觉科学 视觉科学
- 神经科学是一个神经科学.
- 感知 感知 感知 感知
背景情况:
- 人类视觉系统通常保持稳定的对象感知,尽管眼睛不断移动.
- 在特定的条件下,例如固定漂移,运动感知可以减少,特别是当图像运动与视网膜滑动保持一致时.
研究的目的:
- 为了调查是否与视网膜滑动一致移动的刺激,即使在降低的大小,也被认为是稳定的.
- 探索背景参考框架在眼睛漂移期间对运动感知的影响.
主要方法:
- 使用自适应光学扫描光眼镜来呈现刺激.
- 刺激的运动取决于实时视网膜运动.
- 在有或没有世界固定背景内容的条件下测量感知运动,在不同距离.
主要成果:
- 观察到运动感知的一个明显的门.
- 随着视网膜滑动移动的刺激被认为几乎没有运动,无论大小如何.
- 与眼睛运动相同的方向移动的刺激被认为是移动的.
- 当背景内容与刺激相距超过4度时,效果会降低.
结论:
- 当图像运动与固定漂移期间的视网膜滑动相匹配时,视觉系统对稳定性表现出强烈的偏差.
- 运动的感知高度依赖于刺激运动,眼睛运动和背景视觉线索的存在/距离之间的关系.
相关概念视频
 01:12
Perceptual Constancy
364
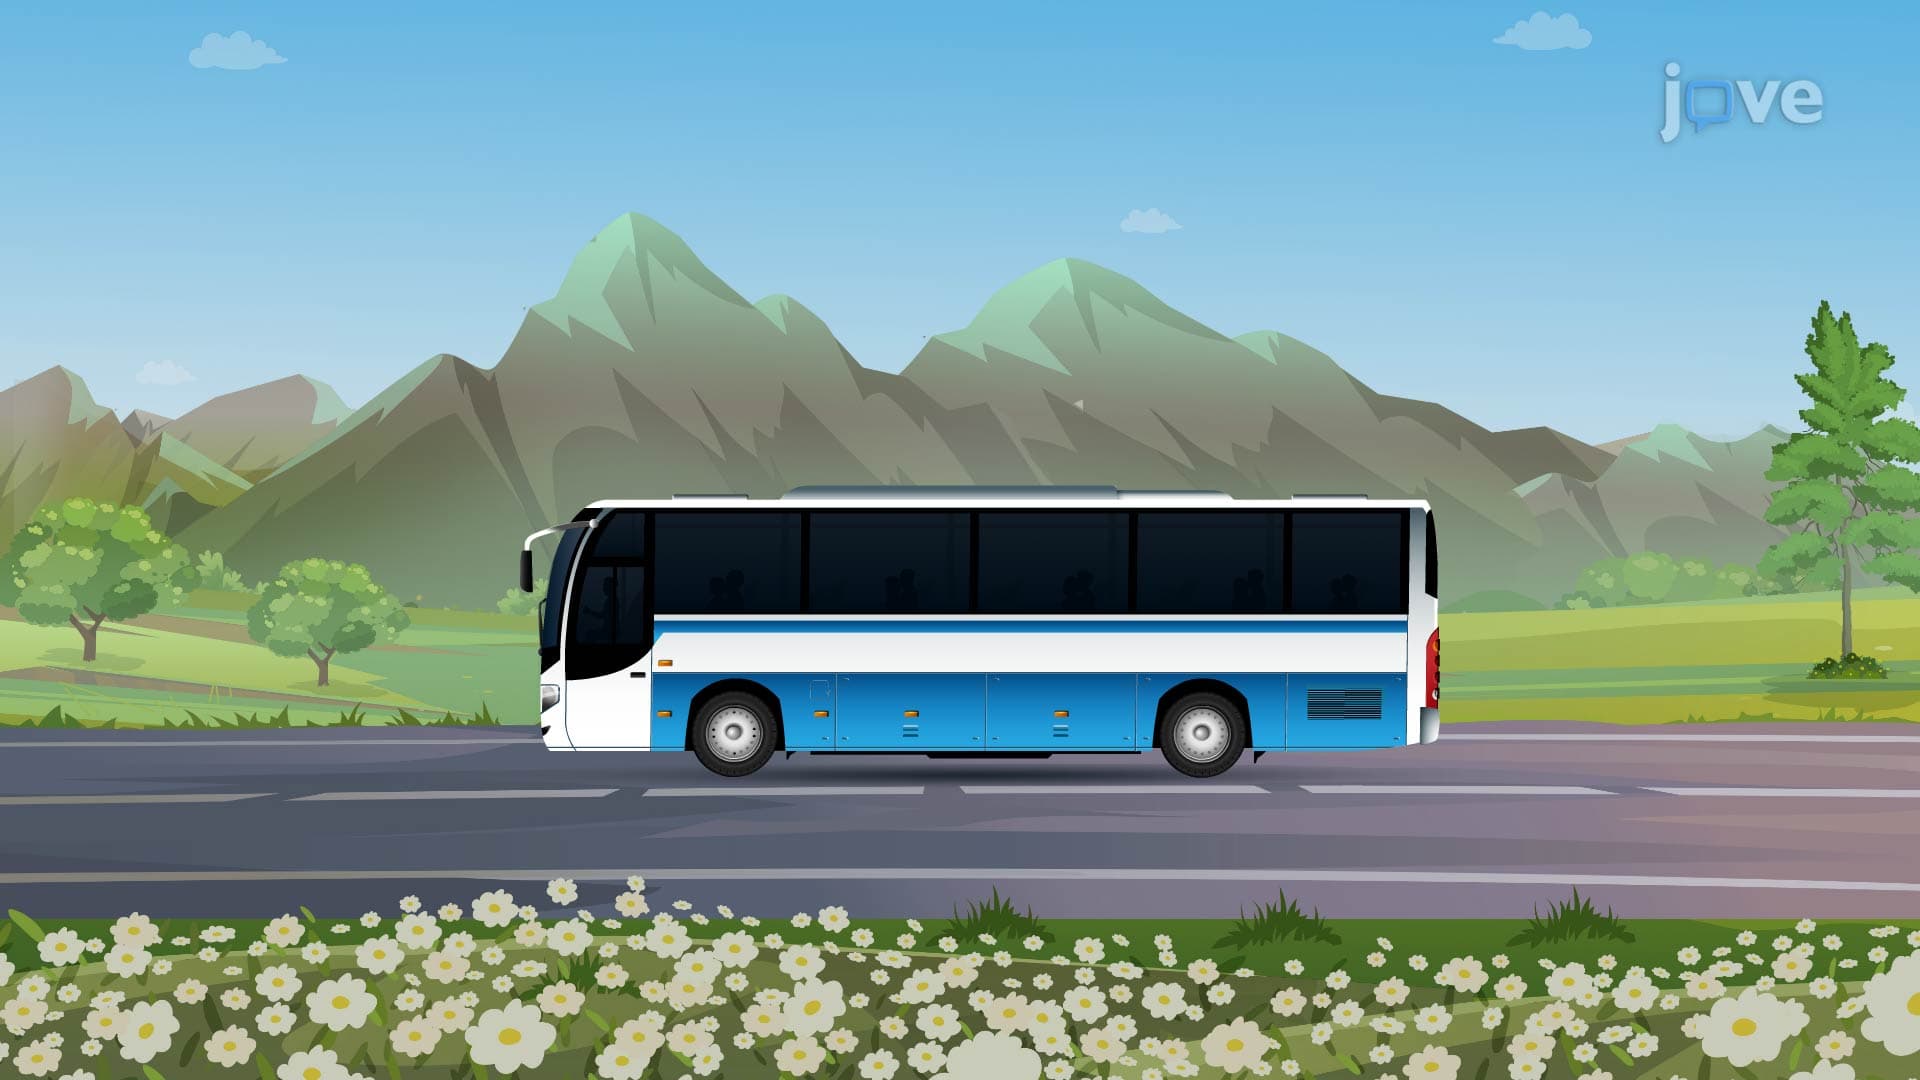
Perceptual constancy is the ability to recognize that objects remain consistent and unchanged even when their appearance varies due to changes in sensory input. There are four main types of perceptual constancy: size constancy, shape constancy, color constancy, and brightness constancy.
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
364
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
391
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
391
 01:25
Relative Motion Analysis using Rotating Axes
450
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
450
 01:15
Depth Perception and Spatial Vision
605
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
605
 01:24
Relative Motion Analysis - Velocity
343
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
343
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
327
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
327