
用物理前置和AWConv在雾天气中对交通场景进行对象检测

概括
这项研究引入了一种使用自适应重量卷积 (AWConv) 的新物体检测方法,以提高雾条件下的性能. 该方法提高了特征的可见性和提取性,从而在恶劣天气下提高了自动驾驶的准确性.
科学领域:
- 计算机视觉 计算机视觉
- 人工智能的人工智能
- 自主驾驶系统 自主驾驶系统
背景情况:
- 在交通场景中对象检测面临挑战,特别是在雾天气中,由于可见度降低和功能信息减弱.
- 频繁出现的雾天气需要强大的物体检测方法来确保安全的自主操作.
研究的目的:
- 开发和评估一个物体检测方法,有效地处理恶劣的天气条件,特别是雾.
- 增强特征提取和表示能力,在具有挑战性的可见性场景中提高检测准确性.
主要方法:
- 提出了一种物体检测方法,包括物理先验和适应性重量卷积 (AWConv).
- 在改进的脱雾算法中应用了马校正,以增强图像区域和特征分离性.
- 利用自适应权重机制来提高模型的特征提取和表示能力.
主要成果:
- 拟议的方法证明了对诸如雾城市景观和RTTS等数据集的性能有所改善.
- 一个小型模型变体在雾城市景观上实现了1.4%的平均平均精度 (mAP) 增加,计算成本低 (24.6 GFLOPs).
- 在RTTS数据集上,该方法减少了GFLOPs3.8%,并提高了回忆 (R) 1.1%.
结论:
- 开发的物体检测方法在雾和恶劣天气条件下显示出显著的有效性和稳定性.
- 该研究强调,图像质量和检测准确性并不总是线性相关.
- 这种方法为提高自动驾驶系统在恶劣天气中的可靠性提供了一个有希望的解决方案.

相关概念视频
 01:05
Difference from Background: Limit of Detection
7.1K
The limit of detection (LOD) is the smallest amount of analyte that can be distinguished from the background noise. The LOD value corresponds to the concentration at which the analyte signal is three times larger than the standard deviation of the blank signal. Below this value, the analyte signal cannot be differentiated from the background noise. It is calculated by dividing the calibration slope by 3 times the standard deviation of the blank signals.
The LOD indicates the presence or absence...
The LOD indicates the presence or absence...
7.1K
 02:16
Light Acquisition
8.6K
In order to produce glucose, plants need to capture sufficient light energy. Many modern plants have evolved leaves specialized for light acquisition. Leaves can be only millimeters in width or tens of meters wide, depending on the environment. Due to competition for sunlight, evolution has driven the evolution of increasingly larger leaves and taller plants, to avoid shading by their neighbors with contaminant elaboration of root architecture and mechanisms to transport water and nutrients.
8.6K
 01:20
Deconvolution
263
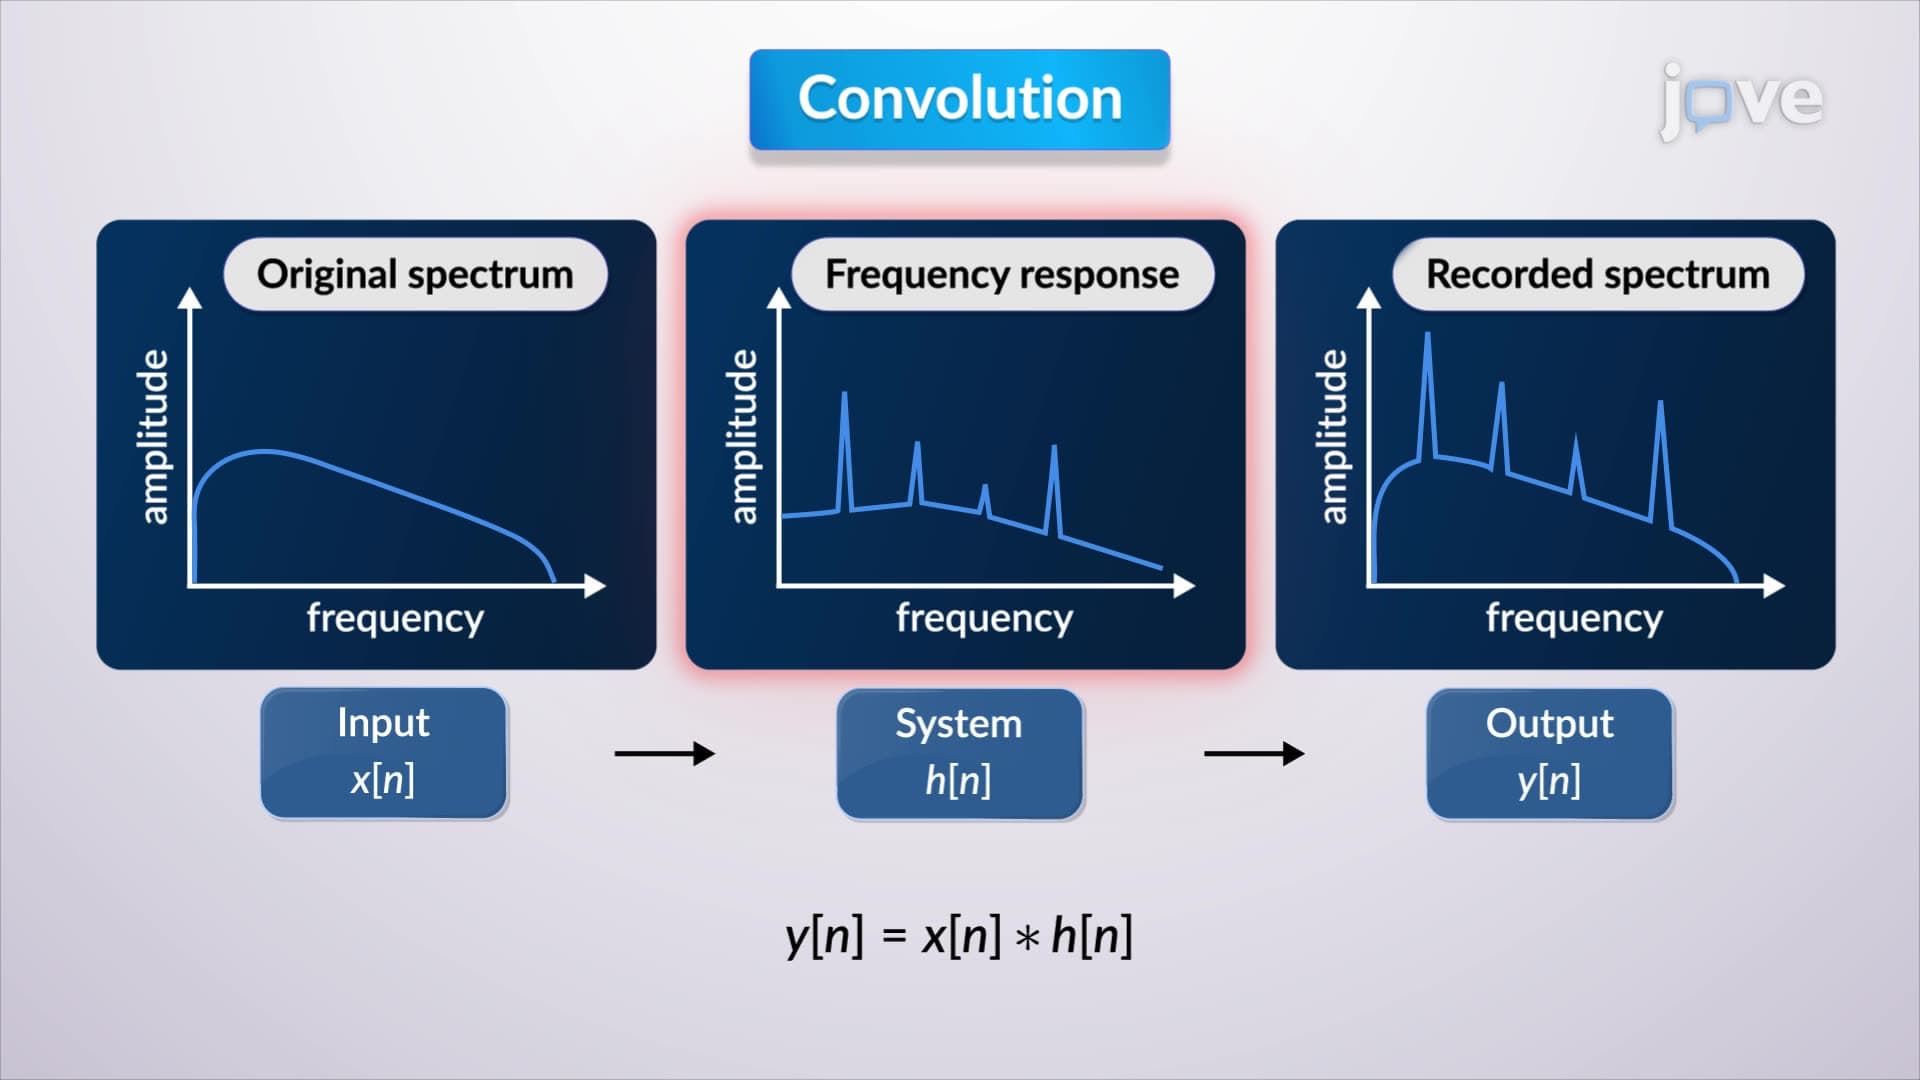
Deconvolution, also known as inverse filtering, is the process of extracting the impulse response from known input and output signals. This technique is vital in scenarios where the system's characteristics are unknown, and they must be inferred from the observable signals.
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
263
 01:21
Association Areas of the Cortex
6.4K
Association areas are regions of the cerebral cortex that do not have a specific sensory or motor function. Instead, they integrate and interpret information from various sources to enable higher cognitive processes such as memory, learning, and decision-making. Some key association areas include the following:
Prefrontal Association Area: This area is located in the frontal lobe and is involved in planning, decision-making, and moderating social behavior. It connects with primary motor areas,...
Prefrontal Association Area: This area is located in the frontal lobe and is involved in planning, decision-making, and moderating social behavior. It connects with primary motor areas,...
6.4K
 01:12
Perceptual Constancy
583
Perceptual constancy is the ability to recognize that objects remain consistent and unchanged even when their appearance varies due to changes in sensory input. There are four main types of perceptual constancy: size constancy, shape constancy, color constancy, and brightness constancy.
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
583
 01:22
Force Classification
1.7K
Forces play a crucial role in the study of physics and engineering. They are essential in describing the motion, behavior, and equilibrium of objects in the physical world. Forces can be classified based on their origin, type, and direction of action.
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
1.7K