
接近弱和强合的领先跟随系统的分支图
S Sinet1, R Bastiaansen1,2, C Kuehn3
1Department of Physics, Institute for Marine and Atmospheric Research Utrecht, Utrecht University, Utrecht, The Netherlands.
Chaos (Woodbury, N.Y.)
|June 20, 2025

概括
在合动态系统中可以发生级联的关键过渡. 本研究开发了对复杂,非线性交互系统的分叉图的近似方法,提供了对气候和生态转折点的见解.
科学领域:
- 复杂系统科学 复杂系统科学
- 气候动力学 气候动力学
- 生态建模 生态建模
背景情况:
- 动态系统可以表现出因分叉引起的倾斜,导致关键过渡.
- 相互作用的系统可能会经历级联倾斜事件,其中一个系统的过渡触发另一个系统的过渡.
研究的目的:
- 研究具有多项式驱动函数的单向合的标量子系统.
- 将分析扩展到线性交互的可比化子系统之外.
- 开发用于在复杂的交互系统中近似分叉图的方法.
主要方法:
- 使用非对称的方法来近似分叉图.
- 分析弱和强合极限.
- 导出平衡分支及其稳定性的近似值.
主要成果:
- 合系统的分叉图的近似值是从解的问题中得出的.
- 均衡分支的稳定性被确定为弱和强合.
- 海洋循环和亚马逊雨林相互作用的概念模型用于说明.
结论:
- 该研究为分析相互作用系统中复杂的倾斜动态提供了一个框架.
- 这些方法提供了对气候和生态环境中潜在的级联关键过渡的洞察力.
- 这些发现适用于理解海洋循环和雨林相互作用等现象.

相关概念视频
 01:19
Plotting and Calibrating the Root Locus
187
Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
187
 01:26
Transmission-Line Differential Equations
414
Transmission lines are essential components of electrical power systems. They are characterized by the distributed nature of resistance (R), inductance (L), and capacitance (C) per unit length. To analyze these lines, differential equations are employed to model the variations in voltage and current along the line.
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
414
 01:26
Linear Approximation in Frequency Domain
139
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
139
 01:18
Second Order systems II
175
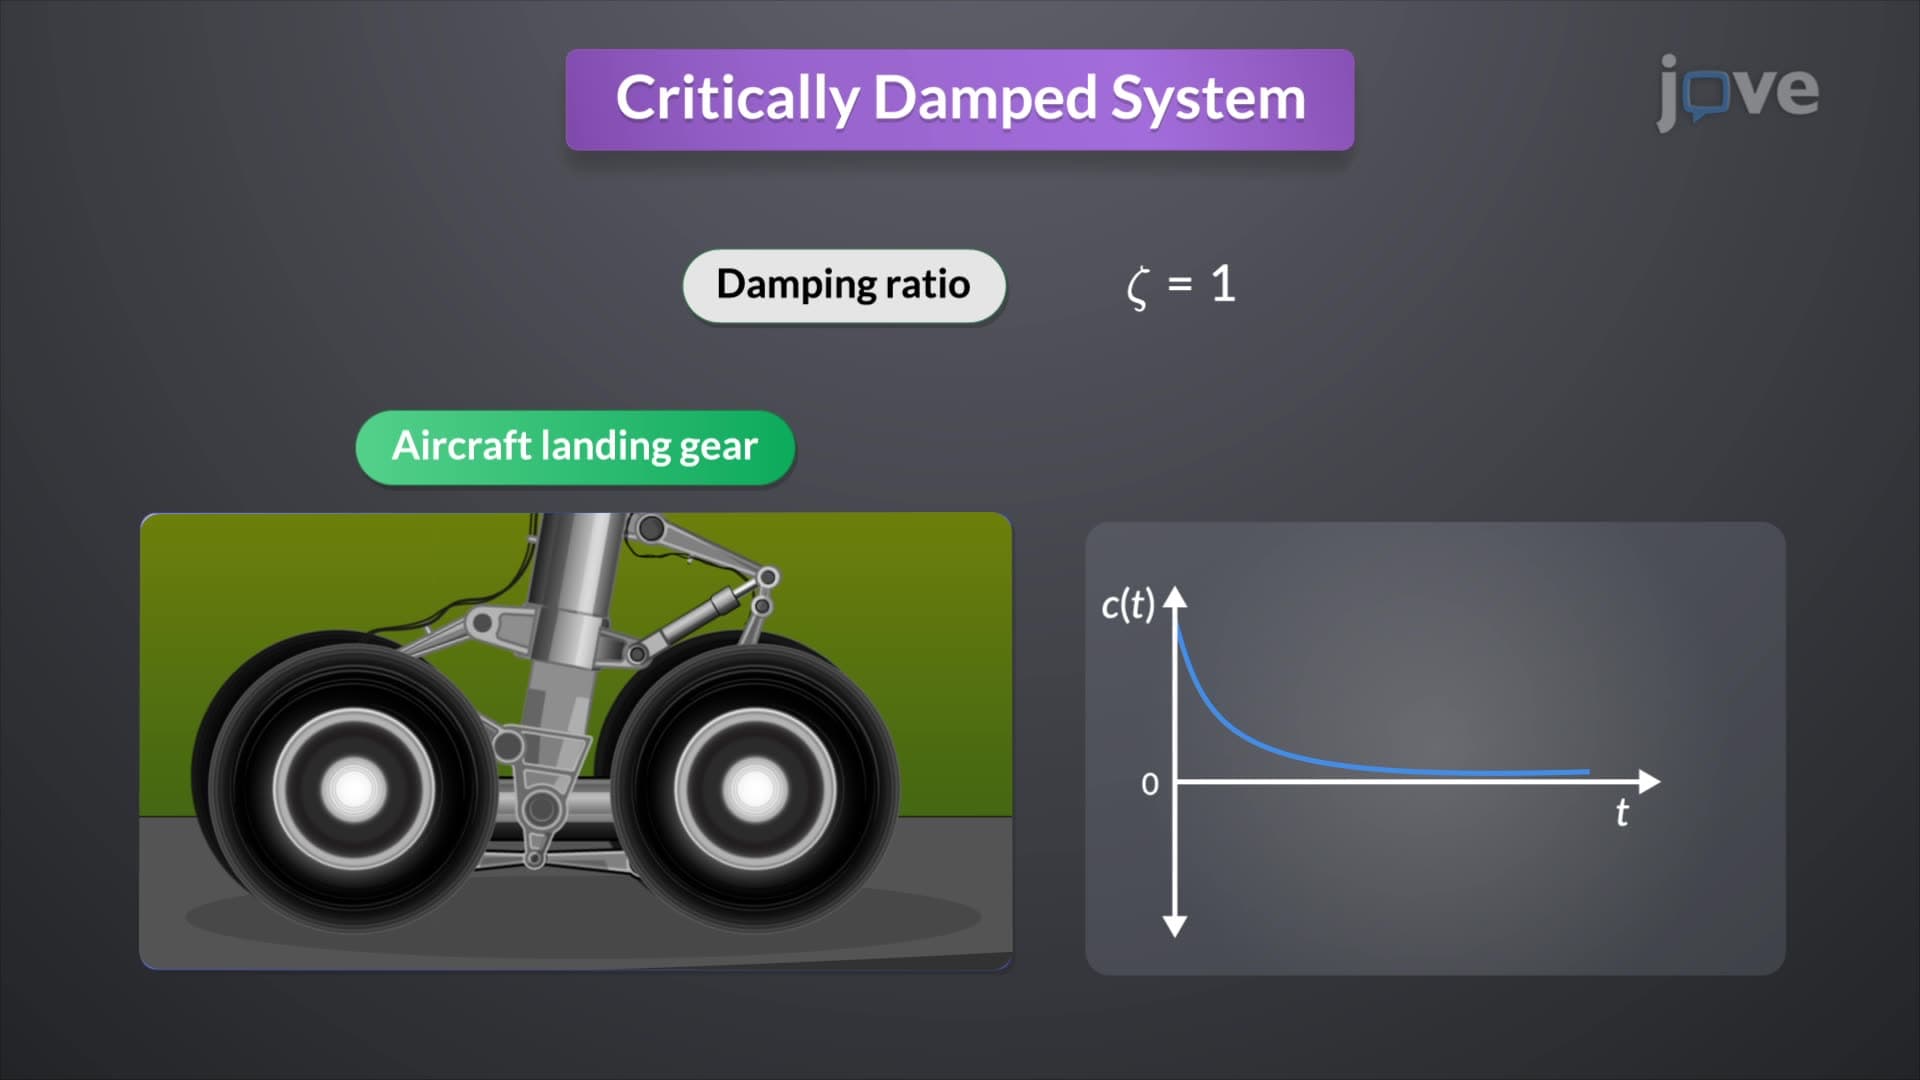
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
175
 01:23
Root Loci for Positive-Feedback Systems
163
The Hartley oscillator is a positive feedback system that sustains oscillations by feeding the output back to the input in phase, thereby reinforcing the signal. Positive feedback systems can be viewed as negative feedback systems with inverted feedback signals. In these systems, the root locus encompasses all points on the s-plane where the angle of the system transfer function equals 360 degrees.
The construction rules for the root locus in positive feedback systems are similar to those in...
The construction rules for the root locus in positive feedback systems are similar to those in...
163
 01:20
Second Order systems I
241
A servo system exemplifies a second-order system, featuring a proportional controller and load elements that ensure the output position aligns with the input position. The relationship between these components is described by a second-order differential equation. Applying the Laplace transform under zero initial conditions yields the transfer function, showing how inputs are converted to outputs in the system.
By reinterpreting the system, one can derive the closed-loop transfer function, which...
By reinterpreting the system, one can derive the closed-loop transfer function, which...
241