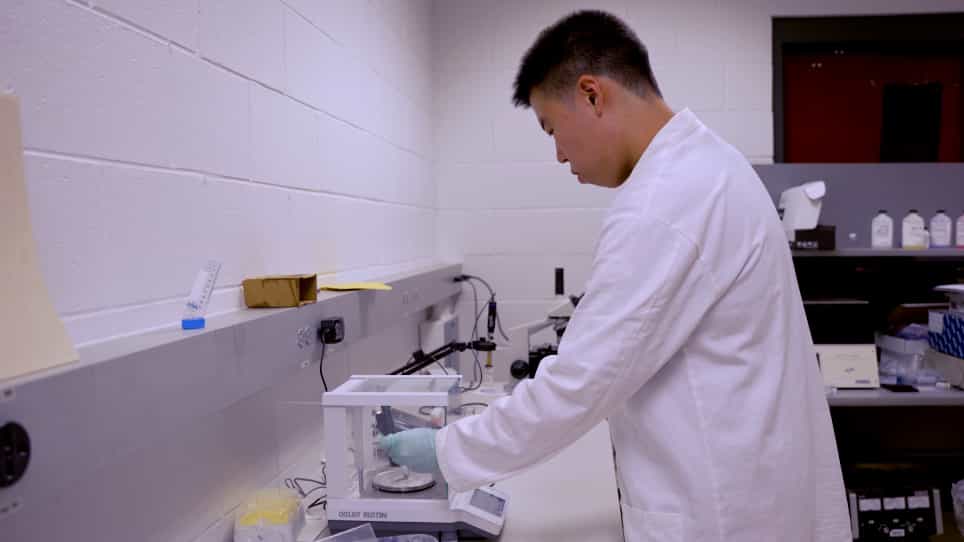

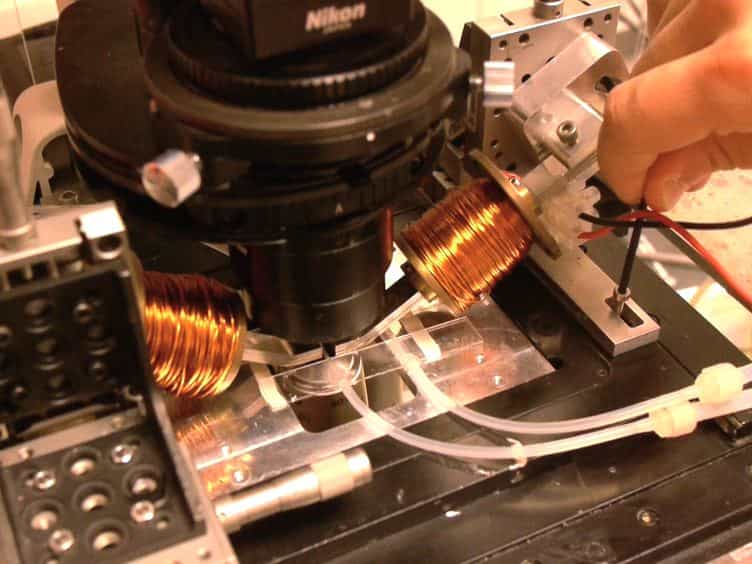
分析磁性配置及其对磁性驱动的软微型机器人的运动的影响,这些机器人处于管状封闭状态
Afarin Khabbazian1, Mir Behrad Khamesee1, Veronika Magdanz2
1Department of Mechanical and Mechatronics Engineering, University of Waterloo, Waterloo, Ontario Canada.
Journal of micro-bio robotics
|June 24, 2025

概括
由凝甲基酸盐 (GelMa) 水凝制成的软机器人可以在尿道中导航. 类似的机器人比类似螺丝的机器人移动速度快三倍,达到18毫米/秒,显示了医疗应用的潜力.
科学领域:
- 生物医学工程 生物医学工程
- 机器人技术 机器人技术 机器人技术
- 材料科学 材料科学 材料科学
背景情况:
- 柔软的,磁性驱动的机器人由于其灵活性和可控性,为医疗应用提供了巨大的潜力.
- 这些机器人可以简单地制造,并且能够承载载荷.
- 它们在导航复杂的生物环境中的应用,比如人类尿道,是研究的一个关键领域.
研究的目的:
- 设计,建模和分析用于尿路导航的软的,毫米尺度的有线性机器人的行为.
- 为了研究两个不同的机器人配置:类似螺丝和类似的.
- 探索微磁铁放置对机器人推进动力学的影响.
主要方法:
- 使用嵌入微磁铁的凝甲基酸盐 (GelMa) 水凝制造软机器人.
- 在外部旋转磁场下的机器人行为的建模和分析.
- 实验频率响应测试用于测量机器人在封闭环境中的速度.
主要成果:
- 与螺丝式机器人相比,在狭窄的空间中,类似的机器人表现出明显更快的运动 (三倍).
- 用类似的机器人实现了高达18毫米/秒的最大速度.
- 发现微磁铁在线丝中的位置会影响推进动力学.
结论:
- 柔软的,磁性驱动的丝状机器人显示出导航狭窄的生物通道,如尿管的希望.
- 类似的配置在狭窄的环境中提供了更高的速度和效率.
- 需要进一步优化,以提高复杂的生物环境中的控制和性能.

相关概念视频
 01:17
Force On A Current Loop In A Magnetic Field
3.4K
Magnetic forces on wires carrying current are most frequently applied in motors. A DC motor is a device that converts electrical energy into mechanical work. In motors, wire loops are enclosed in a magnetic field. When current flows through the loops, the magnetic field applies torque, which causes the shaft to rotate. The direction of the current is reversed once the loop's surface area is lined up with the magnetic field, causing a constant torque on the loop. During the process,...
3.4K
 01:13
Torque On A Current Loop In A Magnetic Field
4.7K
The most common application of magnetic force on current-carrying wires is in electric motors. These consist of loops of wire, which are placed between the magnets with a magnetic field. When current flows through the loops, the magnetic field applies torque, which causes the shaft to rotate, thus converting electrical energy to mechanical energy.
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
4.7K
 01:19
Electro-mechanical Systems
1.2K
Electromechanical systems are intricate configurations that effectively combine electrical and mechanical elements to achieve a desired outcome. Central to many of these systems is the DC motor, a device that converts electrical energy into mechanical motion, enabling various applications ranging from simple fans to complex robotic mechanisms.
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
1.2K
 01:15
Torque Free Motion
570
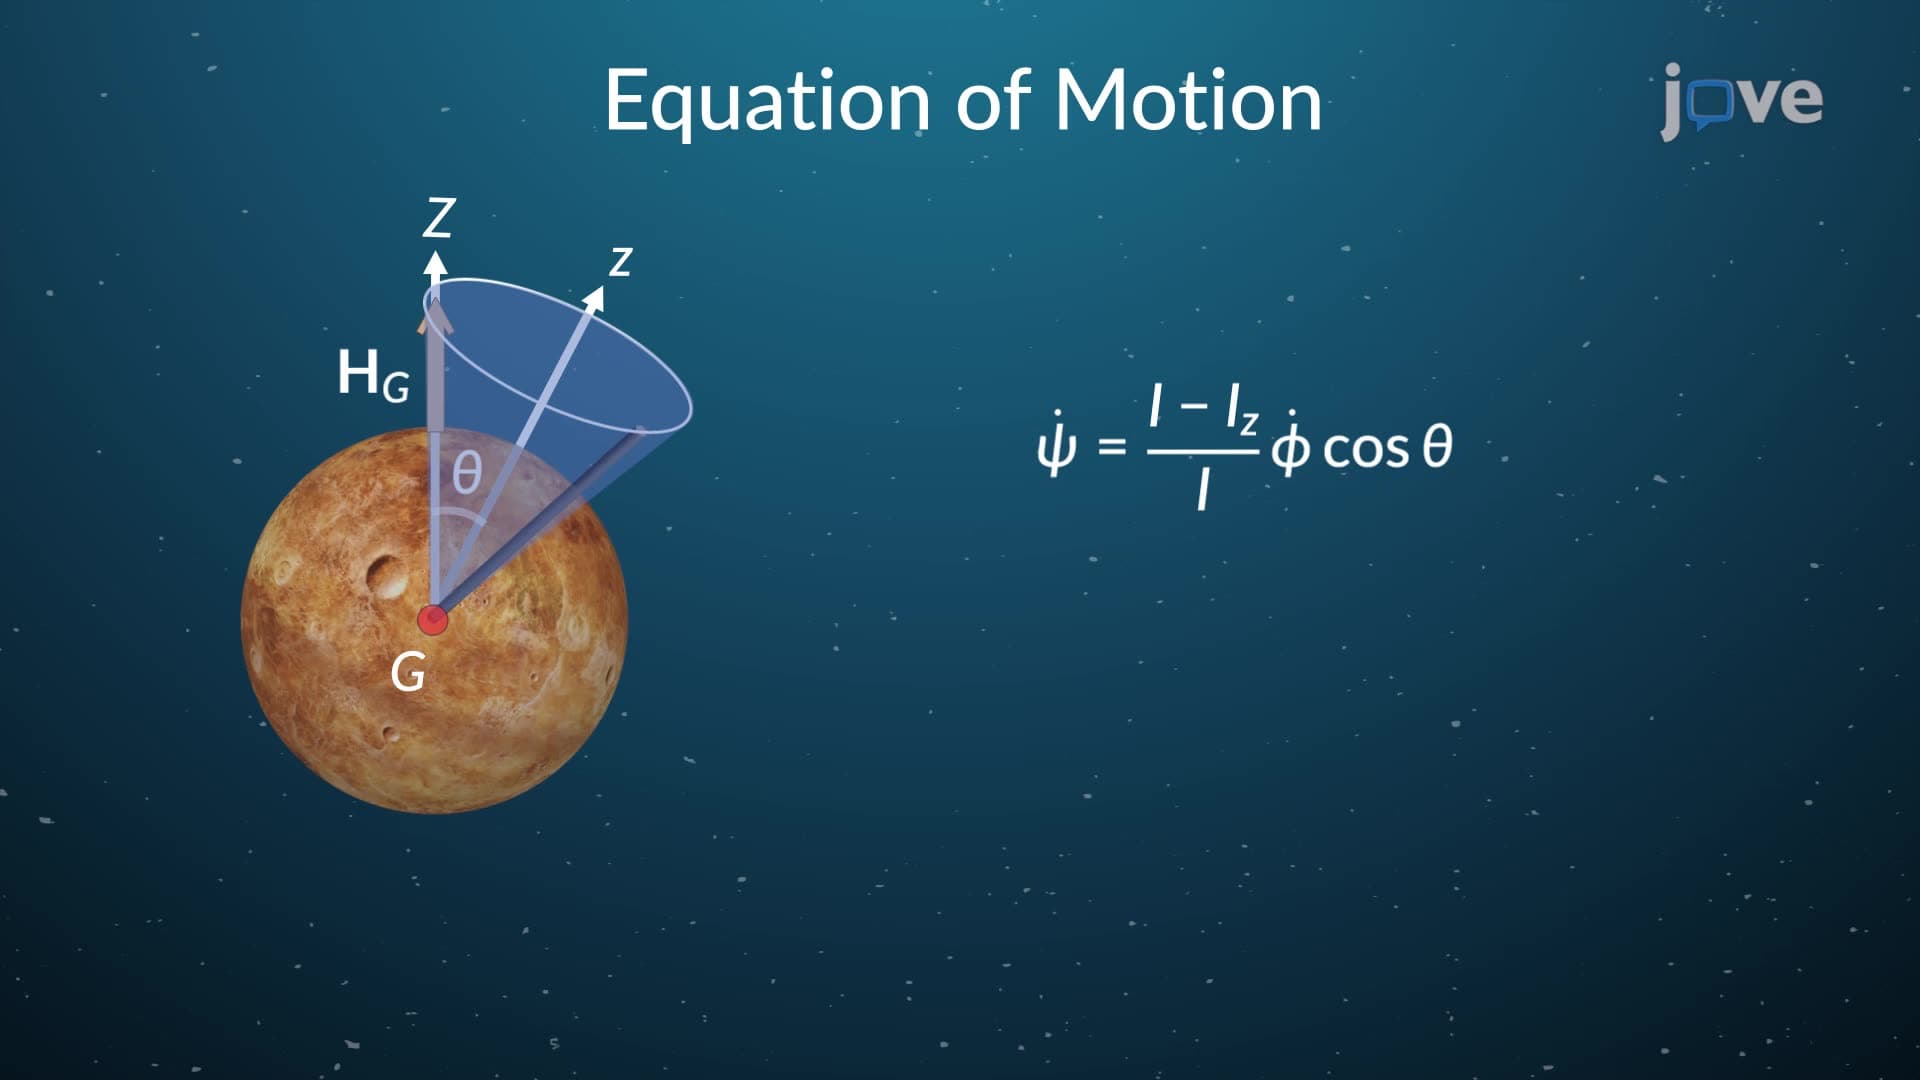
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
570
 01:22
Motional Emf
3.3K
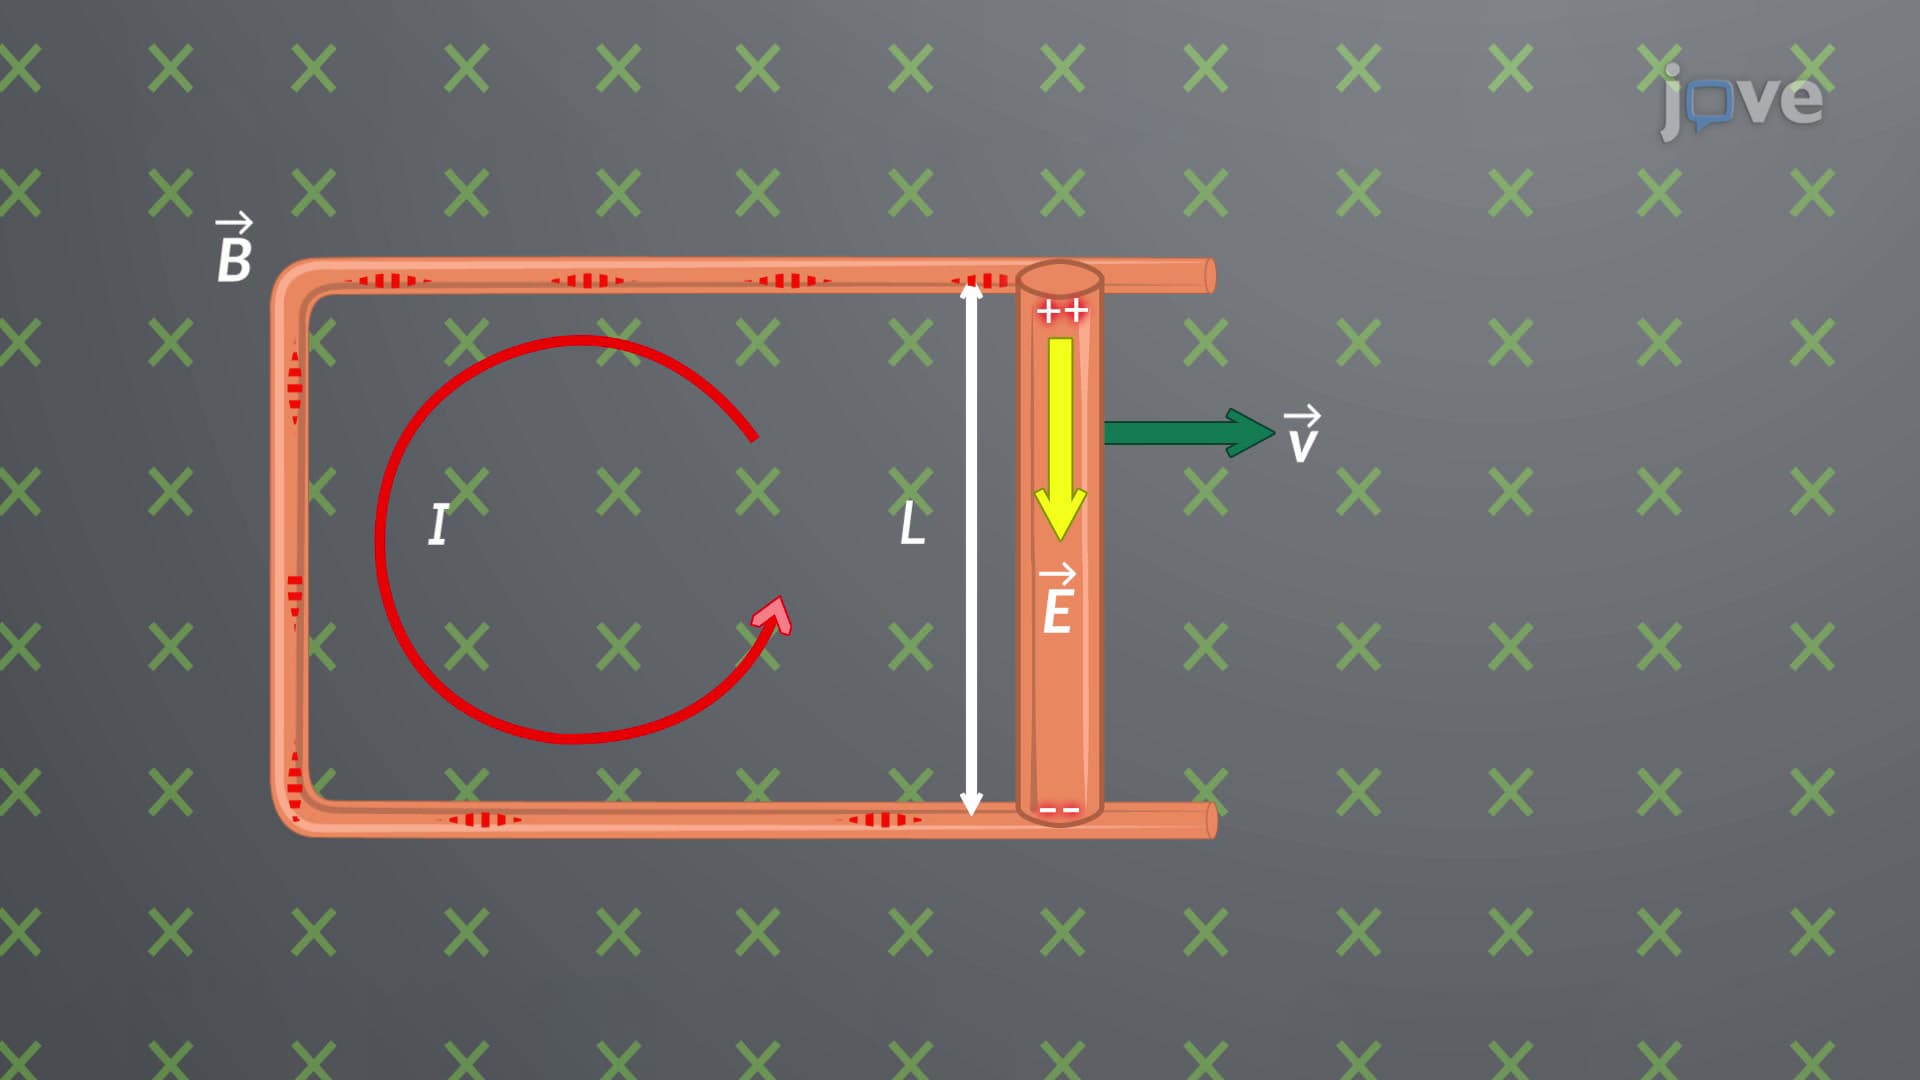
Magnetic flux depends on three factors: the strength of the magnetic field, the area through which the field lines pass, and the field's orientation with respect to the surface area. If any of these quantities vary, a corresponding variation in magnetic flux occurs. If the area through which the magnetic field lines are passing changes, then the magnetic flux also changes. This change in the area can be of two types: the flux through the rectangular loop increases as it moves into the...
3.3K
 01:22
Magnetic Force On Current-Carrying Wires: Example
1.6K
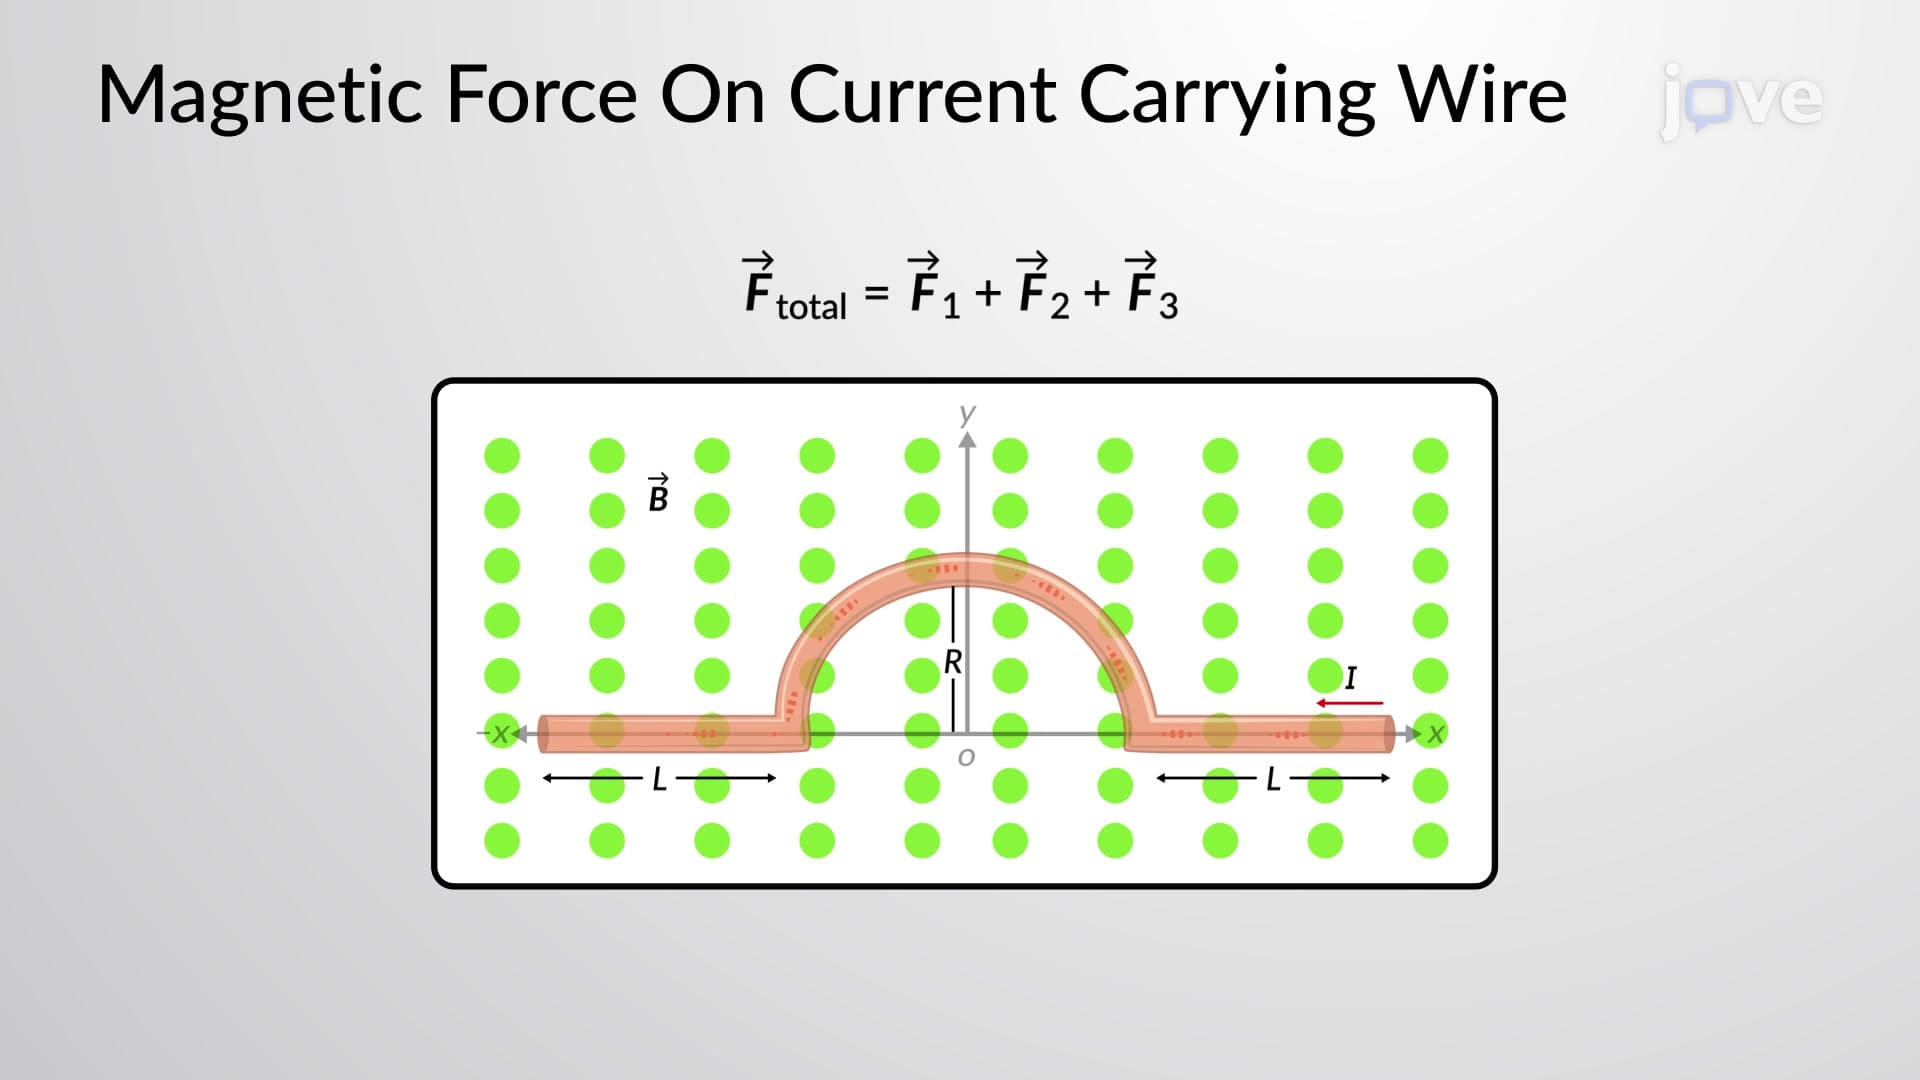
In a magnetic field, moving charges encounter a force. If a wire contains these moving charges, i.e., if the wire is carrying a current, then a force acts on the wire as well. Consider a pair of flexible leads holding a wire that is 40 cm long and 10 g in weight in a horizontal position. The wire is placed in a constant magnetic field of 0.40 T, as shown in Figure 1(a). Determine the magnitude and direction of the current flowing in the wire needed to remove the tension in the supporting leads.
1.6K