相关实验视频
Updated: Sep 18, 2025

Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
通过使用尖端中央模式发生器进行平滑的过渡来增强双腿机器人的运动
Horacio Rostro-Gonzalez1,2, Erick I Guerra-Hernandez3, Patricia Batres-Mendoza3
1GEPI Research Group, IQS-School of Engineering, Ramon Llull University, Via Augusta 390, 08017 Barcelona, Spain.

这项研究引入了一种新的方法,用于在六足动物机器人中使用尖端神经网络 (SNN) 实现无的步态过渡. 该系统通过动态调整运动模式,确保在各种地形上稳定,高效的运动.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 计算神经科学是一种神经科学.
- 控制系统 控制系统
背景情况:
- 有腿的机器人需要适应各种环境的可适应性移动.
- 步态之间的顺过渡对于稳定性和能源效率至关重要.
- 尖端神经网络 (SNN) 为复杂的行为提供了生物启发的控制.
研究的目的:
- 在六足动物机器人中开发一种平滑,无形的步态转换机制.
- 为了保持机器人的平衡,并在运动模式发生变化时提高能源效率.
- 为了实现动态,地形适应步态选择.
主要方法:
- 使用尖端神经网络 (SNN) 作为步行,慢跑和跑步步的中央模式生成器 (CPG).
- 采用SPIKE同步度量来确定最佳步态过渡点.
- 集成FSR传感器来检测地形刚性,以进行动态步态调整.
- 在四种地形类型的物理六足动物机器人上实施实时测试.
主要成果:
- 成功地展示了走路,慢跑和跑步步态之间的平稳和稳定的过渡.
- 实现了几乎不可察觉的步态变化,增强了整体的运动流动性.
- 通过最大限度地减少突然的执行器运动,展示了提高能源效率.
- 通过实时实验验验证了系统对不同地形的适应性.
结论:
- 拟议的基于SNN的CPG与SPIKE同步,可以在六足动物机器人中实现稳健和高效的步态过渡.
- 该系统适应地形刚性的能力提高了其实际适用性.
- 该方法可扩展到其他有腿机器人平台,用于先进的机动控制.
更多相关视频
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
 08:04
Fully Automated Leg Tracking in Freely Moving Insects using Feature Learning Leg Segmentation and Tracking FLLIT
Published on: April 23, 2020
相关概念视频
 01:23
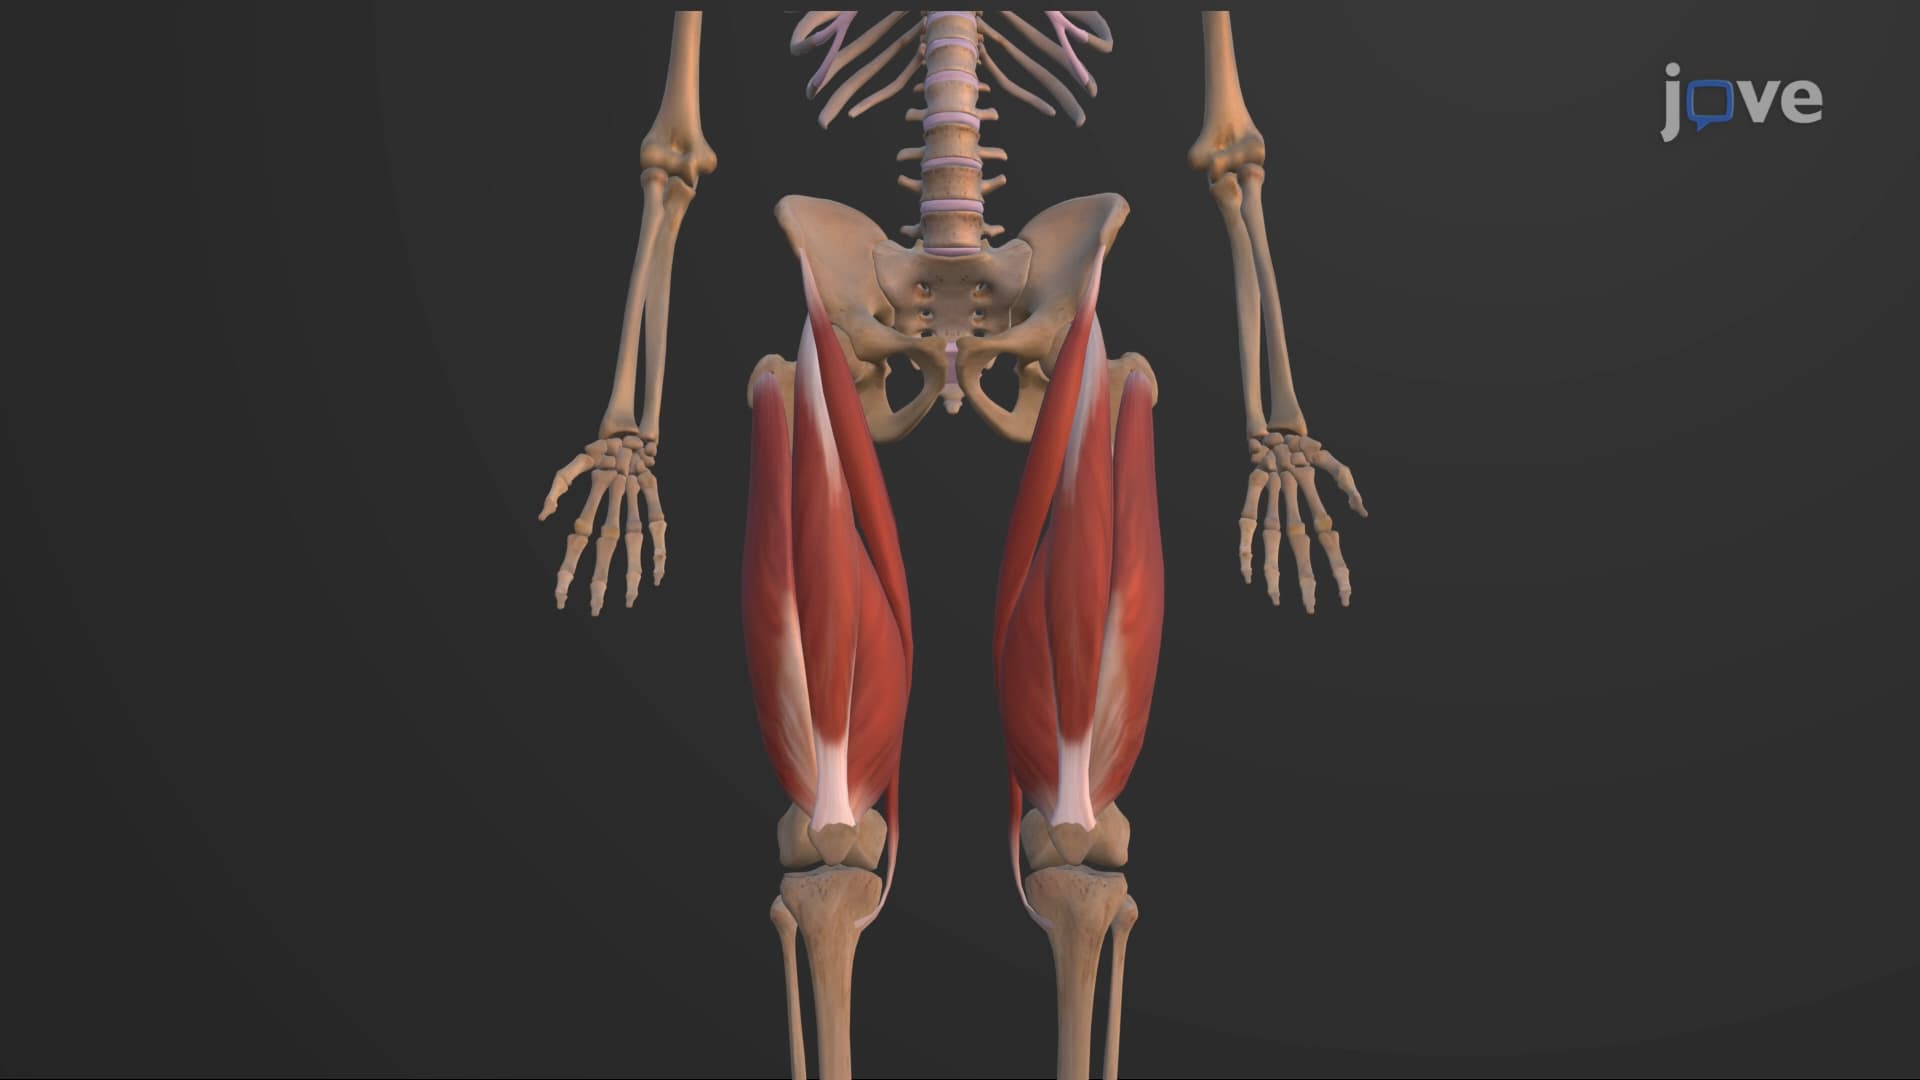
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 01:17
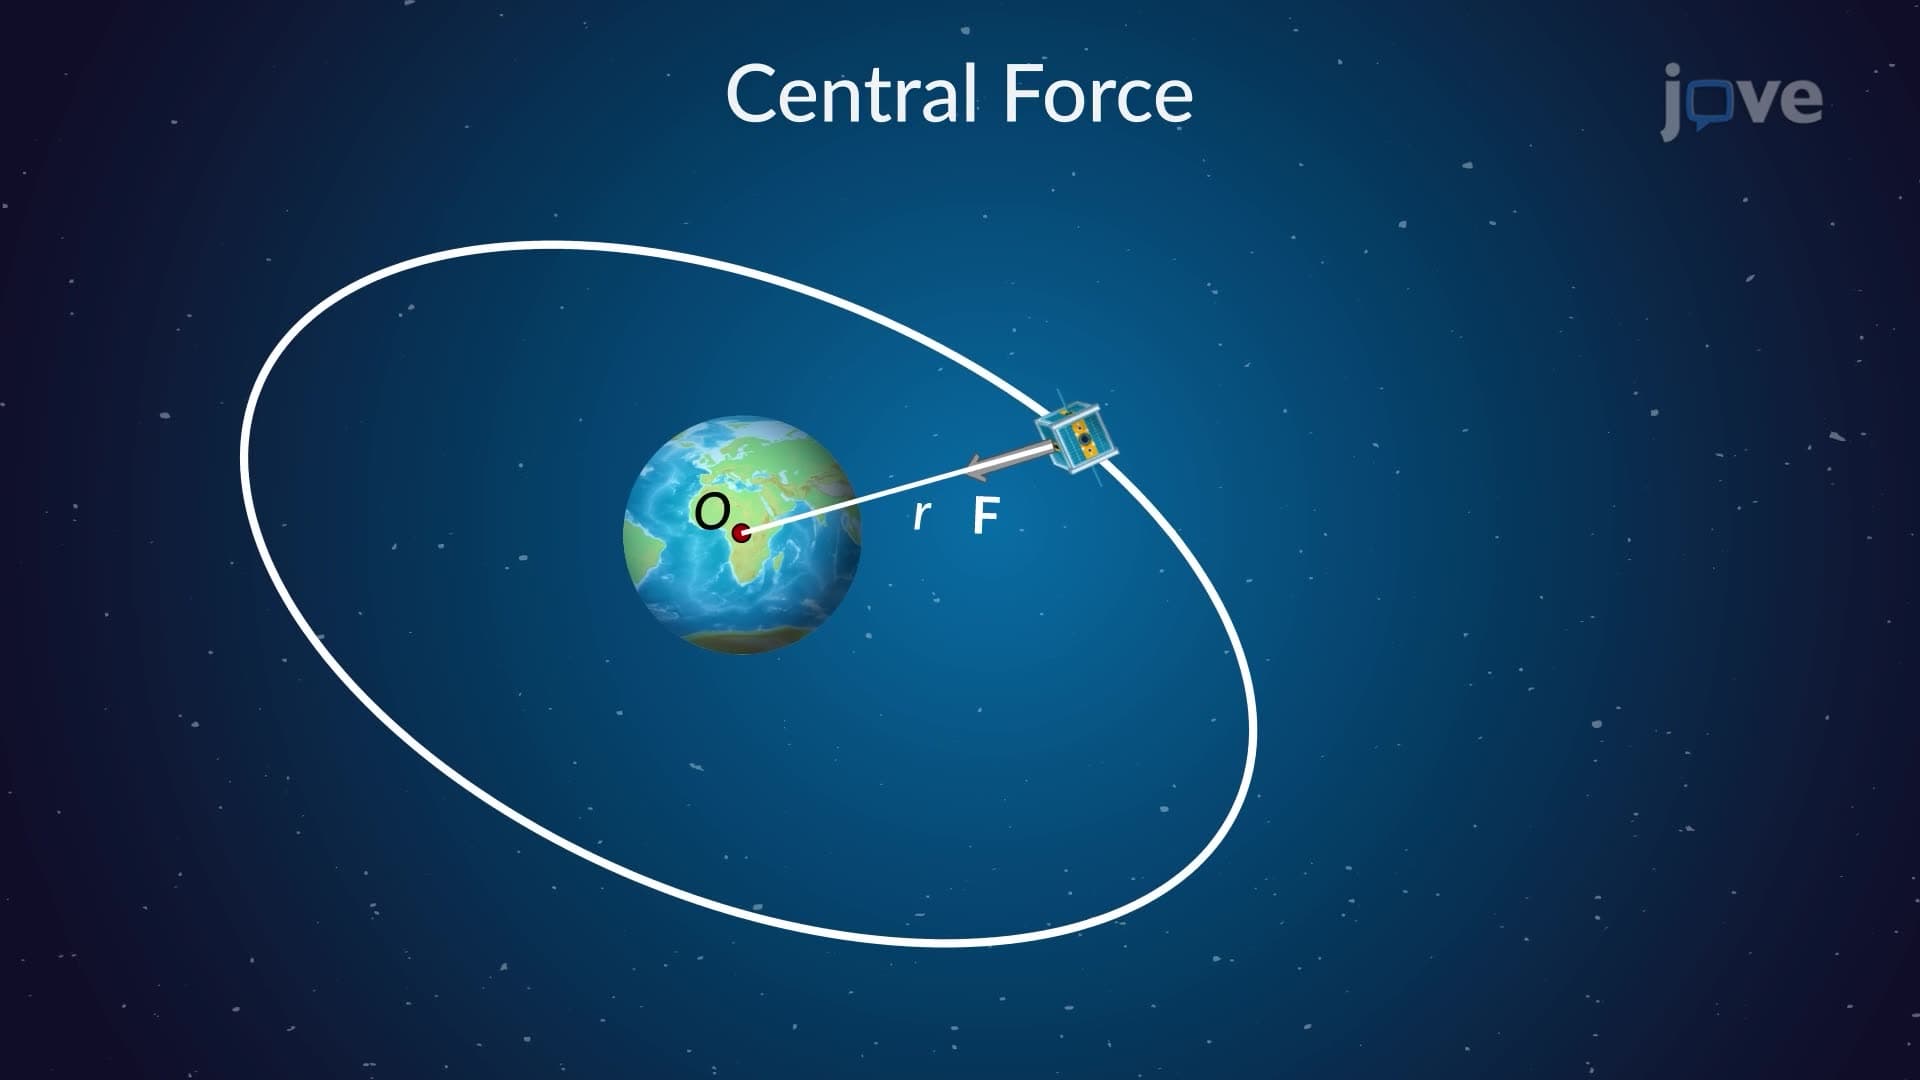
Central-Force Motion
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:11
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...