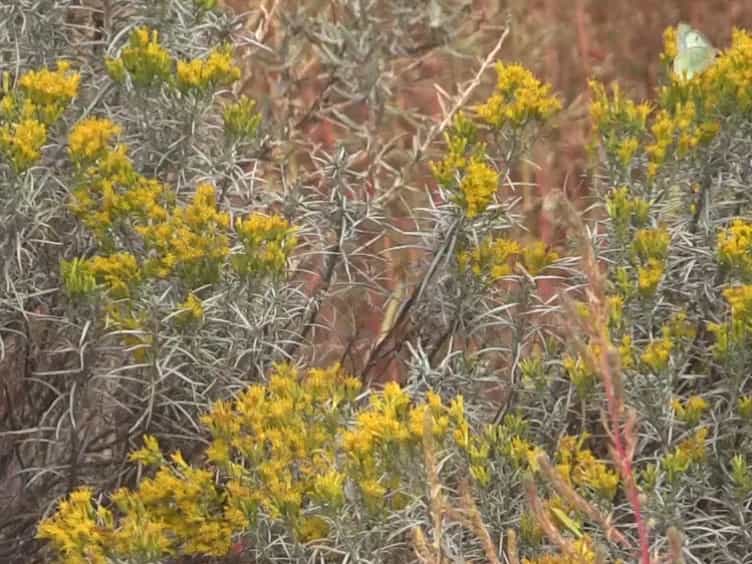

预测一个重要的水果害虫Grapholita dimorpha Komai (Lepidoptera: Tortricidae) 的当前和未来息地分布,使用一个优化的MaxEnt模型
Li Huang1,2, Shichao Zuo1, Yiqi Huo1
1College of Life Science and Agronomy, Zhoukou Normal University, Zhoukou 466001, China.
Insects
|June 25, 2025

概括
主要的果树害虫Grapholita dimorpha,主要在东亚有合适的息地. 预计气候变化将使其范围向北扩大,增加害虫爆发风险.
科学领域:
- 农业昆虫学 农业昆虫学
- 虫害管理 虫害管理 虫害管理
- 生物气候建模模型
背景情况:
- 石墨藻 (Grapholita dimorpha) 是一种重要的挖掘虫害虫害,影响梅,梨和果树,导致水果生产的大量经济损失.
- 人们对G. dimorpha的潜在分布和影响因素的了解仍然不足,这阻碍了有效的害虫防治策略.
研究的目的:
- 用一个优化的最大 (MaxEnt) 模型来预测Grapholita dimorpha的时空分布.
- 确定驱动G. dimorpha.分布的关键生物气候因素.
主要方法:
- 优化最大 (MaxEnt) 模型的模拟.
- 在当前和未来的气候条件下对G. dimorpha分布的时空预测.
- 确定影响害虫分布的关键生物气候变量.
主要成果:
- 在目前的条件下,适合G. dimorpha的息地覆盖东亚273.5×10^4平方公里,主要在中国,韩国和日本.
- 非常适合的息地集中在韩国和日本中部 (19.8 × 10^4 km^2).
- 未来的预测显示,适合地区增加了17.74%62.10%,向北转移,中国和日本的高度适合息地增加.
结论:
- 预测的分布,特别是高度适合的地区,表明G. dimorpha爆发的风险很高,需要优先监测和管理害虫.
- 最干燥的季度 (bio9) 的平均温度和最热的季度 (bio18) 的降水被确定为关键的生物气候驱动因素.
- 鉴定的生物气候变量为有针对性的害虫监测和管理策略提供了宝贵的见解.
相关概念视频
 02:31
Habitat Fragmentation
17.9K
Habitat fragmentation describes the division of a more extensive, continuous habitat into smaller, discontinuous areas. Human activities such as land conversion, as well as slower geological processes leading to changes in the physical environment, are the two leading causes of habitat fragmentation. The fragmentation process typically follows the same steps: perforation, dissection, fragmentation, shrinkage, and attrition.
17.9K
 02:07
Conservation of Declining Populations
9.8K
Conservation of declining population focuses on ways of detecting, diagnosing, and halting a population decline. The approach uses methods to prevent populations from going extinct.
9.8K
 01:20
Maxwell-Boltzmann Distribution: Problem Solving
1.8K
Individual molecules in a gas move in random directions, but a gas containing numerous molecules has a predictable distribution of molecular speeds, which is known as the Maxwell-Boltzmann distribution, f(v).
This distribution function f(v) is defined by saying that the expected number N (v1,v2) of particles with speeds between v1 and v2 is given by
This distribution function f(v) is defined by saying that the expected number N (v1,v2) of particles with speeds between v1 and v2 is given by
1.8K
 01:07
End Point Prediction: Gran Plot
614
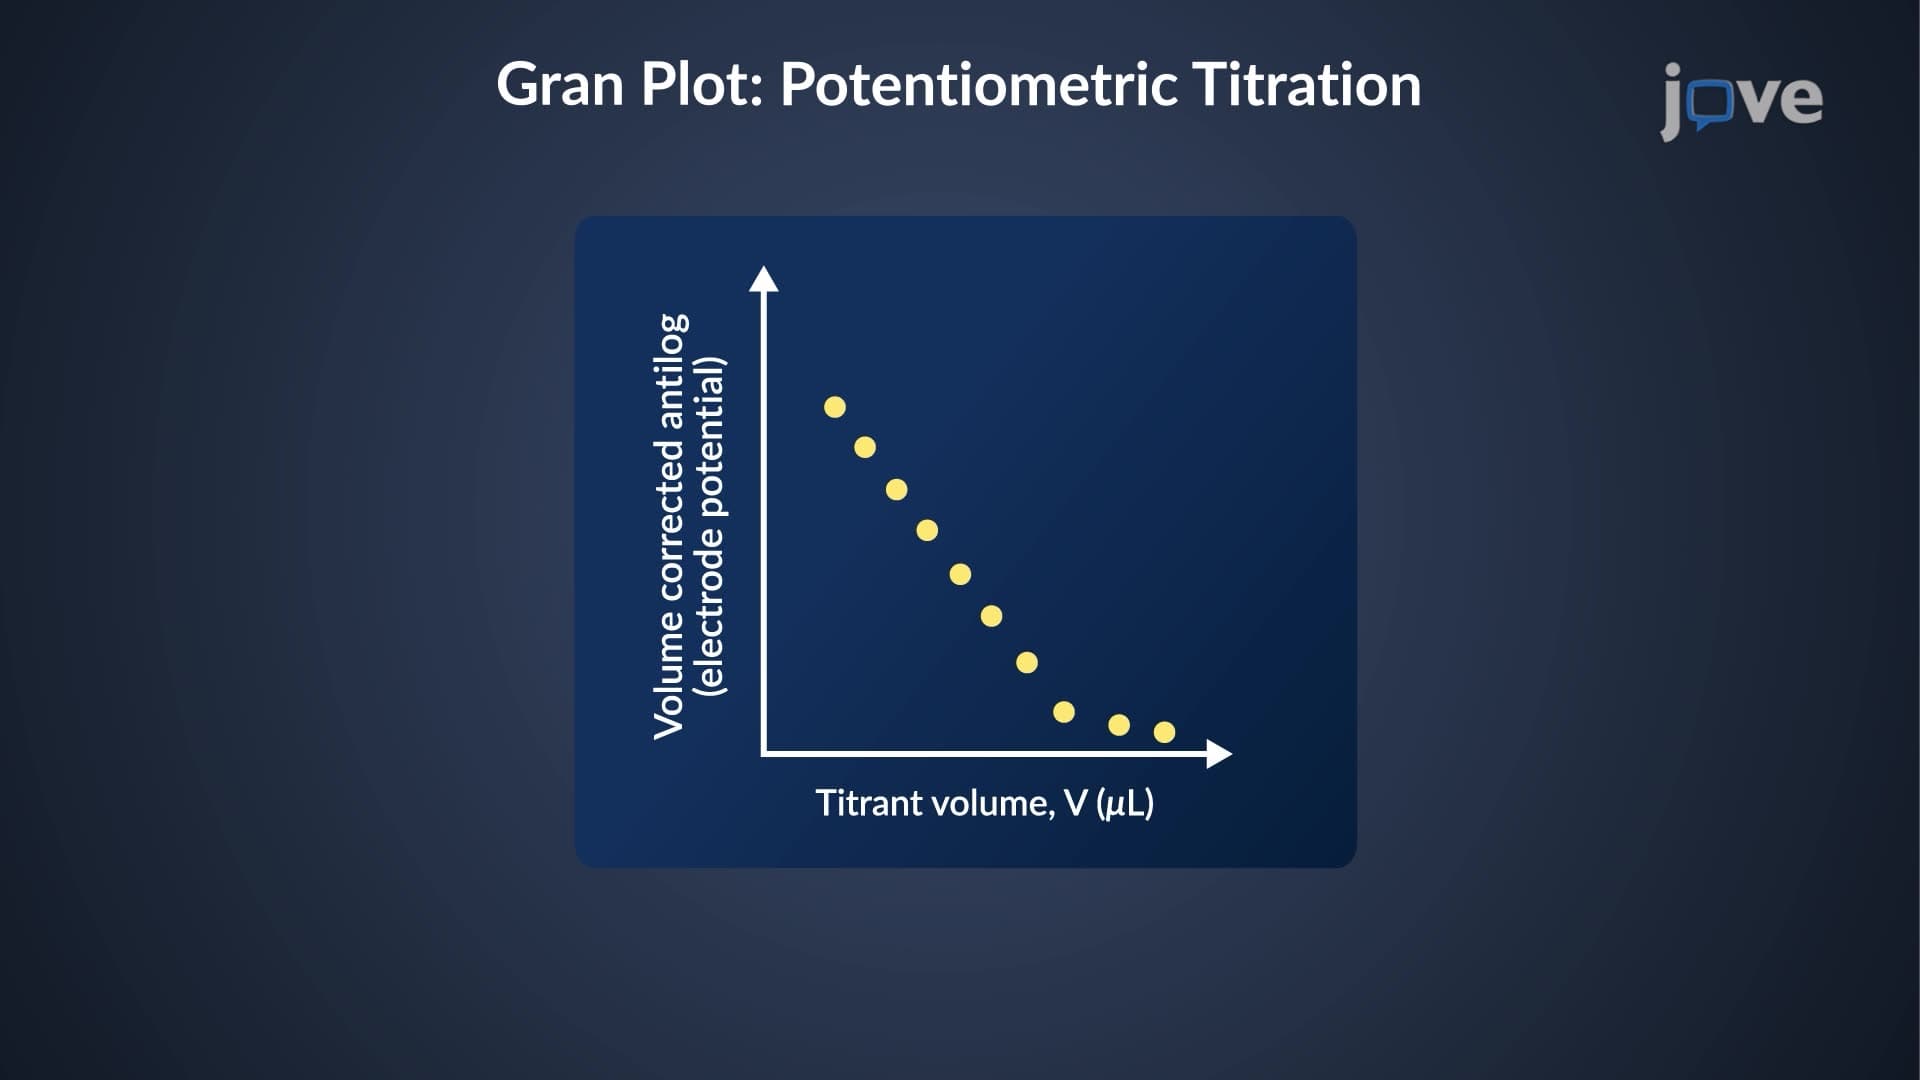
A Gran plot is used to predict the equivalence volume or endpoint of a potentiometric or acid-base titration without reaching the endpoint. Typically, titration data is collected as a function of the titrant's volume up to a point less than the equivalence volume and then transformed into a linear format. The straight line is extended to the x-axis, indicating the necessary titrant volume to achieve the equivalence point.
For potentiometric titration, the Gran plot is created by plotting...
For potentiometric titration, the Gran plot is created by plotting...
614
 02:04
Conservation of Small Populations
13.7K
Small population sizes put a species at extreme risk of extinction due to a lack of variation, and a consequent decrease in adaptability. This weakens the chances of survival under pressures such as climate change, competition from other species, or new diseases. Large populations are more likely to survive pressures such as these, as such populations are more likely to harbor individuals that have genetic variants that are adaptive under new stresses. Small populations are much less...
13.7K
 01:03
Prediction Intervals
2.4K
The interval estimate of any variable is known as the prediction interval. It helps decide if a point estimate is dependable.
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
2.4K