相关实验视频
Updated: Sep 18, 2025

Photorealistic Learned Landscapes for Augmented Reality
Published on: June 27, 2025
一个强大的旋转等值特征提取框架,用于基于地面纹理的视觉定位
Yuezhen Cai1, Linyuan Xia1, Ting On Chan1
1School of Geography and Planning, Sun Yat-sen University, Guangzhou 510275, China.

本研究介绍了Ground Texture Rotation-Equivariant关键点和描述符 (GT-REKD),这是一个用于强大的视觉定位的新框架. GT-REKD在具有挑战性的旋转和稀疏纹理下显著提高了姿势估计的准确性.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 计算机视觉 计算机视觉
- 人工智能的人工智能
背景情况:
- 基于地面纹理的本地化提供了强大的姿势估计,但与大旋转和稀疏纹理作斗争.
- 传统的特征提取方法在具有挑战性的地面纹理场景中缺乏可靠性.
研究的目的:
- 开发基于学习的特征提取框架,GT-REKD,以克服基于地面纹理的本地化局限性.
- 为了实现旋转不变的关键点和描述符提取,以提高本地化准确度.
主要方法:
- 实施了基于学习的框架 (GT-REKD),利用循环旋转组的组等价卷积.
- 集成的定向注意力和定向编码头用于精确的特征提取.
- 生成密集的关键点和描述符不变到0-360°的平面内旋转.
主要成果:
- 在纯旋转测试中,GT-REKD实现了96.14%的匹配,在增量本地化中达到94.08%.
- 证明了5.55°和4.41像素的低重新定位错误.
- 在极端旋转和稀疏纹理下始终优于基线方法.
结论:
- GT-REKD为旋转和稀疏纹理带来的视觉定位挑战提供了强大的解决方案.
- 该框架对视觉定位和同时定位和映射 (SLAM) 任务具有显著的适用性.
更多相关视频
 08:25
Combining Eye-tracking Data with an Analysis of Video Content from Free-viewing a Video of a Walk in an Urban Park Environment
Published on: May 7, 2019
 11:57
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy iPALM
Published on: December 1, 2016
相关概念视频
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Methods of Obtaining Topography
 01:16
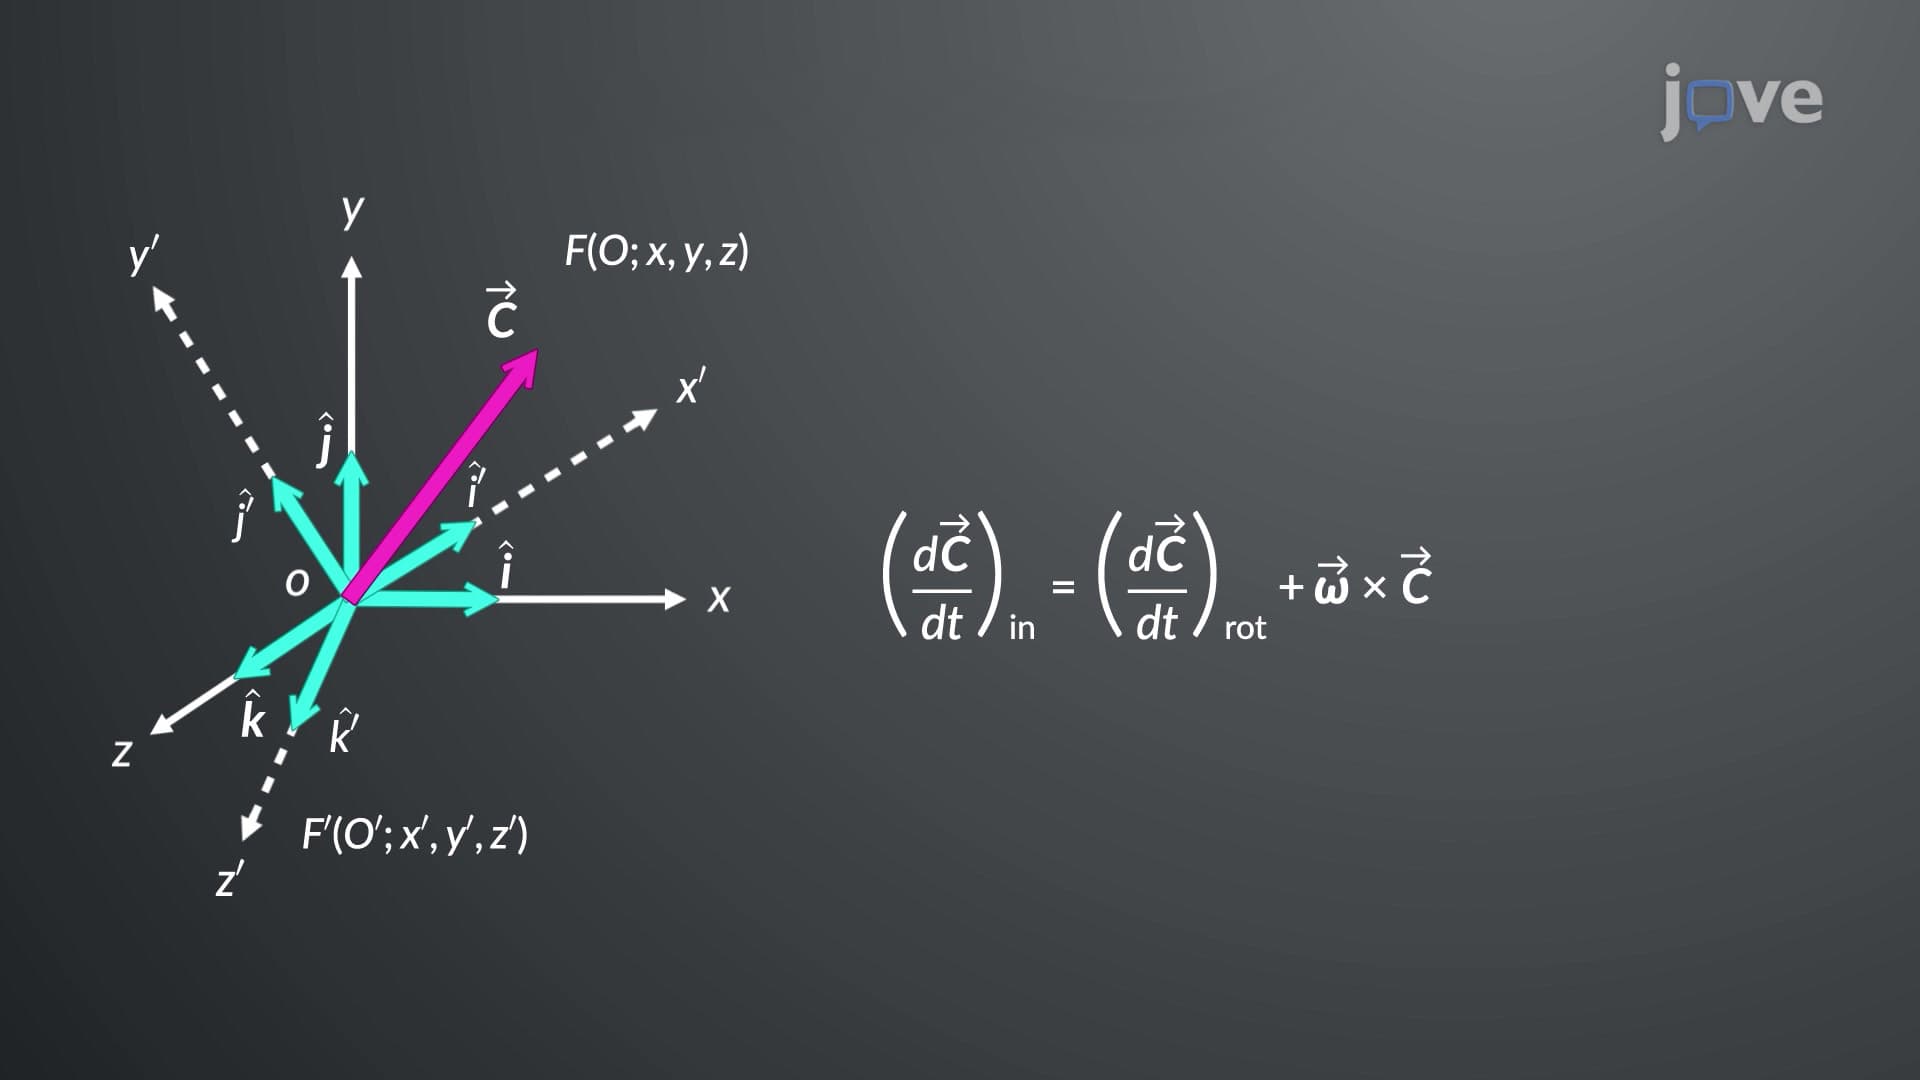
Vector Transformation in Rotating Coordinate Systems
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:25
Shape and Texture of Coarse Aggregate