使用现代低功率微控制器进行ORB加速的新方法
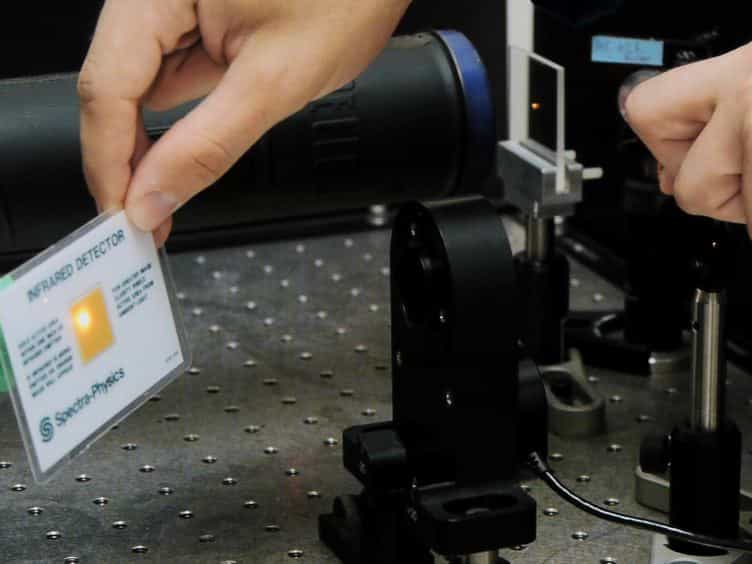
Jorge Aráez1, Santiago Real1, Alvaro Araujo1
1B105 Electronic Systems Lab, Escuela Técnica Superior de Ingenieros de Telecomunicación, Universidad Politécnica de Madrid, Avenida Complutense 30, 28040 Madrid, Spain.
Sensors (Basel, Switzerland)
|June 27, 2025

概括
本研究探讨在视觉同步定位和映射 (SLAM) 系统中使用微控制器进行面向快速和旋转简要 (ORB) 功能提取. 虽然比硬件加速速度慢,但它为特定应用提供了低功耗,具有成本效益的替代方案.
科学领域:
- 计算机视觉 计算机视觉
- 机器人技术 机器人技术 机器人技术
- 嵌入式系统 嵌入式系统
背景情况:
- 特性提取和描述对于视觉同时定位和映射 (SLAM) 系统至关重要.
- 面向快速和旋转简要 (ORB) 是一种常见的,但在SLAM中使用的计算密集型算法.
- 硬件加速 (FPGA,ASIC) 是一种典型的解决方案,但增加了成本.
研究的目的:
- 建议和评估使用低功耗微控制器的特征提取和描述解决方案.
- 分析微控制器上ORB算法的执行时间和功耗.
- 评估基于微控制器的ORB对SLAM应用的可行性.
主要方法:
- 在现代低功耗微控制器上实现ORB算法.
- 分析ORB执行时间变化的特征点和内部变量.
- 在ORB执行过程中测量功耗.
主要成果:
- 对于1241 × 376分辨率的图像,ORB执行时间最高达到0.6秒.
- 电力消耗在30到40毫瓦之间.
- 基于微控制器的解决方案比硬件加速速度慢,但对于某些应用程序来说是可行的.
结论:
- 基于微控制器的ORB实现为SLAM提供了比硬件加速更低功耗和更经济的替代方案.
- 性能适用于实时约束不那么严格的应用.
- 进一步优化可以提高基于微控制器的ORB对SLAM的性能.

相关概念视频
 01:37
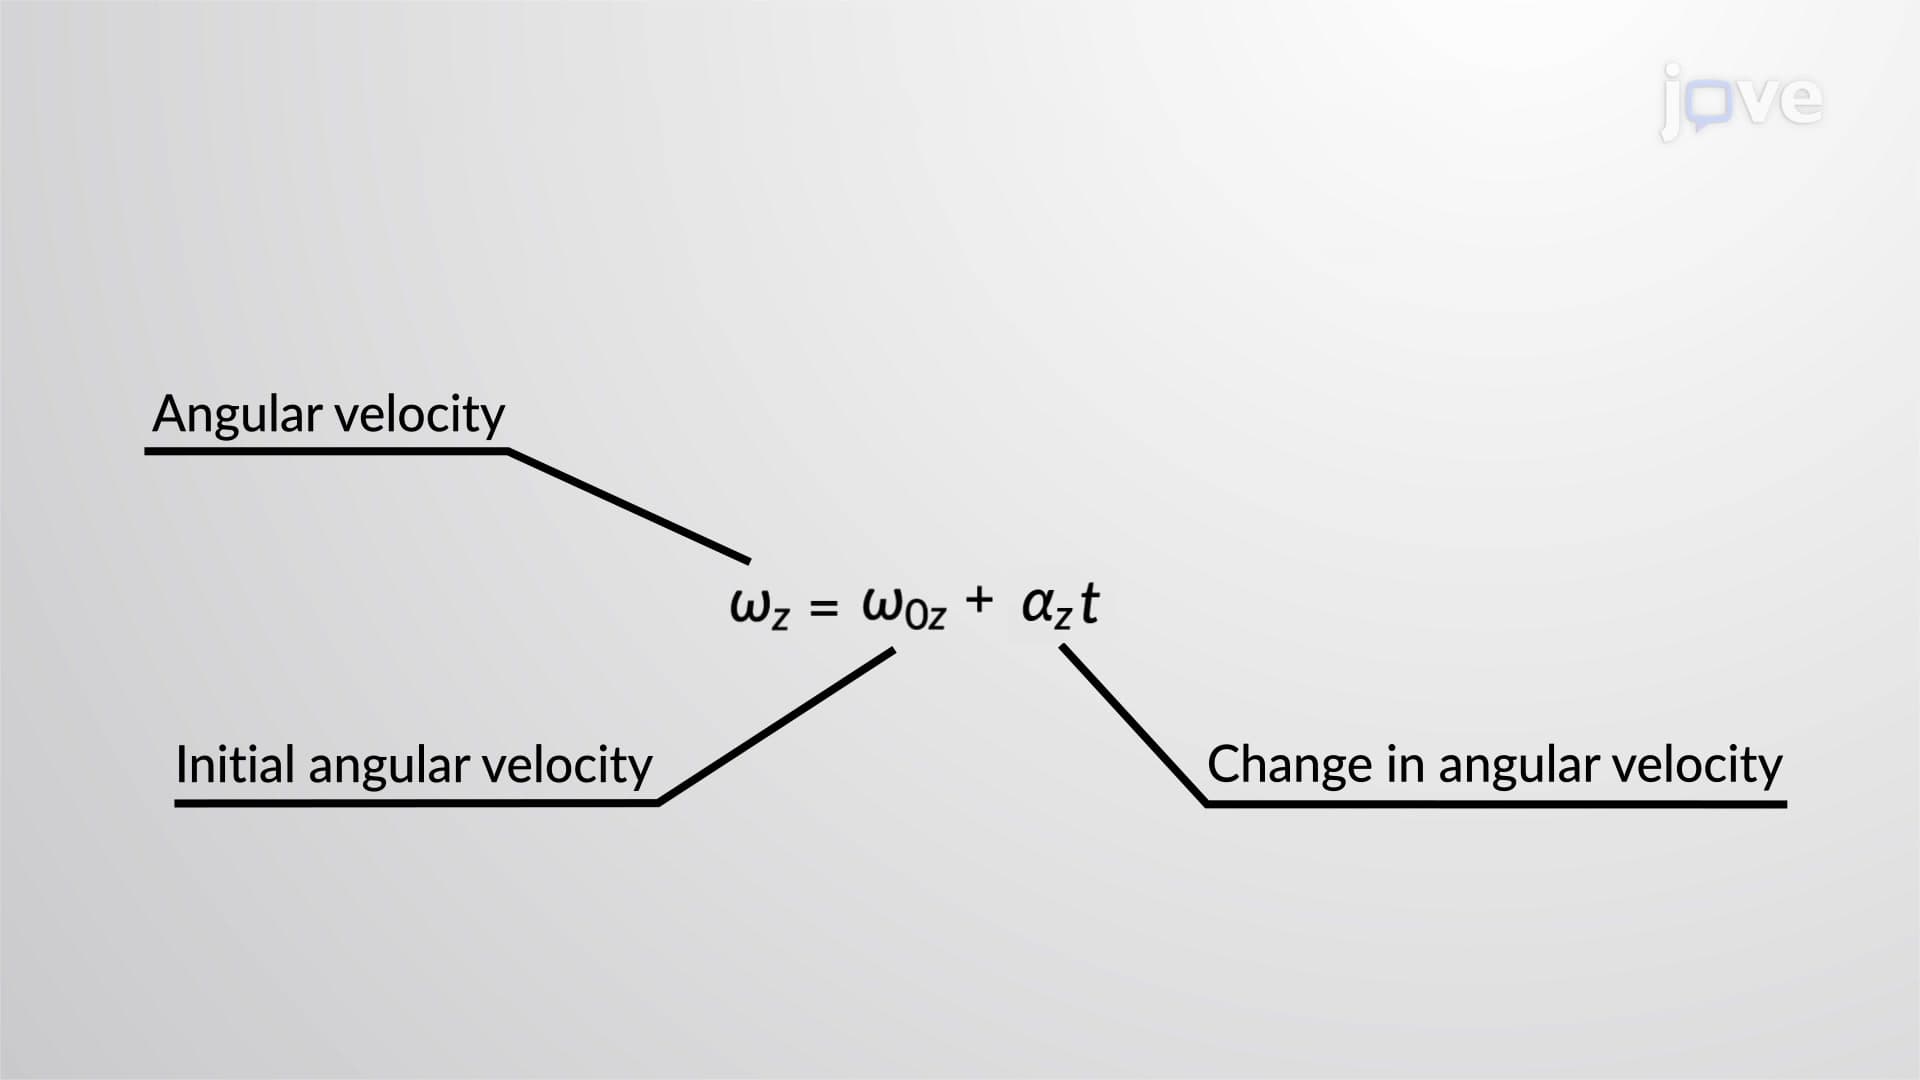
Rotation with Constant Angular Acceleration - I
6.9K
If angular acceleration is constant, then we can simplify equations of rotational kinematics, similar to the equations of linear kinematics. This simplified set of equations can be used to describe many applications in physics and engineering where the angular acceleration of a system is constant.
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
6.9K
 01:16
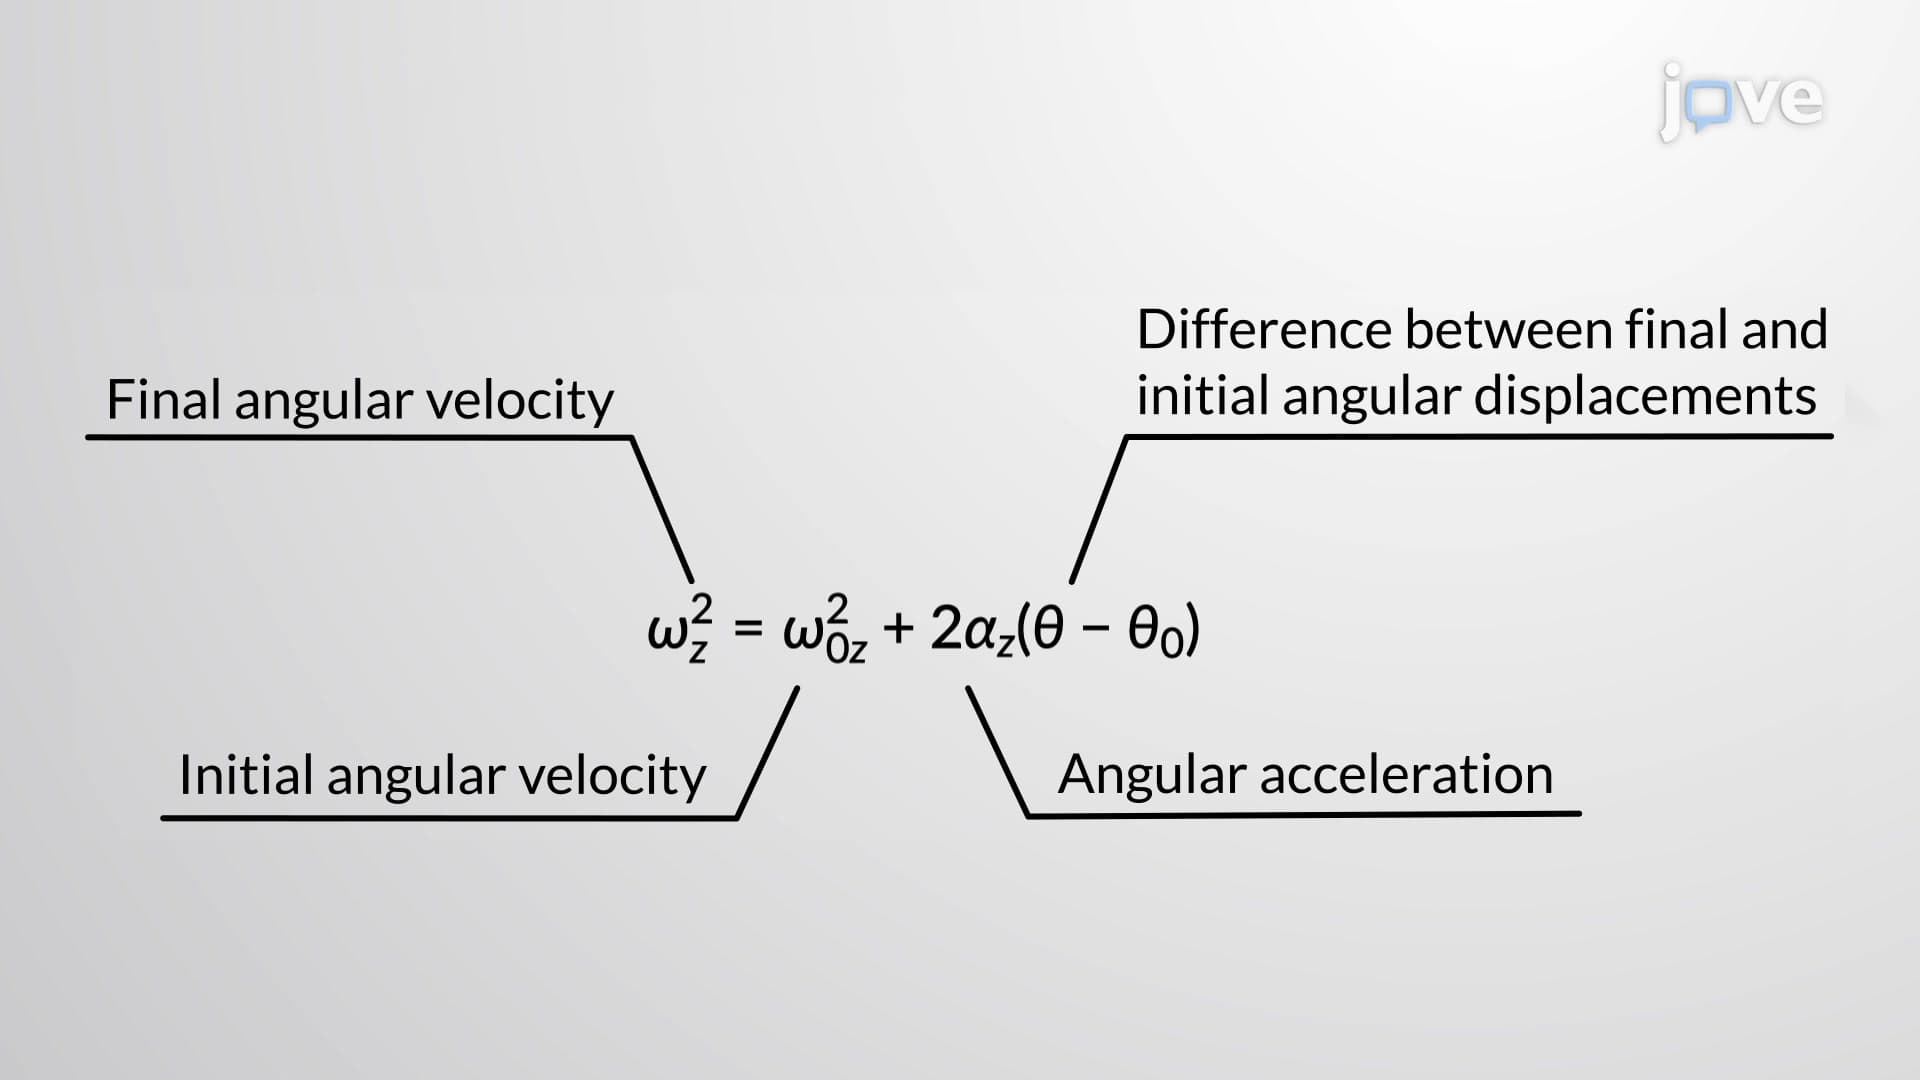
Rotation with Constant Angular Acceleration - II
6.2K
Kinematics is the description of motion. The kinematics of rotational motion discusses the relationships between rotation angle, angular velocity, angular acceleration, and time. One can describe many things with great precision using kinematics, but kinematics does not consider causes. For example, a large angular acceleration describes a very rapid change in angular velocity without any consideration of its cause. Thus, rotational kinematics does not represent the laws of nature.
The first...
The first...
6.2K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
405
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
405
 01:12
Measuring Acceleration Due to Gravity
699
Consider a coffee mug hanging on a hook in a pantry. If the mug gets knocked, it oscillates back and forth like a pendulum until the oscillations die out.
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
699
 01:24
PI Controller: Design
508
Proportional Integral (PI) controllers are a fundamental component in modern control systems, widely used to enhance performance and mitigate steady-state errors. They are particularly effective in applications such as automatic brightness adjustment on smartphones, where they excel at mitigating steady-state errors for step-function inputs. Unlike PD controllers, which require time-varying errors to function optimally, PI controllers leverage their integral component to address residual...
508
 01:26
PD Controller: Design
358
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
358