

一个非单元快速终端滑动模式控制方案,用于在垂直平面中对未经调节的EvoBot模块化移动机器人进行强大的轨迹跟踪
1Department of Mechanical Engineering, Firouzabad Higher Education Center, Shiraz University of Technology, Shiraz, Iran.
ISA transactions
|June 28, 2025

概括
这项研究为一台未成熟的EvoBot移动机器人提出了强大的控制策略,确保了尽管存在不确定性和干扰,但仍能精确地跟踪轨迹. 新型非单元快速终端滑动模式控制可保证稳定性和精确的运动控制.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统工程 控制系统工程
- 应用数学 应用数学 应用数学
背景情况:
- 由于执行器的有限性,未完善的机器人系统会带来重大控制挑战.
- 像EvoBot这样的移动机器人模拟为双反向子,需要复杂的控制来实现稳定的垂直平面运动.
研究的目的:
- 开发一个强大的控制策略,用于EvoBot移动机器人的垂直平面运动.
- 为了实现精确的轨迹跟踪,无论是启动和非启动的通用坐标.
主要方法:
- 使用拉格朗的方法推导系统动态方程.
- 介绍了一种新的非线性和非单元滑动分流体.
- 关于非单元快速终端滑动模式控制 (NFTSMC) 方案的建议.
主要成果:
- 利亚普诺夫稳定性分析证实了追踪误差的有限时间非对称收.
- 该NFTSMC方案有效地处理下调,非线性,不稳定性,参数不确定性和外部干扰.
- MATLAB模拟验证了在各种干扰频率和参数不确定性下控制方案的有效性.
结论:
- 拟议的NFTSMC提供了一个强大而有效的解决方案,用于控制低精度的移动机器人.
- 控制策略确保可靠的轨迹跟踪和稳定性,即使存在系统不确定性和外部干扰.


相关概念视频
 01:24
One-Degree-of-Freedom System
561
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
561
 01:24
Absolute Motion Analysis- General Plane Motion
273
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
273
 01:15
Kinematic Equations: Problem Solving
15.1K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
15.1K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
453
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
453
 01:13
Linear Momentum in Control Volume
1.1K
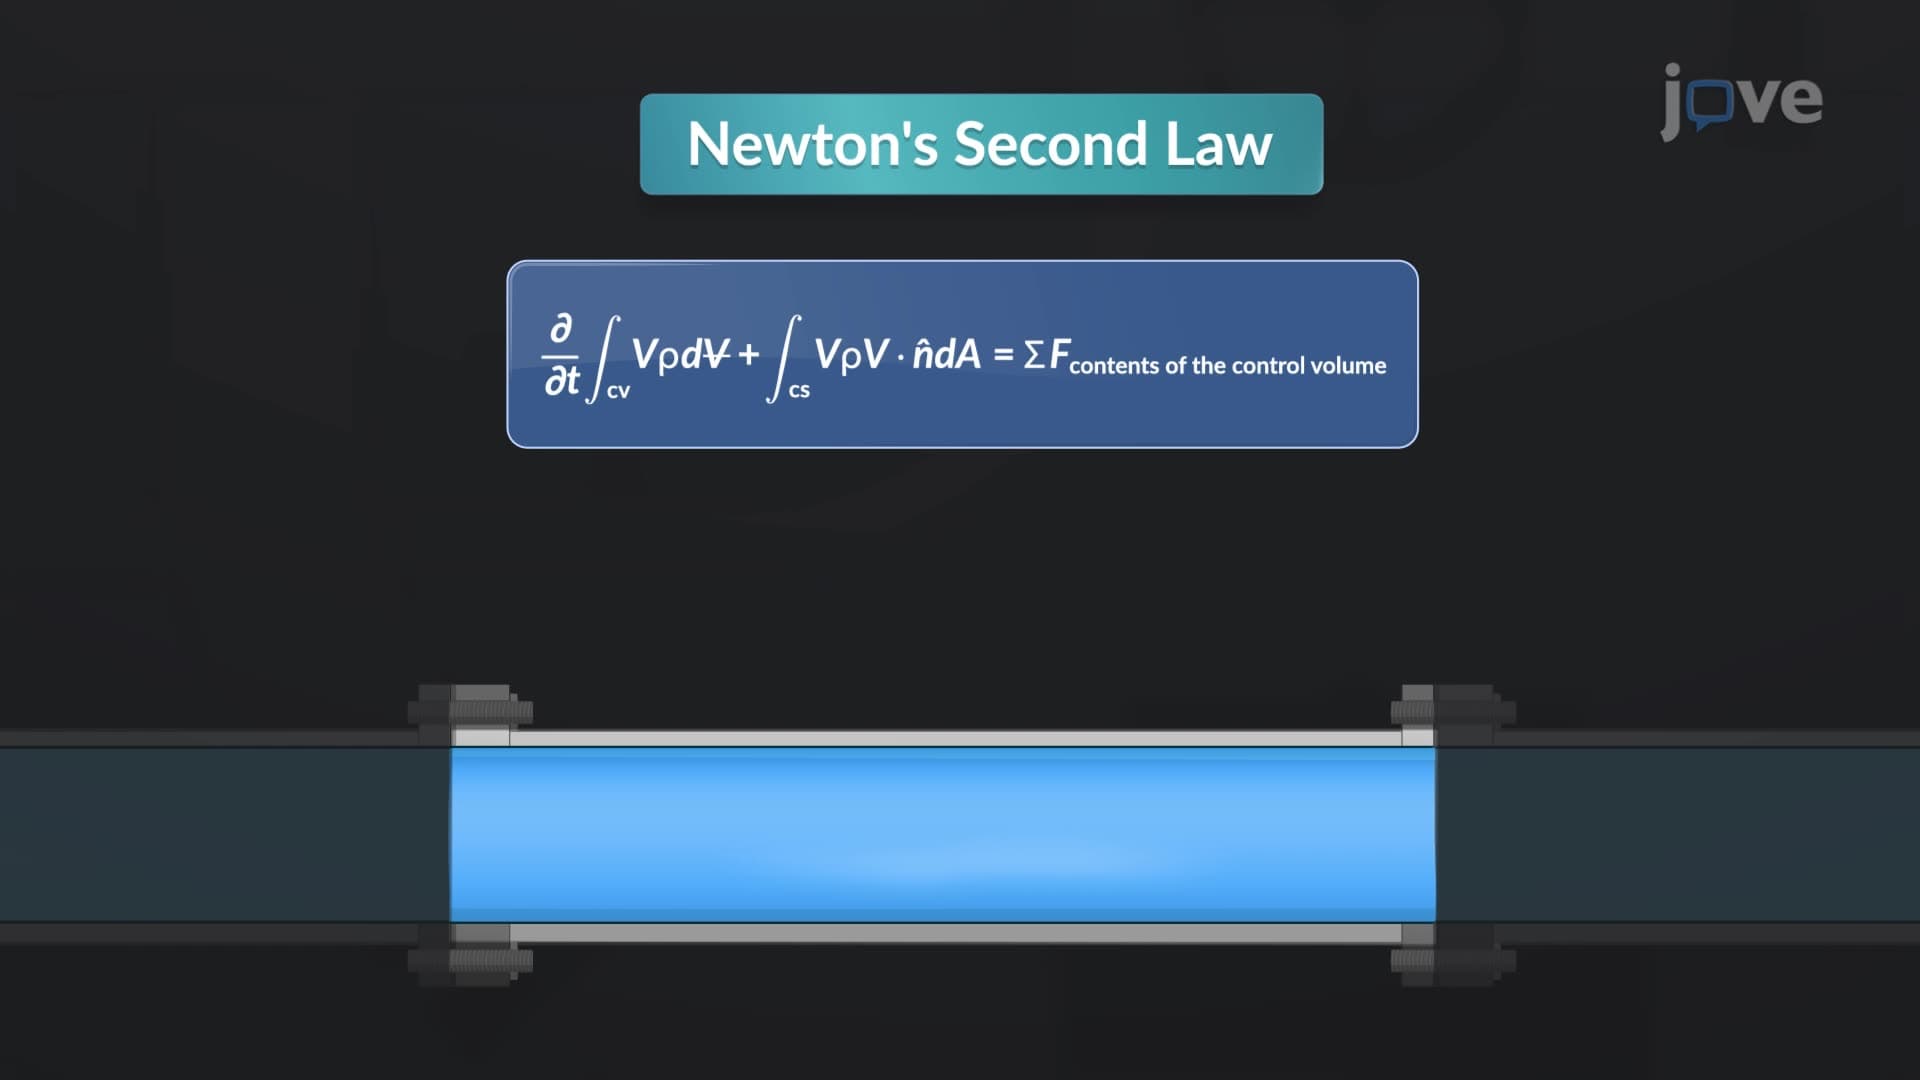
Newton's second law is applied to obtain the linear momentum in a control volume in a fluid system. According to this law, the rate of change of linear momentum is equal to the sum of external forces acting on the system. When a control volume matches the fluid system at a specific moment, the forces acting on both are identical. Reynolds transport theorem helps explain this by breaking down the system's linear momentum into two components: the rate of change of linear momentum within...
1.1K
 01:22
Planar Rigid-Body Motion
562
Understanding the movement of a rigid body in planar motion involves recognizing that every particle within this body is traversing a path that maintains a consistent distance from a specific plane. This concept is fundamental in the study of physics and mechanical engineering, and it allows us to comprehend better how objects move in space.
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
562