
在有限距离的自主任务中,InvSim算法用于预计算飞机飞行控制器,并通过Mirage III战斗机的双滚机动演示
1College of Engineering, University of Buraimi, Al Buraimi, 512, Sultanate of Oman. osama.m@uob.edu.om.
Scientific reports
|July 2, 2025

概括
本研究开发了一种用于飞行力学的反向模拟 (InvSim) 方法,用于预测所需轨迹的飞机控制输入. 该系统使用六度自由度 (6-DOF) 框架和数值集成来计算控制表面的偏移和机动的推力.
科学领域:
- 航空航天工程 航空航天工程
- 飞行机械师 飞行机械师
- 计算动力学是一种计算动力学.
背景情况:
- 飞行力学传统上专注于从已知的控制器预测飞机运动.
- 反向模拟对于控制系统设计和轨迹优化至关重要.
- 现有的方法可能缺乏对一般飞机配置的全面框架.
研究的目的:
- 为6度自由 (6-DOF) 飞机运动方程 (EOM) 开发一个通用的数学框架.
- 在飞行力学中导出一个定制的EOM版本用于反向模拟 (InvSim).
- 为计算实现目标轨迹所需的飞行控制所需的数值程序提供一个数值程序.
主要方法:
- 构建一个通用的6-DOF EOM,包括机体,惯性和风轴,以及球形飞行和飞行路径角度.
- 使用符号数学,明确的第四阶Runge-Kutta (RK4) 和有限差异方法 (FDM) 开发InvSim系统.
- 计算四个控制变量:发动机推力,飞,升降机和杆偏移.
主要成果:
- 为InvSim系统成功开发和集成了一个时序数值程序.
- 计算了离散控制变量值,以实现指定的飞行轨迹.
- 用一个Mirage III飞机示例演示了InvSim程序,模拟了次声波双滚机动.
结论:
- 拟议的InvSim方法为确定所需飞机机动作所需的飞行控制历史提供了一种可行的方法.
- 数字程序有效计算基于轨迹和态度规格的控制输入.
- 该框架提高了设计复杂飞行轨迹和相关控制策略的能力.

相关概念视频
 01:22
Multi-input and Multi-variable systems
152
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
152
 01:24
Absolute Motion Analysis- General Plane Motion
273
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
273
 01:19
Principle of Angular Impulse and Momentum: Problem Solving
273
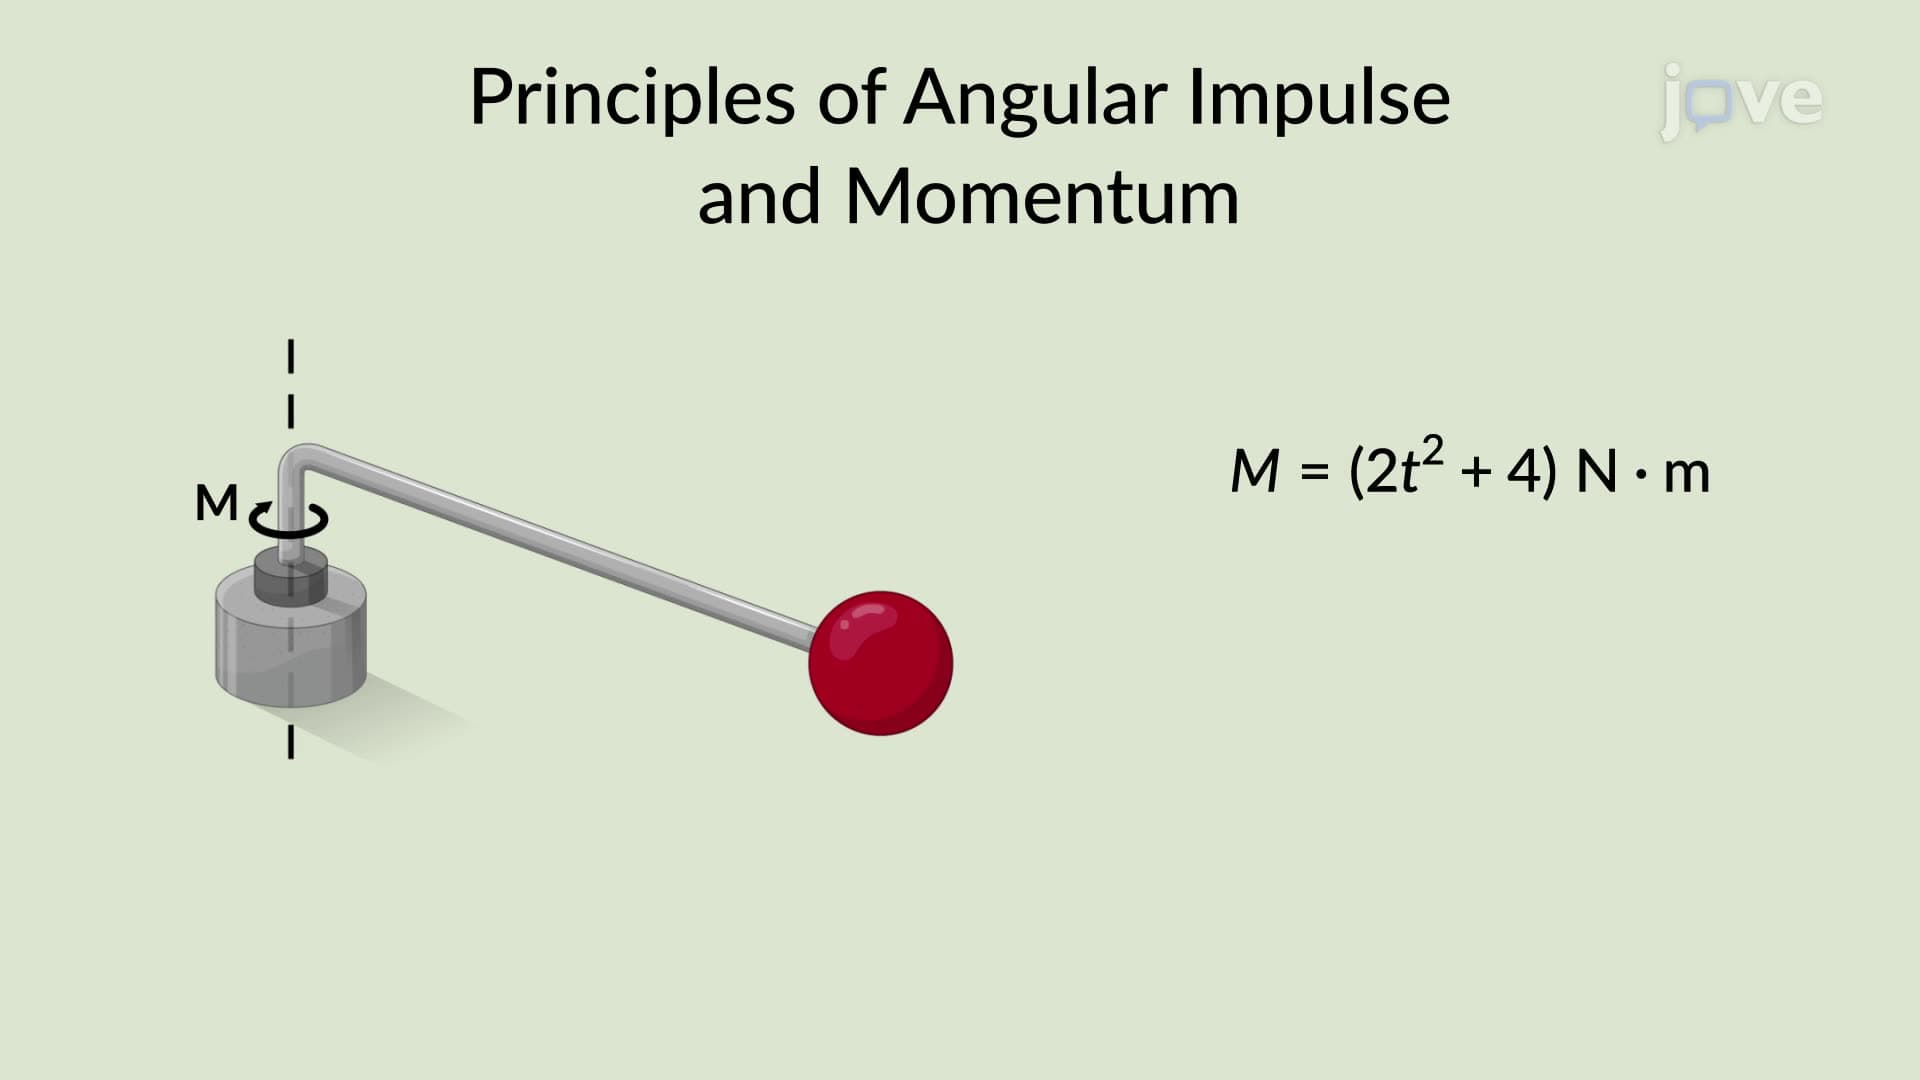
Consider a ball of mass m, attached to a massless rod of known length, subjected to a time-dependent torque. If the initial velocity of the mass is known, then the final velocity of the mass for time t can be determined using the principle of angular impulse and momentum.
Initially, a free-body diagram of the system is drawn to illustrate all the forces acting upon the system, providing a crucial understanding of the dynamics at play. Then, the principle of angular impulse and momentum is...
Initially, a free-body diagram of the system is drawn to illustrate all the forces acting upon the system, providing a crucial understanding of the dynamics at play. Then, the principle of angular impulse and momentum is...
273
 01:22
Controller Configurations
153
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
153
 01:30
Three-Dimensional Force System:Problem Solving
872
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
872
 01:24
One-Degree-of-Freedom System
561
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
561