基于被动性和消散性的模糊控制,在时间尺度上对四次数值的记忆神经网络进行模糊控制
Ruoxia Li1, Jinde Cao2, Zhengwen Tu3
1School of Mathematics and Statistics, Shaanxi Normal University, Xi'an, 710062 China.
Cognitive neurodynamics
|July 3, 2025

概括
这项研究建立了分数顺序四次数值模糊记忆神经网络中被动性和消散性的新标准. 这些发现为分析这些复杂系统提供了有效的方法.
科学领域:
- 复杂系统分析 复杂系统分析
- 神经网络理论 神经网络理论
- 分数微积分的计算.
背景情况:
- 分数顺序系统提供了增强的建模功能.
- 记忆神经网络表现出复杂的动态.
- 四值系统对于先进的应用至关重要.
研究的目的:
- 研究分数顺序四次数值模糊记忆神经网络中的被动性和消散性.
- 为这些系统制定新的分析标准.
- 提供高效和可验证的分析方法.
主要方法:
- 构建一个合适的Lyapunov功能.
- 应用先进的不平等技术.
- 开发特定于四子的分析方法,避免大小考虑.
主要成果:
- 建立了改进的被动性标准.
- 推导出新的散射性结论.
- 通过标准数学计算来证明分析效率.
结论:
- 提出的技术有效地分析分数顺序四次数值的模糊记忆神经网络.
- 这些方法具有计算效率和可验证性.
- 模拟示例证实了开发的标准的有效性.
相关概念视频
 01:07
Time-Domain Interpretation of PD Control
183
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
183
 01:27
Time and frequency -Domain Interpretation of PI Control
208
Proportional-Integral (PI) controllers are essential in many control systems to improve stability and performance. They are commonly used in everyday devices like thermostats to enhance system damping and reduce steady-state error. When the zero in the controller's transfer function is optimally placed, the system benefits significantly in terms of stability and accuracy.
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
208
 01:21
Transfer Function in Control Systems
889
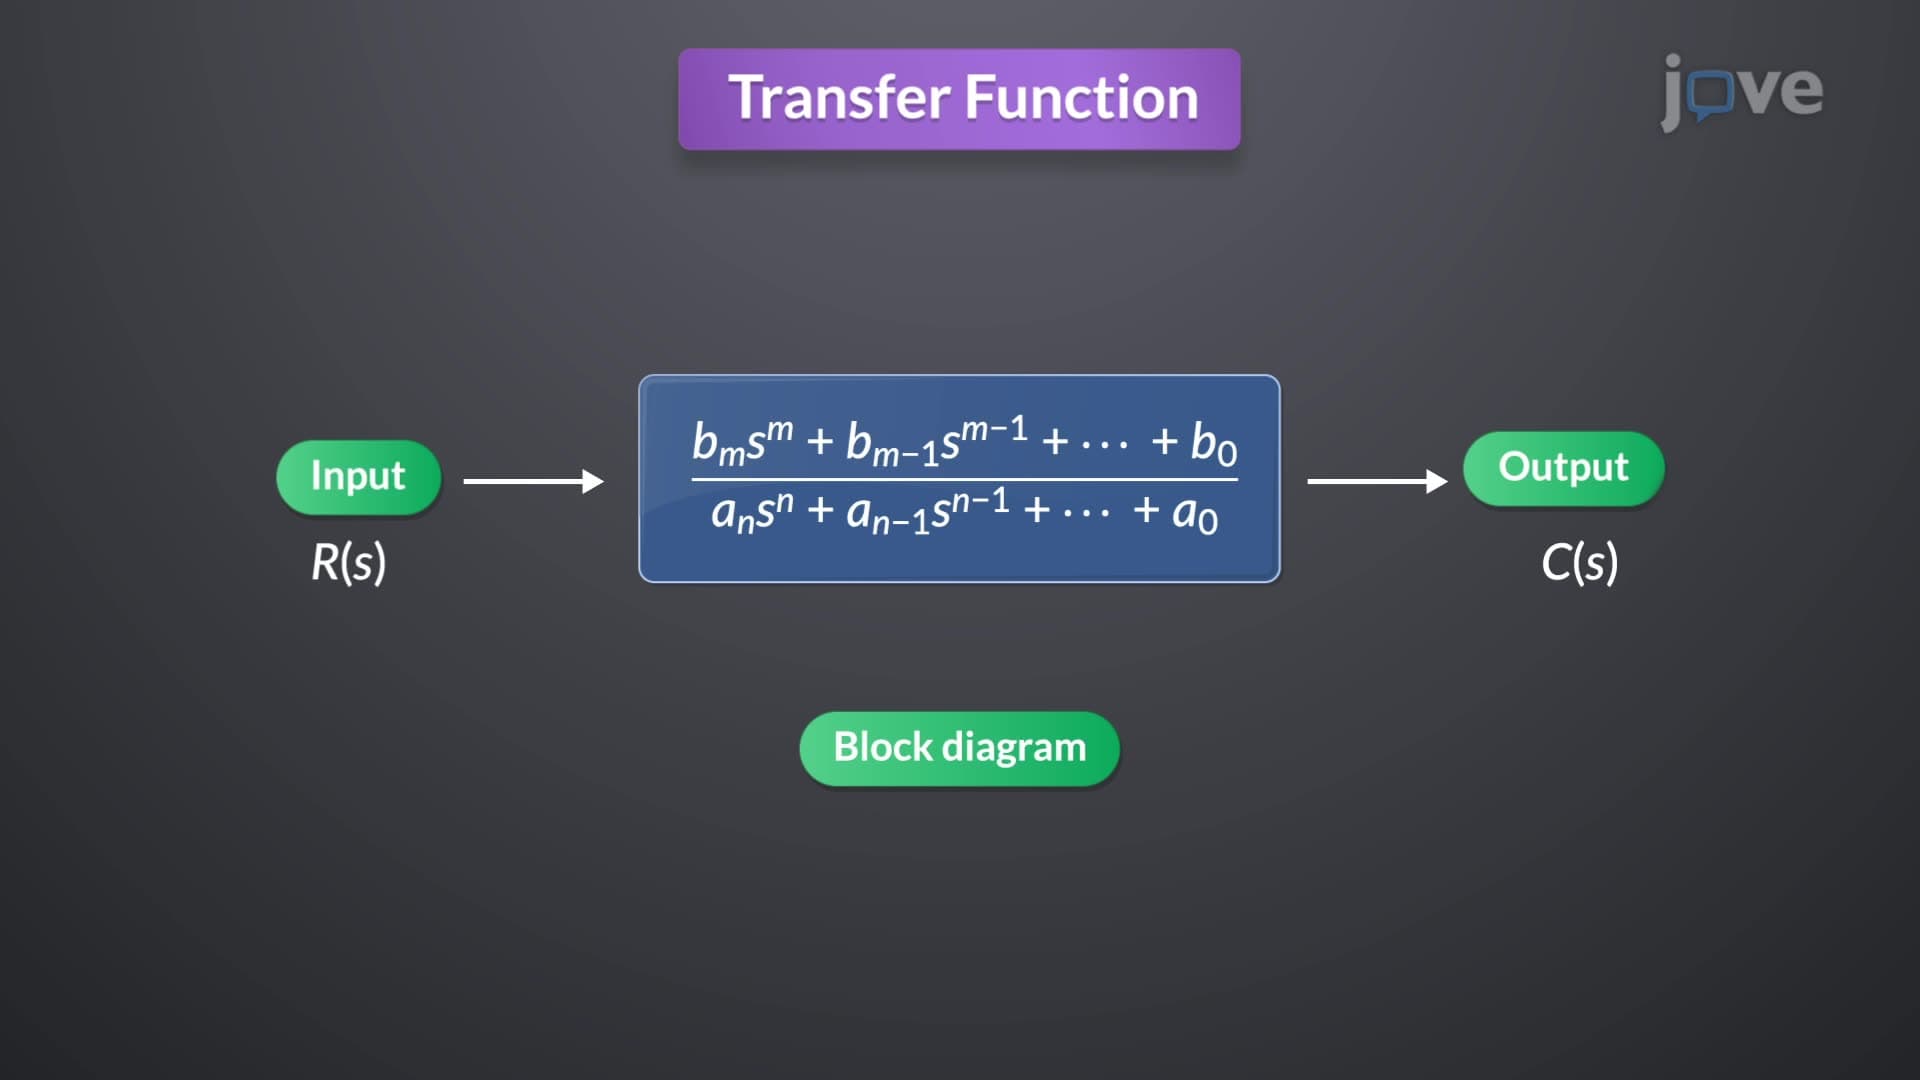
The transfer function is a fundamental concept in the analysis and design of linear time-invariant (LTI) systems. It offers a concise way to understand how a system responds to different inputs in the frequency domain. It serves as a bridge between the time-domain differential equations that describe system dynamics and the frequency-domain representation that facilitates easier manipulation and analysis.
To derive the transfer function, consider a general nth-order linear time-invariant...
To derive the transfer function, consider a general nth-order linear time-invariant...
889
 01:27
State Space Representation
296
The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
Consider an RLC circuit, a...
296
 01:22
Mechanical Systems
294
Mechanical systems are analogous to to electrical networks where springs and masses play similar roles to inductors and capacitors, respectively. A viscous damper in mechanical systems functions similarly to a resistor in electrical networks, dissipating energy. The forces acting on a mass in such systems include an applied force in the direction of motion, counteracted by forces from the spring, a viscous damper, and the mass's acceleration. This interplay of forces is mathematically...
294
 01:17
Open and closed-loop control systems
1.0K
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
1.0K