对于多元组件单波动力学而言,Gross-Pitaevskii系统的分数顺序是分数顺序
Muhammad Bilal1, Yazen M Alawaideh2, Shafqat Ur Rehman3
1Department of Physics, Shanghai University, Shanghai, 200444, China.
Scientific reports
|July 7, 2025

概括
这项研究比较了解决格罗斯-皮塔耶夫斯基方程的两个分数导数,发现β-导数提供了更简单,更光滑的单子,而M截断的导数则为非线性波现象产生了更丰富的动态.
科学领域:
- 非线性动力学是一种非线性动力学.
- 数学物理学的数学物理.
- 凝聚物质物理学 凝聚物质物理学
背景情况:
- 分数格罗斯-皮塔耶夫斯基方程 (Gross-Pitaevskii equation,简称GPE) 对于模拟超流动性和超导电性等非线性现象至关重要.
- 了解非线性波浪演变中的分数顺序效应是推动这些领域发展的关键.
研究的目的:
- 为了比较分析β-分数和M-截断的分数导数在解决复杂的分数GPE时的有效性.
- 用先进的分析方法推导和验证精确的单离子溶液.
主要方法:
- 通用扩展直接代数方法 (gEDAM)
- 库马尔-马利克 (KM) 方法
- 使用Wolfram Mathematica进行验证
主要成果:
- 无论是β-衍生物还是M-截断衍生物,都会产生多种不同的单离子溶液 (超标,周期,雅可比圆,指数).
- β-衍生提供了更光滑的单子形状和计算简单性.
- 由于增强的记忆效应,M截断的衍生品捕获了更丰富的振荡动态.
结论:
- 该研究为建模非线性分数动态提供了一个强大的框架.
- 比较的见解加深了对非线性波浪演变中的分数顺序效应的理解.
- 结果在光纤,等离子体物理学和凝聚物质系统中具有潜在的应用.
相关概念视频
 01:18
Second Order systems II
173
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
173
 01:20
Second Order systems I
239
A servo system exemplifies a second-order system, featuring a proportional controller and load elements that ensure the output position aligns with the input position. The relationship between these components is described by a second-order differential equation. Applying the Laplace transform under zero initial conditions yields the transfer function, showing how inputs are converted to outputs in the system.
By reinterpreting the system, one can derive the closed-loop transfer function, which...
By reinterpreting the system, one can derive the closed-loop transfer function, which...
239
 01:21
Linear Approximation in Time Domain
128
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
128
 01:21
First Order Systems
167
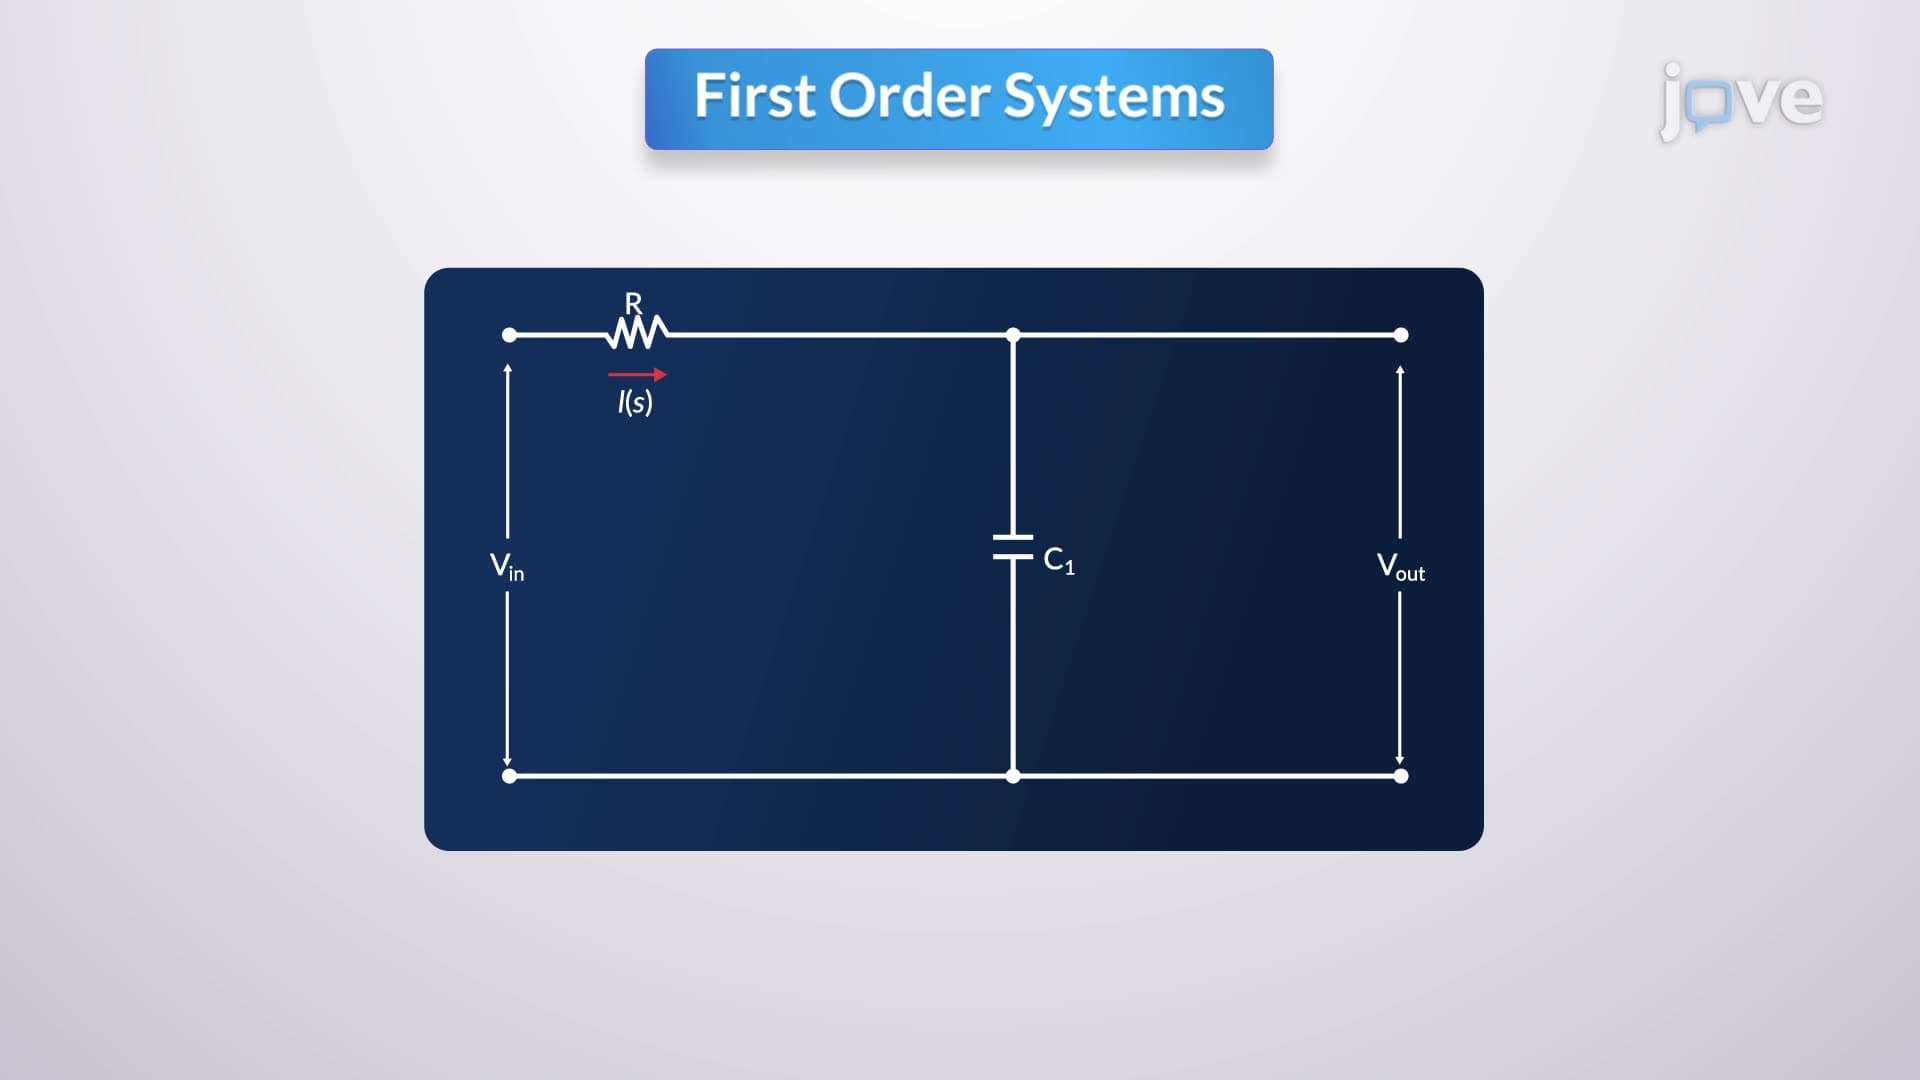
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
167
 01:24
Pole and System Stability
424
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
424
 01:02
Equations of Wave Motion
6.0K
Mathematically, the motion of a wave can be studied using a wavefunction. Consider a string oscillating up and down in simple harmonic motion, having a period T. The wave on the string is sinusoidal and is translated in the positive x-direction as time progresses. Sine is a function of the angle θ, oscillating between +A and −A and repeating every 2π radians. To construct a wave model, the ratio of the angle θ and the position x is considered.
6.0K